
2 layers75.4 × 75.4 mm
53xLIDAR
valerionew/53xLIDAR
53xLIDAR is a solid state, 16 points lidar, based on ST's VL53L1x sensors
61 parts11

 valerionew/53xLIDAR11
53xLIDAR is a solid state, 16 points lidar, based on ST's VL53L1x sensors
Module is an open-source printed circuit board by valerionew, from the valerionew/53xLIDAR repository on GitHub. It is a 2-layer board of 76 × 70.3 mm with 294 parts on 6 nets, routed with 2,272 tracks and 352 vias.
It is built around the VL53L1X. Its parts include 128 resistors, 64 capacitors, 64 connectors and 32 ICs. It belongs with the sensors and measurement boards of this library.
Project for an opensource, all-in-one, solid state lidar.
The lidar is made with 16 VL53L1x Time-of-flight IR ranging sensors.
The sensors are operated by an STM32F411RE on two separate I2C buses, one for sensor 1-8, the other for 9-16.
The XSHUTs are shared between two sensors on the two different I2C buses, while the sensors interrupts are separate for each sensor.
For future use, there is an LSM9DS1, 9 DOF inertial sensor onboard.
The lidar outputs the data via a virtual com port from the native Micro-USB, or via a 3.3V UART on a 4 pin JST-PH connector.
Power (5V 100mA) is provided through the USB or via the 4 pin uart connector.
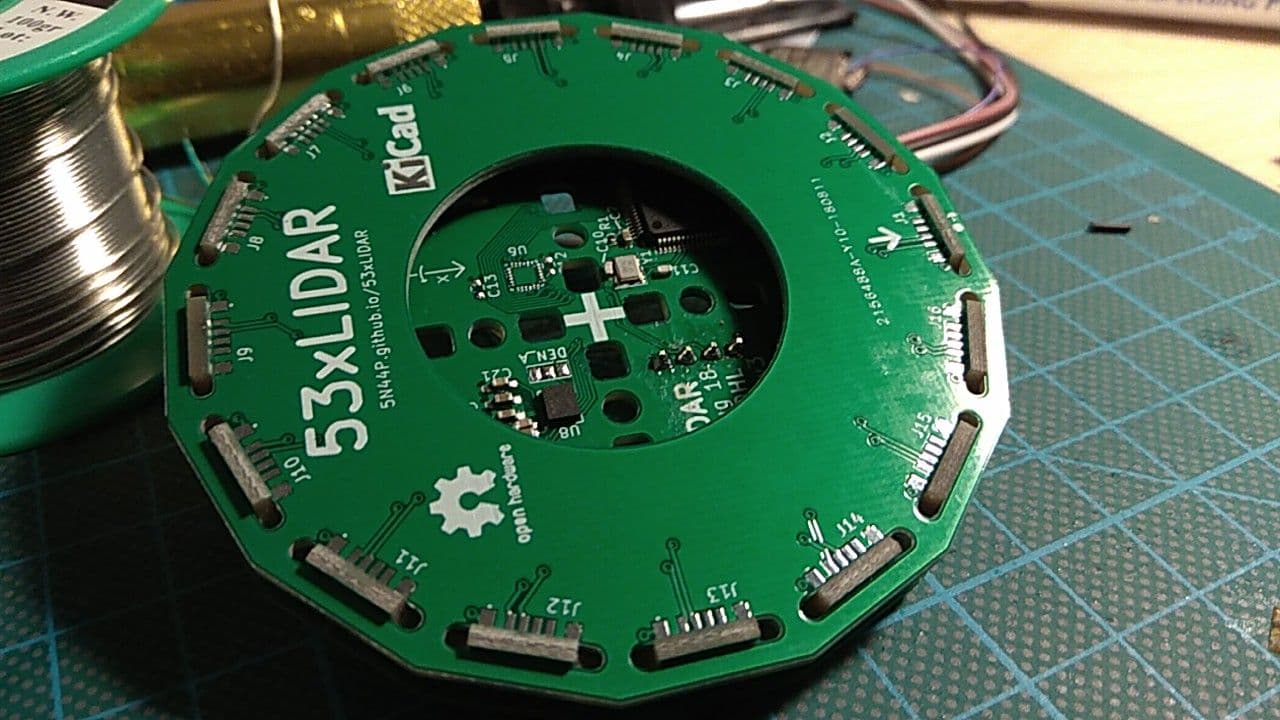
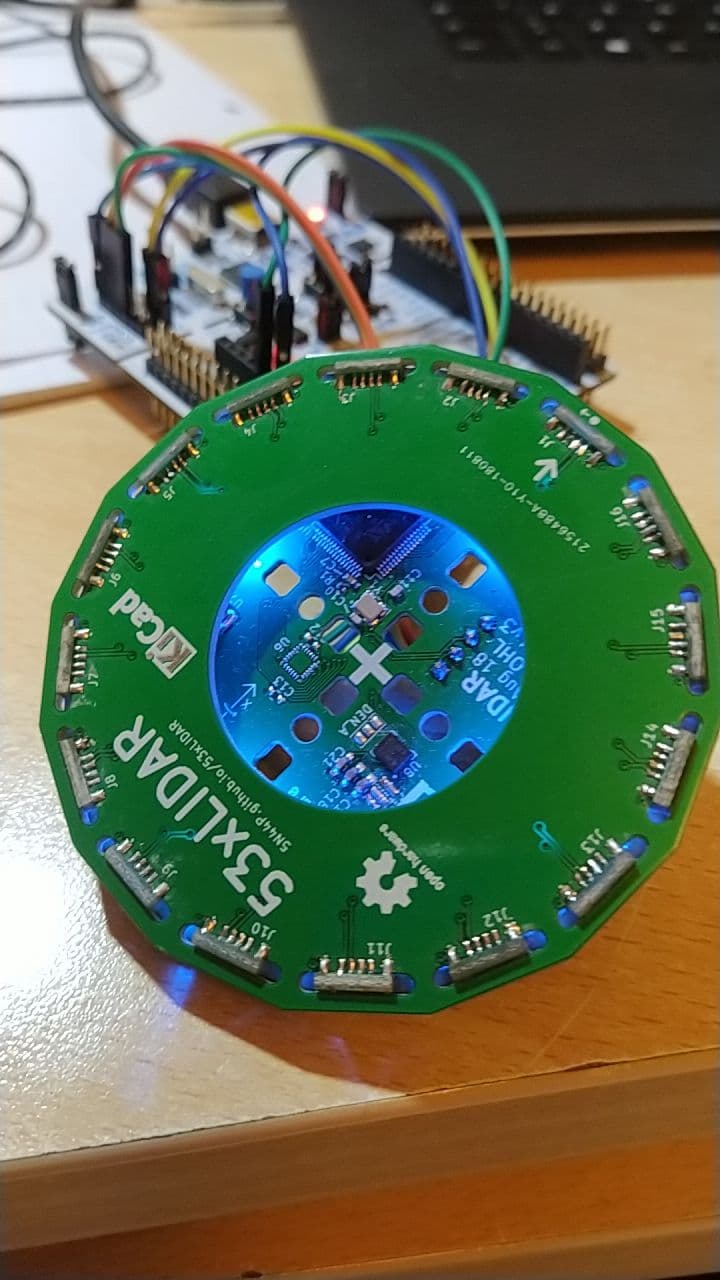
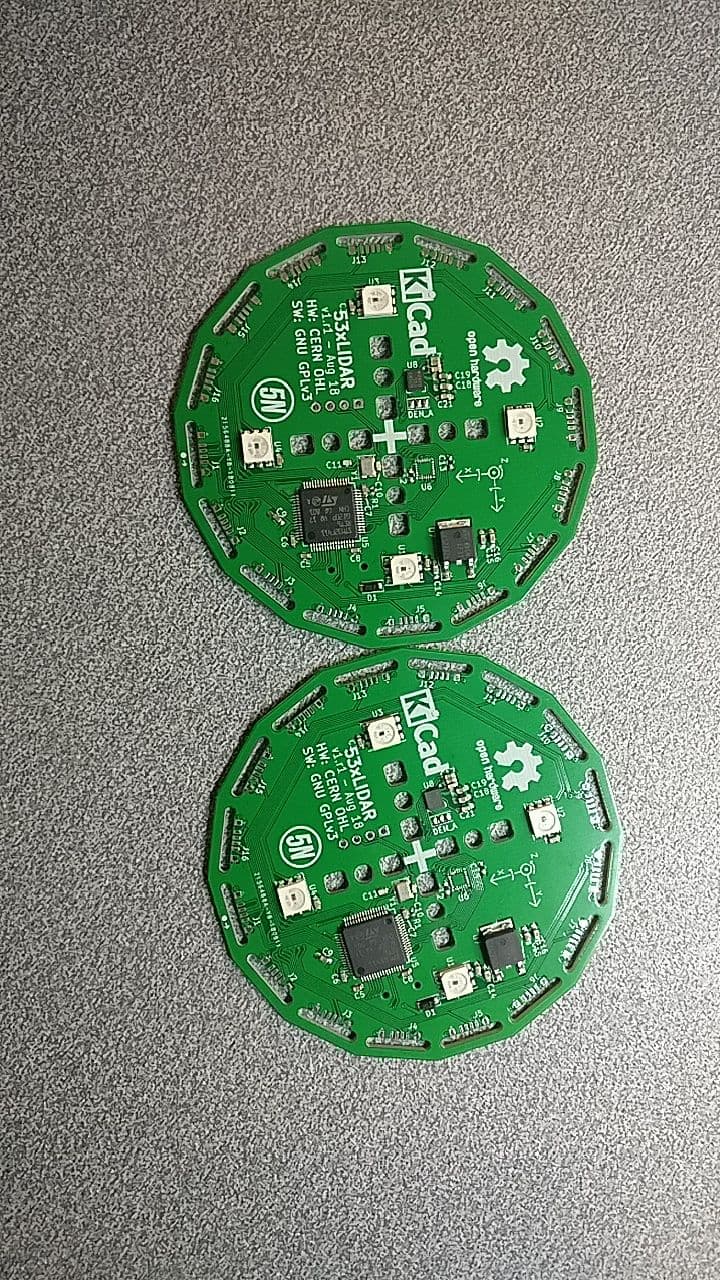
The hardware is designed in KiCAD and released under CERN OHL licence.
It is formed by 16 sensor daughter boards, arranged in a 32 modules panel (only half panel is needed for one lidar, but for manufacturing reasons is made as a 32 modules panel); a bottom board containing all the electronics; a top board which brings the I2C line to the sensors and adds mechanical strenght and protection to the sensors.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 128 | 10k | Resistors_SMD:R_0603 | R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5, R5 +112 |
| 64 | CONN_01X06 | custom-footprints:CONN_Module | J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1, J1 +48 |
| 32 | 100n | Capacitors_SMD:C_0603 | C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1, C1 +16 |
| 32 | 4.7u | Capacitors_SMD:C_0603 | C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2, C2 +16 |
| 32 | VL53L1X | custom-footprints:ST_VL53L_HandSoldering | U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1, U1 +16 |
The 288 most common of 294 parts.
It measures 76 × 70.3 mm and has 2 copper layers, 1.6 mm thick.
294 parts, built around the VL53L1X. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the valerionew/53xLIDAR repository on GitHub, at the commit this page was made from: the board is hardware/src/modules/module.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask valerionew before reusing the design.


CloudyPadmal/CrazyFlieToFDeck
This repository contains KiCAD source files and generated gerber files for CrazyFlie Obstacle Avoidance Sensor Deck.


equationstratos/STRATOSDRONES
A 4-layer, 36×70 mm Tello-style portrait controller board for the STRATOSDRONE: chip-down ESP32-P4 (flight + camera + hardware H.264) with an ESP32-C6-MINI-1 Wi-Fi co-processor, IMU / barometer / ToF / optical-flow…

Honzaaa45/cube-hologram-pcb
Carte electronique d'un afficheur holographique Pepper's Ghost : CAO KiCad 4 couches entierement generee par du code et verifiee automatiquement

MaxJ02/Death_By_Table
Code for the autonomous RC-car "Death_By_Table", which competed in the YRGO Grand Prix 2023. The code is written for the Arduino Nano which uses the Atmega328p microcontroller.


