4 layers94.4 × 72.8 mm
RP2040 base
Twisted-Fields/rp2040-motor-controller
A dual channel brushless motor controller based on the RP2040 microcontroller, designed in Kicad.
325 parts419

 Twisted-Fields/rp2040-motor-controller419
A dual channel brushless motor controller based on the RP2040 microcontroller, designed in Kicad.
Driver module is an open-source printed circuit board by Twisted-Fields, from the Twisted-Fields/rp2040-motor-controller repository on GitHub. It is a 4-layer board of 68.8 × 36 mm with 118 parts on 60 nets, routed with 640 tracks and 162 vias.
It is built around the EG3113, INA240A1D and TPS7A1601DGNT, with the CDBU0130R-HF, FR107 and SMAJ51A among its other parts. Its parts include 42 resistors, 27 capacitors, 13 diodes, 7 ICs and 7 connectors. It belongs with the robots and motor control boards of this library.


A dual channel brushless motor controller based on the RP2040 microcontroller
The boards cost between $15 and $40 each depending on version and quantity.
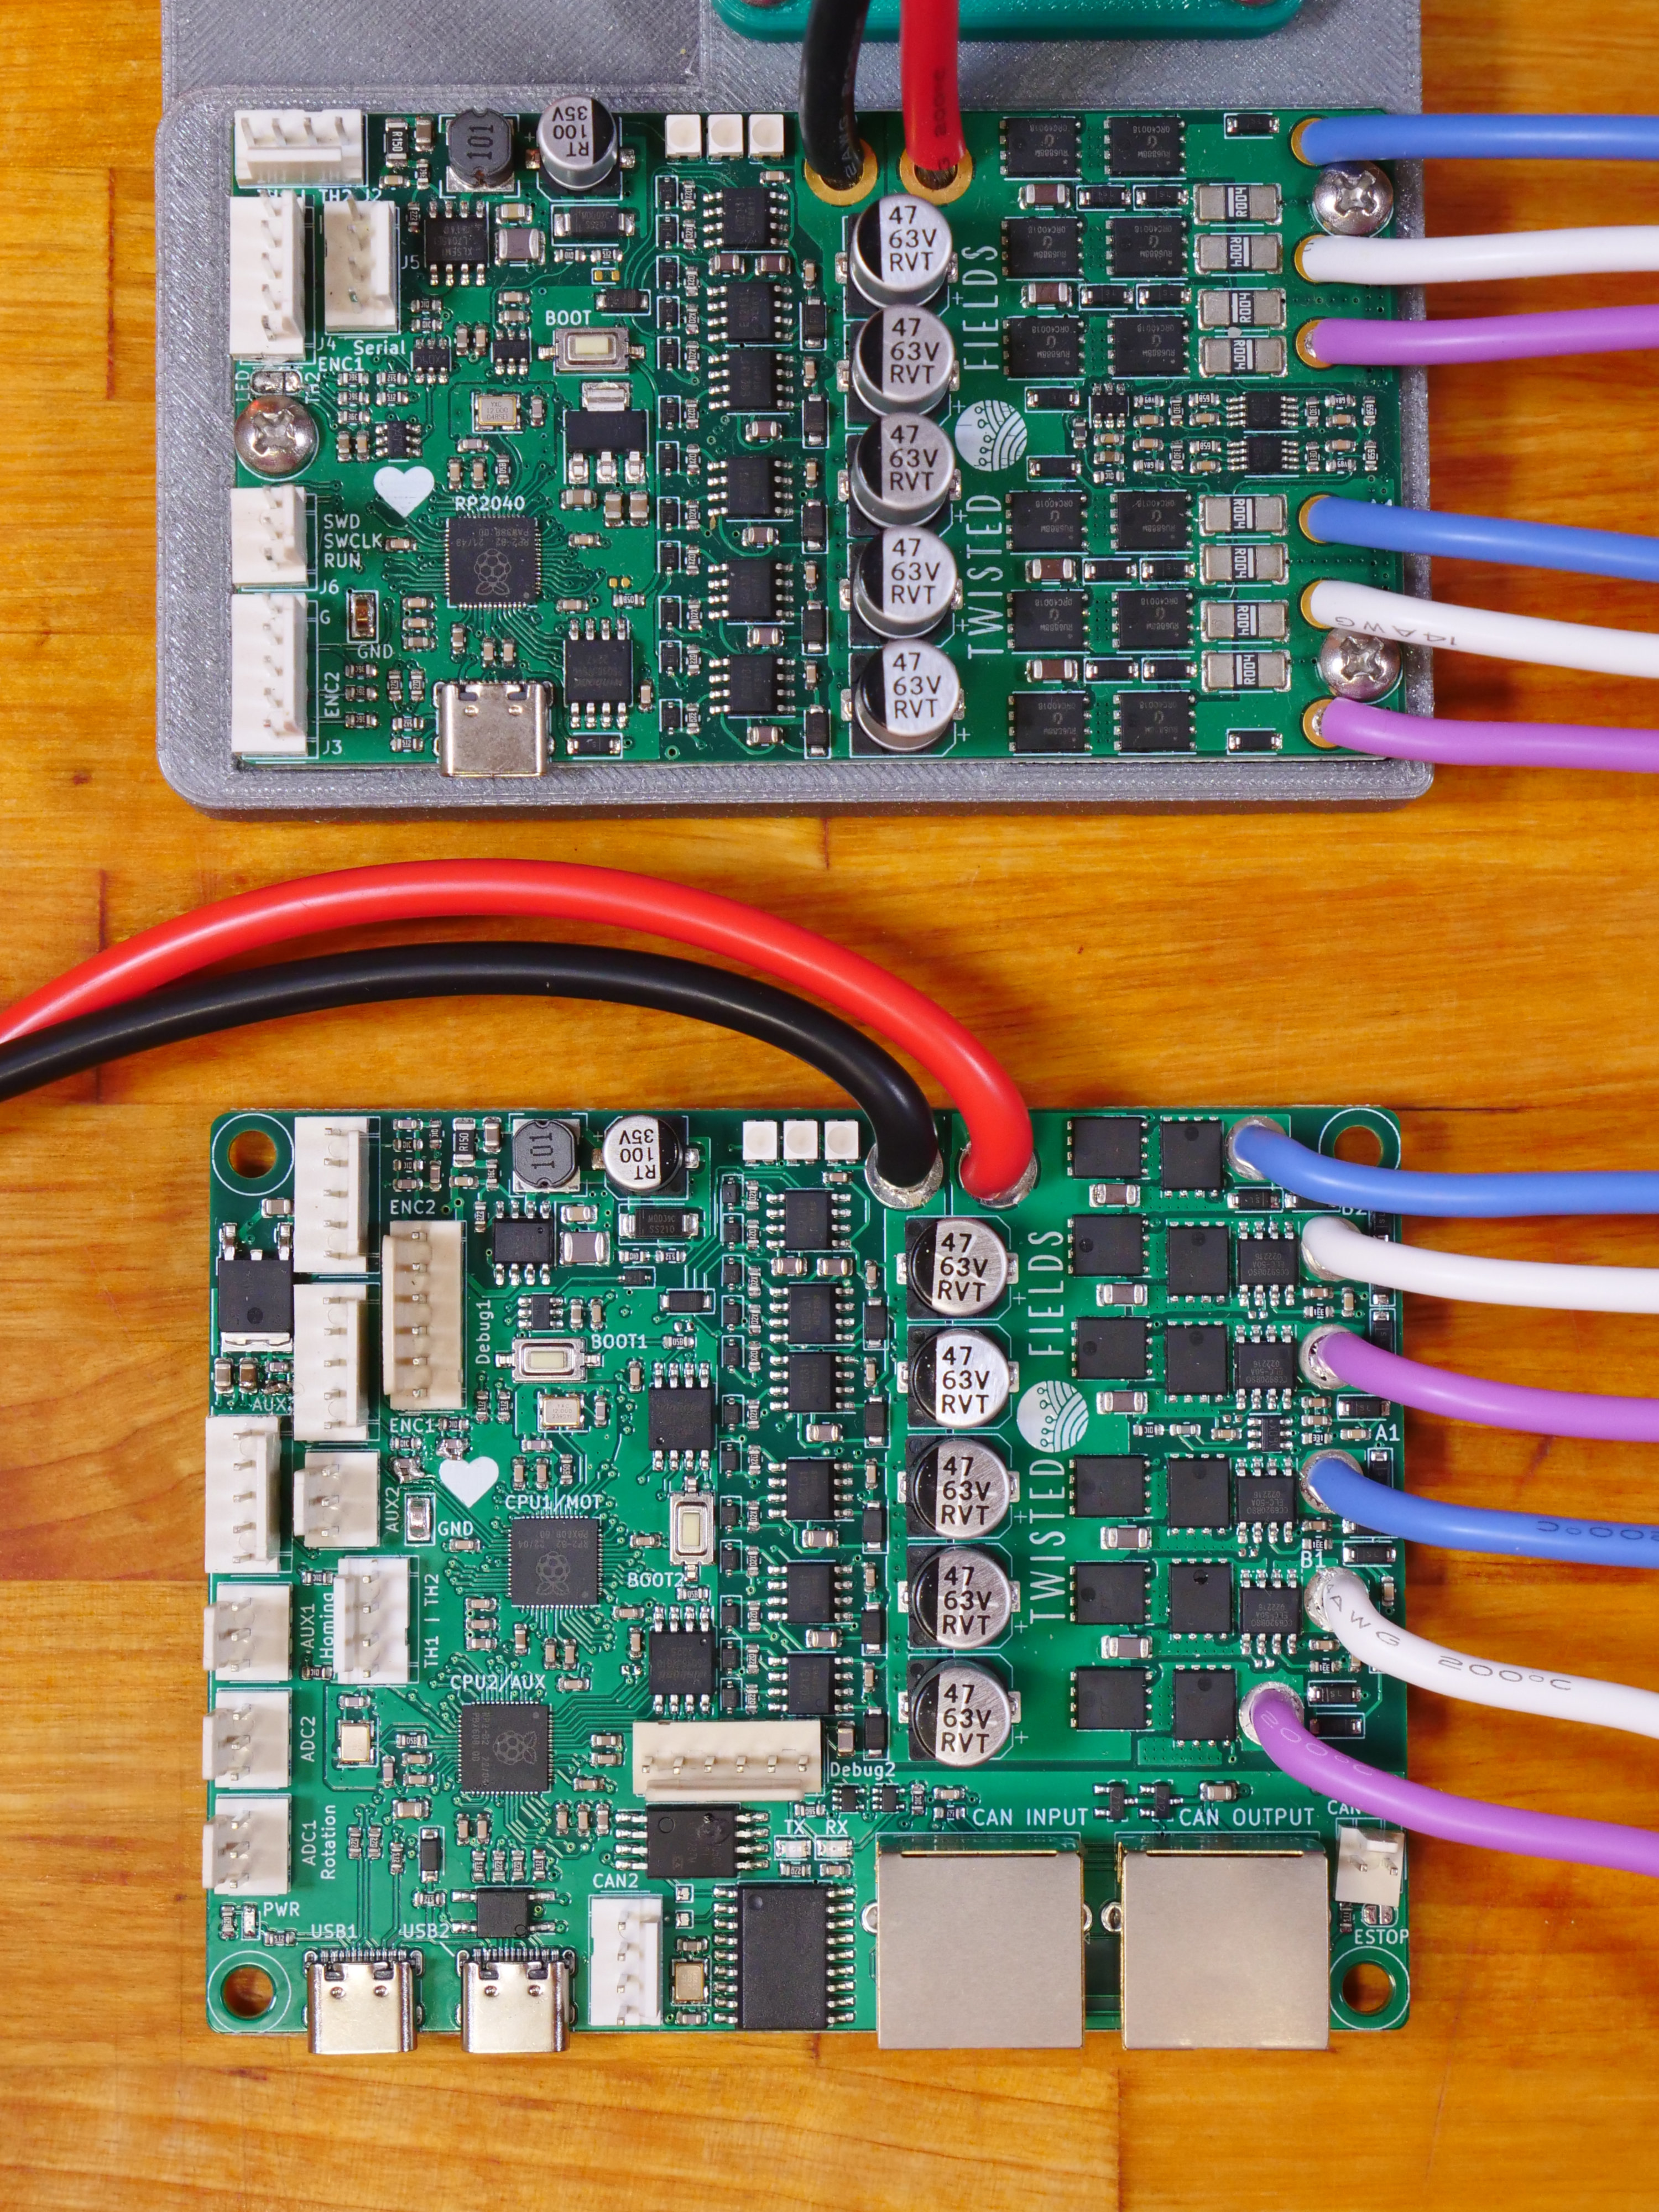
NOTE: This design is still changing. There is currently one board version in
this repo. This is our dual CPU version with CAN bus and extra connectors for
our robot. This version also improves the current measurement circuit compared
to the first rev.

Once we have verified the improved current measurement circuit, we will also
support a single CPU version which is smaller and slightly cheaper. This will
look similar to our first prototype version shown in the top of the photo at the
bottom of this document. To view the files for that board see this commit:
https://github.com/Twisted-Fields/rp2040-motor-controller/commit/ceeeb0ee0d24856a9ad8b6b036be5baf15e3ead6
Warning These files are still under development and undergoing testing. While we do aspire to produce a design that others can easily fabricate, we do not yet recommend making them for yourself! Please post questions on board status to our community forum at community.twistedfields.com.
Our dream is that you will fab your own boards, make changes, and share your work - giving this design life beyond our efforts.
Designed by Taylor Alexander for Twisted Fields, for the Acorn Precision Farming Rover.
Many thanks to Daniel Theobald. Without your financial support and encouragement this project would not have been possible.
Thanks to all of our supporters on Open Collective. Your contributions are helping grow this project in to a sustainable open source organization.
You can support this project yourself at our Open Collective Page.
To learn more about Acorn, please see our announcement blog post. Or see a more recent technical update here.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 0R | Resistor_SMD:R_0603_1608Metric | R1, R3, R7, R8, R18, R22, R26, R30, R31 |
| 9 | 10.2R | Resistor_SMD:R_0603_1608Metric | R23, R24, R25, R27, R28, R29, R32, R33, R36 |
| 7 | 10k | Resistor_SMD:R_0603_1608Metric | R45, R119, R120, R121, R122, R123, R124 |
| 7 | TestPoint | parts:TestPoint_Pad_D1.5mm_no_courtyard | TP64, TP66, TP73, TP74, TP77, TP81, TP94 |
| 6 | 3mΩ | Resistor_SMD:R_2512_6332Metric | R4, R5, R105, R109, R113, R114 |
| 6 | C | Capacitor_SMD:C_0805_2012Metric | C101, C102, C103, C104, C105, C106 |
| 6 | CDBU0130R-HF | Diode_SMD:D_SOD-523 | D5, D6, D14, D15, D16, D17 |
| 6 | MOSFETSO-8 | motor:PowerPAK_SO-8_123 | AH2, AL2, BH2, BL2, CH2, CL2 |
| 6 | R | Resistor_SMD:R_0805_2012Metric | R86, R87, R88, R89, R90, R91 |
| 4 | 4.7uF 35V | Capacitor_SMD:C_0603_1608Metric | C2, C8, C11, C15 |
| 4 | DNP | Capacitor_SMD:C_0603_1608Metric | C7, C9, C17, C25 |
| 4 | MountingHole | RP2040_minimal:MountingHole_3.9mm_Plastite_#6 | H1, H5, H6, H7 |
| 3 | 100R | Resistor_SMD:R_0603_1608Metric | R2, R9, R112 |
| 3 | 100n | Capacitor_SMD:C_0603_1608Metric | C1, C66, C74 |
| 3 | 10uF 35v | Capacitor_SMD:C_0603_1608Metric | C13, C65, C70 |
| 3 | 2.2uF 100V | Capacitor_SMD:C_1206_3216Metric | C77, C78, C79 |
| 3 | EG3113 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U2, U5, U8 |
| 3 | FR107 | Diode_SMD:D_SOD-123 | D2, D7, D10 |
| 3 | INA240A1D | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1, U21, U44 |
| 3 | Q_PNP_BEC | Package_TO_SOT_SMD:SOT-23 | Q1, Q2, Q3 |
| 3 | SMAJ51A | Diode_SMD:D_SMA | D8, D9, D18 |
| 2 | 220uF 63V solid | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C3, C6 |
| 2 | Conn_02x06_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x05_P2.54mm_Vertical | J4, J5 |
| 2 | R | Capacitor_SMD:C_0603_1608Metric | R6, R10 |
| 1 | 1u | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | 2.2uF 100V | Capacitor_SMD:C_0805_2012Metric | C5 |
| 1 | Conn_01x03 | parts:MT60-F.G.Y | J19 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J6 |
| 1 | Power Input | parts:AMASS_XT60PW-F_1x02_P7.20mm_Horizontal | J1 |
| 1 | Power Input | parts:CONN-TH_XT60UPB-M | J21 |
| 1 | Power Input | parts:AMASS_XT60PW-M_1x02_P7.20mm_Horizontal | J2 |
| 1 | SMDJ51CA | Diode_SMD:D_SMC | D1 |
| 1 | TPS7A1601DGNT | parts:DGN0008C_N | U3 |
| 1 | TestPoint | TestPoint:TestPoint_Keystone_5019_Minature | TP71 |
| 1 | Thermistor 10k | Resistor_SMD:R_0603_1608Metric | TH1 |
It measures 68.8 × 36 mm and has 4 copper layers, 1.61 mm thick.
118 parts, built around the EG3113, INA240A1D, TPS7A1601DGNT and CDBU0130R-HF. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Twisted-Fields/rp2040-motor-controller repository on GitHub, at the commit this page was made from: the board is driver_module/driver_module.kicad_pcb and its schematic RP2040_base/RP2040_base.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Twisted-Fields before reusing the design.
Twisted-Fields/rp2040-motor-controller
A dual channel brushless motor controller based on the RP2040 microcontroller, designed in Kicad.

Twisted-Fields/rp2040-motor-controller
A dual channel brushless motor controller based on the RP2040 microcontroller, designed in Kicad.

Twisted-Fields/rp2040-motor-controller
A dual channel brushless motor controller based on the RP2040 microcontroller, designed in Kicad.

sequoia-hope/rp2350-motor-controller
An RP2350 based brushless motor controller

HacklabJKL/sergei_cnc2
Second version of Hacklab's custom built CNC machine


Twisted-Fields/acorn-robot-electronics
PCB hardware designs in KICAD for Acorn, the precision farming rover from Twisted Fields.


devfabiosilva/TeslaSMPS
DIY: High Voltage Range Switching Mode Power Supply for Embedded and Solar systems