6 layers55 × 35 mm
TACCO
Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..
163 parts1CERN-OHL-W-2.0
 Stab-Rabbit-coding/Serenity-UAV1
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..
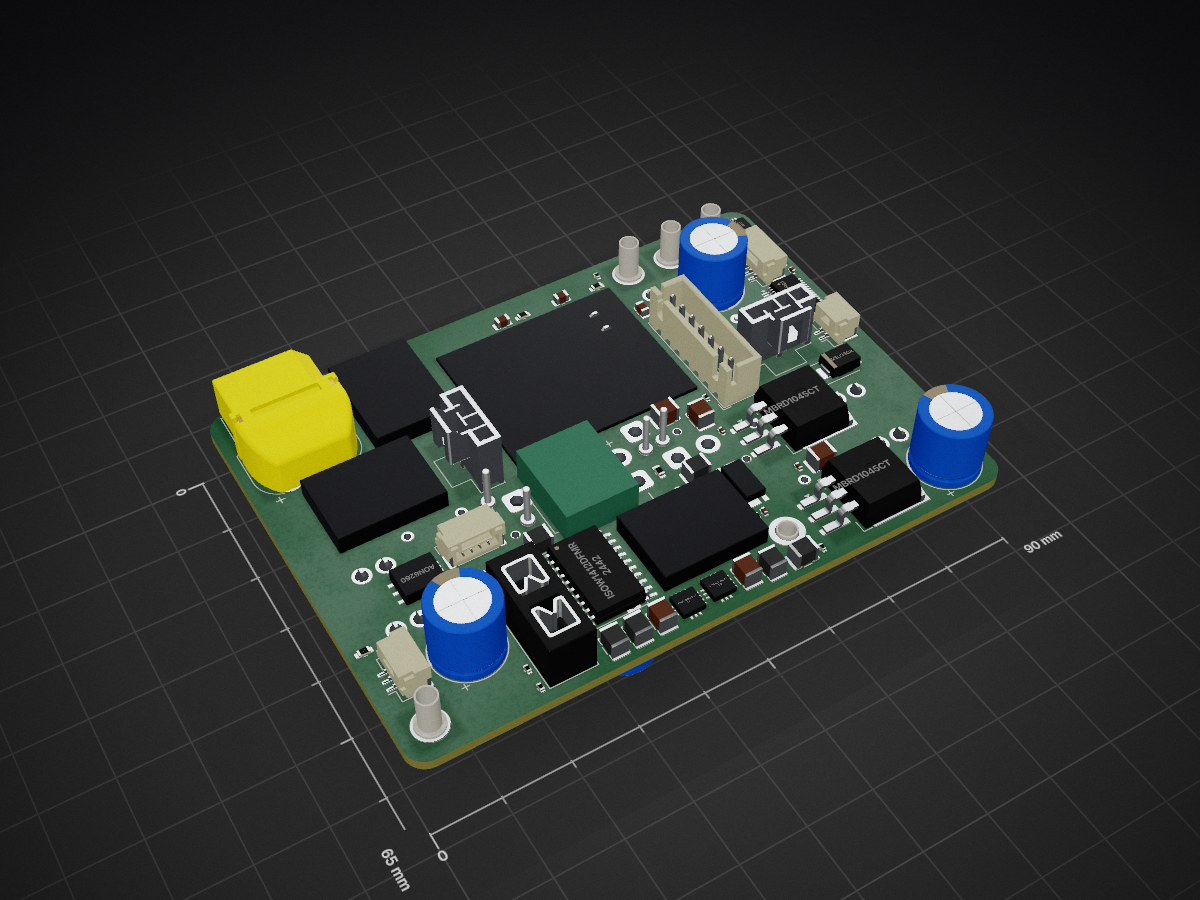
FlightEngineer is an open-source printed circuit board by Stab-Rabbit-coding, from the Stab-Rabbit-coding/Serenity-UAV repository on GitHub, published under the CERN-OHL-W-2.0 licence. It is a 4-layer board of 90 × 65 mm with 153 parts on 107 nets.
It is built around the ISOW1044BDFMR, ISOW1412DFMR and INA226AIDGSR, with the TPS54620RGYT, TPS54540DDAR and SM03B-GHS-TB among its other parts. Its parts include 3 capacitors, 3 inductors, 1 diode and 1 fuse.





"Can't stop the signal, and can't take the sky from me."
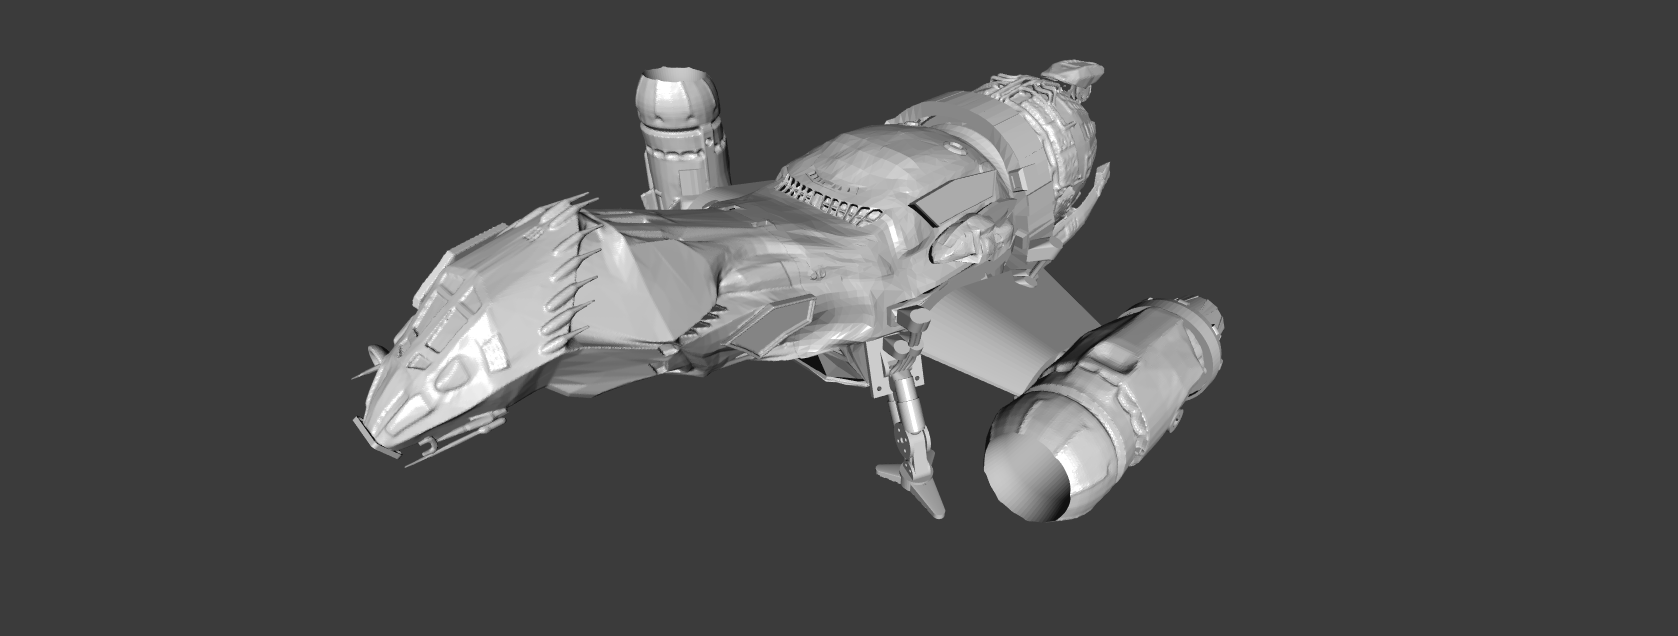
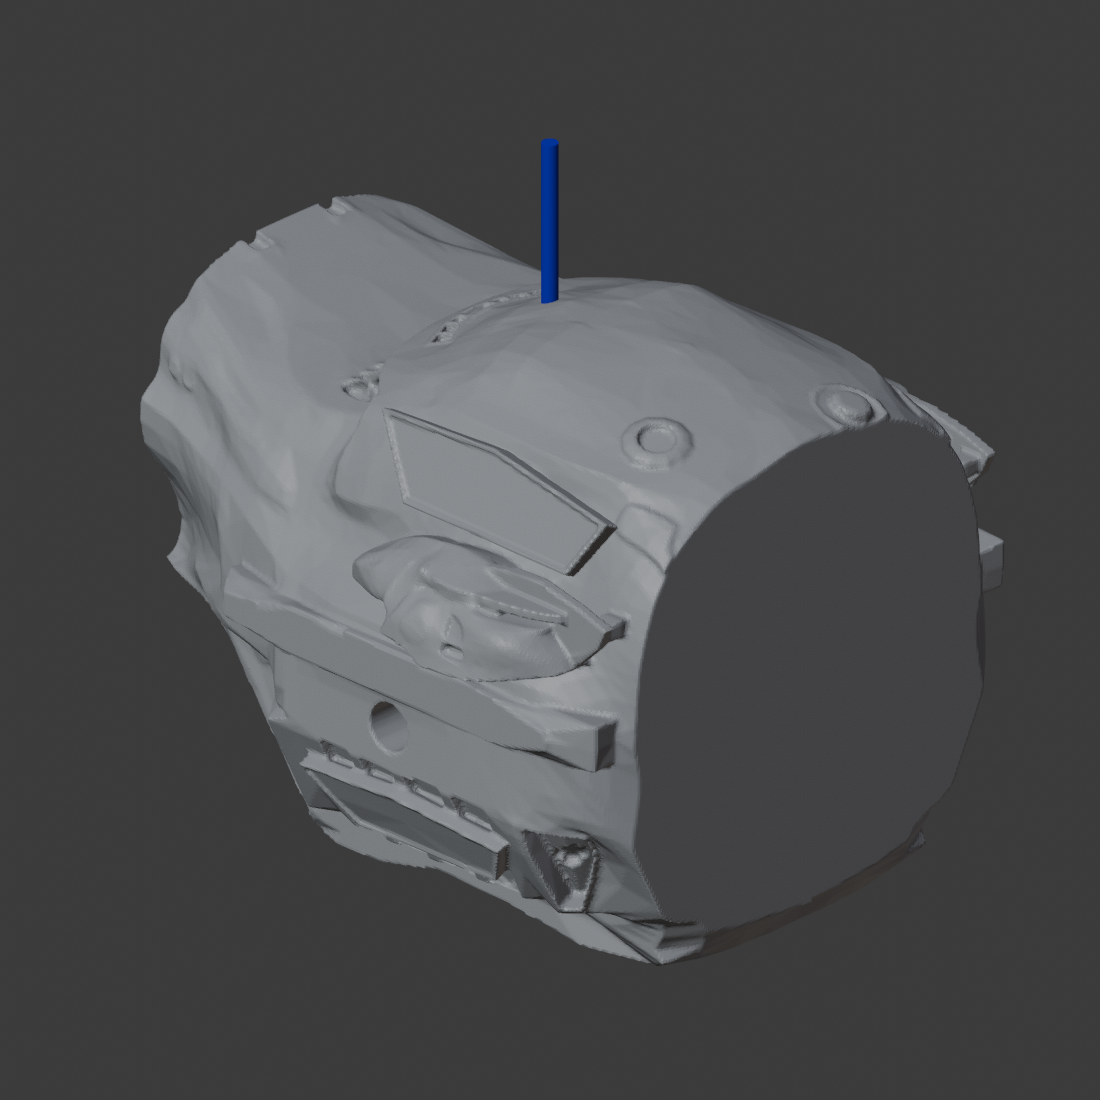
Isometric render of the Rev S assembly — port/bow/dorsal view. Predates the Rev S1g wing
spar and Rev S4c nacelle geometry; re-render pending (see TODO.md §0.10).
Serenity UAV is a fully functional electric ducted fan (EDF) tilt-rotor aircraft engineered as an actual physical build of the Firefly-class transport Serenity (Joss Whedon, 2002) — every component here is fabricated or procured, not conceptual. A two-part SLS-printed hull (one-piece forward head+cargo section and one-piece aft middle+rear section) carries two tilting EDF nacelles, a belly cargo bay with powered winch and clamshell doors, and an 8-node cooperative avionics architecture with PACE (Primary/Alternate/Contingency/Emergency) failover across every flight-critical function.
The design is held to the same rigor as a certifiable aircraft: real mass/CG/load budgets (no
"TBD" specs), FAA/FCC/NIST/IEC standards vetting on every design decision with any effect beyond
cosmetics, redundant power and control paths throughout, and a zero-trust security model — every
onboard message is signed, authenticated, and logged to hardware-enforced non-executable storage —
engineered to keep operating correctly inside a 500 W/m² RF field. Avionics, comms, and software
are built for reuse across other UAV/UGV/USV platforms, not just this airframe. See
AGENTS.md for the full authoritative project policy that governs every design
decision in this repository.
Nominal Mission Profile
Throughout the mission, the aircraft shall also:
|
Specifications
Mass/thrust/T-W figures are the corrected 2026-08-22 baseline (the earlier 1.61 hover T/W used a
stale 2,768 g AUW) and remain provisional until the bottom-up AUW ledger recompute closes — see
|
Rev U, design and PCB layout. Nothing is fabricated or assembled; the physical build has not
started. The path to first flight is in docs/FIRST_FLIGHT_READINESS.md; open work is in
TODO.md, generated from the full record in WBS.md.
| Area | State |
|---|---|
| Airframe | SCAD shells at Rev S baseline, carried into Rev U; STL re-exports pending after the TACCO 60 × 35 mm change; cargo-shell mesh defect open |
| Nacelles | 50 mm Rev S4c is current; 64 mm tandem-EDF redesign (NAC-64-SERVO-01) with a servo-driven nozzle is designed and fit-closed, with pivot, CFD, mass, and bench gates open |
| Avionics PCBs | Pilot and TACCO placed with ERC 0 / DRC 0 before routing, on corrected 4.80 mm PB2 rails; routing and Gerbers open. Flight Engineer, Observer, and Commo Rev T need further PCB work |
| Buses | Fleet MIL-STD-1553C via the Holt HI-6138 on every Pilot and TACCO (2026-09-28) |
| Comms | mLRS on a bare STM32WLE5JC; Wi-Fi USB module selection is a fab blocker; Commo becomes one standalone node (Rev T, 2026-09-29) |
| Firmware | serenity-cn Phase 6 done; serenity-fc Phase 6 stub; Phase 7 open |
| Ground station | Skipper in design; ground-side radio loadout decision open |
| BOM | bom_revU published 2026-11-03 (carry-forward of bom_revT, 2026-09-28); avionics rows lag the 2026-10 PCB changes |
| Build guide | Hand-drawn pre-Rev-T art; rebuild open (task 1.5.6) |
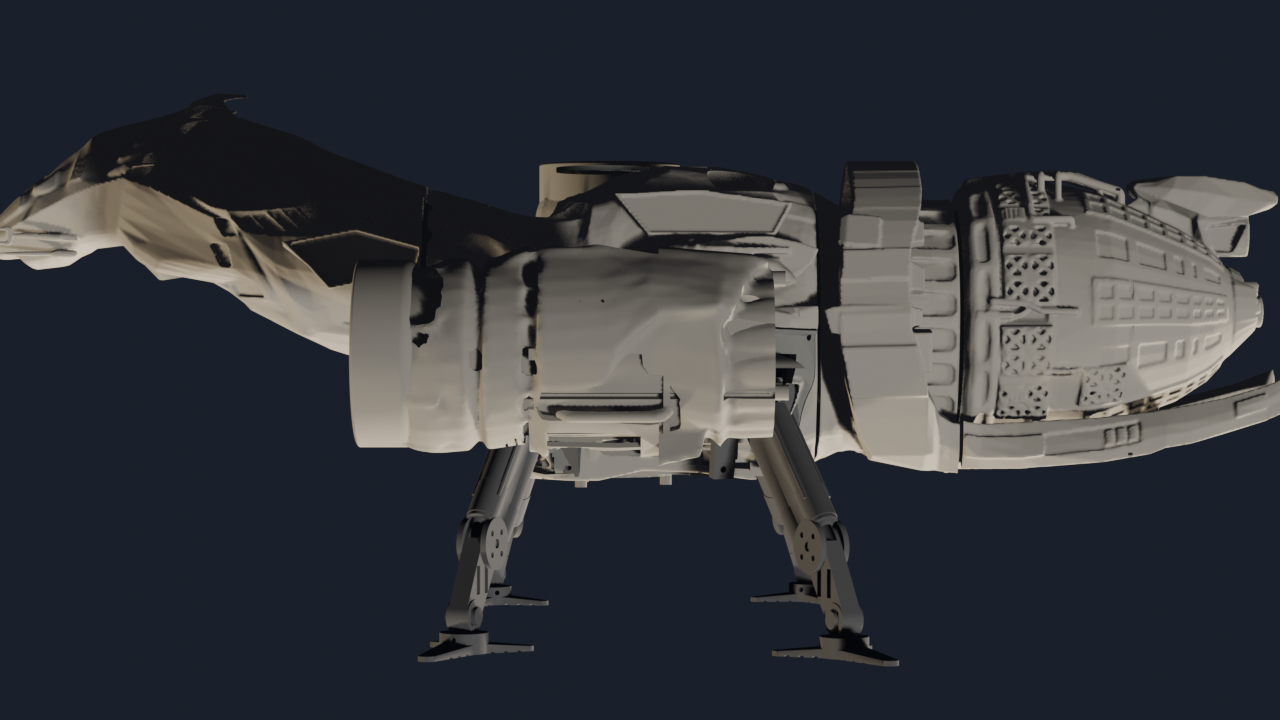 Airframe SLS-printed (DuraForm PA CF) hull with high-lift wings: in two sections (forward head+cargo and aft middle+rear), hollow-walled and foam-filled to the canonical Firefly outer mold line. Rev S1g gave the wing a fixed, bonded 20×16.3 mm carbon-fiber spar as its primary bending member, replacing the earlier rotating-shaft design. |
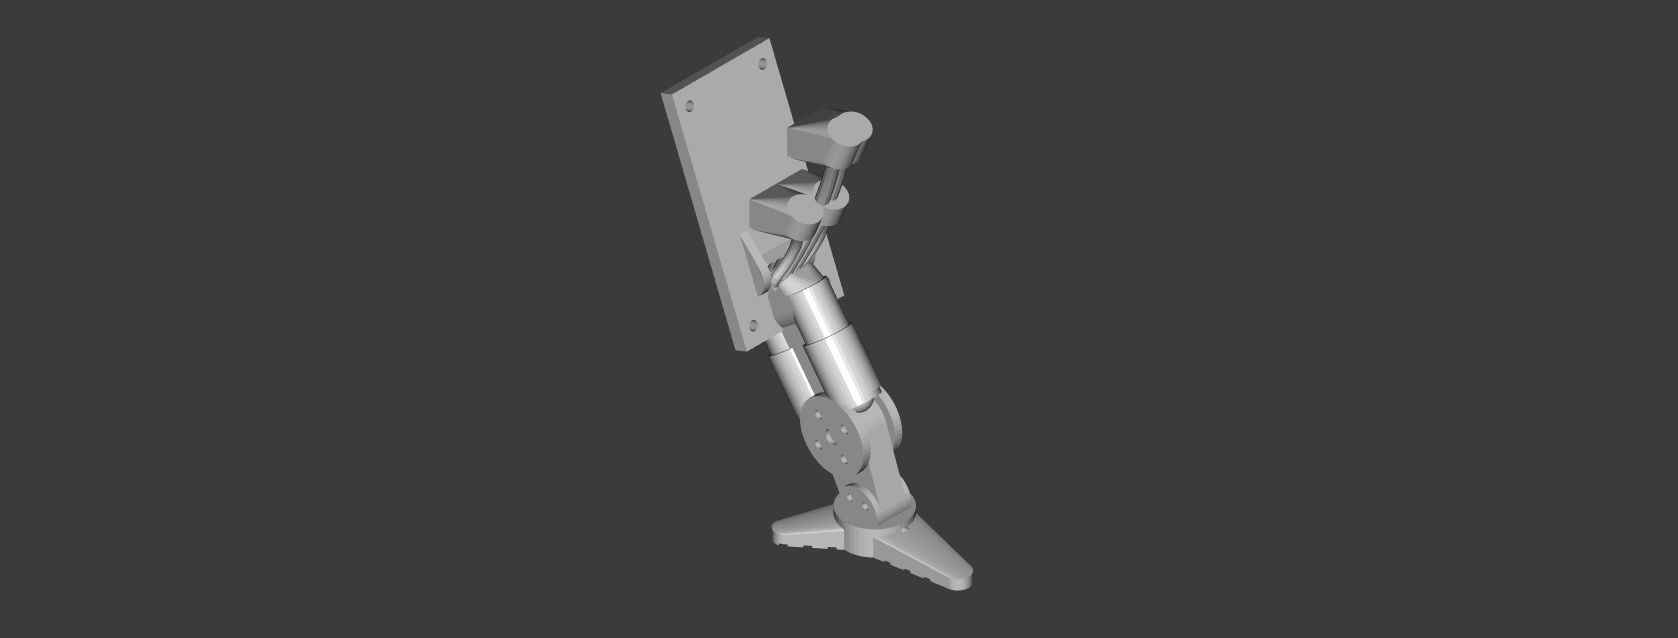 Landing Gear Four corner legs pair a rigid CF-PETG post with spring and ductile wire braces, giving a deliberately progressive, field-replaceable failure mode rated for a 6 ft full-AUW drop. |
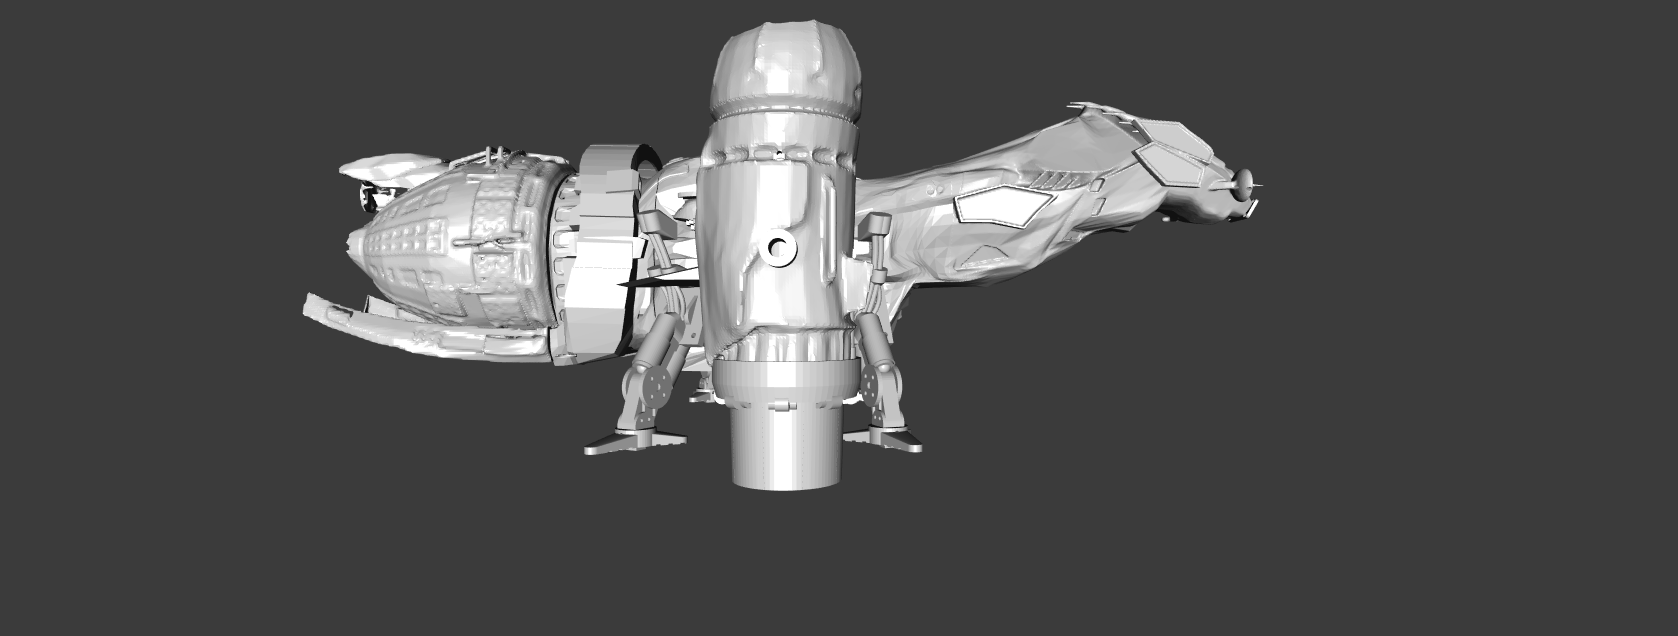 Nacelles Two tilting pods each carry a tandem 50 mm EDF pair behind an 11-fin stator, with a variable-area nozzle scheduled on measured tilt (−5° to +135° pivot; 0° = horizontal) and driven by one sub-micro servo per pod. Rev S4c hollowed the pods (−179 g/pair) and added hinged ESC bays with flush access covers on a 4×90° motor pattern; a 64 mm tandem-EDF redesign is in progress. |
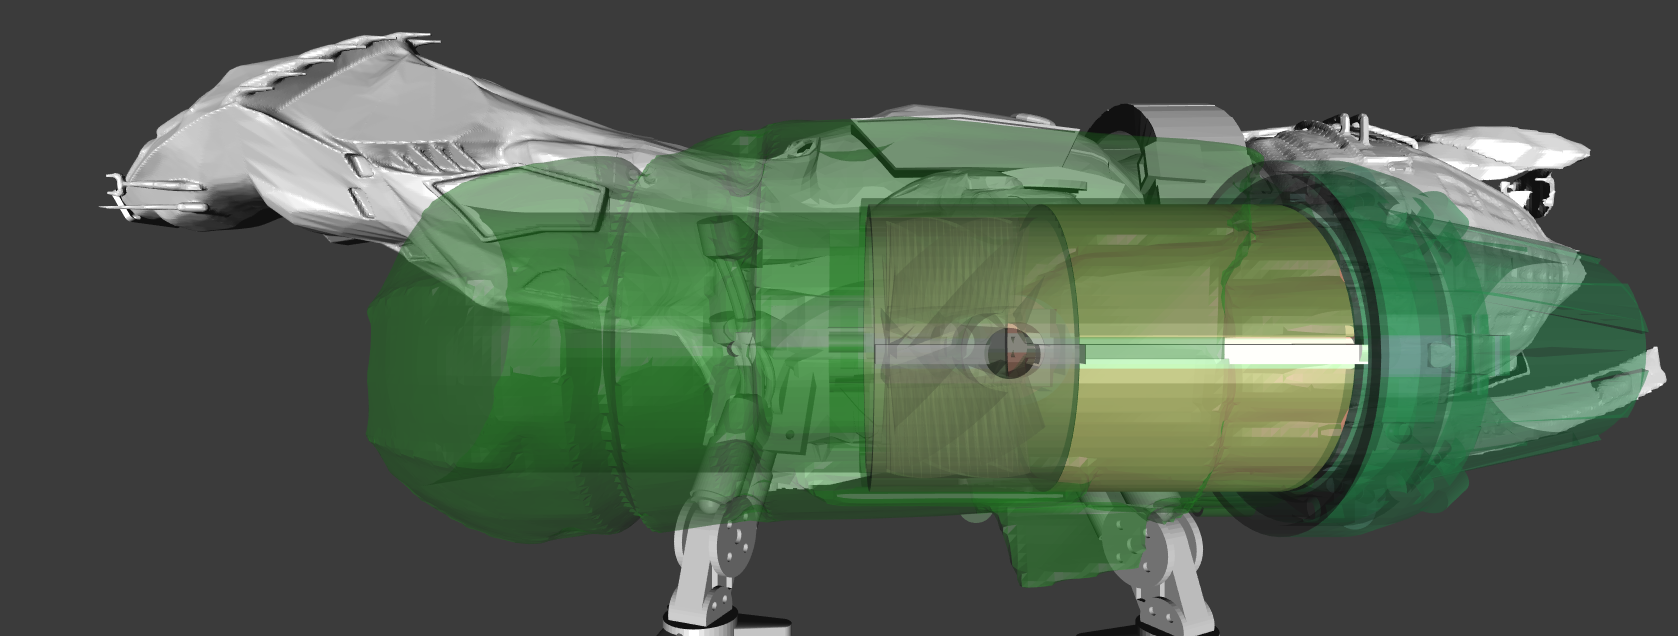 Powerplant Four nacelle EDFs give 9.84 lbf combined hover thrust at a T/W of ≈1.14, fed by a 6S LiPo through the EMI-hardened Flight Engineer power distribution board. |
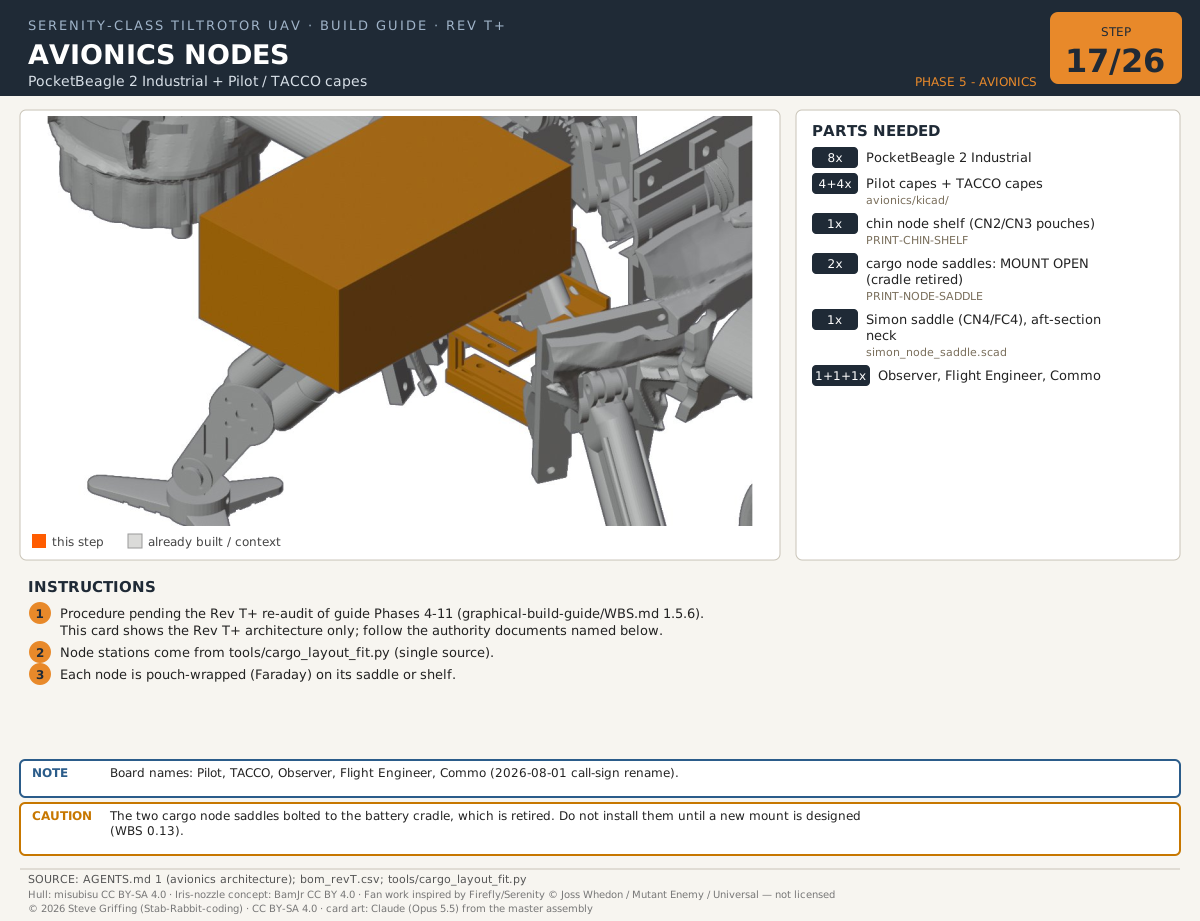 Avionics Eight PocketBeagle 2 Industrial nodes in four PACE-redundant stacks handle flight control, comms, and payload functions, all with 5 kV galvanic isolation, TPM-backed signed logging, MIL-STD-1553C, and a standalone Commo radio node (Rev T), plus the Skipper ground control station. |
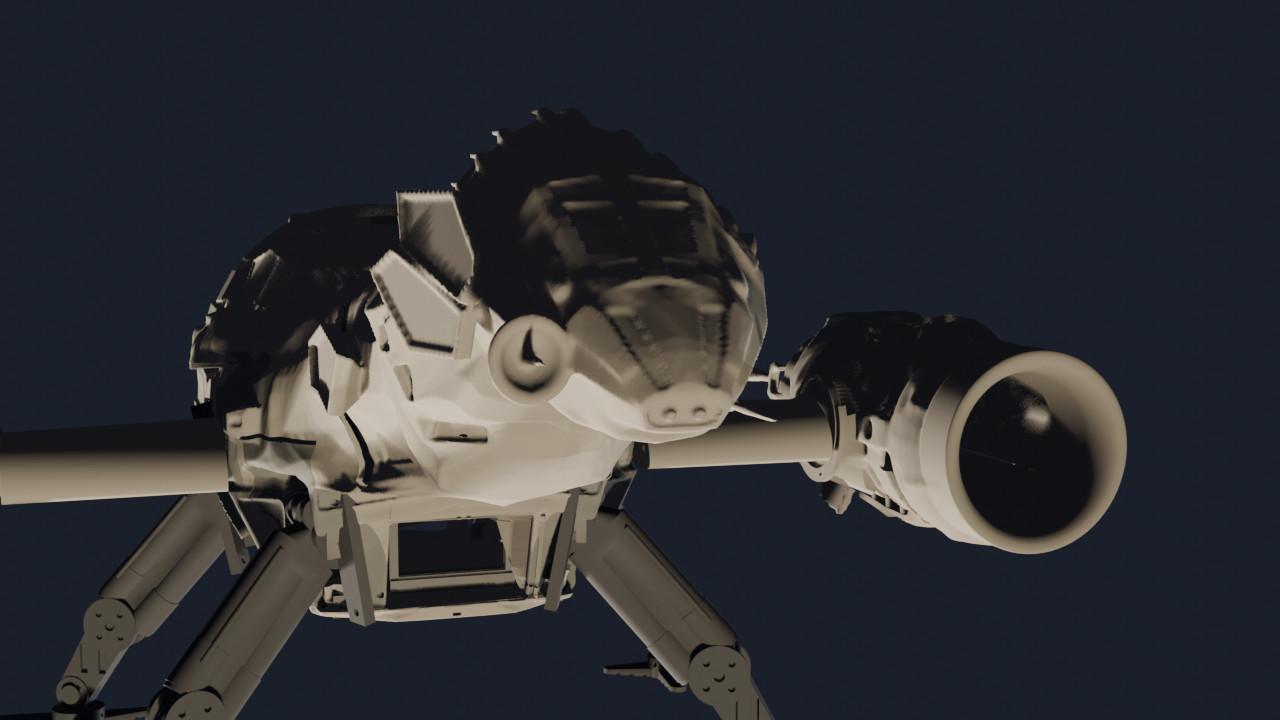 Bow Sensor Suite The forward Observer node — camera, Time-of-Flight array, and an eye-safe laser indicator — in the nose pod handles obstacle avoidance and rough size/orientation sizing of the mission payload. |
 Cargo Handling — Observer A belly clamshell cargo bay with a powered winch and hoist loads/releases an 8 oz payload in flight, guided by the downward-facing Observer node for close-in 3D imaging of the payload. | |
The canonical workspace instructions and design policy are maintained in AGENTS.md. All
contributors and automated tools (including AI assistants) shall follow the requirements and
standards documented there (coding style, fabrication specs, licensing, and attribution).
CLAUDE.md is a one-line pointer to the same file, kept for tooling that looks for that name.
The Nominal Mission Profile and Specifications
above are the current design baseline. Full engineering detail for each subsystem lives in that
subsystem's own README/doc — see the link on each card in Subsystems above. The
narrative that used to live directly in this file (full Airframe/Powerplant/Avionics/Cargo
Handling write-ups) is preserved verbatim, for historical reference, in
archives/root-readme-deep-dive-2026-08-03/.
current-specification/bom_revU.json (Rev U, 2026-11-03)Licensed by Steve Griffing, PE(CSE), CISSP-ISSEP, CPP, according to what each file produces:
CERN-OHL-W-2.0).
Full text: LICENSE (root) / LICENSES/CERN-OHL-W 2.0.MIT). Full text:
LICENSES/MIT.CC-BY-SA-4.0). Full text: LICENSES/CC-BY-SA 4.0.See docs/attribution_and_licensing.md for the full policy, the per-subsystem LICENSE
federation map, and the CERN-OHL-W "Available Component" treatment of upstream
canonical-reference geometry. Revision U, November 2026.
"Serenity Tiltrotor Drone Project — hardware CERN-OHL-W 2.0, software MIT, docs CC BY-SA 4.0, based on: · Serenity Firefly-class hull by misubisu (thingiverse.com/thing:7330462, CC BY-SA 4.0) · Variable-area EDF nozzle by BamJr (thingiverse.com/thing:2991269, CC BY 4.0) Include a link to the applicable license and indicate if changes were made."
| Component | Original Author | Source | License | Derivative Notes |
|---|---|---|---|---|
| Hull | misubisu | thingiverse.com/thing:7330462 | CC BY-SA 4.0 (Available Component under CERN-OHL-W 2.0) | Scaled to 24 in, hollowed to 0.079 in (2.0 mm) CF-PETG shell, foam-filled |
| Nozzle mechanism concept | BamJr | thingiverse.com/thing:2991269 | CC BY 4.0 | Iris petal concept reference; all Rev O/P/Q nozzle geometry original |
| Design (hardware/CAD/PCB) | This project | — | CERN-OHL-W 2.0 | All original work: PCBs, mechanical/CAD, wiring |
| Design (docs/code/scripts) | This project | — | CC BY-SA 4.0 | Firmware spec, tooling, build guides, this document |
Covered under CERN-OHL-W 2.0 (hardware):
Covered under CC BY-SA 4.0 (documentation, code, scripts, non-hardware drawings):
Not covered / separate terms:
This license does NOT grant rights to any patents held by component manufacturers or the design authors. The design uses standard open hardware interfaces (CAN FD, Ethernet, SDIO, SPI, I²C, MAVLink). If you commercialise products based on this design, conduct your own freedom-to-operate analysis. The write-blocker CPLD design implements append-only log enforcement consistent with log data protection principles in NIST SP 800-92 §4.4.2 [REF-NIST-004]; no patent claims are made on the implementation.
The write-blocker and NX enforcement hardware described in this design are intended to support operational log integrity, not forensic evidence collection. They implement log data protection principles consistent with NIST SP 800-92 §4.4.2 [REF-NIST-004]. They are NOT certified forensic tools under NIST CFTT (Computer Forensics Tool Testing) Program specifications or SWGDE (Scientific Working Group on Digital Evidence) standards. Do not use this design as the sole mechanism for evidence preservation in legal proceedings without independent verification of the implementation against your jurisdiction's evidence handling requirements.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 100nF | Capacitor_SMD:C_0402_1005Metric | C_BEC_SV_OUT2, C_BEC1_BOOT, C_BEC1_OUT2, C_BEC2_BOOT, C_BEC2_OUT2, C_BEC6_BOOT, C_ISOCAN3, C_MCU_3V3, C_RS485_3, C_TPM2, C_TPM3, C_TPM4 |
| 6 | 100R | Resistor_SMD:R_0402_1005Metric | R_BAL1, R_BAL2, R_BAL3, R_BAL4, R_BAL5, R_BAL6 |
| 6 | 10k | Resistor_SMD:R_0402_1005Metric | R_DSG_G, R_MCU_NRST, R_NTC_PU, R_RS485FLT_PU, R_TPM10, R_TPMCS |
| 6 | 10nF | Capacitor_SMD:C_0402_1005Metric | C_BEC1_SS, C_BEC2_SS, C_ISOCAN1, C_ISOCAN4, C_RS485_1, C_RS485_4 |
| 6 | 7440640500 | Serenity-Custom:Wurth_7440640500_CMC_THT | CM_ESC1, CM_ESC2, CM_ESC3, CM_ESC4, CM1, CM2 |
| 5 | 0R link | Resistor_SMD:R_0603_1608Metric | ESC1_LINK, ESC2_LINK, ESC3_LINK, ESC4_LINK, VDIS_LINK |
| 5 | 10uF | Capacitor_SMD:C_0805_2012Metric | C_H_IN, C_ISOCAN2, C_ISOCAN5, C_RS485_2, C_RS485_5 |
| 5 | INA226AIDGSR | Package_SO:VSSOP-10_3x3mm_P0.5mm | U_IS_MAIN, U_IS1, U_IS2, U_IS3, U_IS4 |
| 5 | M3 chassis lug | Serenity-Custom:M3_Chassis_Lug_PGND | J_PGND_BATT, J_SHLD_ESC1, J_SHLD_ESC2, J_SHLD_ESC3, J_SHLD_ESC4 |
| 5 | PGND via | Serenity-Custom:PGND_ViaPad_1p2mm | J_SHLD_5V, J_SHLD_6V, J_SHLD_ALERT, J_SHLD_I2C, J_SHLD_NTC |
| 4 | 0297040.WXNV 40A mini | Fuse:Fuseholder_Blade_Mini_Keystone_3568 | F_ESC1, F_ESC2, F_ESC3, F_ESC4 |
| 4 | 1mOhm 3W Kelvin | Resistor_SMD:R_Shunt_Vishay_WSK2512_6332Metric_T1.19mm | RS1, RS2, RS3, RS4 |
| 4 | 470uF 35V low-ESR | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C_DEC1, C_DEC2, C_DEC3, C_DEC4 |
| 4 | SM03B-GHS-TB | Connector_JST:JST_GH_SM03B-GHS-TB_1x03-1MP_P1.25mm_Horizontal | J_485_IN, J_485_OUT, J_CAN_IN, J_CAN_OUT |
| 4 | XT30PW-F | Connector_AMASS:AMASS_XT30PW-F_1x02_P2.50mm_Horizontal | J_ESC1, J_ESC2, J_ESC3, J_ESC4 |
| 3 | 10.0k 1% | Resistor_SMD:R_0402_1005Metric | R_FB1_2, R_FB2_2, R_FB6_2 |
| 3 | 100uF 50V | Capacitor_SMD:C_1210_3225Metric | C_BEC_SV_IN, C_BEC1_IN, C_BEC2_IN |
| 3 | 10uH 6A | Inductor_SMD:L_1210_3225Metric | L1, L2, L3 |
| 3 | 1uF | Capacitor_SMD:C_0402_1005Metric | C_MCU_VCORE, C_REGOUT, C_TPM1 |
| 3 | 742792612 | Inductor_SMD:L_1210_3225Metric | FB_5V1, FB_5V2, FB_6V |
| 2 | 0.1uF | Capacitor_SMD:C_0402_1005Metric | C_CAP1, C_CAP2 |
| 2 | 120R | Resistor_SMD:R_0603_1608Metric | R_485TERM, R_CANTERM |
| 2 | 2.2nF | Capacitor_SMD:C_0402_1005Metric | C_BEC1_COMP, C_BEC2_COMP |
| 2 | 220uF | Capacitor_SMD:C_1210_3225Metric | C_BEC1_OUT1, C_BEC2_OUT1 |
| 2 | 220uF 35V | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C1, C2 |
| 2 | 4.7k | Resistor_SMD:R_0402_1005Metric | R_I2C_SCL, R_I2C_SDA |
| 2 | 4.7nF 250V Y2 | Capacitor_SMD:C_0805_2012Metric | C_Y1, C_Y2 |
| 2 | 56.2k 1% | Resistor_SMD:R_0402_1005Metric | R_FB1_1, R_FB2_1 |
| 2 | MBRD1045CT | Package_TO_SOT_SMD:TO-263-3_TabPin2 | D_OR1, D_OR2 |
| 2 | Nano-Fit 4P | Connector_Molex:Molex_Nano-Fit_105309-xx04_1x04_P2.50mm_Vertical | J_5V, J_6V |
| 2 | SM02B-GHS-TB | Connector_JST:JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J_ALERT, J_NTC |
| 2 | SM04B-GHS-TB | Connector_JST:JST_GH_SM04B-GHS-TB_1x04-1MP_P1.25mm_Horizontal | J_I2C, J_SWD_H |
| 2 | TPS54620RGYT | Serenity-Custom:Texas_RGY0014A_VQFN-14-1EP_3.5x3.5mm | U_BEC_5V_1, U_BEC_5V_2 |
| 1 | 0297150.ZXNV 150A MAXI | Serenity-Custom:MAXI_Blade_Fuseholder_2P | F1 |
| 1 | 0R | Resistor_SMD:R_0603_1608Metric | R_GND_PGND |
| 1 | 0R | Resistor_SMD:R_0402_1005Metric | R_CANSTB |
| 1 | 0R socketed | Resistor_SMD:R_0402_1005Metric | R_CHGND |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R_EN_BIAS |
| 1 | 100k 1% | Resistor_SMD:R_0402_1005Metric | R_H_FBB |
| 1 | 100nF X7R | Capacitor_SMD:C_0402_1005Metric | C_NTC |
| 1 | 100nF X7R 0805 | Capacitor_SMD:C_0805_2012Metric | C3 |
| 1 | 100uF | Capacitor_SMD:C_1210_3225Metric | C_BEC_SV_OUT1 |
| 1 | 10uF 50V X7R 1210 | Capacitor_SMD:C_1210_3225Metric | C_DM1 |
| 1 | 1mOhm 5W Kelvin | Resistor_SMD:R_Shunt_Vishay_WSK2512_6332Metric_T1.19mm | RS_MAIN |
| 1 | 1nF | Capacitor_SMD:C_0402_1005Metric | C_BEC6_COMP |
| 1 | 2.2k | Resistor_SMD:R_0402_1005Metric | R_ALERT |
| 1 | 2.2uH | Inductor_SMD:L_1210_3225Metric | L_H1 |
| 1 | 22uF | Capacitor_SMD:C_0805_2012Metric | C_H_OUT |
| 1 | 453k 1% | Resistor_SMD:R_0402_1005Metric | R_H_FBT |
| 1 | 64.9k 1% | Resistor_SMD:R_0402_1005Metric | R_FB6_1 |
| 1 | AON6260 | Serenity-Custom:AOSMD_DFN5x6-8L | Q_BATT_DSG |
| 1 | AON6260 (DNP) | Serenity-Custom:AOSMD_DFN5x6-8L | Q_BATT_CHG |
| 1 | BQ76930PWRQ1 | Package_SO:TSSOP-30_4.4x7.8mm_P0.5mm | U_CELL |
| 1 | ISOW1044BDFMR | Package_SO:SOIC-20W_7.5x12.8mm_P1.27mm | U_ISOCAN |
| 1 | ISOW1412DFMR | Package_SO:SOIC-20W_7.5x12.8mm_P1.27mm | U_RS485 |
| 1 | M3 standoff x4 | Serenity-Custom:M3_Chassis_Lug_PGND | J_CHASSIS |
| 1 | MSPM0G3518-Q1 | Package_DFN_QFN:Texas_RHB0032E_VQFN-32-1EP_5x5mm_P0.5mm_EP3.45x3.45mm | U_MCU |
| 1 | PRTR5V0U2X | Package_TO_SOT_SMD:SOT-143 | D_I2C |
| 1 | SLB9672XU20 | Package_DFN_QFN:QFN-32-1EP_5x5mm_P0.5mm_EP3.6x3.6mm | U_TPM |
| 1 | SMBJ33CA | Diode_SMD:D_SMB | D1 |
| 1 | TLV62569PDRLR | Package_TO_SOT_SMD:SOT-563 | U_REG_3V3_H |
| 1 | TPS54540DDAR | Package_SO:TI_SO-PowerPAD-8 | U_BEC_6V |
| 1 | XH-7P | Connector_JST:JST_XH_B7B-XH-A_1x07_P2.50mm_Vertical | J_BAL |
| 1 | XT60PW-F | Connector_AMASS:AMASS_XT60PW-F_1x02_P7.20mm_Horizontal | J_BATT |
It measures 90 × 65 mm and has 4 copper layers, 1.6 mm thick.
153 parts, built around the ISOW1044BDFMR, ISOW1412DFMR, INA226AIDGSR and TPS54620RGYT. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Stab-Rabbit-coding/Serenity-UAV repository on GitHub, at the commit this page was made from: the board is avionics/kicad/FlightEngineer/kicads/FlightEngineer.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-W-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/Serenity-UAV
A functional, security conscious, Unmanned Aerial Vehicle based on the Firefly Class spacecraft Serenity from the 2002 show..

Stab-Rabbit-coding/SecureControllers
unmanned system controllers with security baked in

axpaul/KinetiCoreDC
Compact STM32G0-based DC motor controller board featuring TI DRV8874 H-bridge drivers, RS485 communication, optoisolated I/O, and hardware power protection.


ust-modules/UST5BATT18650V01
5x 18650 lion cell power supply with stabilized voltage output

stef1029/trilab-floating-platform
Head-fixed floating platform for studying sensory-guided spatial orienting in mice — hardware, firmware and control software.

UofA-SPEAR/pcb_designs_2026
Repository for SPEAR 2026 PCB designs. PCB design software is KiCad.

nickraymond/nereus_Pi_shield_ADIN2111
A Raspberry Pi Zero 2W shield built from a copy of the Sofar Bristlemouth mote: ADIN2111 two-port 10BASE-T1L with PoDL, powered from the bus, 5 V for the Pi, a 24 V payload port, and the Sofar mote's power path…

Gecesars/18-gateway-industrial
Gateway Industrial Modbus/CAN Universal — baseline técnica e acompanhamento do projeto