

2 layers100 × 100 mm

 rutvikts/ECE445_SP24
UIUC ECE 445 - Senior Design Project Repository
ECE445 SP24 is an open-source printed circuit board by rutvikts, from the rutvikts/ECE445_SP24 repository on GitHub. It is a 2-layer board of 100 × 100 mm with 74 parts on 77 nets, routed with 474 tracks and 38 vias.
It is built around the TPS56339DDC and NRS8030T6R8MJGJ. Its parts include 21 capacitors, 15 connectors, 10 resistors, 6 ICs and 4 diodes. It belongs with the STM32 boards of this library.
UIUC ECE 445 - Senior Design Project Repository
Team Members:
Children's interstitial and diffuse lung disease (ChILD) is a collection of diseases or disorders. These diseases cause a thickening of the interstitium (the tissue that extends throughout the lungs) due to scarring, inflammation, or fluid buildup. This eventually affects a patient’s ability to breathe and distribute enough oxygen to the blood.
Numerous children experience the impact of this situation, requiring supplemental oxygen for their daily activities. It hampers the mobility and freedom of young infants, diminishing their growth and confidence. Moreover, parents face an increased burden, not only caring for their child but also being directly involved in managing the oxygen tank as their child moves around.
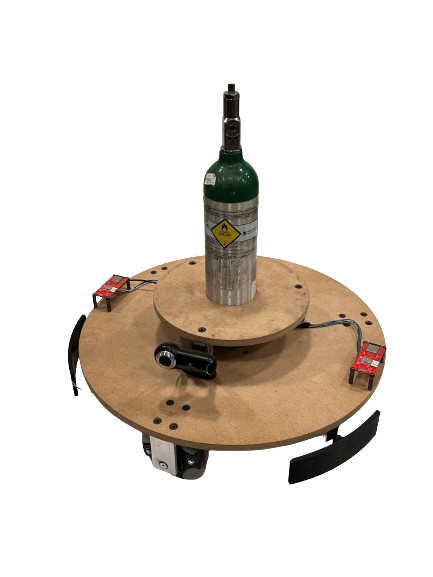
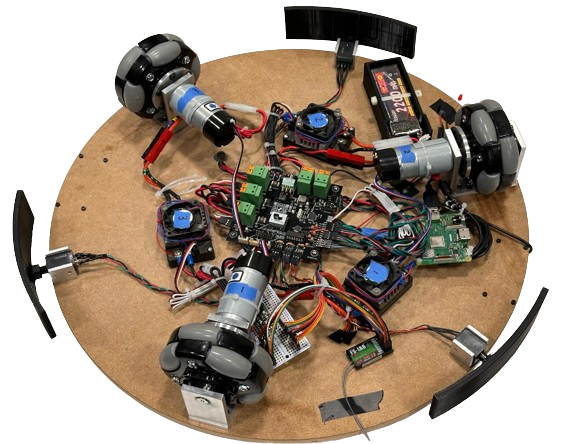
Mobile oxygen delivery is a mostly untapped market for users both elderly and young. This project details a prototype design for a mobile oxygen delivery robot. We utilize a three-wheeled omnidirectional drivetrain, ultra-wideband triangulation, computer vision, and a simple Roomba-style bumper system. We remove ourselves from the context of dealing with oxygen-related tubing as swivel solutions already exist and focus on the issue of creating a robot that can autonomously and efficiently move an oxygen tank around in an indoor space.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 100n | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C6, C7, C12, C13, C18, C19 |
| 6 | 10u | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C1, C2, C10, C11, C16, C17 |
| 6 | 33u | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C8, C9, C14, C15, C20, C21 |
| 6 | TestPoint | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP1, TP2, TP3, TP4, TP5, TP6 |
| 5 | 5442170 | ProjectLibrary:5442170 | J1, J2, J3, J4, J8 |
| 4 | 4.7k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3, R10 |
| 4 | Conn_01x03_Socket | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J5, J6, J7, J14 |
| 4 | LED | LED_THT:LED_D3.0mm_Clear | D1, D2, D3, D4 |
| 4 | MountingHole | MountingHole:MountingHole_5mm | H1, H2, H3, H4 |
| 3 | 0.1uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C3, C4, C5 |
| 3 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R5, R7, R9 |
| 3 | Conn_01x04_Socket | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J18, J19, J20 |
| 3 | SolderJumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_TrianglePad1.0x1.5mm | JP1, JP2, JP3 |
| 3 | TPS56339DDC | Package_TO_SOT_SMD:SOT-23-6 | U1, U2, U5 |
| 2 | CD74HC00_N_14 | Package_DIP:DIP-14_W7.62mm_LongPads | U4, U6 |
| 2 | Conn_01x06_Socket | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J10, J11 |
| 1 | 31.1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4 |
| 1 | 4.7u | Inductor_SMD:L_1008_2520Metric | L1 |
| 1 | 5.6u | Inductor_SMD:L_1008_2520Metric | L3 |
| 1 | 52.3k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R8 |
| 1 | 53.6k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R6 |
| 1 | Conn_01x04_Socket | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J12 |
| 1 | LOGO | LOGO | G*** |
| 1 | NRS8030T6R8MJGJ | ProjectLibrary:NRS8030T6R8MJGJ | L2 |
| 1 | STM32F103C8Tx | Package_QFP:LQFP-48_7x7mm_P0.5mm | U3 |
| 1 | SW_Push | Button_Switch_THT:SW_PUSH_6mm_H7.3mm | SW1 |


mattvenn/usbc-synth-psu
For build notes, problems and fixes, please check the project log


HeyPCB/quack-core
Brain board for the Open Duck Mini: Pi Zero 2W carrier, 14-servo STS bus, fused 2S power path in stitched copper zones (15-18 A battery side), USB-C charging with balancing, IMU.

robotont/robotont-electronics-mainboard
Unified pcb design for the 3rd generation robotont robot.
It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
74 parts, built around the TPS56339DDC and NRS8030T6R8MJGJ. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rutvikts/ECE445_SP24 repository on GitHub, at the commit this page was made from: the board is PCB/MainBoard/MainBoard.kicad_pcb and its schematic PCB/MainBoard/3v3BuckConverter.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask rutvikts before reusing the design.