
2 layers100 × 100 mm

 rutvikts/ECE445_SP24
UIUC ECE 445 - Senior Design Project Repository
MainBoardv2 is an open-source printed circuit board by rutvikts, from the rutvikts/ECE445_SP24 repository on GitHub. It is a 2-layer board of 100 × 100 mm with 103 parts on 89 nets, routed with 706 tracks and 128 vias.
It is built around the TPS56637RPA. Its parts include 25 connectors, 14 capacitors, 13 resistors, 6 diodes and 5 ICs. It belongs with the STM32 boards of this library.
UIUC ECE 445 - Senior Design Project Repository
Team Members:
Children's interstitial and diffuse lung disease (ChILD) is a collection of diseases or disorders. These diseases cause a thickening of the interstitium (the tissue that extends throughout the lungs) due to scarring, inflammation, or fluid buildup. This eventually affects a patient’s ability to breathe and distribute enough oxygen to the blood.
Numerous children experience the impact of this situation, requiring supplemental oxygen for their daily activities. It hampers the mobility and freedom of young infants, diminishing their growth and confidence. Moreover, parents face an increased burden, not only caring for their child but also being directly involved in managing the oxygen tank as their child moves around.
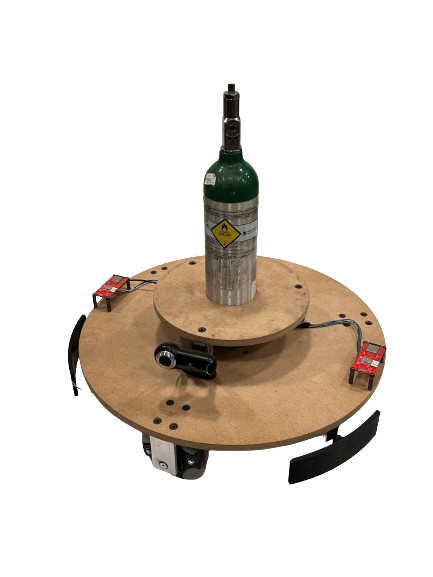
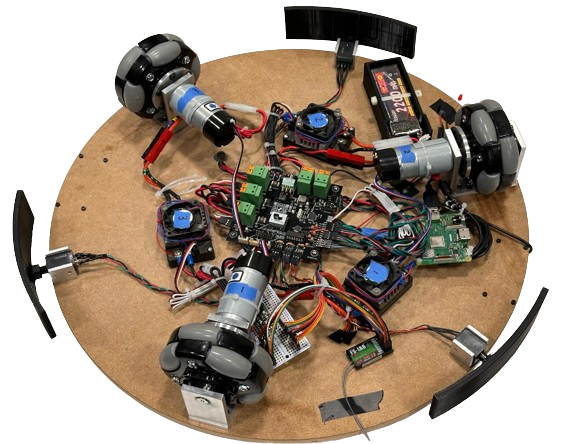
Mobile oxygen delivery is a mostly untapped market for users both elderly and young. This project details a prototype design for a mobile oxygen delivery robot. We utilize a three-wheeled omnidirectional drivetrain, ultra-wideband triangulation, computer vision, and a simple Roomba-style bumper system. We remove ourselves from the context of dealing with oxygen-related tubing as swivel solutions already exist and focus on the issue of creating a robot that can autonomously and efficiently move an oxygen tank around in an indoor space.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 1.5k | Resistor_SMD:R_0603_1608Metric | R1, R2, R3, R4, R8, R9, R10 |
| 6 | Conn_01x03_Socket | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Horizontal | J10, J13, J16, J23, J24, J25 |
| 6 | LED | LED_SMD:LED_0603_1608Metric | D1, D2, D3, D4, D5, D6 |
| 6 | Orange | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP3, TP4, TP5, TP6, TP9, TP10 |
| 5 | 100n | Capacitor_SMD:C_0603_1608Metric | C4, C5, C6, C7, C14 |
| 5 | Screw_Terminal_01x02 | CustomFootprints:PHOENIX_1017521 | J5, J7, J20, J21, J22 |
| 4 | Conn_01x03_Socket | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J11, J14, J17, J19 |
| 4 | MountingHole | MountingHole:MountingHole_5mm | H1, H2, H3, H4 |
| 4 | White | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP11, TP12, TP13, TP14 |
| 3 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R11, R12, R13 |
| 3 | 10k | Resistor_SMD:R_0603_1608Metric | R5, R6, R7 |
| 3 | 1u | Capacitor_SMD:C_0603_1608Metric | C2, C3, C11 |
| 3 | Conn_01x04_Socket | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J12, J15, J18 |
| 3 | Conn_01x04_Socket | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Horizontal | J6, J8, J9 |
| 3 | Polyfuse | Fuse:Fuse_2920_7451Metric | F1, F2, F3 |
| 2 | 100nF | Capacitor_SMD:C_0805_2012Metric | Cboot1, Cinx1 |
| 2 | 10u | Capacitor_SMD:C_0603_1608Metric | C8, C9 |
| 2 | 20p | Capacitor_SMD:C_0603_1608Metric | C12, C13 |
| 2 | Conn_02x03_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J1, J3 |
| 2 | SolderJumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_TrianglePad1.0x1.5mm | JP1, JP2 |
| 1 | 100k | Resistor_SMD:R_0805_2012Metric | Rpg1 |
| 1 | 100pF | Capacitor_SMD:C_0805_2012Metric | Cff1 |
| 1 | 10k | Resistor_SMD:R_0805_2012Metric | Rfbb1 |
| 1 | 10n | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 120R | Inductor_SMD:L_0603_1608Metric | FB1 |
| 1 | 12V | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP8 |
| 1 | 15uF | Capacitor_SMD:C_0805_2012Metric | Cin1 |
| 1 | 20k | Resistor_SMD:R_0805_2012Metric | Rff1 |
| 1 | 22u | Capacitor_SMD:C_0805_2012Metric | C10 |
| 1 | 3.3V | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP2 |
| 1 | 3.3uH | CustomFootprints:IHLP3232DZER3R3M01 | L1 |
| 1 | 47uF | Capacitor_SMD:C_1210_3225Metric | Cout1 |
| 1 | 5V | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP1 |
| 1 | 5V_Buck | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP15 |
| 1 | 73.2k | Resistor_SMD:R_0805_2012Metric | Rfbt1 |
| 1 | 8MHz Crystal | Crystal:Crystal_HC49-U_Vertical | Y1 |
| 1 | AZ1117-3.3 | Package_TO_SOT_SMD:TO-252-2 | U1 |
| 1 | CD74HC00_N_14 | Package_DIP:DIP-14_W7.62mm_LongPads | U4 |
| 1 | Conn_01x05_Pin | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | J4 |
| 1 | GND | TestPoint:TestPoint_Keystone_5000-5004_Miniature | TP7 |
| 1 | LOGO | LOGO | G*** |
| 1 | SN74HCS4075PWR | CustomFootprints:SN74HCS4075PWR | U5 |
| 1 | STM32F103C8T6TR | Package_QFP:LQFP-48_7x7mm_P0.5mm | U2 |
| 1 | SW_Push | Button_Switch_THT:SW_PUSH_6mm_H7.3mm | SW1 |
| 1 | Slide | CustomFootprints:SW_GF-161-0005 | SW3 |
| 1 | TPS56637RPA | CustomFootprints:RPA0010A | U3 |
| 1 | Toggle | CustomFootprints:MTM8206NRA | SW2 |
| 1 | USB_B_Micro | CustomFootprints:AMPHENOL_10118192-0002LF | J2 |

xPiTi/pillex-main
Submission files for MSc project - Pillex - pill dispensing device


pierrechevalier83/ferris
A low profile split keyboard designed to satisfy one single use case elegantly

shorepine/tulipcc
The Tulip Creative Computer and AMYboard - portable Python synthesizers


LouWii/ErgoMax
Custom ergo split keyboard project, based on ErgoDox, with hot swap sockets

Orange-Murker/parametric_speaker
A directional speaker with a driver based on STM32

afternoonlabs/BreezeKeyboard
Breeze is a split mechanical keyboard with a column-staggered layout. With a focus on productivity, Breeze features a full 6x4 alphanumeric layout, arrow keys, and an extra 6 key cluster for typing and coding.
It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
103 parts, built around the TPS56637RPA. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rutvikts/ECE445_SP24 repository on GitHub, at the commit this page was made from: the board is PCB/MainBoardv2/MainBoardv2.kicad_pcb and its schematic PCB/MainBoard/3v3BuckConverter.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask rutvikts before reusing the design.