
2 layers80 × 21.7 mm
 romi/romi-cablebot4
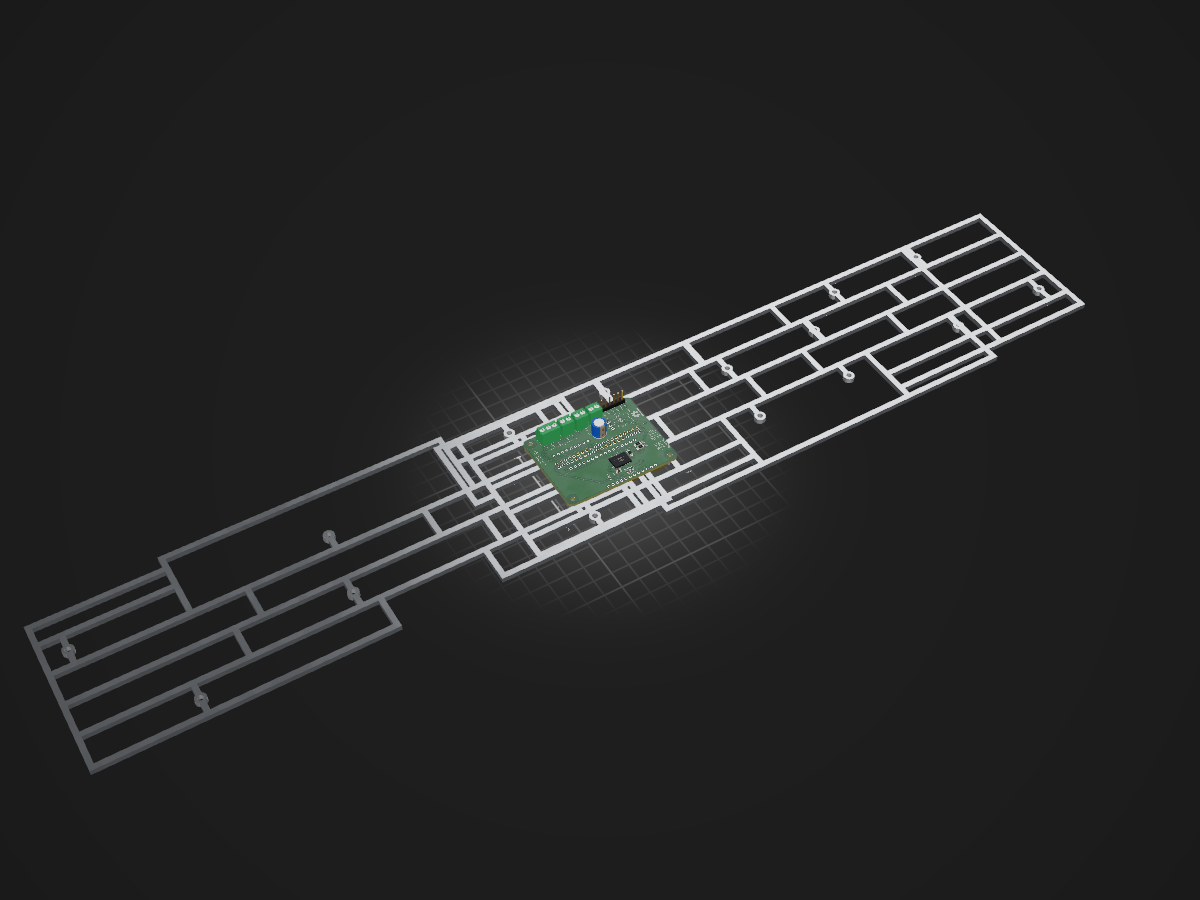
Cablebot camera is an open-source printed circuit board by romi, from the romi/romi-cablebot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 65 × 50.1 mm with 26 parts on 31 nets, routed with 320 tracks and 18 vias.
It is built around the DRV8313PWP. Its parts include 6 capacitors, 6 connectors, 3 resistors and 2 ICs.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 0.1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1, C3, C5, C6 |
| 3 | 10kΩ | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1, R2, R3 |
| 3 | MountingHole | lib:MountingHole_2.7mm_M2.5_uHAT_RPi | H3, H4, H6 |
| 3 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J4, J5, J6 |
| 1 | 0.01uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2 |
| 1 | 100uF | Capacitor_THT:CP_Radial_D8.0mm_P3.50mm | C4 |
| 1 | ACCEL | fab:Adafruit-LSM6DSOX-PCB | AC1 |
| 1 | Adafruit_Feather_M0_Express | Module:Adafruit_Feather | A1 |
| 1 | Conn_01x06_Male | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J3 |
| 1 | DRV8313 | SquantorTexasInstruments:SquantorTexasInstruments-HTSSOP-28 | U3 |
| 1 | GPIO_CONNECTOR | lib:PinSocket_2x20_P2.54mm_Vertical_Centered_Anchor | J1 |
| 1 | Logo_Open_Hardware_Small | Symbol:OSHW-Logo2_7.3x6mm_SilkScreen | LOGO1 |
| 1 | OKI-78SR-5_1.5-W36-C | Converter_DCDC:Converter_DCDC_Murata_OKI-78SR_Horizontal | U1 |
| 1 | ROMI | logos:ROMI_LOGO | LOGO3 |
| 1 | SONYLOGO | logos:SONY_CSL_LOGO | LOGO4 |
| 1 | Screw_Terminal_01x03 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-3-3.5-H_1x03_P3.50mm_Horizontal | J8 |
| 1 | fablab | logos:fablab | LOGO2 |
It measures 65 × 50.1 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the DRV8313PWP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the romi/romi-cablebot repository on GitHub, at the commit this page was made from: the board is Hardware/Electronics/cablebot_camera/cablebot_camera.kicad_pcb and its schematic Hardware/Electronics/cablebot_controller/cablebot_controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


williamhaarhoff/foc8313
Highly compact field oriented controller based on the DRV8313 IC

nerdmaennchen/motorcontroller-hw
An open hardware PCB to control motors with (BLDC and DC)

Visaging/ESP32-Gimbal
A high-performance, open-source 3-axis smartphone gimbal built from scratch using a custom PCB and the SimpleFOC library. It features real-time stabilization, native USB-C programming, and custom motion modes.


bjthemost-hub/l103-drv8313-as5600
Joint motor driver: CH32L103 + DRV8313 + AS5600. KiCad hardware, FOC firmware, PC tools, 2-stage planetary gearbox (J, 25:1). MIT.
