2 layers
Robot encoder module
adamjvr/robot-encoder-module
LSI encoder chip carrier board for Archim motion control board can be used with any other controller
16 parts

 rodolfoviolac/qser1
QSER is a application and hardware shield interface to manage and fully control a engine motor (Quanser Robots) on Galileo v2 shield.
Shield Galileo is an open-source printed circuit board by rodolfoviolac, from the rodolfoviolac/qser repository on GitHub, published under the MIT licence. It is a 2-layer board of 144.3 × 78.7 mm with 20 parts on 41 nets, routed with 263 tracks and 0 vias.
It is built around the L298HN, 74HC04D and LS7366R. Its parts include 5 diodes, 4 capacitors, 4 ICs, 4 connectors and 2 resistors.


QSER is a application and hardware shield interface to manage and fully control a engine motor (Quanser Robots) on Galileo v2 shield.
On this repository you will find the shield hardware design under /shield and the software resources under /src.
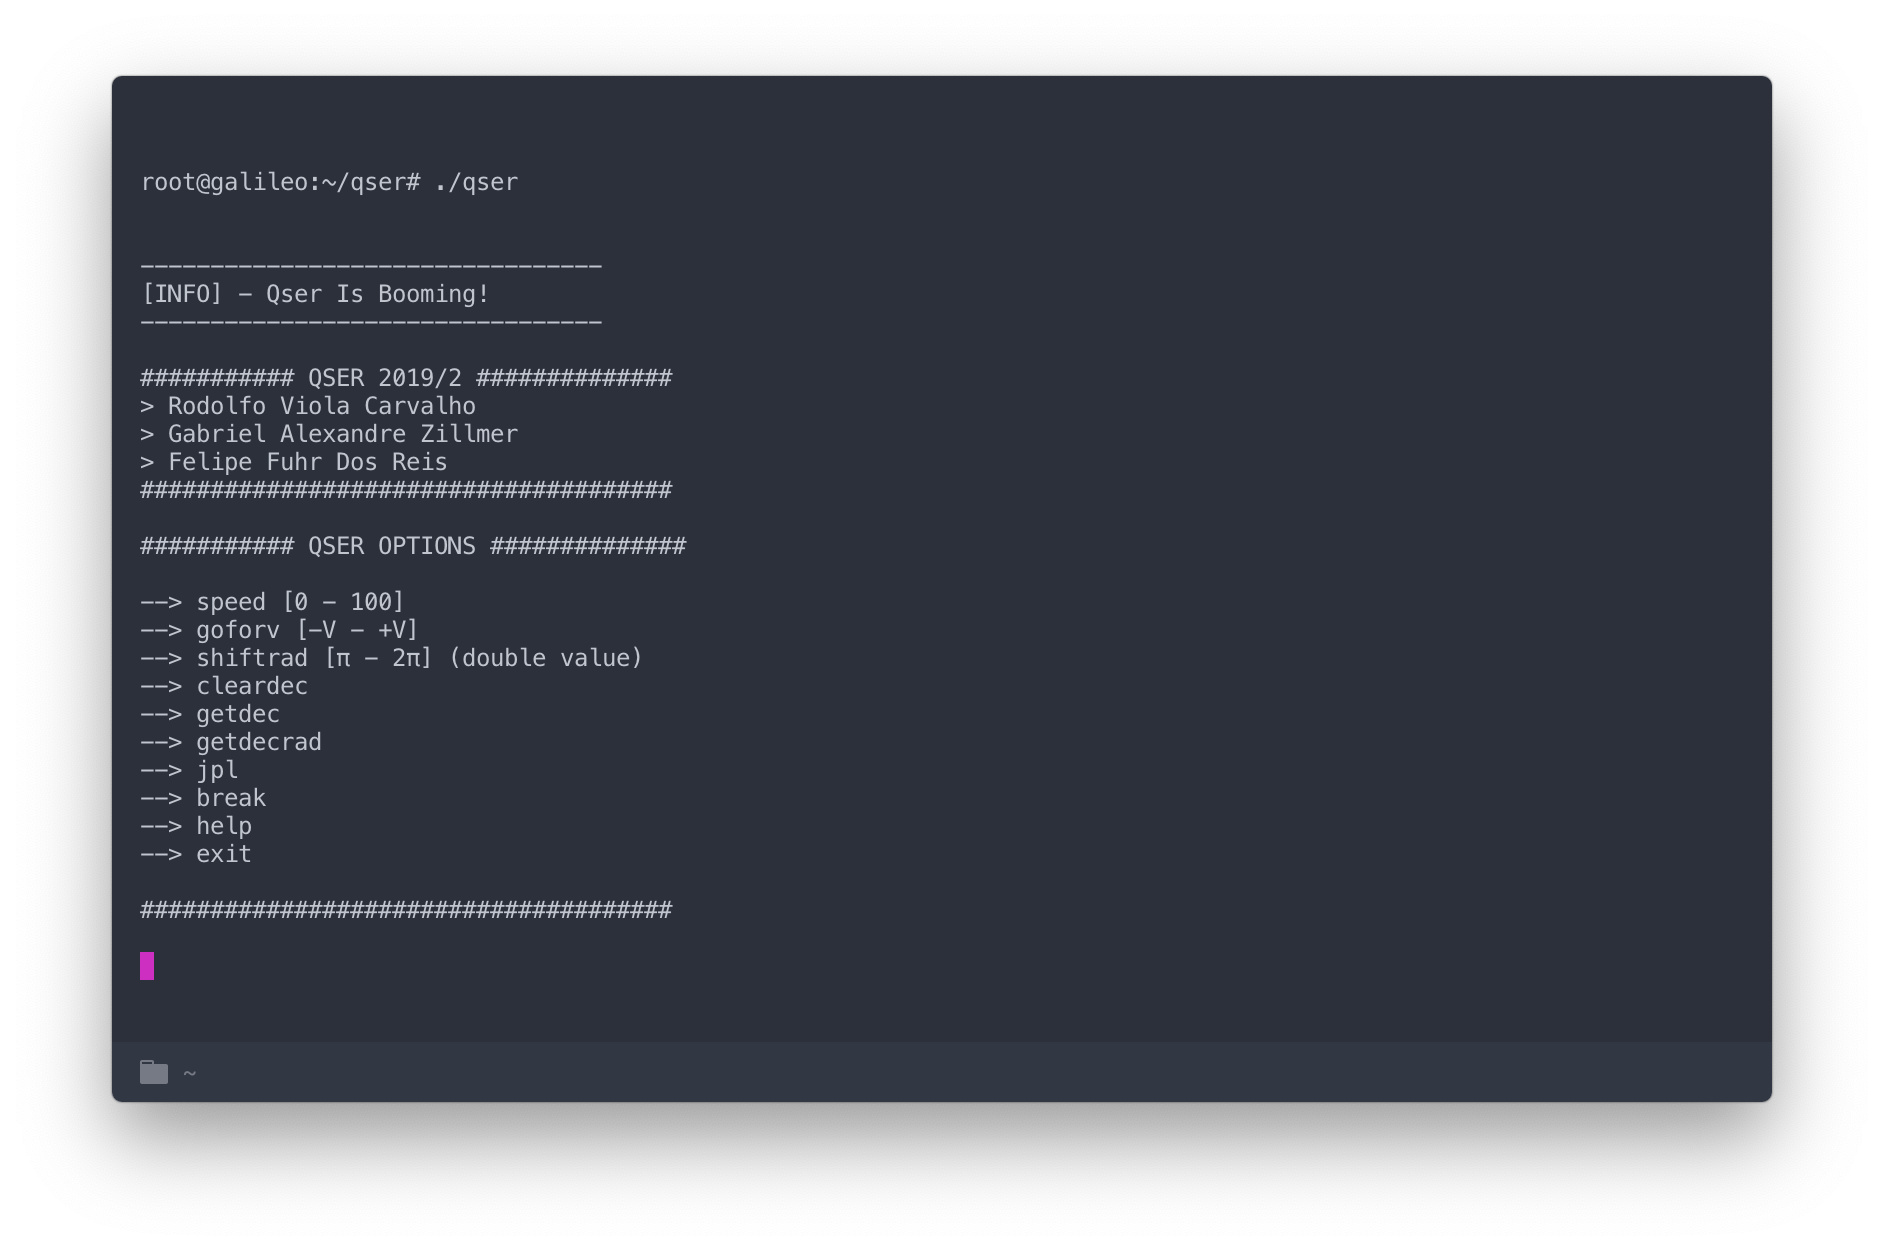
This project is using cmake to automate build releases and versioning.
/cmake-build-release/make./cmake-build-release/make clean.make.make clean.Compile the project documentation to docs/ folder.
$ make docsThis project contain a built in debugger for handling execution path helping the developers find out eventual bugs or errors.
To enable this feature you need to enable the debugger options under /src/helpers/helpers.h.
This project contain a local template simulation to help developers simulate the code that will run on the Galileo shield, this feature enable developers to build and run the code without the physical shield device.
To enable this feature you need to enable the Run Local option under /src/helpers/helpers.h.
See the open issues for a list of proposed features (and known issues).
For major changes, please open an issue first to discuss what you would like to change. Please make sure to update tests as appropriate.
git checkout -b feature/AmazingFeature)git commit -m 'Add some AmazingFeature')git push origin feature/AmazingFeature)Or Contributors
| Rodolfo Viola | Gabriel Zillmer | Felipe Fuhr |
|---|---|---|
 |  | [Image blocked: felipefuhr] |
github.com/rodolfoviolac | github.com/gazillmer | github.com/felipefuhr |
Project Link: https://github.com/rodolfoviolac/qser
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 1N4007 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3, D4 |
| 2 | 100nF | Capacitor_THT:C_Disc_D10.5mm_W5.0mm_P7.50mm | C3, C4 |
| 2 | 22pF | Capacitor_THT:C_Disc_D3.0mm_W2.0mm_P2.50mm | C1, C2 |
| 1 | 1M | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1 |
| 1 | 27V Power Supply | TerminalBlock:TerminalBlock_Altech_AK300-2_P5.00mm | J3 |
| 1 | 32MHz | Crystal:Crystal_HC52-6mm_Vertical | Y1 |
| 1 | 74HC04 | Quanser_2DSFJE_Library:DIP-14_W7.62mm | U4 |
| 1 | Connector_Encoder | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J1 |
| 1 | End_Sensor | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | Intel_Galileo_Gen2 | Quanser_2DSFJE_Library:Intel_Galileo_Gen2_Pins | U2 |
| 1 | L298HN | L298N:TO127P2020X500X2100-15 | U3 |
| 1 | LED | LED_THT:LED_D5.0mm | D5 |
| 1 | LS7366R | Quanser_2DSFJE_Library:DIP-14_W7.62mm | U1 |
| 1 | Motor | TerminalBlock:TerminalBlock_Altech_AK300-2_P5.00mm | J4 |
| 1 | R | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R2 |
It measures 144.3 × 78.7 mm and has 2 copper layers, 1.6 mm thick.
20 parts, built around the L298HN, 74HC04D and LS7366R. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rodolfoviolac/qser repository on GitHub, at the commit this page was made from: the board is shield/Shield_Galileo.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
adamjvr/robot-encoder-module
LSI encoder chip carrier board for Archim motion control board can be used with any other controller


GinoAvanzini/bluepill-expansion
Simple blue pill expansion board. Used as learning tool in a KiCad workshop

abzman/modular-i2c-board-set
boards designed to be used together to create a modular control system