
Proton
ewyrick-mark-1/Chromatone
Chromatone is an embedded audio visualizer running on the Raspberry Pi RP2350. It samples audio through the ADC, performs a real-time FFT, detects musical notes, and drives an RGB LED output based on the results.

The Bounded Infrared Recording Drone Ecosystem (BIRD-E) is a tethered quadcopter with an attached infrared camera, with livestream functionality and XBOX ground control. Senior design capstone at Purdue ECE.
Onboard pcb is an open-source printed circuit board by rober708, from the rober708/BIRD-E repository on GitHub. It is a 4-layer board of 85.1 × 100.5 mm with 103 parts on 106 nets, routed with 1,326 tracks and 406 vias.
It is built around the MPL3115A2R1, TPS56637RPAR and TPS62142RGT, with the W25Q128JVSIQ, BNO055 and TPS2116DRL among its other parts. Its parts include 23 capacitors, 19 resistors, 14 connectors, 9 ICs and 3 inductors. It belongs with the robots and motor control boards and the RP2350 boards of this library.
The Bounded Infrared Recording Drone Ecosystem (BIRD-E) is a specialized, lightweight tethered quadcopter system equipped with night-vision capabilities. It is designed to provide rapid, temporary, and cost-effective aerial surveillance for fire departments, law enforcement, industrial engineers, and other managerial groups who may benefit from mobile sentries. By operating via a power tether, BIRD-E circumvents standard drone flight limitations of other drones in its price point (~$260).
This repository consolidates all subsystems of the BIRD-E project:
The firmware is built using PlatformIO targeting the custom RP2350 proton board configuration with picosdk.
# Navigate to the firmware directory
cd Flight-Control
# Build the firmware binary
pio run
# Flash the firmware via Picoprobe
pio run -t uploadThe pilot interfaces with the drone using a laptop running a Python-based PyGame client that streams controller commands wirelessly over Wi-Fi.
# Navigate to the controller directory
cd xbox-controller
# Create and activate virtual environment
python -m venv .venv
.venv\Scripts\activate # On Linux/macOS use: source .venv/bin/activate
# Install required dependencies
pip install pygame==2.6.1
# Run the pilot-interface handler (Pi Zero 2W target)
python src/z2w/client_user.pyCommunication Established.| Control Input | Function / Command |
|---|---|
| Button A (Green) | Runs pre-flight diagnostics and initiates automatic takeoff to base hover altitude. |
| D-Pad Up/Down | Increases or decreases the hover altitude set point. |
| D-Pad Left/Right | Controls yaw rotation speed (clockwise/counter-clockwise swivel). |
| Button B (Red) | Commands automated soft landing (vertical speed $< 0.5\text{ m/s}$). |
| Button X (Blue) | Emergency Abort. Instantly cuts duty-cycle on all PWM engine signals to 0% in $< 1\text{ s}$. |
To process thrust measurement data and generate calibration curves for BLDC motor PWM duty cycles:
cd force-sensor
pip install pandas numpy matplotlib
python pwm_to_thrust.pyframe/)| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 100n | Capacitor_SMD:C_0603_1608Metric | C8, C11, C13, C14, C15, C16, C17, C18, C19, C20, C21, C32 |
| 7 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7, R18, R19, R20, R26, R27, Rfbb1 |
| 6 | 100nF | Capacitor_SMD:C_0603_1608Metric | C_D_MPL1, C_D_MPL2, CBNO0, CBNO3, Cboot_5, Cinx_5 |
| 5 | 150 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R_LED4, R_LED5, R_LED6, R_LED7, R28 |
| 5 | LED | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D_PWR1, D4, D5, D6, D7 |
| 4 | 100k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R29, R30, Rpg_3, Rpg_5 |
| 4 | 4.7u | Capacitor_SMD:C_0603_1608Metric | C5, C6, C9, C10 |
| 4 | Conn_01x02_Pin | Connector_Wire:SolderWire-0.1sqmm_1x02_P3.6mm_D0.4mm_OD1mm | J2, J3, J4, J5 |
| 4 | Conn_01x02_Pin | Connector_Wire:SolderWire-0.5sqmm_1x02_P4.8mm_D0.9mm_OD2.3mm | J10, J11, J12, J13 |
| 3 | 10u | Capacitor_SMD:C_0603_1608Metric | C12, C33, C34 |
| 3 | 1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R4, R8, R23 |
| 2 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | C35, C44 |
| 2 | 10uF | Capacitor_SMD:C_0603_1608Metric | C_D_MPL0, Cin_3 |
| 2 | 15p | Capacitor_SMD:C_0603_1608Metric | C30, C31 |
| 2 | 27 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R9, R10 |
| 2 | 5.1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R24, R25 |
| 2 | Conn_01x03_Socket | Connector_JST:JST_EH_S3B-EH_1x03_P2.50mm_Horizontal | J_PORT_0, J_STARBOARD_0 |
| 2 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H2, H4 |
| 2 | RESET | Button_Switch_SMD:SW_SPST_PTS647_Sx38 | SW2, SW3 |
| 2 | Screw_Terminal_01x01 | TerminalBlock_Wuerth:Wuerth_REDCUBE-THR_WP-THRBU_74650173_THR | J1, J14 |
| 1 | 100pF | Capacitor_SMD:C_0603_1608Metric | Cff1 |
| 1 | 120nF | Capacitor_SMD:C_0603_1608Metric | CBNO2 |
| 1 | 15uF | Capacitor_SMD:C_0603_1608Metric | Cin_5 |
| 1 | 2.2uH | Inductor_SMD:L_0805_2012Metric_Pad1.05x1.20mm_HandSolder | L1 |
| 1 | 20k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | Rff1 |
| 1 | 22uF | Capacitor_SMD:C_0603_1608Metric | Cout_3 |
| 1 | 3.3u | Inductor_SMD:L_0805_2012Metric_Pad1.05x1.20mm_HandSolder | L3 |
| 1 | 3.3uH | Inductor_SMD:L_0805_2012Metric_Pad1.05x1.20mm_HandSolder | L2 |
| 1 | 33 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5 |
| 1 | 390pF | Capacitor_SMD:C_0603_1608Metric | Css_3 |
| 1 | 47uF | Capacitor_SMD:C_0603_1608Metric | Cout_5 |
| 1 | 6.8nF | Capacitor_SMD:C_0603_1608Metric | CBNO1 |
| 1 | 73.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | Rfbt1 |
| 1 | ABM8-272-T3 | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | BAT60JFILM | custom_footprints:SOD323_ST | CR1 |
| 1 | BNO055 | custom_footprints:LGA28R50P4X10_380X520X100 | U4 |
| 1 | Conn_01x07 | Connector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_Vertical | J6 |
| 1 | Conn_01x08 | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J7 |
| 1 | Conn_02x03_Counter_Clockwise | Connector_PinSocket_2.54mm:PinSocket_2x03_P2.54mm_Vertical_SMD | J9 |
| 1 | MPL3115A2 | Package_LGA:NXP_LGA-8_3x5mm_P1.25mm_H1.1mm | U10 |
| 1 | NCP1117-3.3_SOT223 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U13 |
| 1 | RP2350_80QFN | Package_DFN_QFN:QFN-80-1EP_10x10mm_P0.4mm_EP3.4x3.4mm_ThermalVias | U3 |
| 1 | TPS2116DRL | Package_TO_SOT_SMD:SOT-583-8 | U14 |
| 1 | TPS56637RPAR | custom_footprints:CONV_TPS56637RPAR | U2 |
| 1 | TPS62142 | Package_DFN_QFN:VQFN-16-1EP_3x3mm_P0.5mm_EP1.68x1.68mm_ThermalVias | U1 |
| 1 | USBLC6-2P6 | Package_TO_SOT_SMD:SOT-666 | U12 |
| 1 | USB_C_Receptacle_USB2.0_14P | Connector_USB:USB_C_Receptacle_G-Switch_GT-USB-7010ASV | J8 |
| 1 | W25Q128JVS | custom_footprints:SOIC127P790X216-8N | U11 |
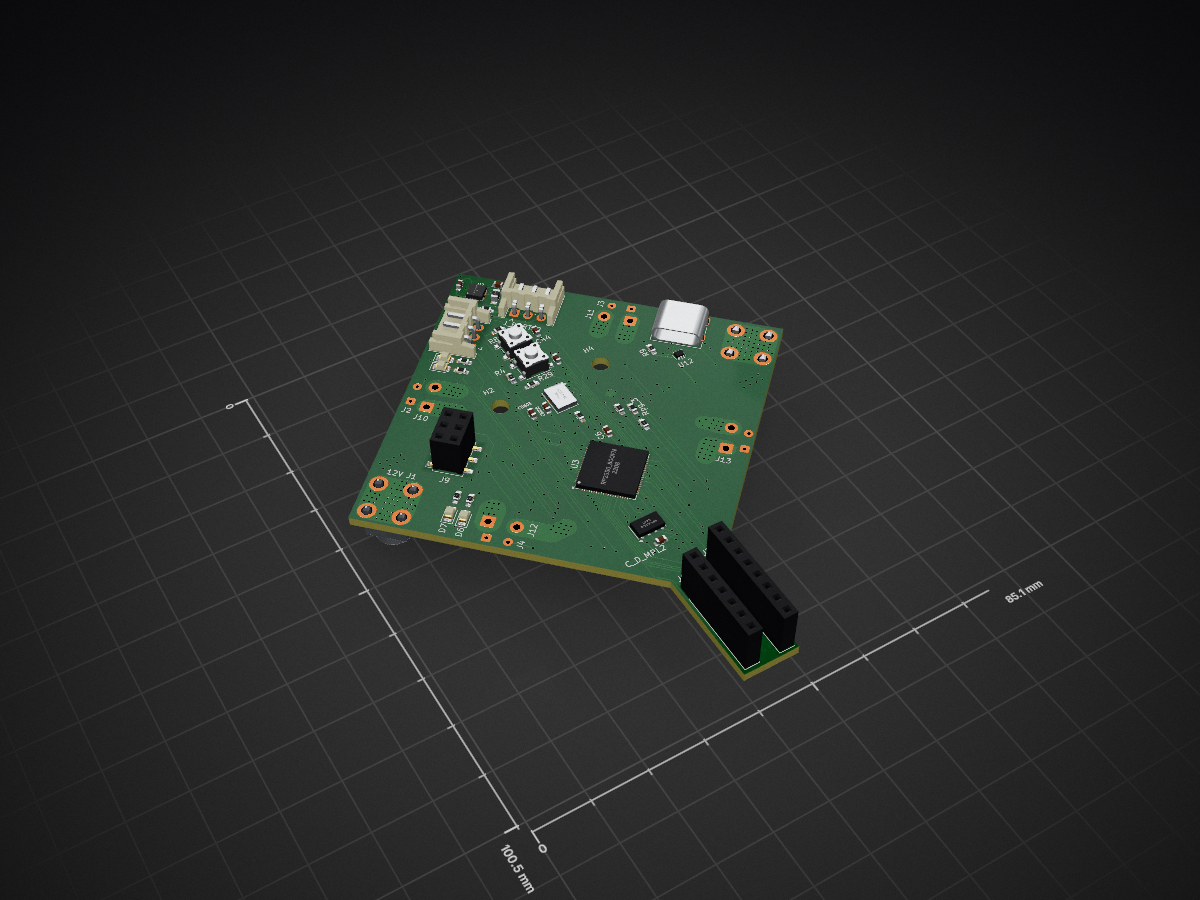
It measures 85.1 × 100.5 mm and has 4 copper layers, 1.6 mm thick.
103 parts, built around the MPL3115A2R1, TPS56637RPAR, TPS62142RGT and W25Q128JVSIQ. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rober708/BIRD-E repository on GitHub, at the commit this page was made from: the board is onboard-PCB/onboard_pcb/onboard_pcb.kicad_pcb and its schematic onboard-PCB/Power_Distro/Initial_PCB_Oct_21.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask rober708 before reusing the design.

ewyrick-mark-1/Chromatone
Chromatone is an embedded audio visualizer running on the Raspberry Pi RP2350. It samples audio through the ADC, performs a real-time FFT, detects musical notes, and drives an RGB LED output based on the results.

ndesserich/ECE-36200-Final-Project-PCB
A PCB that integrates an RP2350 and various peripherals to play games.

MAGG4444/BT_Audio_Player_PCB
Bluetooth-enabled audio player PCB for wireless audio playback and easy device integration.

PurdueECE-362-SSTV-Project/SSTV-Hardware
This repo contains the SCHEM and PCB files for the SSTV Receiver.


KungfuPancake/longboi
Possibly the longest controller board to control the BoxTurtle AFC

PTR-projects/PTR_mini_hardware
Welcome to the KPPTR-hardware repository! This repository contains the design files for the hardware components used in the KPPTR project.