2 layers100 × 100 mm
 rene-dev/stmbl990
AC Servo Driver for STM32F4
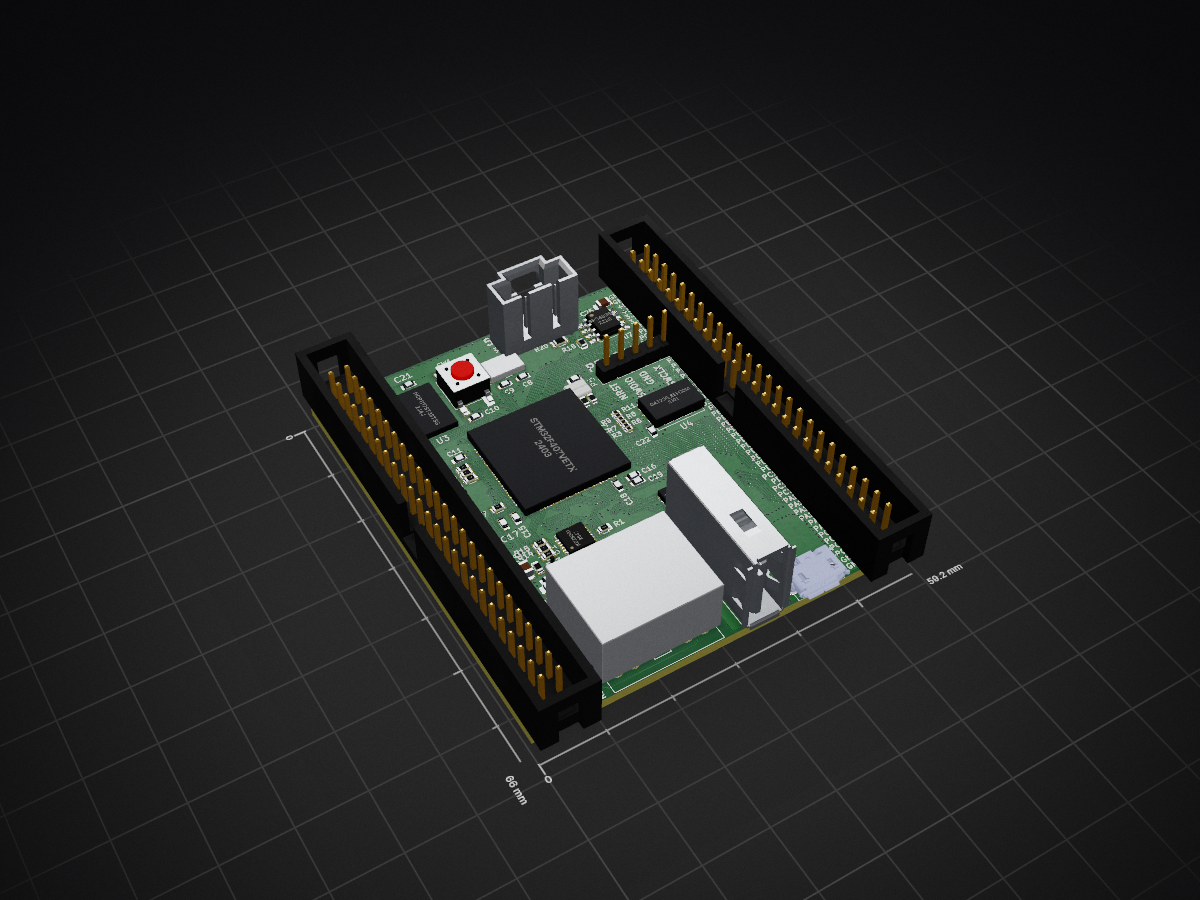
Ethernet bob is an open-source printed circuit board by rene-dev, from the rene-dev/stmbl repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 59.2 × 66 mm with 562 parts on 146 nets, routed with 1,672 tracks and 112 vias.
It is built around the SP3485EN-Y and USBLC6-4SC6. Its parts include 26 capacitors, 23 resistors, 8 connectors, 6 ICs and 3 diodes. It belongs with the robots and motor control and interfaces and adapters boards and the STM32 boards of this library.


Build Log: https://travis-ci.org/rene-dev/stmbl
THE AUTHORS OF THIS SOFTWARE ACCEPT ABSOLUTELY NO LIABILITY FOR ANY HARM OR LOSS RESULTING FROM ITS USE. IT IS EXTREMELY UNWISE TO RELY ON SOFTWARE ALONE FOR SAFETY. Any machinery capable of harming persons must have provisions for completely removing power from all motors, etc, before persons enter any danger area. All machinery must be designed to comply with local and national safety codes, and the authors of this software can not, and do not, take any responsibility for such compliance.
This software is released under the GPLv3.
There is work in progress on documentation: https://github.com/rene-dev/stmbl/blob/master/docs/src/Getting%20Started.adoc
IRC: #stmbl on irc.hackint.eu https://webirc.hackint.org/#stmbl
STMBL is an open source servo drive designed for Retrofitting CNC machines and Robots. It supports Industrial AC and DC servos with up to 320V and 2kW (see specs for details).
Documentation about the PCB and pinout of the feedback connector:
https://github.com/rene-dev/stmbl/wiki/Pinouts
https://github.com/rene-dev/stmbl/wiki/PCB


https://www.youtube.com/watch?v=d6NH1W7DUnQ
https://www.youtube.com/watch?v=oTllxnYAgFc
https://www.youtube.com/watch?v=gwgnAeGjZrA
https://www.youtube.com/watch?v=wXLcAZwjlzE
https://www.youtube.com/watch?v=24LftGNp4MI
https://www.youtube.com/watch?v=kqenepupJIs
https://www.youtube.com/watch?v=-E1o_5cFyto
Should you find the GPL license insufficient for your needs, other licenses can be purchased from my company.
Likewise, please contact us should you wish to fund the further development of this project, or are interesed in custom hardware, software, or commercial support.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 100n | stmbl:C_0603 | C1, C3, C6, C7, C11, C12, C13, C14, C15, C16, C17, C18, C19, C23, C26 |
| 7 | 1k | Resistors_SMD:R_0603 | R5, R10, R12, R13, R14, R15, R17 |
| 6 | R | Resistors_SMD:R_0402 | R3, R6, R7, R8, R9, R11 |
| 5 | C | stmbl:C_0603 | C5, C10, C20, C21, C22 |
| 4 | R | stmbl:R_0603 | R19, R22, R23, R24 |
| 3 | 22µ | stmbl:C_0805 | C2, C4, C24 |
| 2 | 18pF | stmbl:C_0603 | C8, C9 |
| 2 | 220 | Resistors_SMD:R_0603 | R4, R21 |
| 2 | CONN_02X25 | Pin_Headers:Pin_Header_Straight_2x25 | P2, P3 |
| 2 | LED | stmbl:LED-0805 | D2, D3 |
| 2 | R | Resistors_SMD:R_0805 | R16, R20 |
| 2 | testpoint | stmbl:Fiducial_1mm_Outer_CopperTop | T1, T2 |
| 1 | 6k49 | Resistors_SMD:R_0603 | R1 |
| 1 | BOOT0 | Capacitors_SMD:C_0603 | JP1 |
| 1 | C | stmbl:C_0805 | C25 |
| 1 | CAT250_EEPROM | mt25q:MLP8_8x6 | U4 |
| 1 | CONN_01X01 | Measurement_Points:Measurement_Point_Round-SMD-Pad_Big | J3 |
| 1 | CONN_01X04 | Pin_Headers:Pin_Header_Straight_1x04 | P6 |
| 1 | CONN_01X04 | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | P5 |
| 1 | CRYSTAL_SMD_4pin | stmbl-kicad-lib:Crystal_SMD_0603_4Pads | X1 |
| 1 | D_Schottky | stmbl:SMA_Standard | D1 |
| 1 | HR911105_RJ45 | stmbl:HY951180A_RJ45 | J1 |
| 1 | KSZ8081 | stmbl:QFN-24-1EP_4x4mm_Pitch0.5mm | U1 |
| 1 | NCP1117ST33T3G | TO_SOT_Packages_SMD:SOT-223 | U3 |
| 1 | R | Resistors_SMD:R_0603 | R18 |
| 1 | SP3485EN | Housings_SOIC:SOIC-8_3.9x4.9mm_Pitch1.27mm | U7 |
| 1 | STM32F407VETx | stmbl:LQFP-100_14x14mm_Pitch0.5mm | U2 |
| 1 | SW_PUSH | Buttons_Switches_SMD:SW_SPST_EVQQ2 | SW1 |
| 1 | USBLC6-4SC6 | TO_SOT_Packages_SMD:SOT-23-6 | U5 |
| 1 | USB_A | Connect:USB_A_Vertical | P4 |
| 1 | USB_OTG | stmbl:USB_Micro-B | P1 |
The 71 most common of 562 parts.


coon42/stmbl_otter
sudo dfu-util -d 0483:df11 -a 0 -s 0x8000000:leave -D objhvf3/hvf3.bin


Fluepke/Fluepdot
Project for controlling Annax flipdot panels used by the Berliner Verkehrsbetriebe

ReflexCreations/io-board
This repository contains source documents and manufacturing files for the RE:Flex Dance Pad's I/O Board. It was created using KiCAD 5.1.4.


It measures 59.2 × 66 mm and has 4 copper layers, 1.6 mm thick.
562 parts, built around the SP3485EN-Y and USBLC6-4SC6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rene-dev/stmbl repository on GitHub, at the commit this page was made from: the board is hw/kicad/bob/ethernet_bob/ethernet_bob.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).