2 layers27.9 × 20.3 mm
Rfm95-breaktout
RainDrop-lora/raindrop
Soil moisture monitoring system on LoRaWAN network
5 parts10Apache-2.0

 RainDrop-lora/raindrop10
Soil moisture monitoring system on LoRaWAN network
Lora bridge is an open-source printed circuit board by RainDrop-lora, from the RainDrop-lora/raindrop repository on GitHub, published under the Apache-2.0 licence. It is a 4-layer board of 63 × 50 mm with 74 parts on 67 nets, routed with 473 tracks and 285 vias.
It is built around the SN65HVD72D, RS485 and RFM95W-868S2. Its parts include 20 resistors, 15 capacitors, 9 diodes, 6 connectors and 5 transistors. It belongs with the radio and wireless and interfaces and adapters boards and the SAM D and SAM boards of this library.


This is a board that is specifically designed to easily hook up RS485 and I2C sensors to LoRaWAN network.
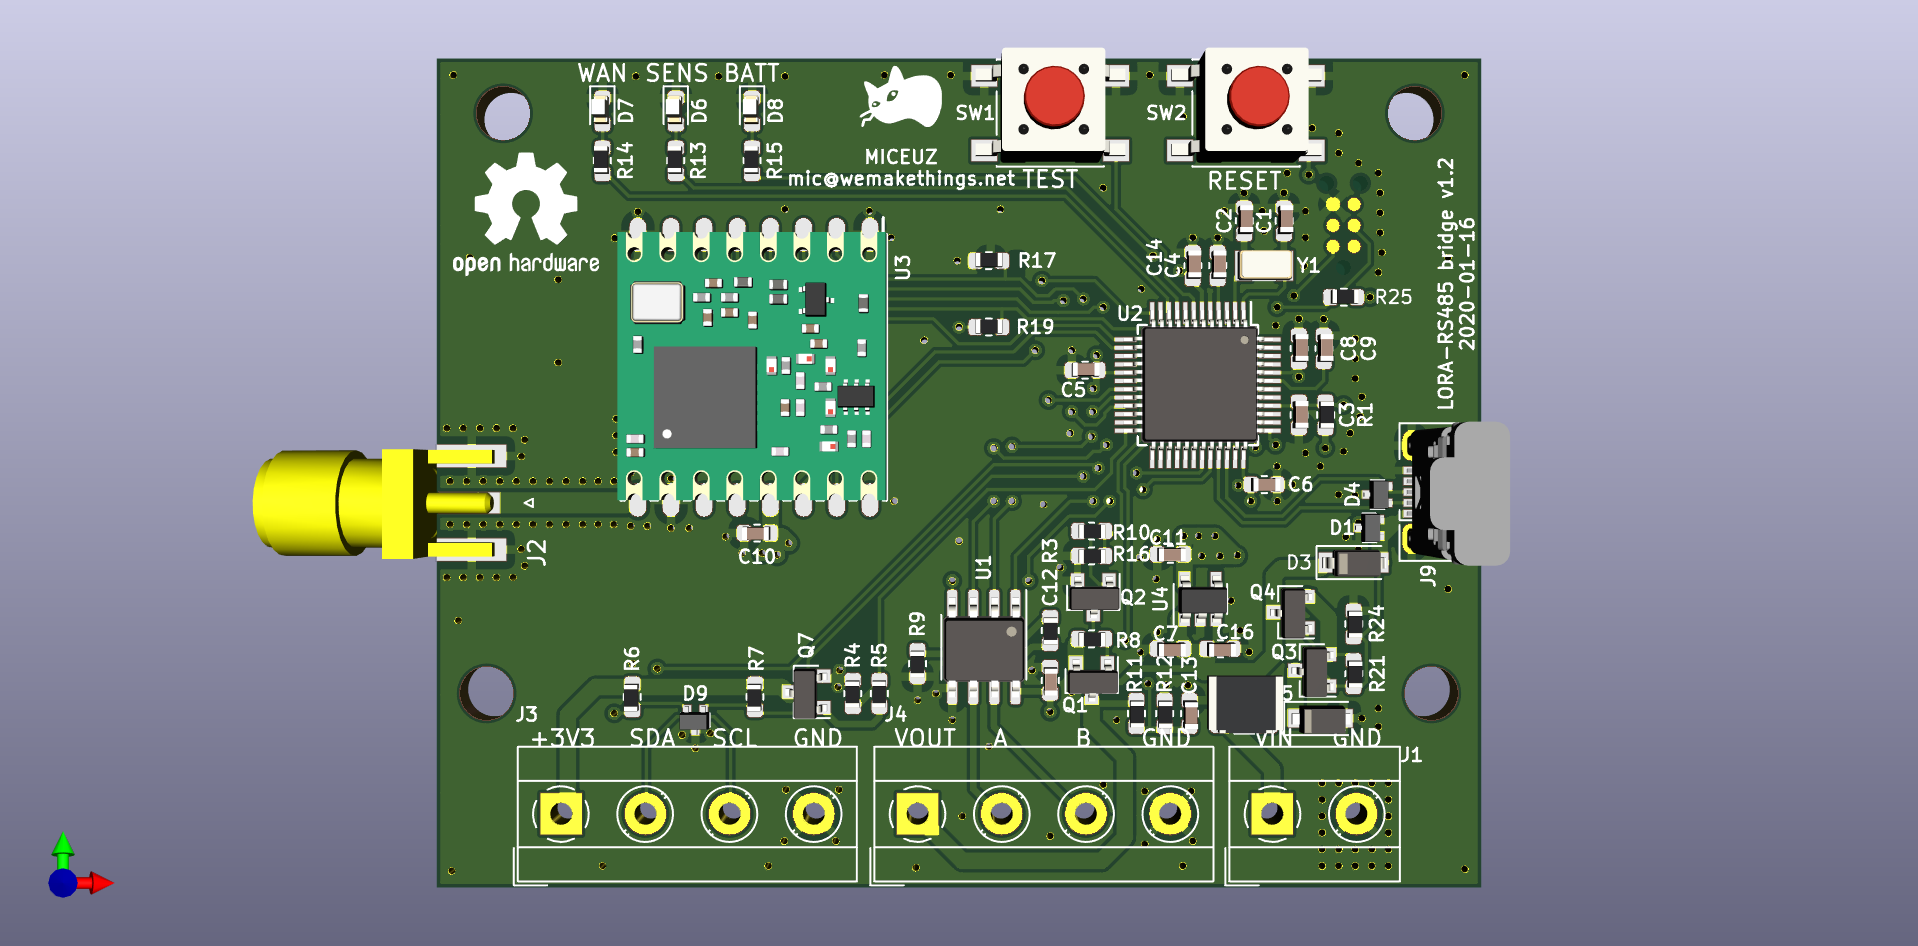
The board is designed to be used with 4xAA 1.5V cells, actually physical dimensions of the board resemble a common cheap 4xAA holder. This strategy was chosen because for low power device it makes little sense to use recheargable batteries as you probably will not want to bring back device from field to charge it, it's much more practical to just change the batteries. 4xAA configuration allows to use up full capacity of AA cell - typically AA cells are totally flat at 0.8V, thus the circuit will stay fully operational till the batteries are flat - 0.8x4=3.2V while microcontroller works down to 2.5V and RFM69 module works down to 1.8V.
Nevertheless, power sources up to 12V can be used. Also rechargeable LiPo cells can be used.
A SMA connector is available on board, a right angle SMA connector designed for 1.6mm thickness board can be fitted.
Nevertheless, a simple wire works just fine, I was able to transmit messages up to 10km away using a simple piece of wire as an antenna. Solder a piece of single core wire and cut it to a length for your frequency:
A working example firmware source code is provided. The firmware takes care of setting up radio module, sleep, querying sensors and formatting payload and transmission.
A tutorial provided by Adafruit for Feather M0 boards can be followed for the programming environment setup. In a nutshell:
https://adafruit.github.io/arduino-board-index/package_adafruit_index.jsonThree leds are provided on the board called WAN, SENS and BATT. It is up to the user to decide how exaclty to use them, but general guidance is that WAN led displays radio activity, SENS led provides sensor activity or status indication and BATT led provides battery status indication.
RESET and TEST buttons are available. RESET button resets the microcontroller, also it can be used to enter the bootloader mode for firmware upload. If sleep is utilised in the firmware, doubleclick the RESET button to enter the bootloader.
TEST button usage is up to the user.
Serial port is availale via USB-CDC interface, it can be used for debug messages, command line interface or other uses to be decided by the user. Note that in sleep mode USB is disconnected, disable sleep in the firmware to use the serial port.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 1M | Resistor_SMD:R_0603_1608Metric | R3, R4, R8, R9, R16, R17, R19, R21, R24 |
| 9 | 1u | Capacitor_SMD:C_0603_1608Metric | C3, C4, C5, C6, C8, C9, C12, C13, C14 |
| 5 | 1k | Resistor_SMD:R_0603_1608Metric | R1, R13, R14, R15, R25 |
| 4 | 4.7u | Capacitor_SMD:C_0603_1608Metric | C7, C10, C11, C16 |
| 4 | MountingHole | Mounting_Holes:MountingHole_3.2mm_M3_DIN965 | H1, H2, H3, H4 |
| 4 | Q_PMOS_GSD | Package_TO_SOT_SMD:SOT-23 | Q1, Q3, Q4, Q7 |
| 3 | D_TVS_x2_AAC | miceuz-lib:SC89 | D1, D4, D9 |
| 3 | LED | LED_SMD:LED_0603_1608Metric | D6, D7, D8 |
| 2 | 150 | Resistor_SMD:R_0603_1608Metric | R5, R10 |
| 2 | 22p | Capacitor_SMD:C_0603_1608Metric | C1, C2 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric | R6, R7 |
| 2 | Fiducial | Fiducials:Fiducial_1mm_Dia_2mm_Outer | FID1, FID2 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R12 |
| 1 | 1N4148 | Diode_SMD:D_SOD-123 | D3 |
| 1 | 20k | Resistor_SMD:R_0603_1608Metric | R11 |
| 1 | 32.768 | Crystals:Crystal_SMD_3215-2pin_3.2x1.5mm | Y1 |
| 1 | 7.6V | Diode_SMD:D_SOD-323 | D2 |
| 1 | ANT | miceuz-lib:SMA_6.35_EdgeMount | J2 |
| 1 | ATSAMD21G18A-AUT | Package_QFP:TQFP-48_7x7mm_P0.5mm | U2 |
| 1 | D_TVS | Diode_SMD:D_SOD-123F | D5 |
| 1 | LOGO | miceuz-lib:catnip | G*** |
| 1 | NCP718 | TO_SOT_Packages_SMD:SOT-23-5 | U4 |
| 1 | Q_NMOS_GSD | Package_TO_SOT_SMD:SOT-23 | Q2 |
| 1 | RFM95W-868S2 | miceuz-lib:RFM95 | U3 |
| 1 | SN65HVD72 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1 |
| 1 | SWD | miceuz-lib:TC2030-MCP-NL | J5 |
| 1 | SW_Reset | Button_Switch_SMD:SW_Push_1P1T_NO_6x6mm_H9.5mm | SW2 |
| 1 | SW_Test | Button_Switch_SMD:SW_Push_1P1T_NO_6x6mm_H9.5mm | SW1 |
| 1 | Thermistor_PTC | Fuse:Fuse_1206_3216Metric | TH1 |
| 1 | USB micro | Connectors_USB:USB_Micro-B_Vertical_Molex-105133-0001 | J9 |
| 1 | battery | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_Pitch5.08mm | J1 |
| 1 | i2c | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01604HBWC_Pitch5.08mm | J3 |
| 1 | rs485 | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01604HBWC_Pitch5.08mm | J4 |
The 70 most common of 74 parts.
It measures 63 × 50 mm and has 4 copper layers, 1.6 mm thick.
74 parts, built around the SN65HVD72D, RS485 and RFM95W-868S2. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the RainDrop-lora/raindrop repository on GitHub, at the commit this page was made from: the board is Electronics/lora-rs485-bridge/lora-bridge.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Apache-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
RainDrop-lora/raindrop
Soil moisture monitoring system on LoRaWAN network

Miceuz/rs485-moist-sensor
Digital (RS485 - based) soil moisture and temperature sensor

Miceuz/rs485-breakout
A tiny development board to quickly prototype RS485/Modbus devices


Technariumas/smalsiukas
The conversion of a forklift truck to a line following robot.


punkfab/pcb-corpus
235 real KiCad boards from open-source hardware repositories, prepared as a placement and routing benchmark

dridri/bcflight
Raspberry Pi based drone flight controller and remote control
