2 layers42 × 42 mm
NEW PCB ADCS
niki100jad/POQUITO_ADCS
ADCS for a PocketQube mission (Warning: Still untested!)
82 parts2

 lucaspcamargo/hydrus-v2
Second version of the Hydrus project: sw, hw, docs, etc. (RaspberryPi based)
Drone v2-systemboard notrace is an open-source printed circuit board by lucaspcamargo, from the lucaspcamargo/hydrus-v2 repository on GitHub. It is a 2-layer board of 100 × 100 mm with 61 parts on 64 nets.
It is built around the ATMEGA328-PU, AD8603AUJ and BC547. Its parts include 23 connectors, 15 resistors, 6 capacitors, 6 diodes and 3 ICs. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.


Hydrus is an autonomous surface vehicle for water quality measurement. The original v1 platform won first place at the Intel Embedded Systems Competition 2016. This repository contains v2: a ground-up retool of the vehicle firmware and hardware, now running on a Raspberry Pi Zero W atop a custom backbone board.
The vehicle navigates a body of water along a pre-planned route, stops at designated waypoints to collect sensor readings, and streams data in real time to a Qt5-based base station running on a laptop.
The project spans embedded firmware, base station software, custom PCB hardware design, and 3D-printed mechanical components.
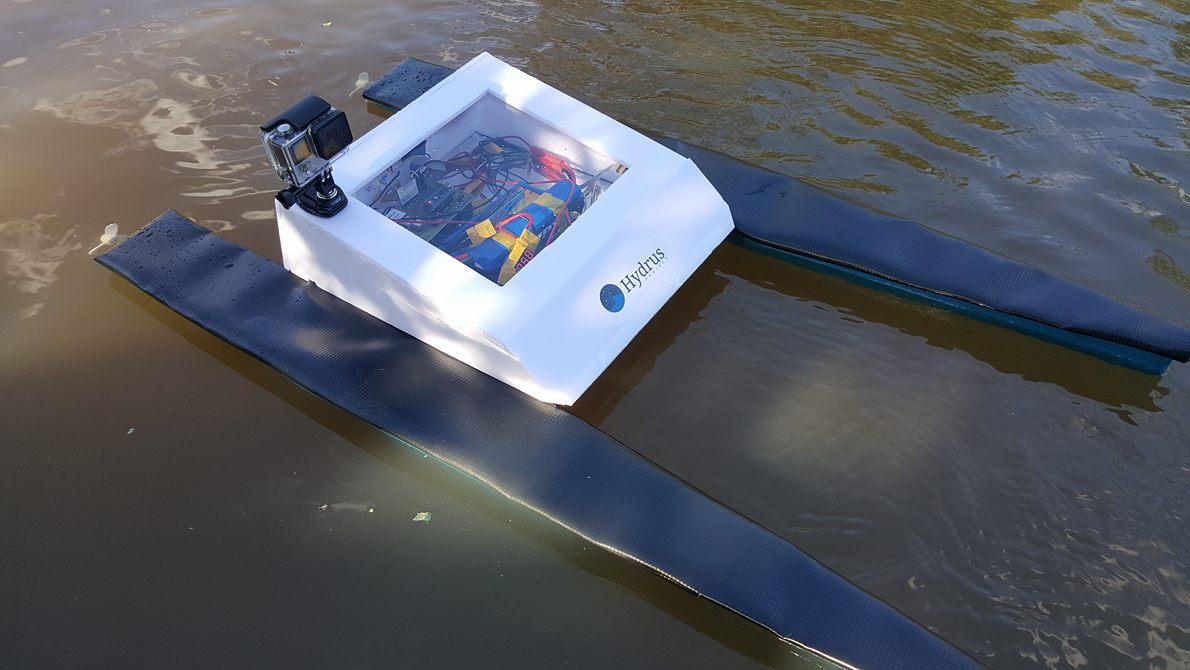
Hydrus during field testing on a lake in Joinville, 2016.
The vehicle runs on a Raspberry Pi Zero W with a custom backbone board that integrates all peripherals:
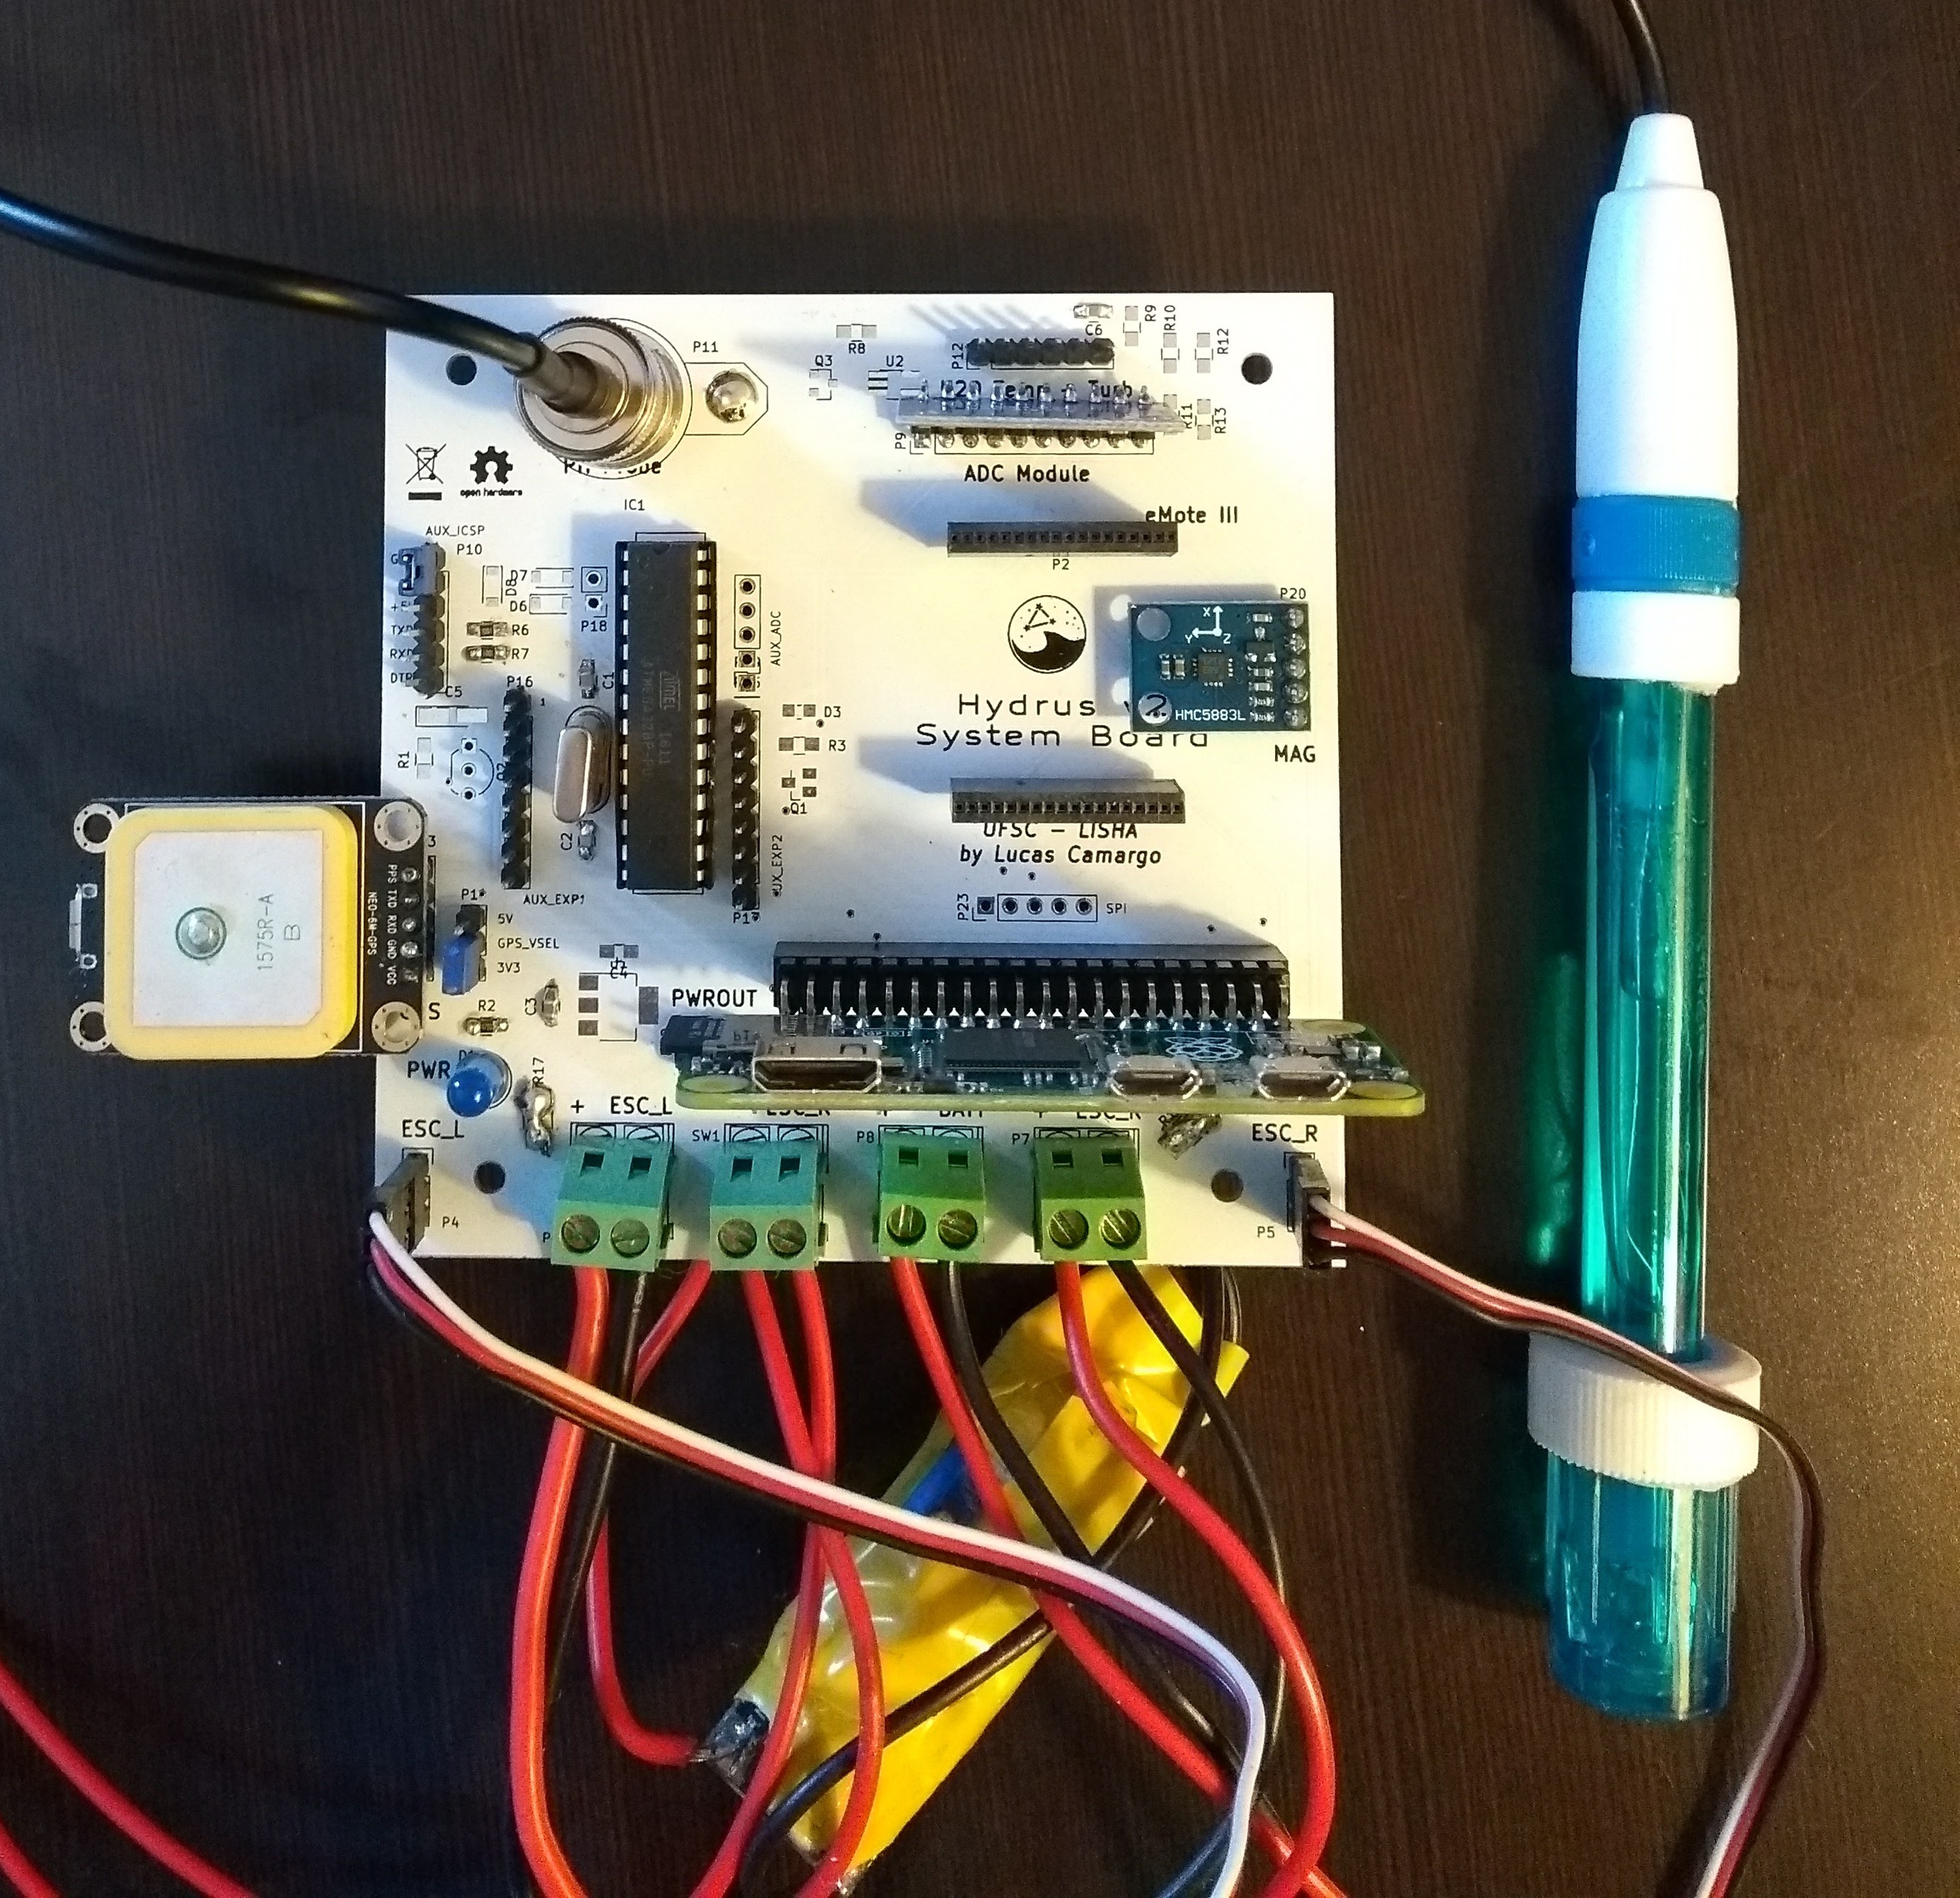
The custom Hydrus v2 System Board, with GPS antenna and pH probe.
Hardware design files (KiCad schematics and layouts) are in hw/. Mechanical parts (propellers, axle adapters, board mounts) are 3D-printable models in mech/.
The vehicle firmware (fw/) is written in C++11 and built with CMake. It runs four concurrent periodic tasks:
| Task | Rate | Responsibility |
|---|---|---|
SystemTask | 2 Hz | State machine, battery/thermal monitoring, shutdown |
SensingTask | 30 Hz | pH, temperature, turbidity, IMU heading |
NavigationTask | 10 Hz | GPS, motor control, waypoint tracking |
CommTask | 20 Hz | TCP link to base station, command routing |
All tasks share a double-buffered blackboard with reader-writer locking, which eliminates contention between producers and consumers without blocking.
Autonomous navigation follows a state machine: align to bearing → traverse toward waypoint → acquire data → advance to next waypoint. Distance and bearing use the Haversine formula and forward azimuth calculation against WGS-84 coordinates. Speed is throttled adaptively as the vehicle closes in on a waypoint.
A remote-control mode is also supported, accepting velocity vectors from the base station for manual operation.
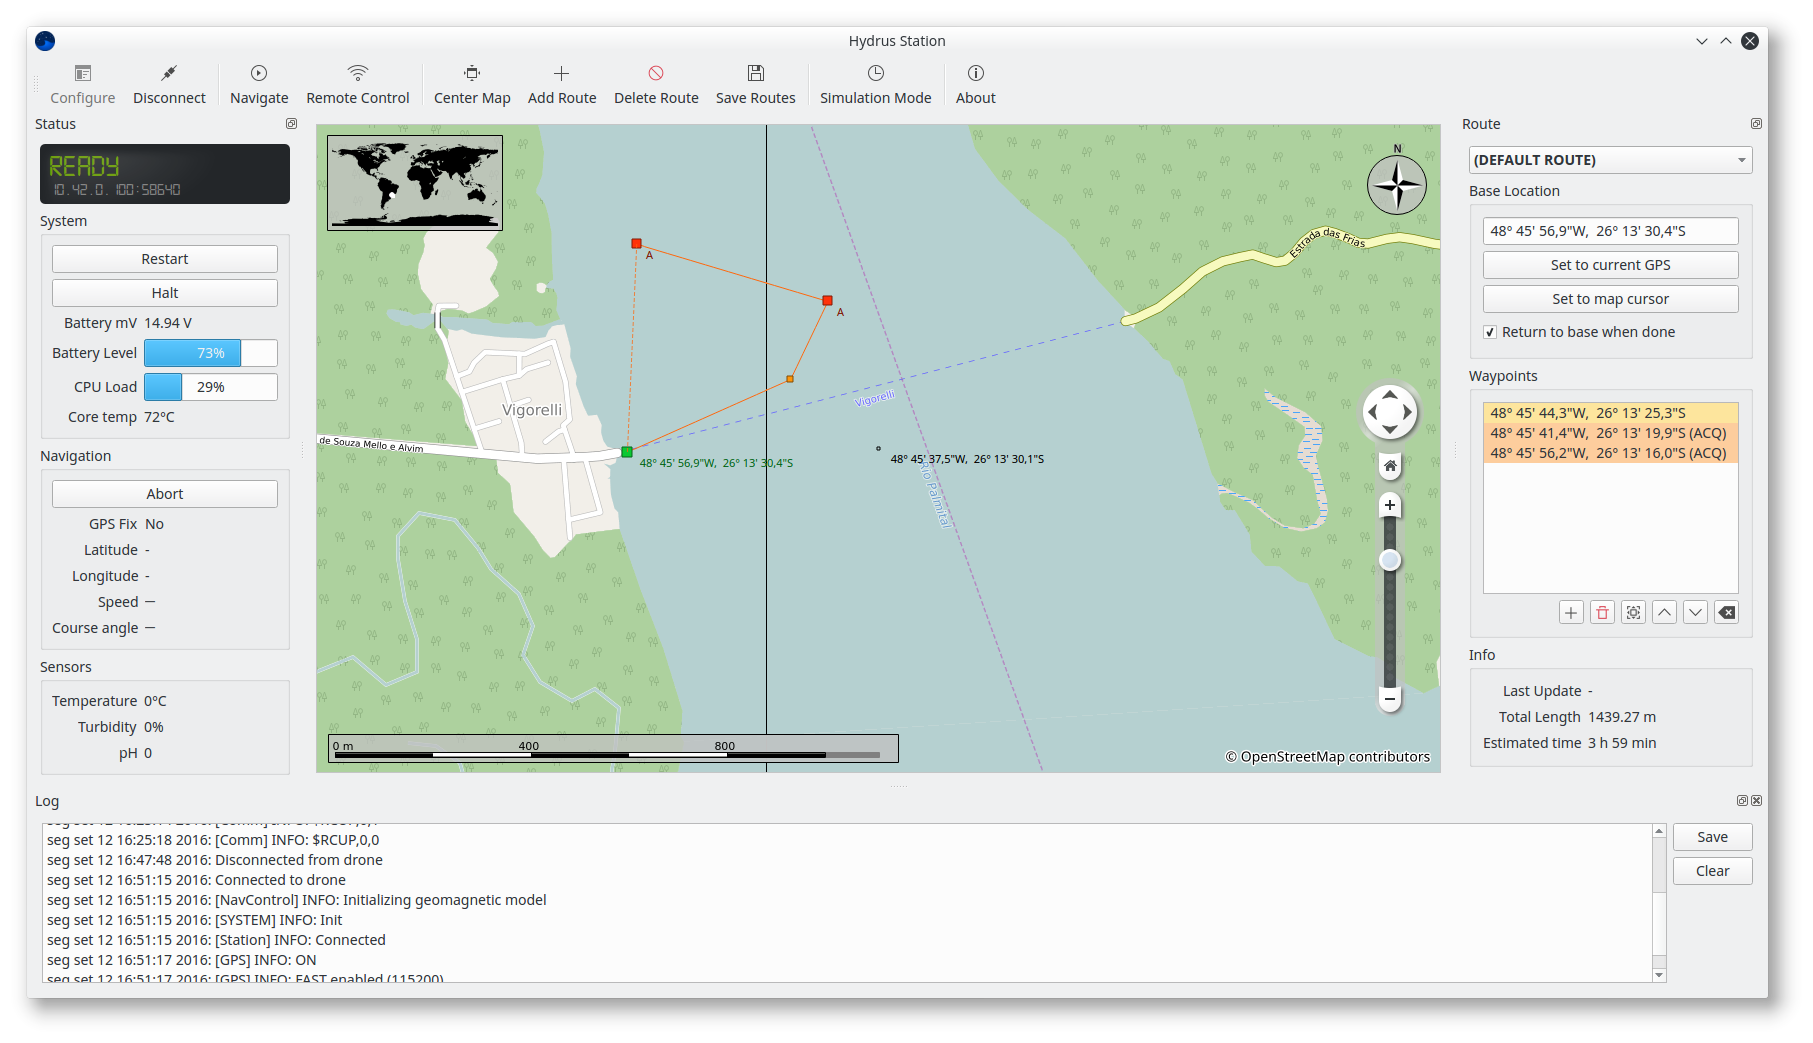
Base station software showing a live mission on the map.
The base station (station/) is a Qt5/C++ desktop application featuring:
Communication uses a TCP socket (port 6666). The vehicle streams binary blackboard snapshots and log messages; the base station sends text commands.
doc/      Documentation and branding (including competition presentation)
fw/       Vehicle firmware (C++11, CMake)
lib/      Shared libraries
station/  Base station software (Qt5, C++11)
hw/       PCB schematics and layouts (KiCad)
mech/ 3D-printable mechanical componentsThe original Hydrus project was developed at Universidade Federal de Santa Catarina. Team members: Guilherme Augusto Pangratz and Emili Bohrer. Mentored by Prof. Dr. Giovani Gracioli.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 4.7k | Resistors_SMD:R_0805_HandSoldering | R10, R11, R12, R13 |
| 4 | D | Diodes_SMD:D_SOD-123 | D2, D6, D7, D8 |
| 2 | 0R | Resistors_SMD:R_1210_HandSoldering | R16, R17 |
| 2 | 1k | Resistors_SMD:R_0805_HandSoldering | R6, R7 |
| 2 | 22pF | Capacitors_SMD:C_0805_HandSoldering | C1, C2 |
| 1 | .1u | Capacitors_SMD:C_0805_HandSoldering | C6 |
| 1 | 0.47uf | Capacitors_SMD:C_0805_HandSoldering | C3 |
| 1 | 1.5k | Resistors_SMD:R_0805_HandSoldering | R8 |
| 1 | 10K | Resistors_SMD:R_0805_HandSoldering | R1 |
| 1 | 10uF | Capacitors_Tantalum_SMD:CP_Tantalum_Case-S_EIA-3216-12_Hand | C5 |
| 1 | 1K | Resistors_SMD:R_0805_HandSoldering | R2 |
| 1 | 1mH | Inductors:Inductor_1212 | L1 |
| 1 | 300R | Resistors_SMD:R_0805_HandSoldering | R3 |
| 1 | 470R | Resistors_SMD:R_0805_HandSoldering | R9 |
| 1 | 47k | Resistors_SMD:R_0805_HandSoldering | R14 |
| 1 | 6.4k | Resistors_SMD:R_0805_HandSoldering | R15 |
| 1 | 66uf | Capacitors_SMD:C_0805_HandSoldering | C4 |
| 1 | AD8603 | TO_SOT_Packages_SMD:TSOT-23-5_HandSoldering | U2 |
| 1 | ADC_MODULE | Pin_Headers:Pin_Header_Straight_1x10_Pitch2.54mm | P9 |
| 1 | ADR1581 | TO_SOT_Packages_SMD:SOT-23 | Q3 |
| 1 | ATMEGA328-P | Housings_DIP:DIP-28_W7.62mm | IC1 |
| 1 | AUX_ADC | Pin_Headers:Pin_Header_Straight_1x04_Pitch2.54mm | P15 |
| 1 | AUX_ADC_GND | Pin_Headers:Pin_Header_Straight_1x01_Pitch2.54mm | P19 |
| 1 | AUX_ICSP_SERIAL | Pin_Headers:Pin_Header_Straight_1x06_Pitch2.54mm | P10 |
| 1 | AUX_P1 | Pin_Headers:Pin_Header_Straight_1x08_Pitch2.54mm | P17 |
| 1 | AUX_P2 | Pin_Headers:Pin_Header_Straight_1x08_Pitch2.54mm | P16 |
| 1 | AUX_UART | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | P18 |
| 1 | BATT | Connect:AK300-2 | P8 |
| 1 | BC547 | TO_SOT_Packages_THT:TO-92_Inline_Wide | Q2 |
| 1 | EMOTE3_EXP1 | emote3:HEADER_18x1_EMOTE | P1 |
| 1 | EMOTE3_EXP2 | emote3:HEADER_18x1_EMOTE | P2 |
| 1 | ESC_L | Pin_Headers:Pin_Header_Straight_1x03 | P4 |
| 1 | ESC_L_PWR | Connect:AK300-2 | P6 |
| 1 | ESC_R | Pin_Headers:Pin_Header_Straight_1x03 | P5 |
| 1 | ESC_R_PWR | Connect:AK300-2 | P7 |
| 1 | GPIO_EXT | Pin_Headers:Pin_Header_Straight_1x04_Pitch2.54mm | P21 |
| 1 | GPS_VDD_sel | Pin_Headers:Pin_Header_Straight_1x03_Pitch2.54mm | P14 |
| 1 | GPS_module | Pin_Headers:Pin_Header_Straight_1x05_Pitch2.54mm | P13 |
| 1 | H2O_temp_turb | Pin_Headers:Pin_Header_Straight_1x06_Pitch2.54mm | P12 |
| 1 | LED | LEDs:LED-5MM | D1 |
| 1 | LM3940 | TO_SOT_Packages_SMD:SOT-223-3Lead_TabPin2 | U1 |
| 1 | LOGO | hydrus:hydrus_logo_8mm | G*** |
| 1 | L_AUX_P | LEDs:LED_0805 | D3 |
| 1 | MAG_MODULE | Pin_Headers:Pin_Header_Straight_1x05_Pitch2.54mm | P20 |
| 1 | OSHW-Symbol_6.7x6mm_SilkScreen | Symbols:OSHW-Symbol_6.7x6mm_SilkScreen | OSW |
| 1 | PH_IN | Connect:BNC | P11 |
| 1 | PWR_OUT | Pin_Headers:Pin_Header_Straight_2x03_Pitch2.54mm | P22 |
| 1 | PWR_SW | Connect:AK300-2 | SW1 |
| 1 | SPI_OUT | Pin_Headers:Pin_Header_Straight_1x05_Pitch2.54mm | P23 |
| 1 | WEEE-Logo_4.2x6mm_SilkScreen | Symbols:WEEE-Logo_4.2x6mm_SilkScreen | WEEE |
| 1 | XT_AUX_16M | Crystals:Crystal_HC49-U_Vertical | Y1 |
| 1 | rbpi | Pin_Headers:Pin_Header_Straight_2x20 | P3 |
niki100jad/POQUITO_ADCS
ADCS for a PocketQube mission (Warning: Still untested!)

scalinq-lab/cryomagsens
The sensor unit was designed in KiCad 10 and manufactured by JLCPCB. It is built in a flex PCB material to achieve a very small build height, in order to come very close to the device under test.


ZeshuLiu/SX-70-Mk2
把板子上的U+ U- GND VCC焊到usb线上,连接电脑后可以当作树莓派Pico开发板进行操作,上传代码的参见这里(树莓派官网)。 \ 在将机身主控安装至机器内部之前需要将micropython固件及代码烧录至控制器中。后续可以通过机身控制器上的USB接口连接开发板并更新python代码。 将code根目录中的所有python文件上传至控制器(文件夹不需要),并且将gmain.py命名为…


SimoneDamian/RP_Spectroscopy_kicad
Circuits for the hardware part of the project
It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
61 parts, built around the ATMEGA328-PU, AD8603AUJ and BC547. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the lucaspcamargo/hydrus-v2 repository on GitHub, at the commit this page was made from: the board is hw/drone-v2-systemboard/drone-v2-systemboard-notrace.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask lucaspcamargo before reusing the design.