2 layers126.2 × 163.9 mm
Sterownik DC
lologog/RowSeederController
This project is a row seeder controller featuring DC motor control and CAN communication for efficient and precise seeding operations
104 partsMIT

 lologog/RowSeederController
This project is a row seeder controller featuring DC motor control and CAN communication for efficient and precise seeding operations
Sterownik DC is an open-source printed circuit board by lologog, from the lologog/RowSeederController repository on GitHub, published under the MIT licence. It is a 2-layer board of 109.1 × 100.1 mm with 134 parts on 118 nets, routed with 1,320 tracks and 102 vias.
It is built around the BTS5030-1EJA, BAS21 and BC807. Its parts include 65 resistors, 25 capacitors, 15 diodes, 11 connectors and 6 ICs. It belongs with the robots and motor control boards of this library.


This project focuses on the design and development of a modular DC motor controller system for a row seeder. The system ensures precise control over seed dispensing and supports communication with external devices via CAN protocol.
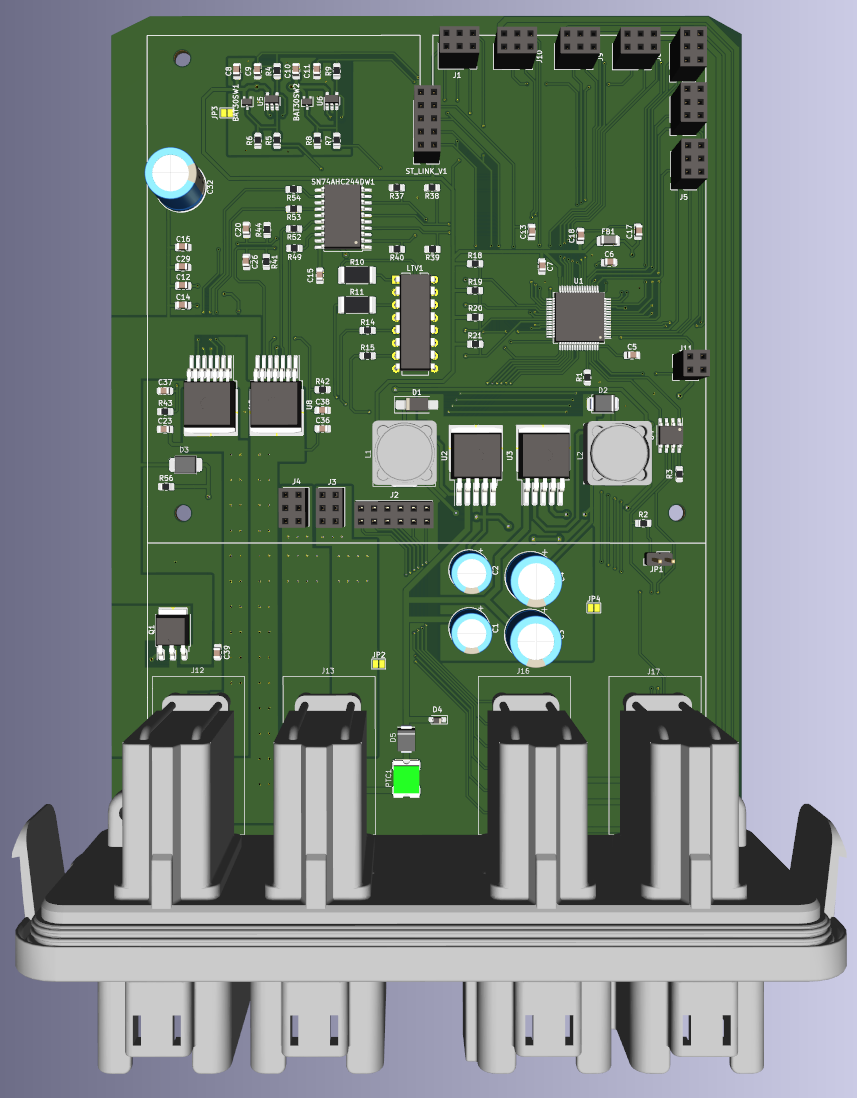
The project consists of a main controller board an an extension board connected via 2.54mm pin sockets:
This modular approach allows future modifications for broader compatibility and functionality.
Main Controller Board:
Extension Board:
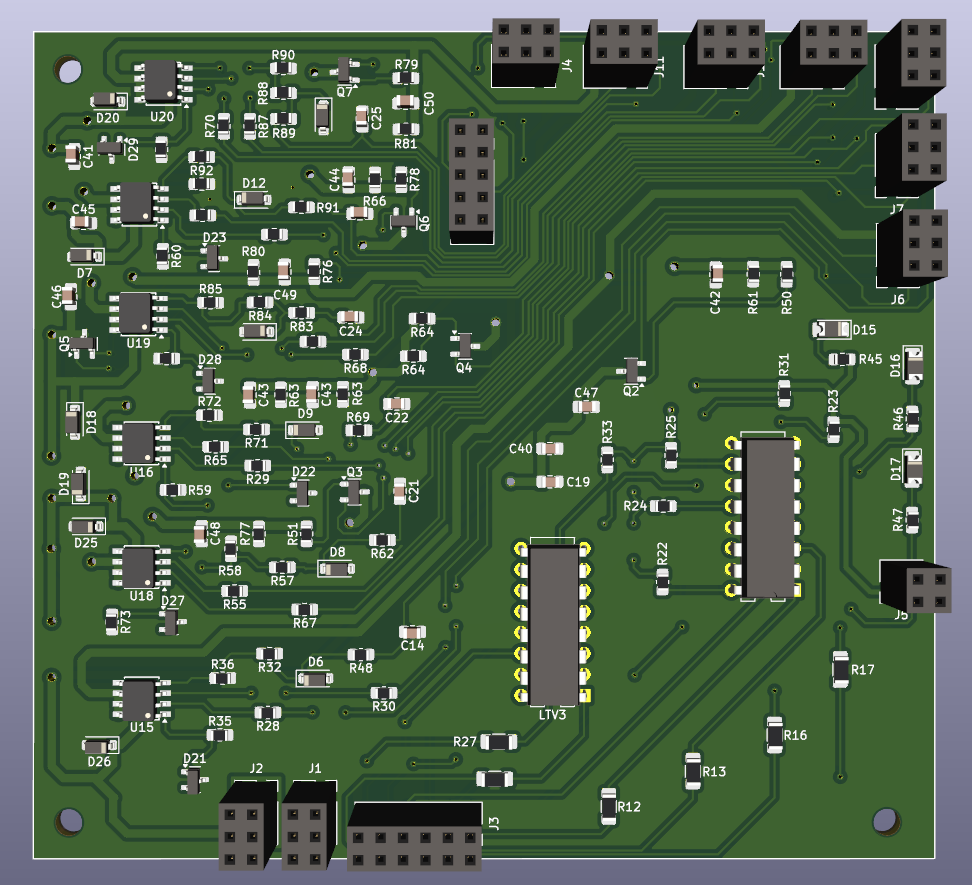
Extension PCB made by my friend :)
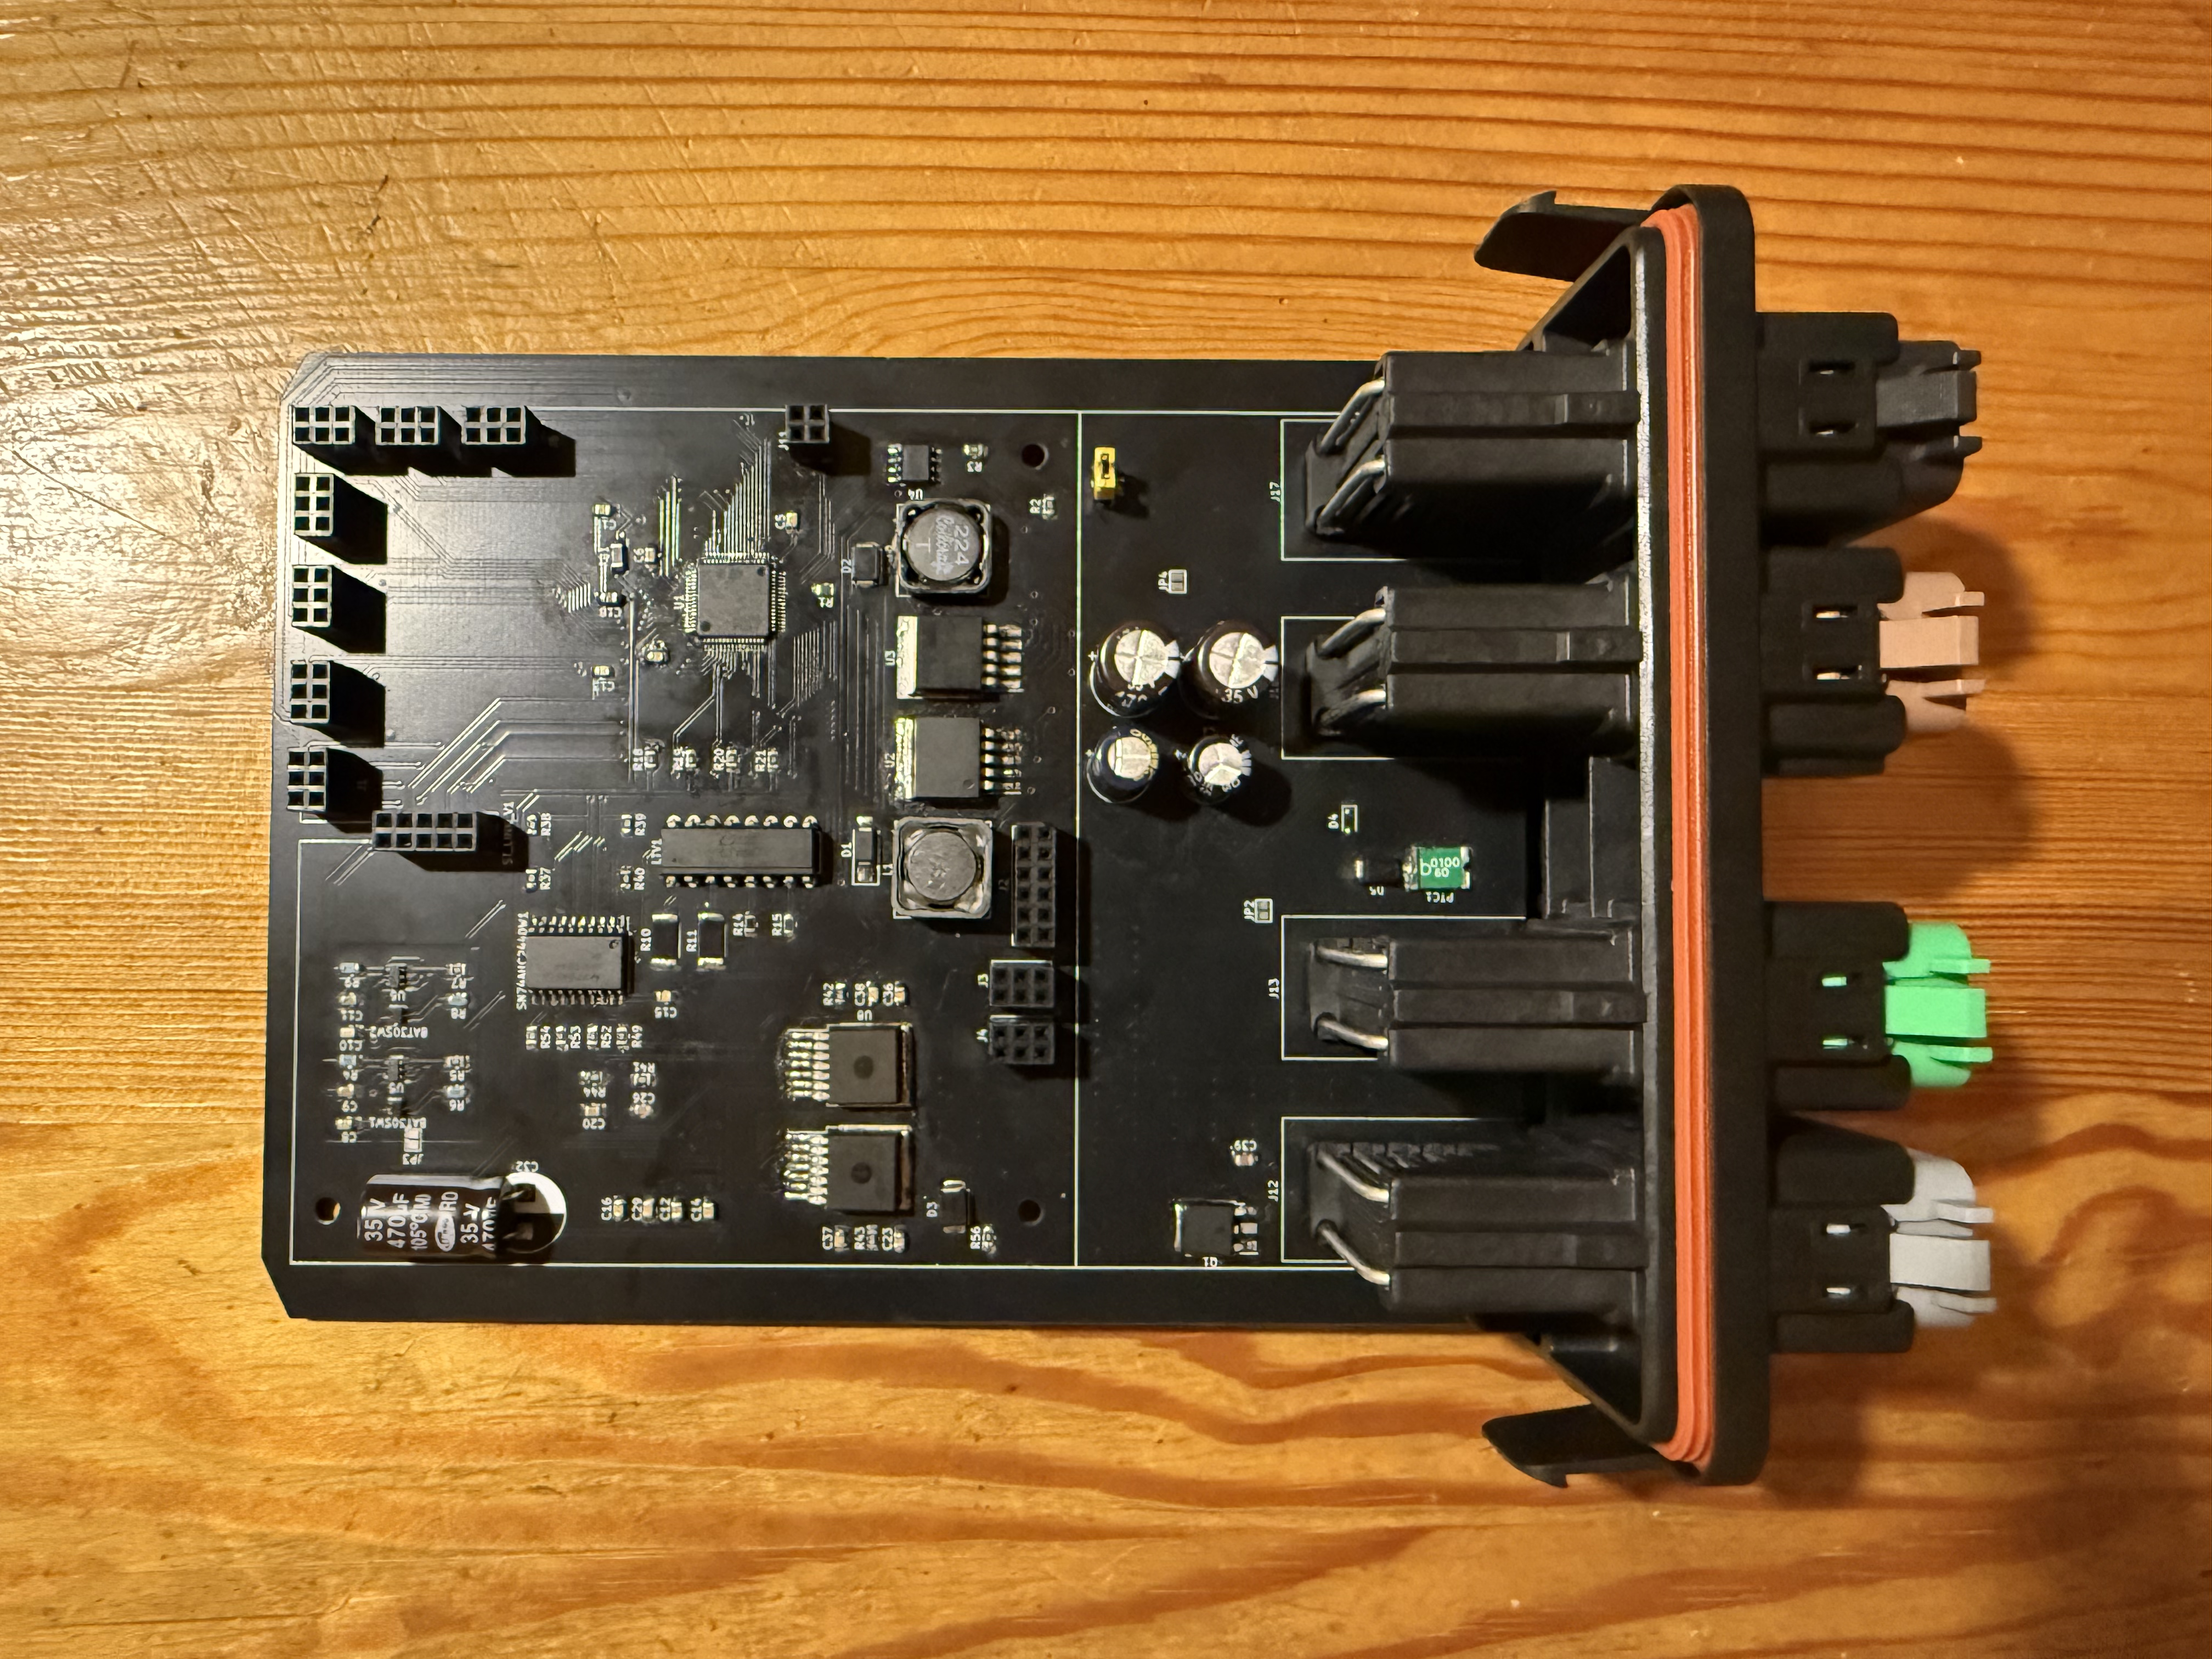
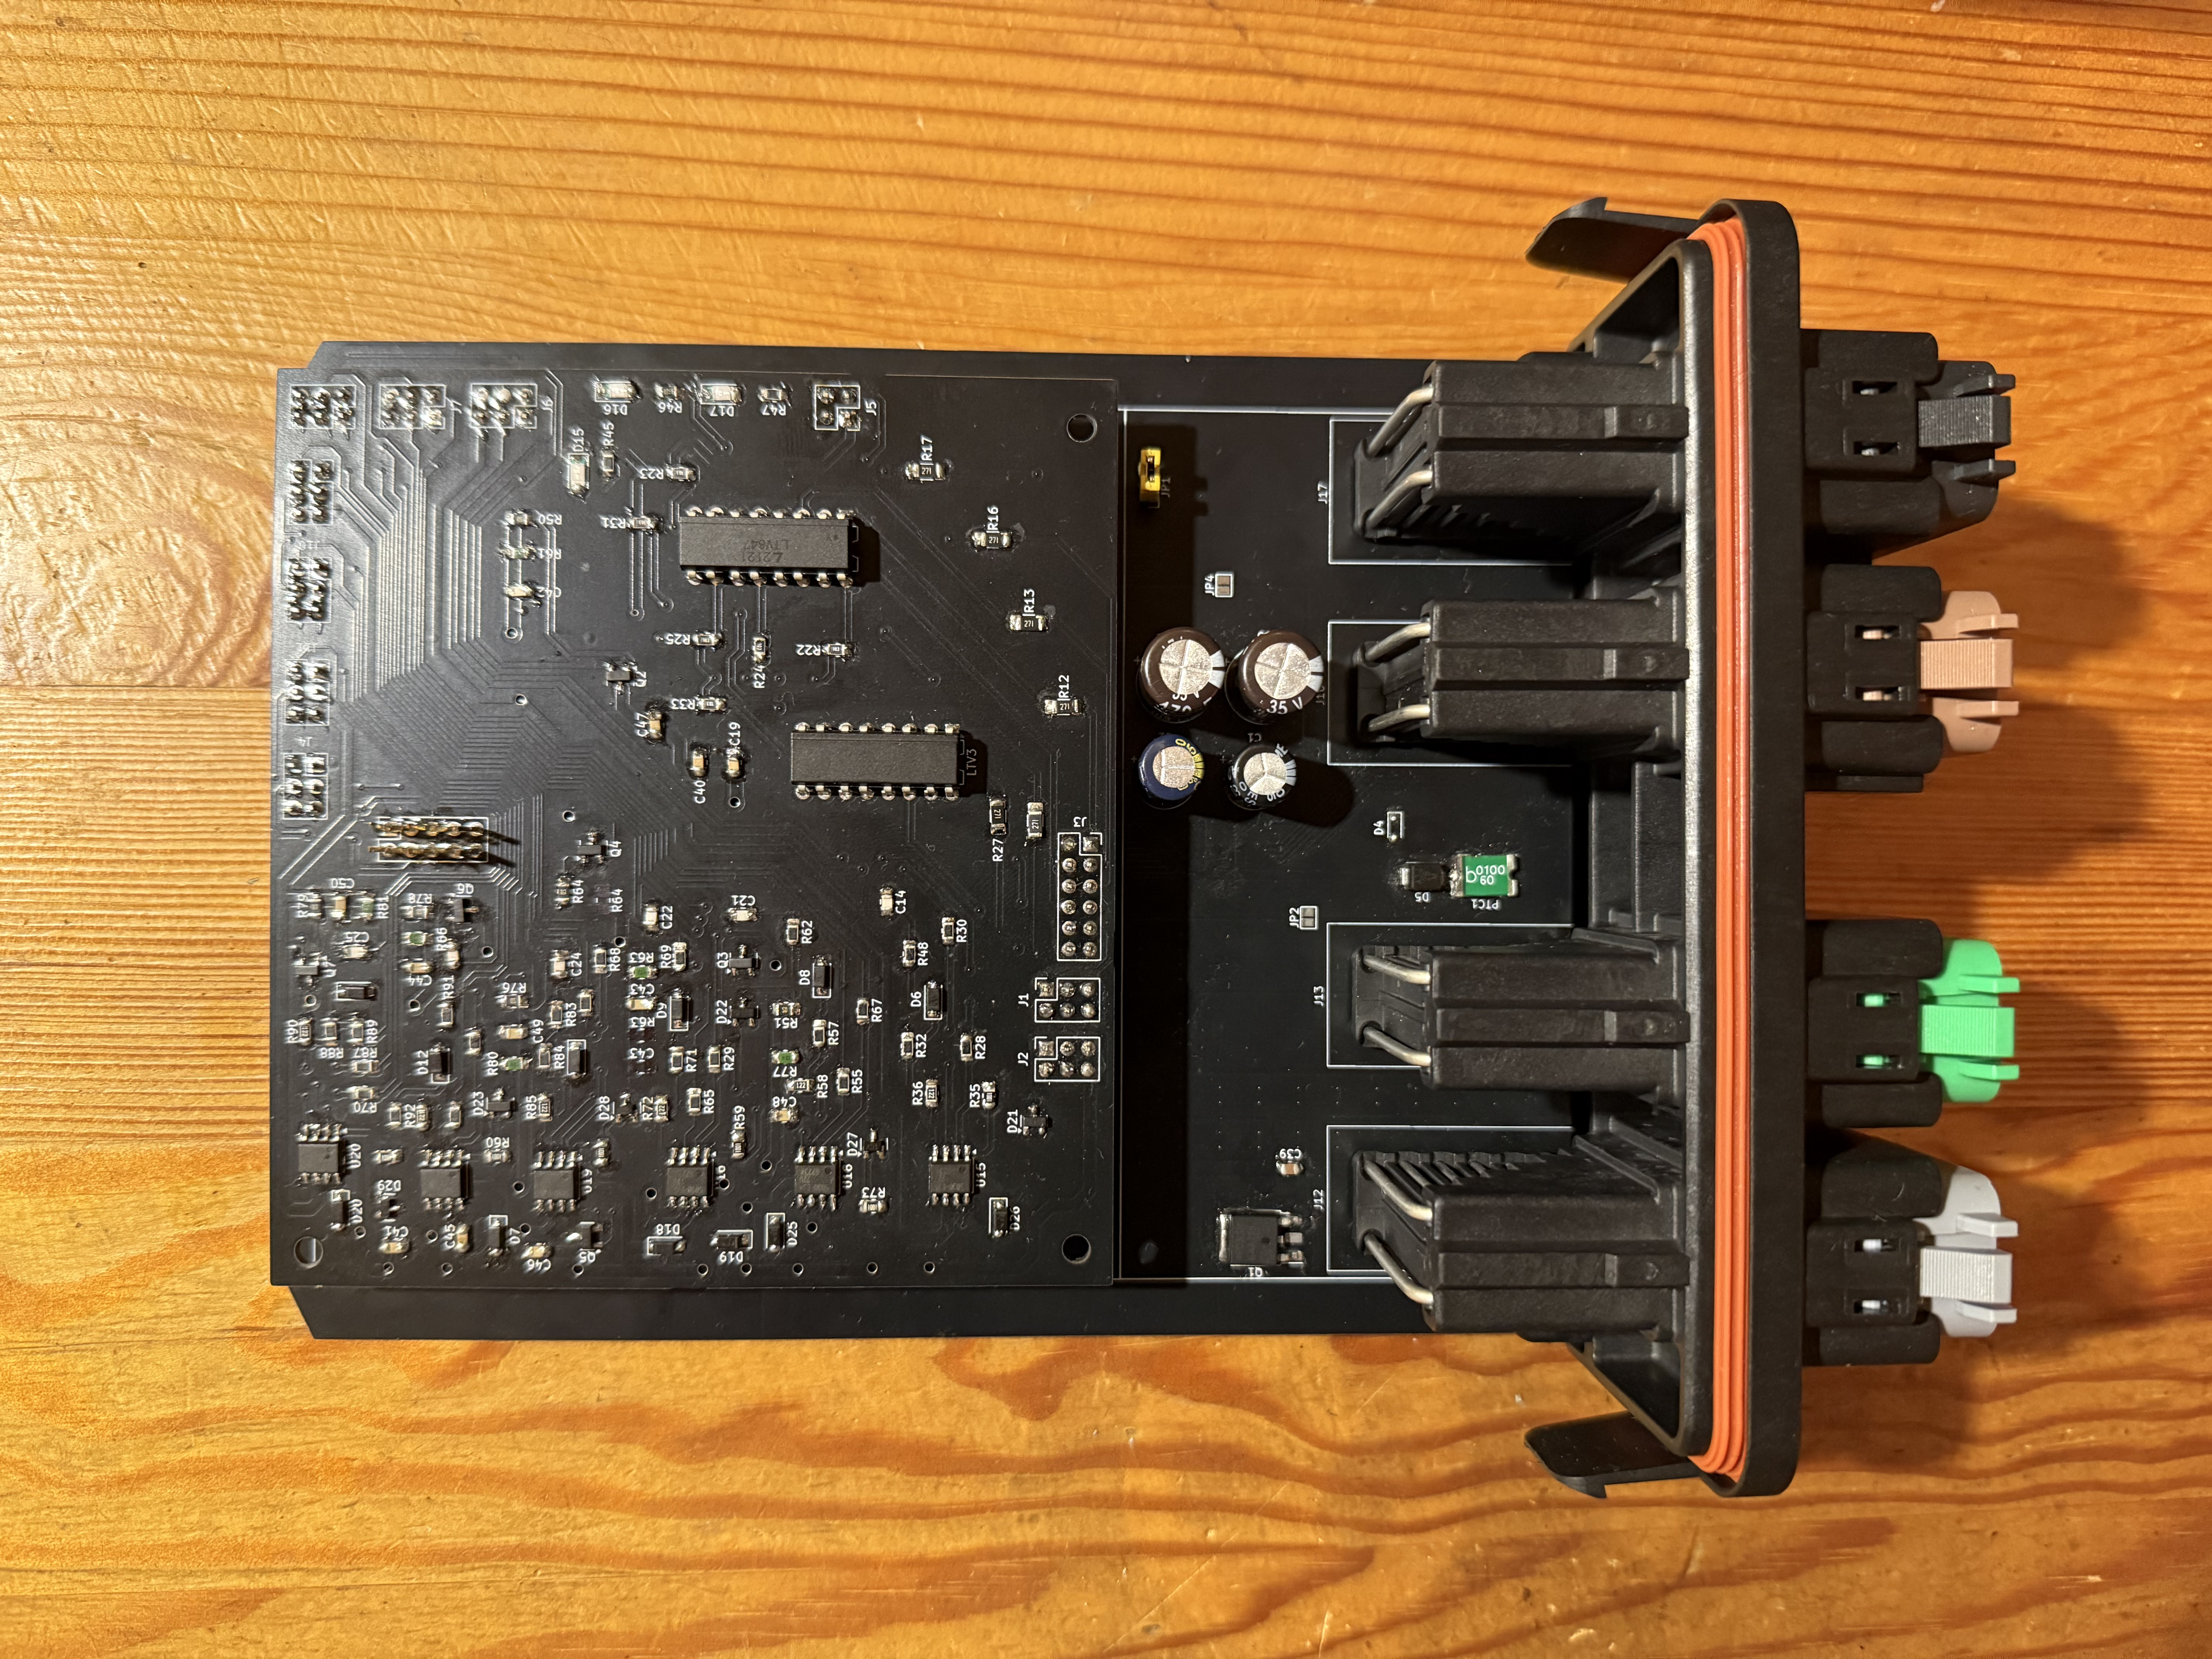
Below are images of the actual hardware implementation:
Fully assembled main controller:
Main controller connected with extension board:
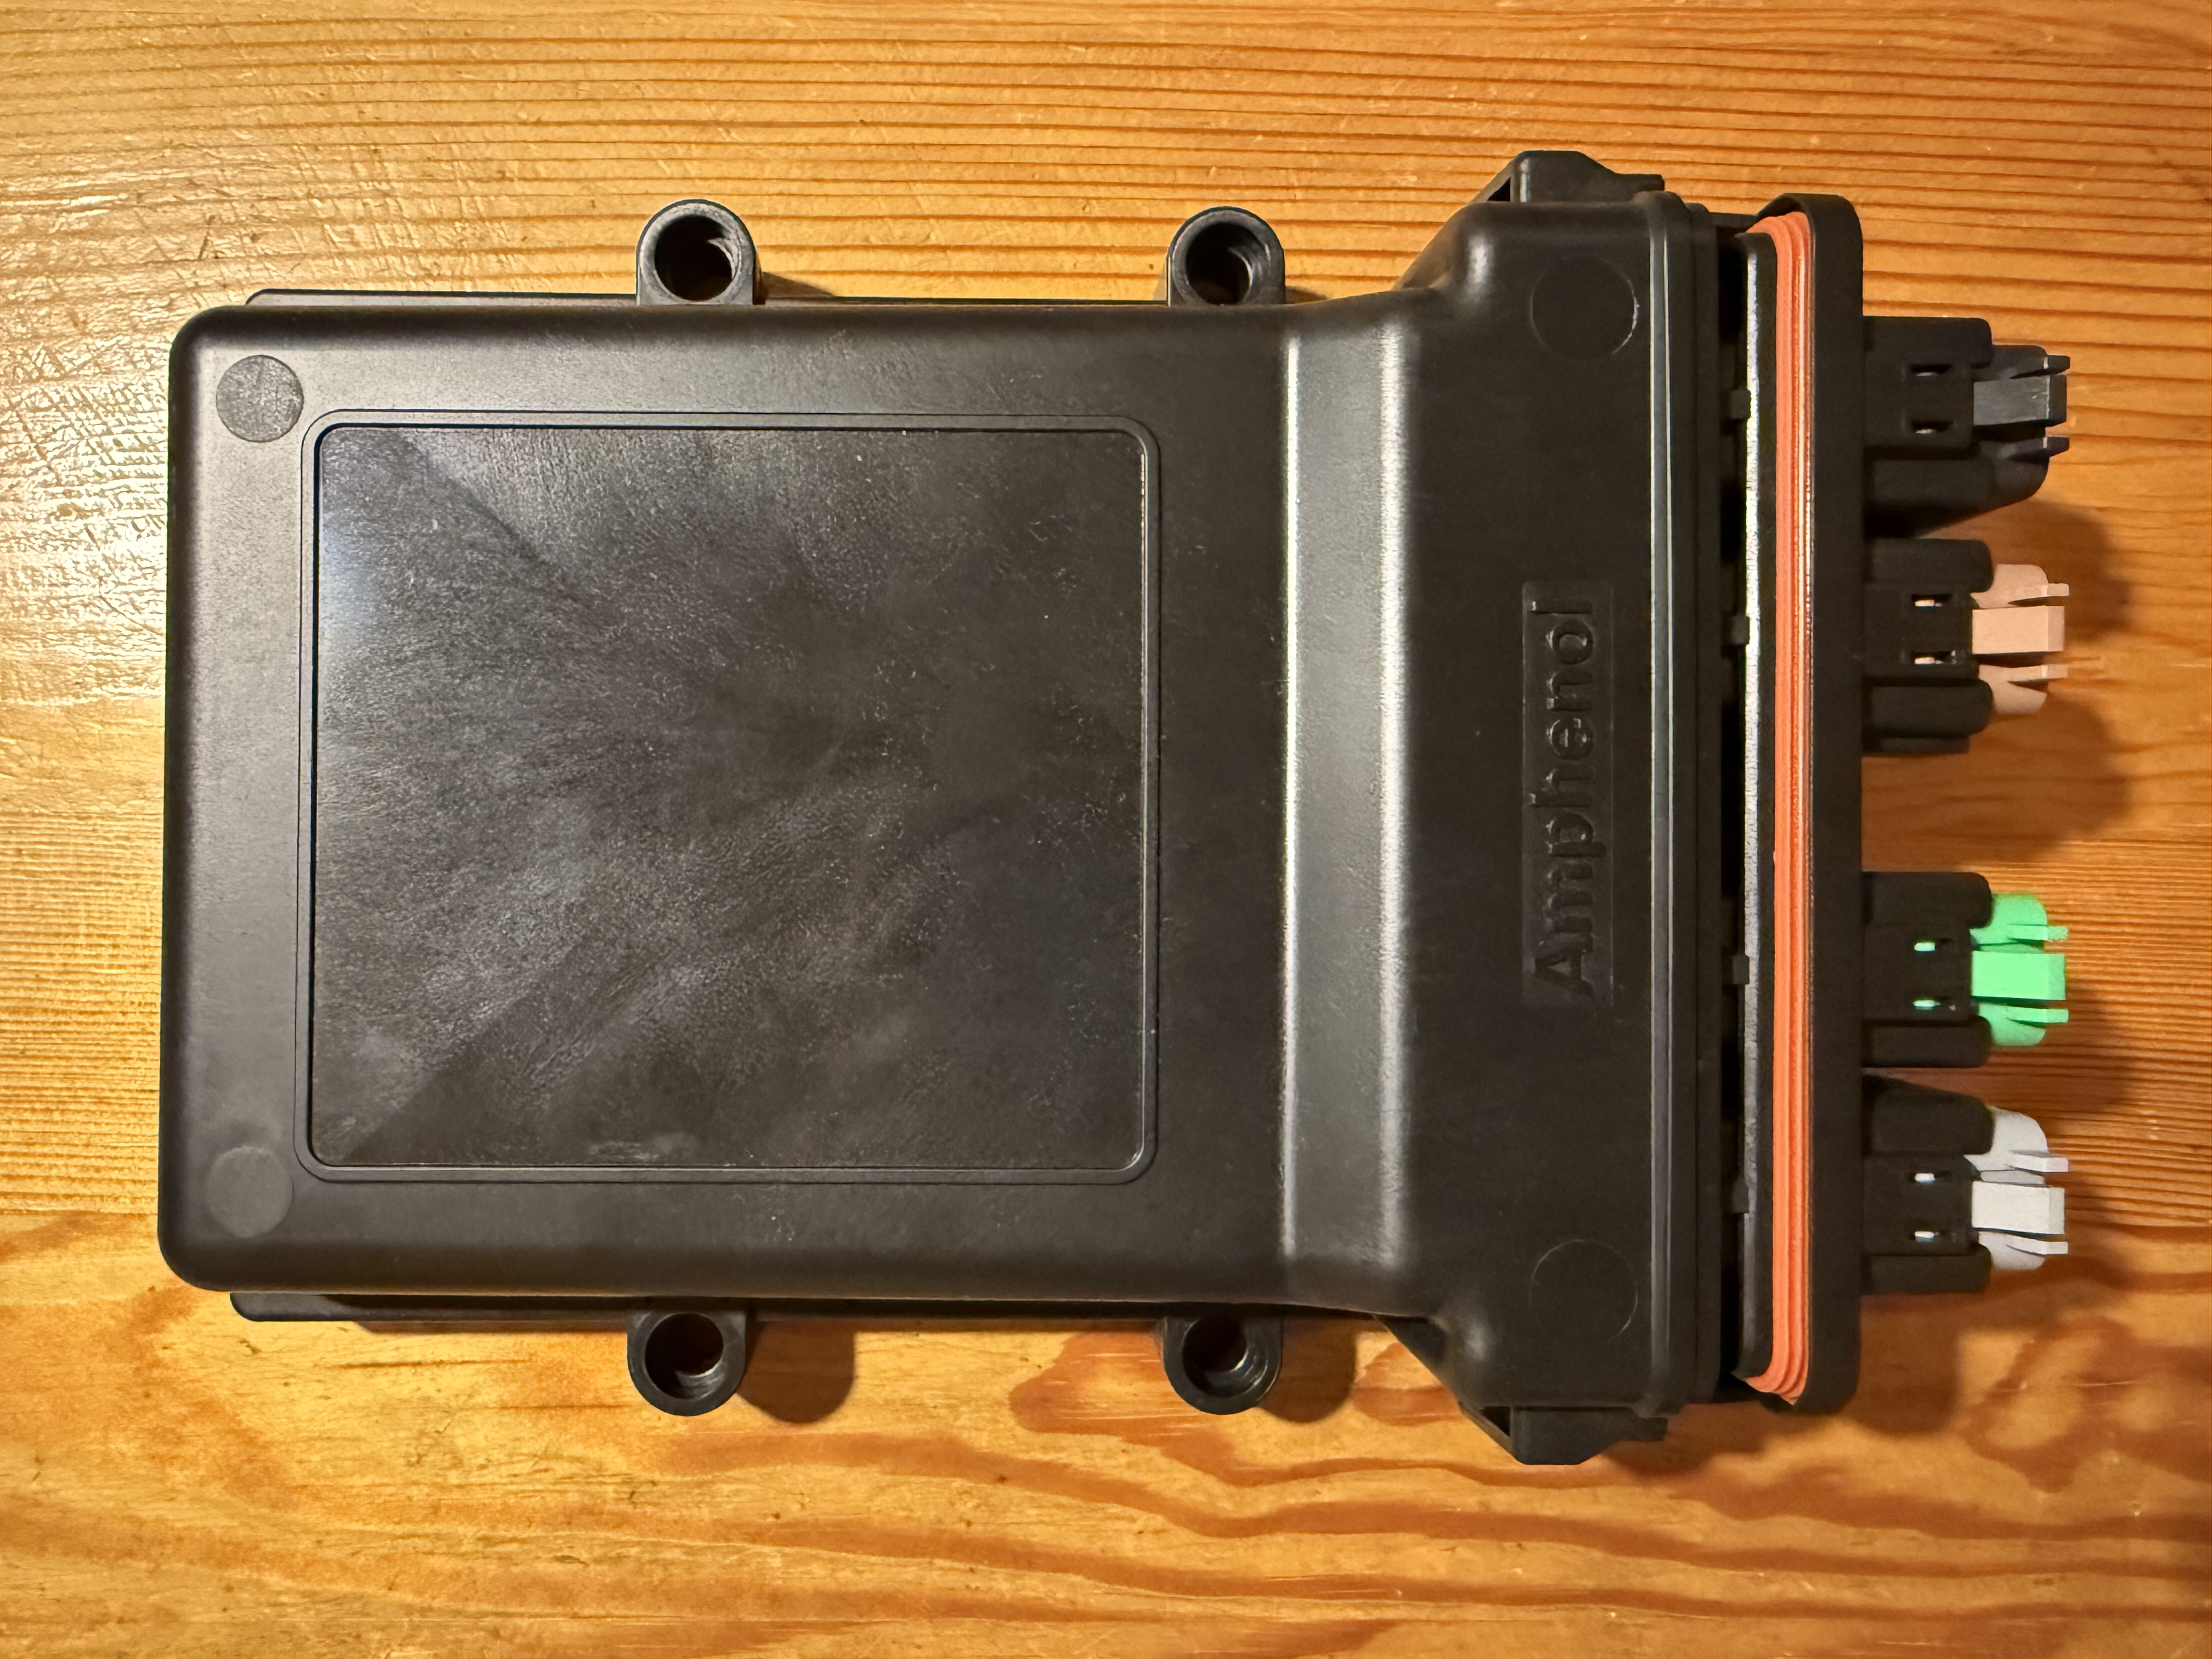
Whole controller packed in a cover with 4 connectors:
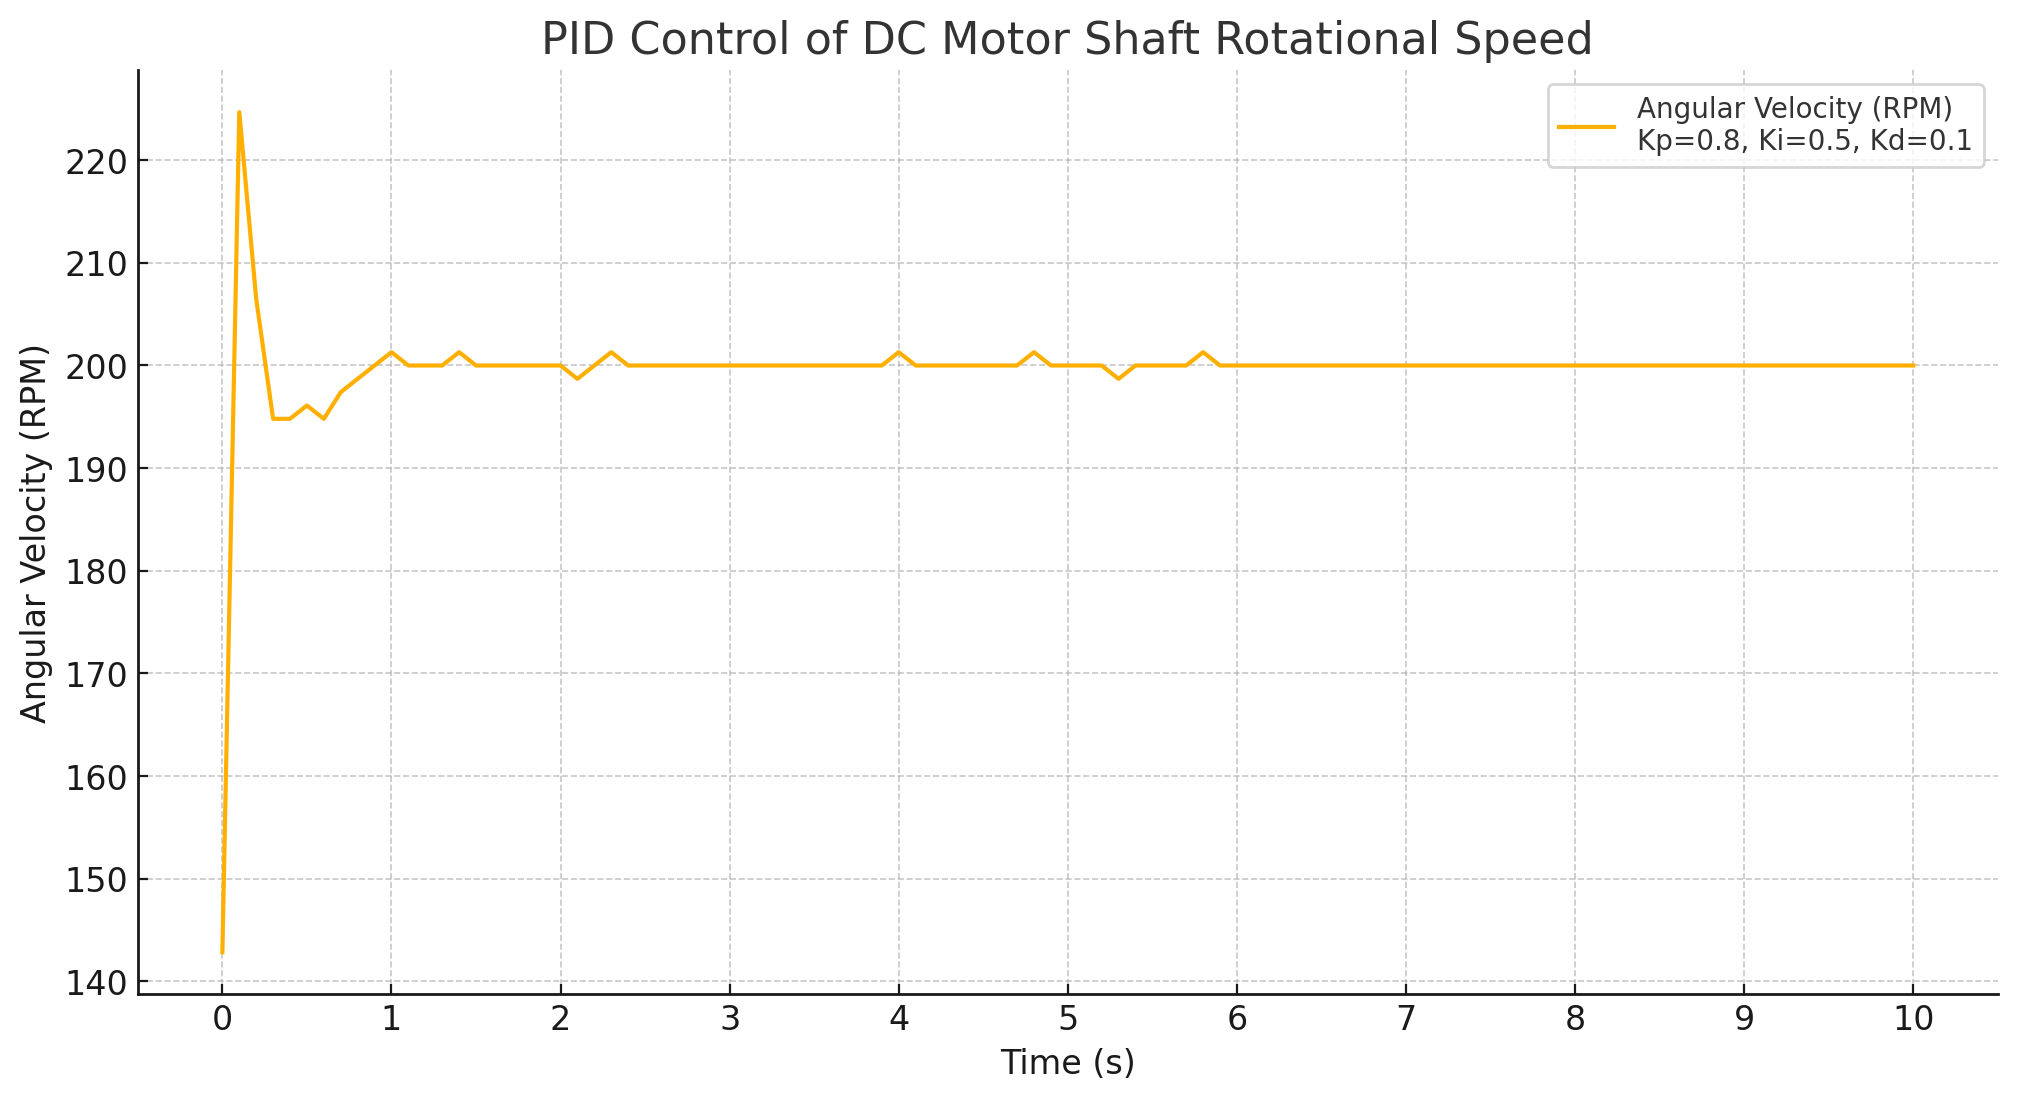 Example motor angular velocity step response (fs = 10Hz)
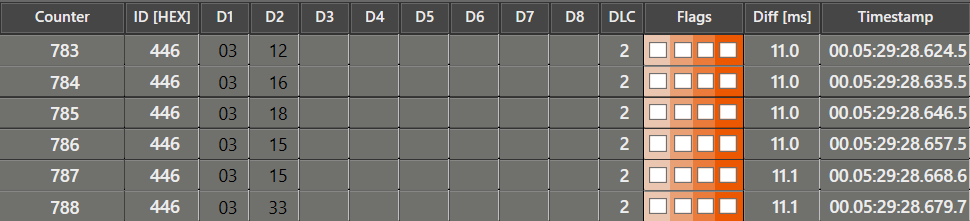 Sending analog reading of distance sensor via CAN bus
The following table includes example CAN IDs and their corresponding actions. These IDs are meant as examples and should be adjusted to fit the needs of the target hardware and system.
| ID | Function | Parameters | Message Type | Notes |
|---|---|---|---|---|
| 0x01 | Ping | None | Response | Sends a "ping" response |
| 0x02 | Turn LED ON | None | Request | Turns on the LED |
| 0x03 | Turn LED OFF | None | Request | Turns off the LED |
| 0x04 | Toggle LED state | None | Request | Toggles the LED state |
| 0x05 | Read distance sensor 1 | ADC channel | Request | Reads analog measurement from channel 6 |
| 0x06 | Read distance sensor 2 | ADC channel | Request | Reads analog measurement from channel 7 |
| 0x07 | Turn on/off switch 1 | 1 (ON), other (OFF) | Request | Controls power switch 1 |
| 0x08 | Turn on/off switch 2 | 1 (ON), other (OFF) | Request | Controls power switch 2 |
| 0x09 | Turn on/off switch 3 | 1 (ON), other (OFF) | Request | Controls power switch 3 |
| 0x10 | Turn on/off switch 4 | 1 (ON), other (OFF) | Request | Controls power switch 4 |
| 0x11 | Turn on/off switch 5 | 1 (ON), other (OFF) | Request | Controls power switch 5 |
| 0x12 | Turn on/off switch 6 | 1 (ON), other (OFF) | Request | Controls power switch 6 |
| 0x13 | Motor PID control | RPM, direction | Request | PID control for motor speed |
| 0x14 | Stop motor | None | Request | Stops the motor |
| 0x15 | Motor percent control | Percent, direction | Request | Controls motor using percentage duty cycle |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 18 | 4.7k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R30, R32, R48, R55, R57, R62, R65, R69, R71, R82, R83, R84, R86, R87, R88, R89 +2 |
| 7 | 1.5k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R50, R51, R64, R64, R76, R78, R79 |
| 7 | 4.7 nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C42, C43, C43, C44, C48, C49, C50 |
| 7 | 47k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R61, R63, R63, R66, R77, R80, R81 |
| 7 | Conn_01x06_Socket | Connector_PinSocket_2.54mm:PinSocket_2x03_P2.54mm_Vertical | J4, J6, J7, J8, J9, J10, J11 |
| 6 | 1.2k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R36, R58, R72, R85, R90, R93 |
| 6 | 100 nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C19, C40, C41, C45, C46, C47 |
| 6 | 100pF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C14, C21, C22, C24, C25, C27 |
| 6 | 10k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R22, R23, R24, R25, R31, R33 |
| 6 | 1k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R35, R59, R60, R73, R74, R75 |
| 6 | 270 | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R12, R13, R16, R17, R26, R27 |
| 6 | 36V | Diode_SMD:D_SOD-123 | D7, D18, D19, D20, D25, D26 |
| 6 | 4.7K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R28, R29, R34, R67, R68, R70 |
| 6 | 4.7V | Diode_SMD:D_SOD-123 | C25, D6, D8, D9, D10, D12 |
| 6 | BAS21 | Package_TO_SOT_SMD:SOT-23 | D21, D22, D23, D27, D28, D29 |
| 6 | BC807 | Package_TO_SOT_SMD:SOT-23-3 | Q2, Q3, Q4, Q5, Q6, Q7 |
| 6 | BTS5030-1EJA | Package_SO:Infineon_PG-DSO-8-43 | U15, U16, U17, U18, U19, U20 |
| 3 | LED | Diode_SMD:D_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D15, D16, D17 |
| 2 | 100 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R45, R47 |
| 2 | Conn_02x03_Odd_Even | Connector_PinSocket_2.54mm:PinSocket_2x03_P2.54mm_Vertical | J1, J2 |
| 2 | ~ | Package_DIP:DIP-16_W7.62mm | LTV2, LTV3 |
| 1 | 330 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R46 |
| 1 | Conn_01x04_Socket | Connector_PinSocket_2.54mm:PinSocket_2x02_P2.54mm_Vertical | J5 |
| 1 | Conn_01x12_Socket | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J3 |
| 1 | ~ | Connector_PinSocket_2.54mm:PinSocket_2x05_P2.54mm_Vertical | ST_LINK_V1 |
The 131 most common of 134 parts.
lologog/RowSeederController
This project is a row seeder controller featuring DC motor control and CAN communication for efficient and precise seeding operations

doppelhub/MuddersMIMA
Mudders Take on Manual IMA Control in the G1 Honda Insight


PySpice-org/eda-rw
Python library to read/write KiCad and LibrePCB Sexpr file format

filmolino/SlideScanner
The Filmolino SlideScanner is a device that makes it easy to scan slides in magazines fully automated using a modified slide projector and a digital camera.


MattisLind/teleprinterHat
A RaspberryPi HAT that interfaces a old school teleprinter

BILLEE-BroncoSTAR/billee-hardware-2027
Hardware and firmware Repository for BILLEE URC 2027

cl0rm/ElectroLumino
Portable Mulit-Channel programmable EL wire driver featuring PWM
It measures 109.1 × 100.1 mm and has 2 copper layers, 1.6 mm thick.
134 parts, built around the BTS5030-1EJA, BAS21 and BC807. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the lologog/RowSeederController repository on GitHub, at the commit this page was made from: the board is PCBs/ExtensionBoard/Sterownik-DC.kicad_pcb and its schematic PCBs/ExtensionBoard/Sterownik-DC.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).