
2 layers44.5 × 50.8 mm

 kyleRhess/DroneFluxx2
ARM-based custom flight controller firmware + hardware.
DroneFluxx is an open-source printed circuit board by kyleRhess, from the kyleRhess/DroneFluxx repository on GitHub. It is a 4-layer board of 45 × 45 mm with 58 parts on 78 nets, routed with 398 tracks and 104 vias.
It is built around the CAM-M8C-0, BMP388 and LIS3MDL, with the LP2985-33DBV and LSM6DSM among its other parts. Its parts include 16 capacitors, 6 resistors, 6 ICs, 5 connectors and 4 diodes. It belongs with the STM32 boards of this library.


The current firmware version is tailored for an STM32F4 microcontroller. This means that it is best-suited for the related hardware, and much of this firmware is very proprietary.
However, the lightweight PID module built for this project could be useful in other applications.
Flight controller hardware is still in work, but has been made public for those who are interested.
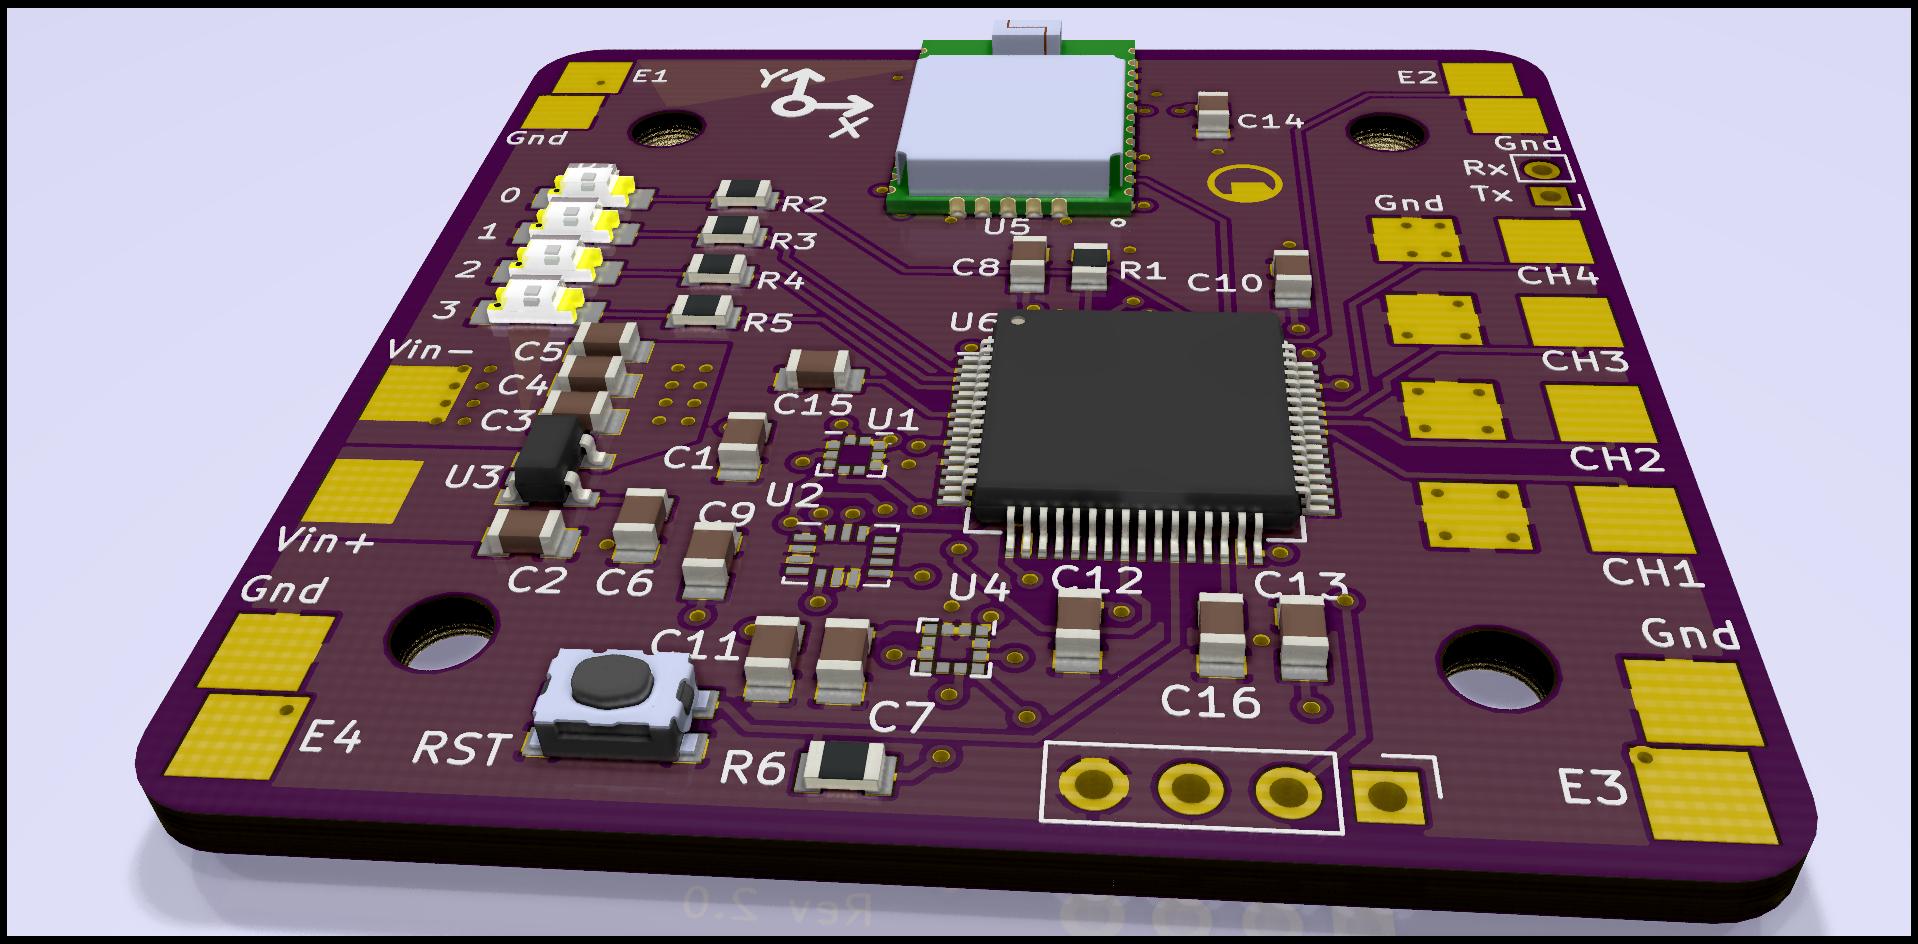
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | Conn_01x01_Female | Measurement_Points:Measurement_Point_Square-SMD-Pad_Big | CH1, CH2, CH3, CH4, E1, E2, E3, E4, Gnd, Gnd, Gnd, Gnd, Gnd |
| 9 | 0.1uF | Capacitor_SMD:C_0805_2012Metric | C1, C4, C7, C8, C10, C11, C12, C13, C15 |
| 4 | 470 | Resistor_SMD:R_0805_2012Metric | R2, R3, R4, R5 |
| 4 | LED | LED_SMD:LED_1206_3216Metric | D1, D2, D3, D4 |
| 3 | Conn_01x01_Female | TestPoint:TestPoint_Pad_3.0x3.0mm | J20, J21, J22 |
| 2 | 10k | Resistor_SMD:R_0805_2012Metric | R1, R6 |
| 2 | 10nF | Capacitor_SMD:C_0805_2012Metric | C5, C6 |
| 2 | 1uF | Capacitor_SMD:C_0805_2012Metric | C2, C9 |
| 2 | 2.2uF | Capacitor_SMD:C_0805_2012Metric | C3, C16 |
| 1 | 4.7uF | Capacitor_SMD:C_0805_2012Metric | C14 |
| 1 | BMP388 | kyleRhess_packages:LGA-10_2x2mm_Pitch0.5mm | U1 |
| 1 | CAM-M8C-0 | kyleRhess_packages:31-SMD_Module | U5 |
| 1 | Conn_01x02_Female | Connector_PinSocket_2.00mm:PinSocket_1x02_P2.00mm_Vertical | J2 |
| 1 | Conn_01x04_Male | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | LIS3MDL | Package_LGA:LGA-12_2x2mm_P0.5mm | U4 |
| 1 | LOGO | kyleRhess_logos:logo_blackmesa | G*** |
| 1 | LOGO | kyleRhess_logos:logo_foxhound | G*** |
| 1 | LOGO | kyleRhess_logos:logo_foxflight | G*** |
| 1 | LP2985-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U3 |
| 1 | LSM6DSM | Package_LGA:Bosch_LGA-14_3x2.5mm_P0.5mm | U2 |
| 1 | STM32F410RBTx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U6 |
| 1 | SW_Push | Buttons_Switches_SMD:SW_SPST_KMR2 | RST |
The 54 most common of 58 parts.

hasenbanck/exa_tim
EXA_tim is a wrist watch PCB with GNSS time synchronization and e-paper display

Rain-604/PERRII---Aerospace-Flight-Computer-version-2
PERRII - a modular aerospace flight computer designed for environmental sensing and long-range data telemetry

Rain-604/PERRII---Aerospace-Flight-Computer
PERRII - a modular aerospace flight computer designed for environmental sensing and long-range data telemetry

rland93/ollyfc
A small rust-embedded flight computer. RTIC, FrSky protocols, and STM32F4 hardware.

bastocon/sparse-pose-benchmark
Bachelor Thesis Paper: Sparse Pose Estimation data collection, evaluation backend, frontend, as well as all resources for the creation of the Hidden Dataset using commodity sensors.


nikphillydev/NP1_DRONE
Building a quadcopter from scratch. Hardware and software. Developed using STM32 microcontroller and FreeRTOS.
It measures 45 × 45 mm and has 4 copper layers, 1.6 mm thick.
58 parts, built around the CAM-M8C-0, BMP388, LIS3MDL and LP2985-33DBV. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the kyleRhess/DroneFluxx repository on GitHub, at the commit this page was made from: the board is Hardware/DroneFluxx.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask kyleRhess before reusing the design.