2 layers
Barry FL
Rain-604/PERRII---Aerospace-Flight-Computer
PERRII - a modular aerospace flight computer designed for environmental sensing and long-range data telemetry
41 parts

 Rain-604/PERRII---Aerospace-Flight-Computer-version-21
PERRII - a modular aerospace flight computer designed for environmental sensing and long-range data telemetry
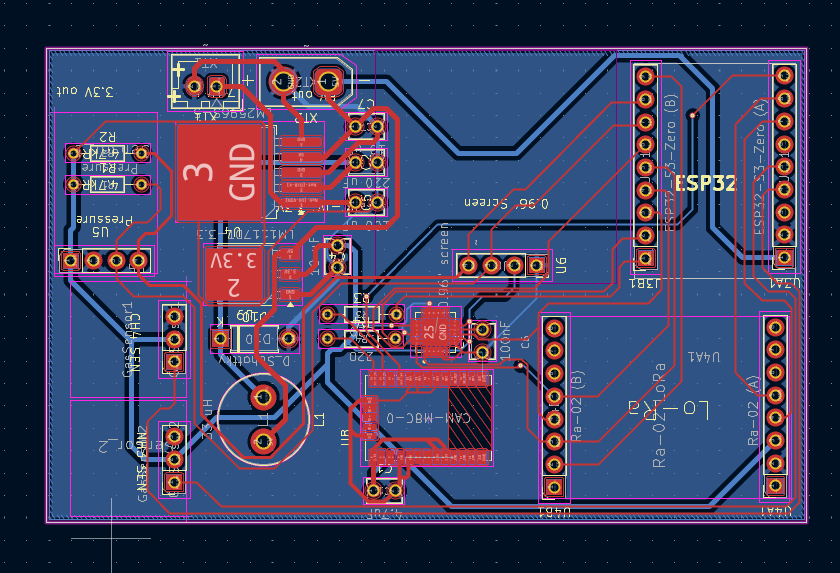
Flight computer is an open-source printed circuit board by Rain-604, from the Rain-604/PERRII---Aerospace-Flight-Computer-version-2 repository on GitHub. It is a 2-layer board of 53 × 85 mm with 30 parts on 48 nets, routed with 390 tracks and 8 vias.
It is built around the CAM-M8C-0, LM2596S-5.0 and LM1117DT-3.3. Its parts include 11 ICs, 6 capacitors, 4 resistors, 3 switches and 1 diode. It belongs with the ESP32 boards of this library.


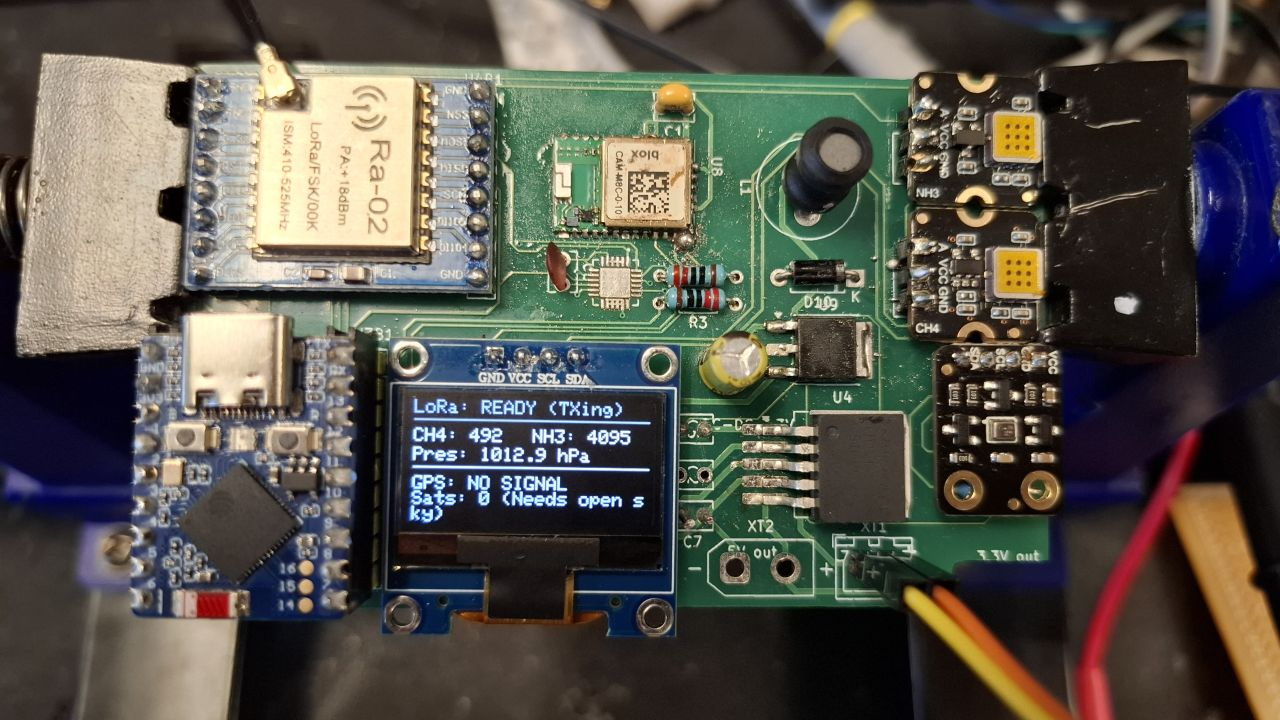
PERRII is a modular aerospace flight computer designed for environmental sensing and long-range data telemetry. The system is built around the ESP32-S3 Zero microcontroller and is designed to function as a scientific payload for high-altitude ballooning or atmospheric research. It integrates precision GNSS positioning, environmental gas sensing (Methane and Ammonia), and a robust power regulation system.
As the lead for the communication system, I was responsible for the hardware integration and signal integrity of the long-range telemetry link.
While my primary focus was the communication link, I worked closely with the team to integrate the following subsystems:
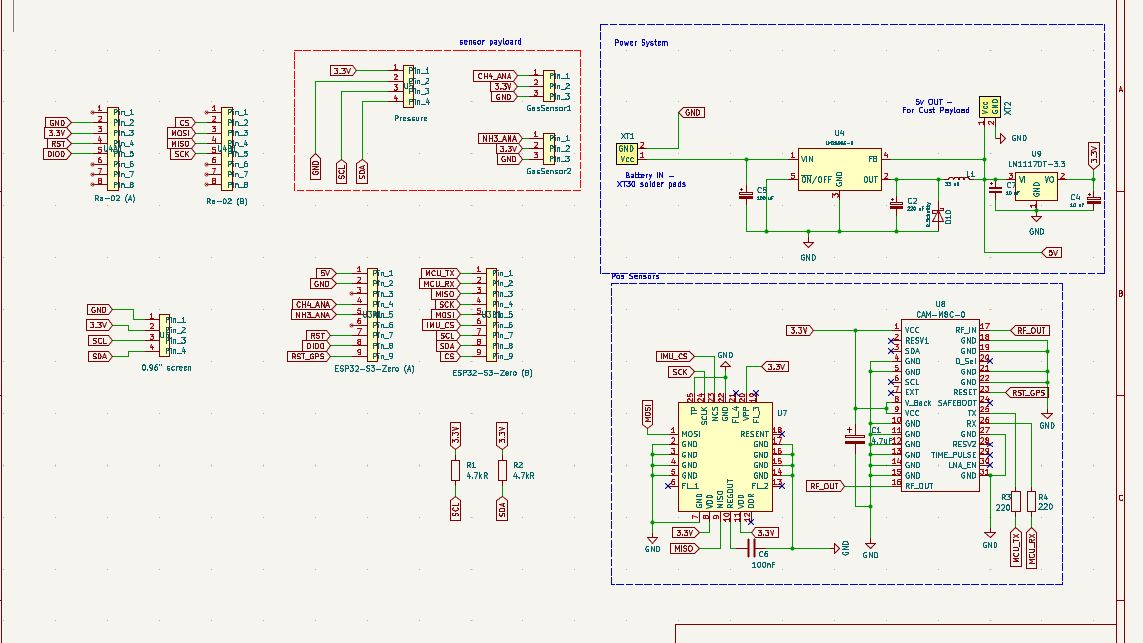
The schematic follows a modular design separated into Power, TX, Sensor, and GPS blocks.
A circular 2-layer board designed for cylindrical aerospace housing.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 10 uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C4, C7 |
| 2 | 220 | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R3, R4 |
| 2 | 4.7kR | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R1, R2 |
| 1 | 0.96" screen | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | U6 |
| 1 | 100 uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C5 |
| 1 | 100nF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C6 |
| 1 | 220 uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C2 |
| 1 | 33 uH | Inductor_THT:L_Radial_D10.0mm_P5.00mm_Fastron_07P | L1 |
| 1 | 4.7uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C1 |
| 1 | CAM-M8C-0 | Custom_Avionics:MODULE_CAM-M8C-0 | U8 |
| 1 | D_Schottky | Diode_THT:D_A-405_P7.62mm_Horizontal | D10 |
| 1 | ESP32-S3-Zero (A) | Connector_PinSocket_2.54mm:PinSocket_1x09_P2.54mm_Vertical | U3A1 |
| 1 | ESP32-S3-Zero (B) | Connector_PinSocket_2.54mm:PinSocket_1x09_P2.54mm_Vertical | U3B1 |
| 1 | GasSensor1 | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | GasSensor1 |
| 1 | GasSensor2 | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | GasSensor2 |
| 1 | LM1117DT-3.3 | Package_TO_SOT_SMD:TO-252-3_TabPin2 | U9 |
| 1 | LM2596S-5 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U4 |
| 1 | Pressure | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | U5 |
| 1 | Ra-02 (A) | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | U4A1 |
| 1 | Ra-02 (B) | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | U4B1 |
| 1 | Ra-02 LoRa | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | U4A1 |
| 1 | Sensor_1 | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | S1 |
| 1 | Sensor_2 | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | S2 |
| 1 | Sensor_3 | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | S3 |
| 1 | ~ | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | XT1 |
| 1 | ~ | IIM-20670:QFN50P450X450X115-25N | U7 |
| 1 | ~ | Connector_AMASS:AMASS_XT30UPB-F_1x02_P5.0mm_Vertical | XT2 |
Rain-604/PERRII---Aerospace-Flight-Computer
PERRII - a modular aerospace flight computer designed for environmental sensing and long-range data telemetry


hasenbanck/exa_tim
EXA_tim is a wrist watch PCB with GNSS time synchronization and e-paper display


Deni90/singleDigitNixieClock
A small project that combines ESP32 with a vintage Soviet Nixie tube from the 70’ to create an artistic clock. Originally developed on ESP8266/Arduino, now evolved to ESP32 with ESP-IDF for greater performance and…

K0nradG/self-balancing-robot
Self-balancing robot powered by nRF52840 and Zephyr RTOS, with BLE control, OTA updates, and a Raspberry Pi camera interface designed for future autonomous navigation.

VictorRavani/Irrigation_IoT
This project covers the complete development of Hardware and Firmware for IoT-based supervisory control. It offers all the necessary information and resources so that anyone can set up the system independently.
It measures 53 × 85 mm and has 2 copper layers, 1.6 mm thick.
30 parts, built around the CAM-M8C-0, LM2596S-5.0 and LM1117DT-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Rain-604/PERRII---Aerospace-Flight-Computer-version-2 repository on GitHub, at the commit this page was made from: the board is flight_computer.kicad_pcb and its schematic flight_computer.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Rain-604 before reusing the design.