2 layers52.5 × 62.6 mm
 h0lad/MiniSpeedController7
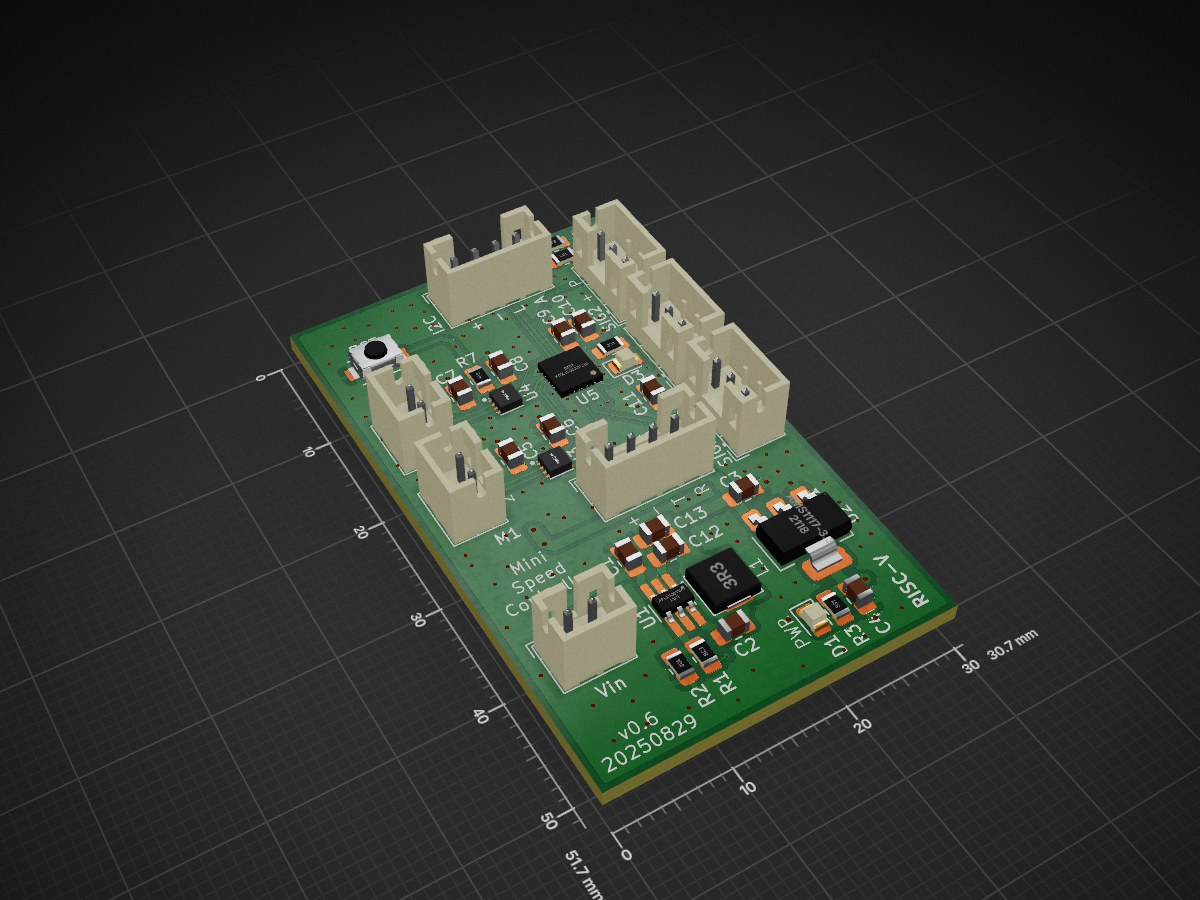
MiniSpeedController is a dual DC motor controller based on a WCH CH32V003F RISC-V Microcontroller and two TI DRV8837DSGR. It consumes two encoder inputs and is controllable using an USART via simple TLV commands. Sensors can be attached using I2C.
SmallSpeedController is an open-source printed circuit board by h0lad, from the h0lad/MiniSpeedController repository on GitHub, published under the CERN-OHL-S-2.0 licence. It is a 4-layer board of 30.7 × 51.7 mm with 37 parts on 32 nets, routed with 213 tracks and 195 vias.
It is built around the DRV8837DSGR-MS, AP62300TWU and AMS1117-3.3, with the TS-1088-AR02016 among its other parts. Its parts include 13 capacitors, 8 connectors, 7 resistors, 5 ICs and 2 diodes. It belongs with the robots and motor control boards and the RISC-V boards of this library.


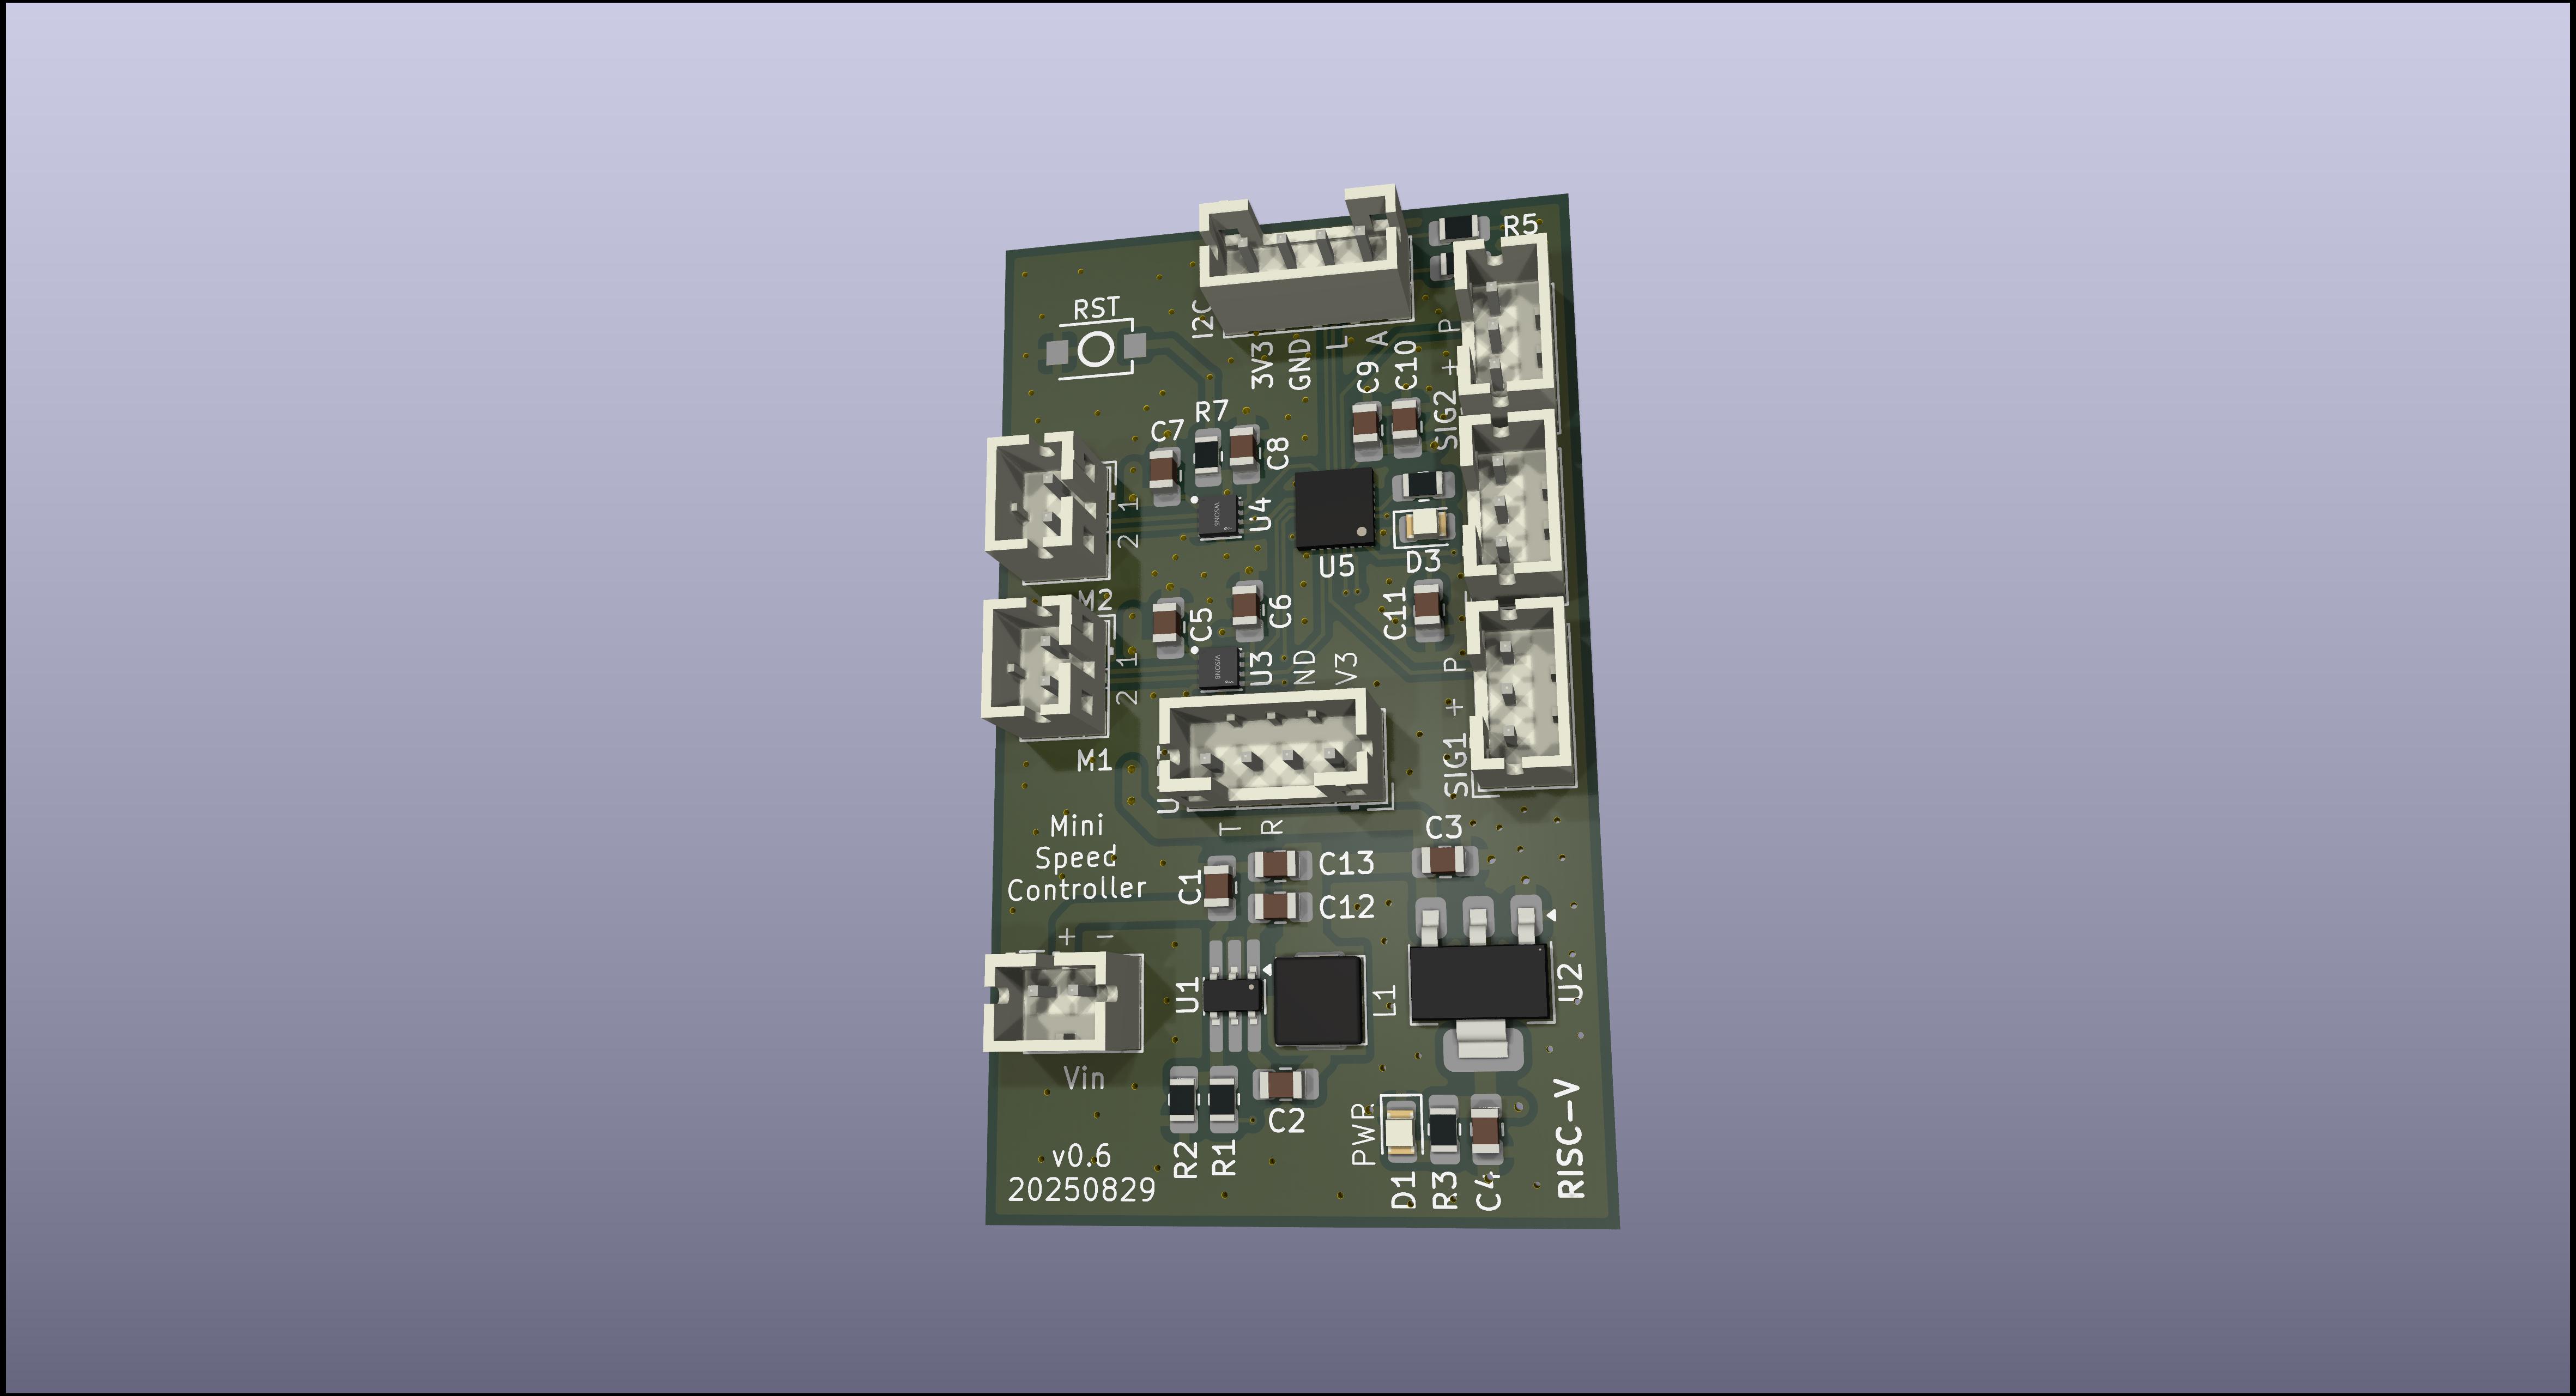
This project implements a compact DC motor speed controller using a RISC-V microcontroller.
It is designed for speed control via pulse feedback from a light barrier and communicates through a serial interface. Additional sensors can be attached using I2C.
Beware that the entire PCB isn't a masterpiece as this is just for technology evaluation.
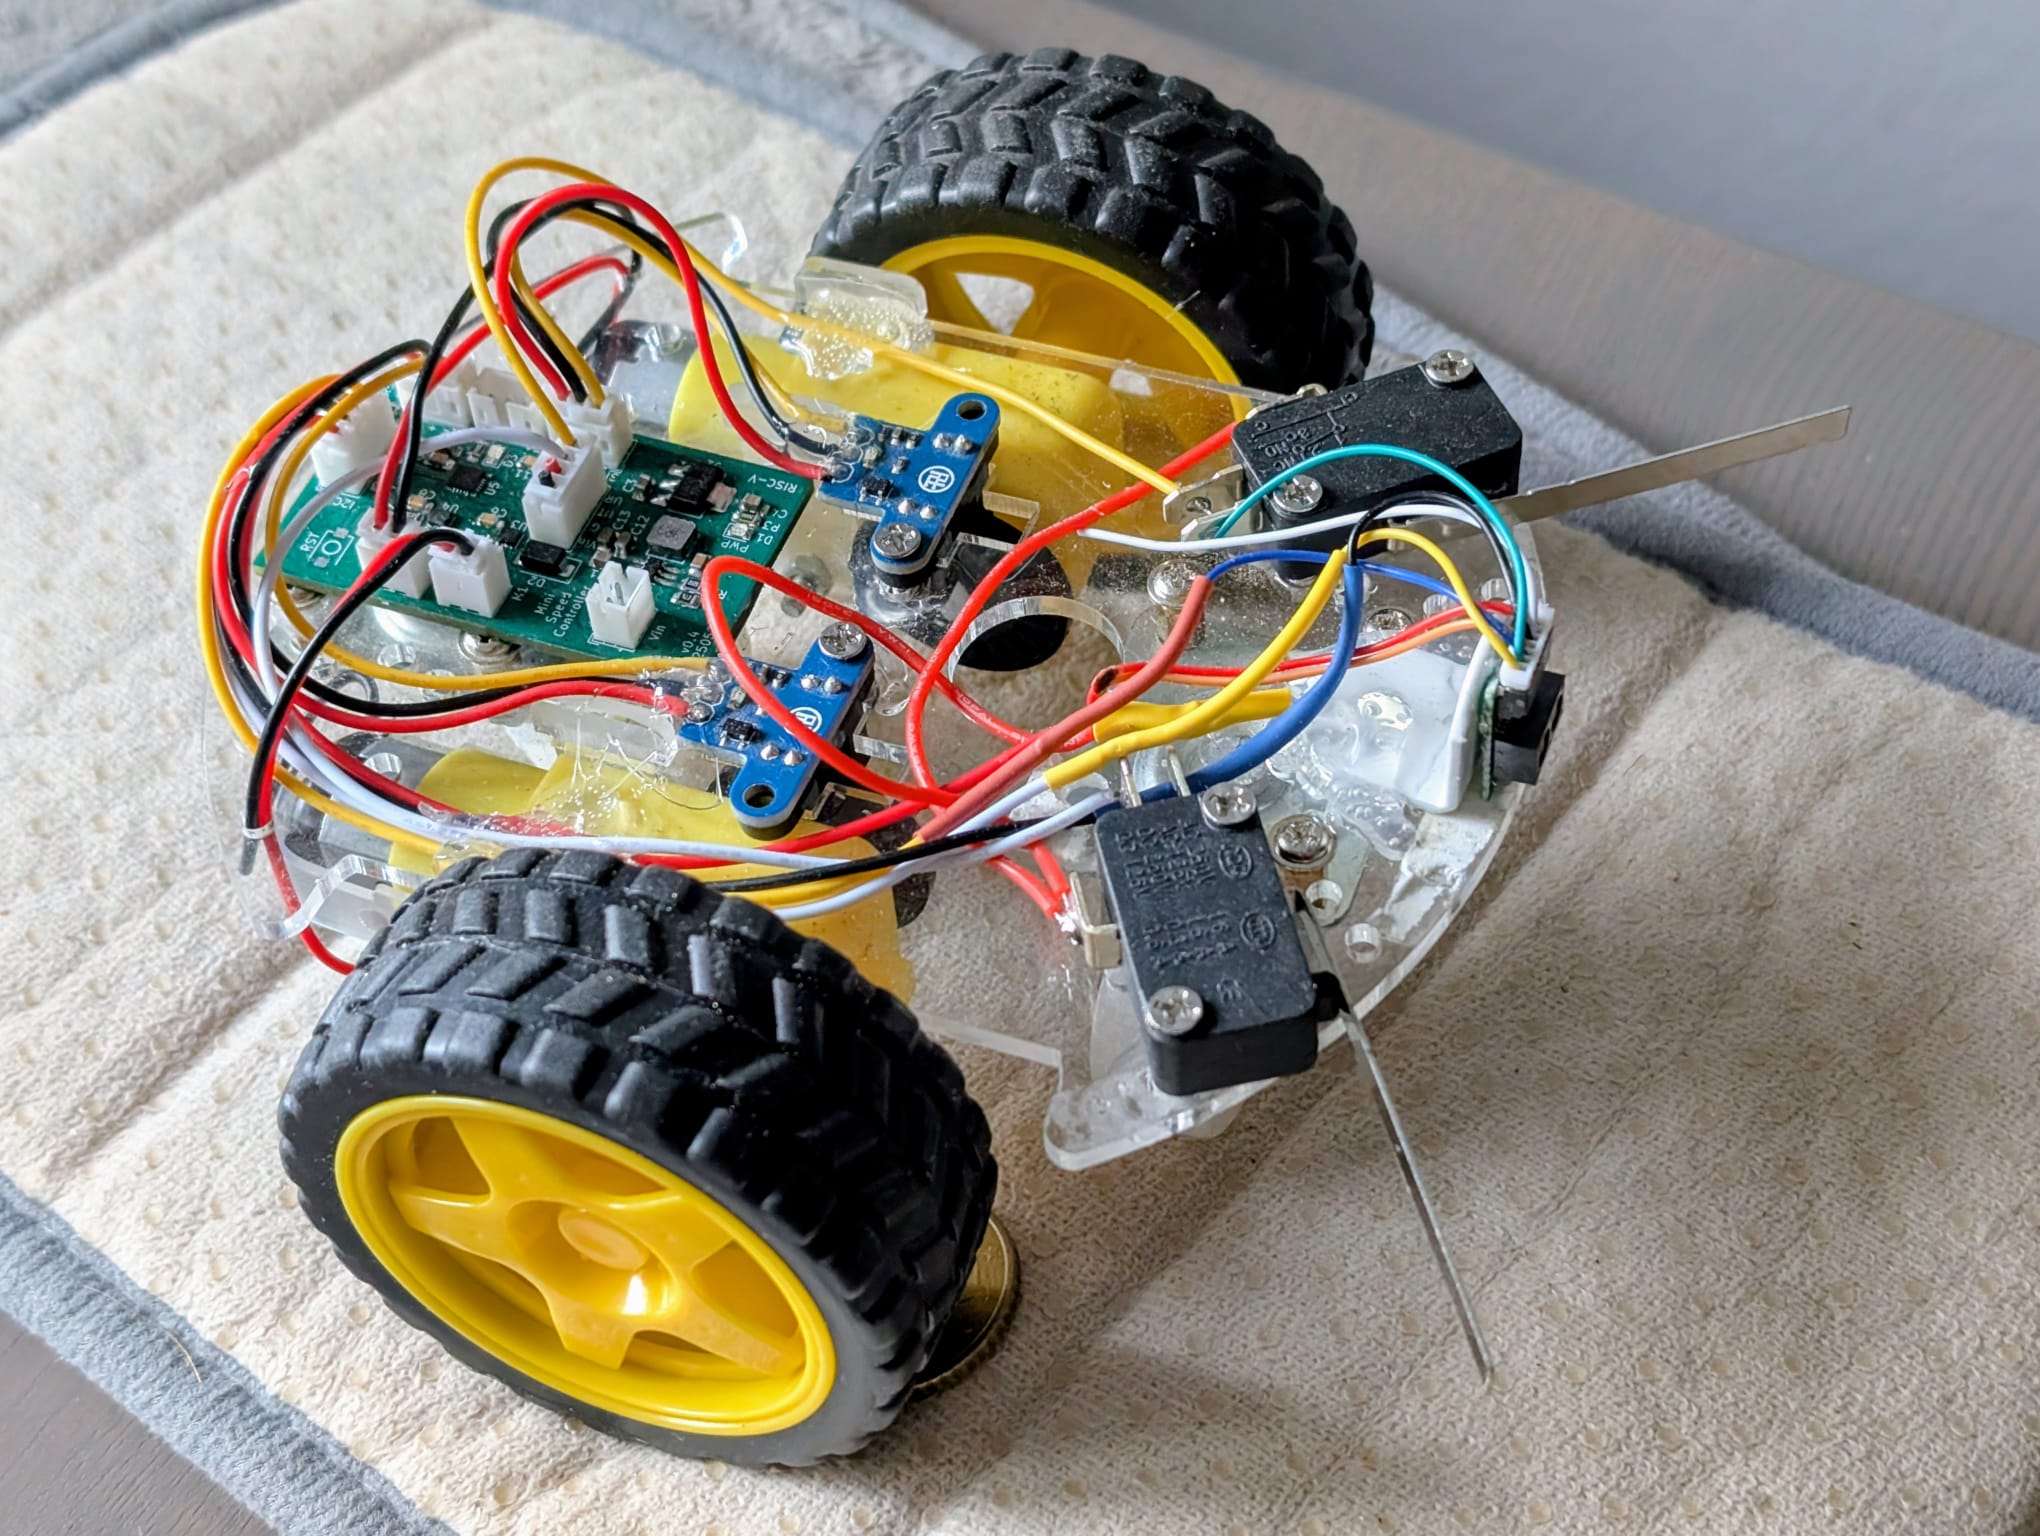
Mostly for playing around with very cheap RISC-V microcontrollers and an execise for C/Rust with very limited resources. It can be used for controlling simple toy robot chassis that usually have two DC motors with light barriers which can be used as feedback loop for a speed control algorithm.
| Pin | Meaning |
|---|---|
| PC5 | motcon1_sleep |
| PC6 | motcon1_in2 |
| PD2 | motcon1_pwm_in1 |
| Pin | Meaning |
|---|---|
| PC3 | motcon2_sleep |
| PC4 | motcon2_in2 |
| PA1 | motcon2_pwm_in1 |
| Pin | Meaning |
|---|---|
| PC0 | pwm_speed_input1 |
| PD3 | pwm_speed_input2 |
| Pin | Meaning |
|---|---|
| PC1 | i2c_sda |
| PC2 | i2c_scl |
| PD5 | usart_tx |
| PD6 | usart_rx |
| Pin | Meaning |
|---|---|
| PD1 | SWDIO |
| PD7 | nRST |
| Pin | Meaning |
|---|---|
| PA2 | status_led |
| Pin | Meaning |
|---|---|
| PC7 | X |
| PD0 | X |
| PD4 | X |
CERN OHL v2 – Strongly Reciprocal (S)
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5, C6, C7, C8, C9, C11 |
| 4 | 10k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R4, R5, R7 |
| 4 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C3, C4, C10 |
| 3 | Conn_01x02_Socket | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J1, J2, J4 |
| 3 | Conn_01x03_Socket | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J9, J10, J11 |
| 2 | 22uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C12, C13 |
| 2 | 330 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3, R6 |
| 2 | Conn_01x04_Socket | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J5, J6 |
| 2 | DRV8837DSGR | libs:WSON-8_L2.0-W2.0-P0.50-TL-EP | U3, U4 |
| 2 | LED | LED_SMD:LED_0805_2012Metric | D1, D3 |
| 1 | 220nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2 |
| 1 | 3.3uH | libs:CPX0420 | L1 |
| 1 | 82k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U2 |
| 1 | AP62300TWU | Package_TO_SOT_SMD:TSOT-23-6_HandSoldering | U1 |
| 1 | CH32V003FxUx | Package_DFN_QFN:QFN-20-1EP_3x3mm_P0.4mm_EP1.65x1.65mm | U5 |
| 1 | TS-1088-AR02016 | libs:SW-SMD_L3.9-W3.0-P4.45 | SW2 |
It measures 30.7 × 51.7 mm and has 4 copper layers, 1.6 mm thick.
37 parts, built around the DRV8837DSGR-MS, AP62300TWU, AMS1117-3.3 and TS-1088-AR02016. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the h0lad/MiniSpeedController repository on GitHub, at the commit this page was made from: the board is pcb/SmallSpeedController.kicad_pcb and its schematic pcb/SmallSpeedController.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-S-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

McMaster-Rocketry-Team/VLF4r2
PCB schematics and layout for Void Lake Fusion 4 Avionics


chilly23/PCBGolf-master-Comma.ai
Compact PCB studies for the comma.ai PCBGolf challenge, including KiCad and EasyEDA designs, BOMs, STEP models, and routing-status reports.


kevleep/Project-Roll
Project Roll Project Roll is a spherical robot that achieves omni-directional movement using omni-wheels and a hamster ball drive mechanism.