2 layers65 × 56 mm
RasPi4-UART RS485
noriakinakagawa/RasPi4-UART-RS485
Raspberry Pi 4 のUART 5chをRS485に変換したコマンド式サーボモータを動かすための基板データ
49 parts3
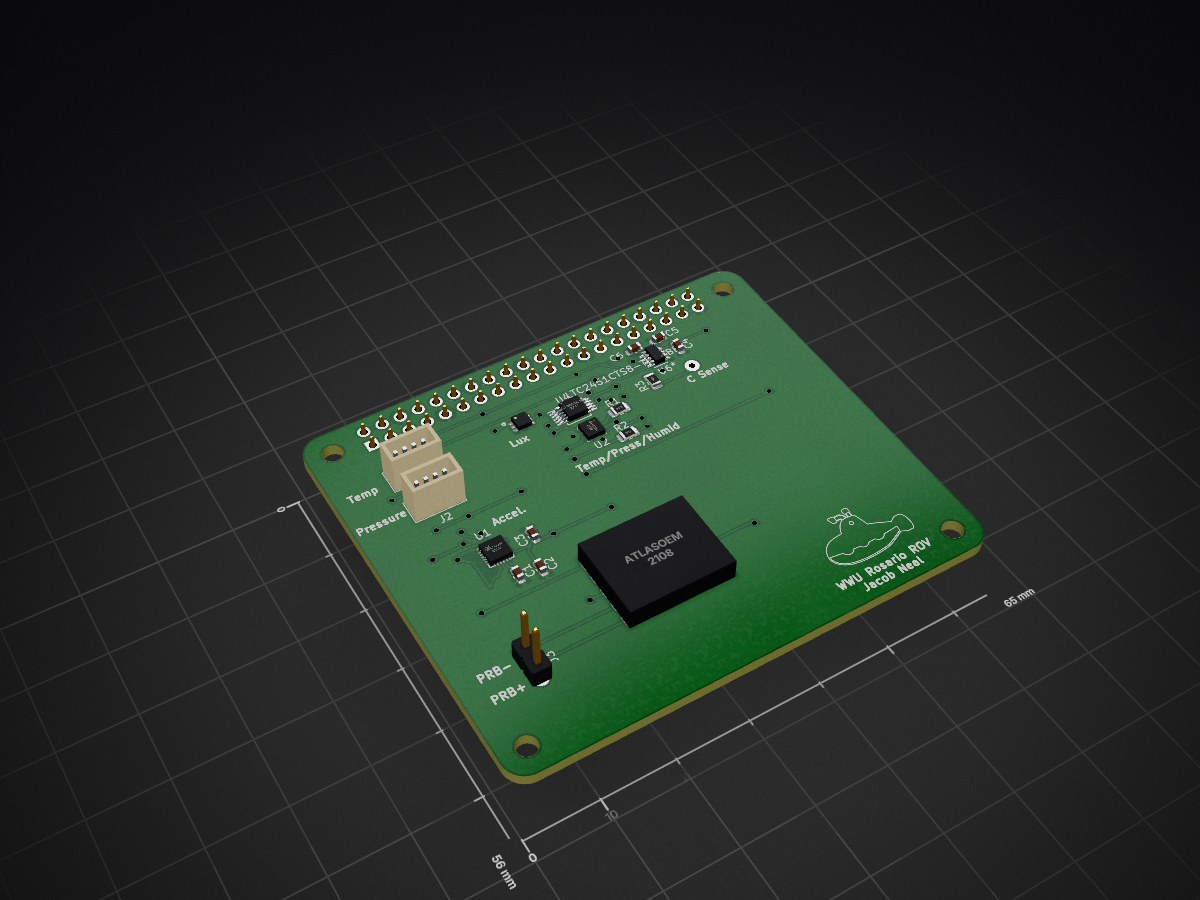
 dakriy/Rosario-ROV3
This project is to create a working ROV with features such as live video for the WWU Rosario Beach Marine Laboratory.
ROVPCB is an open-source printed circuit board by dakriy, from the dakriy/Rosario-ROV repository on GitHub, published under the MIT licence. It is a 2-layer board of 65 × 56 mm with 24 parts on 48 nets, routed with 227 tracks and 42 vias.
It is built around the BME280, MPU-9250 and M2.5. Its parts include 6 capacitors, 6 ICs, 5 connectors and 3 resistors.


This project is to create a working ROV with features such as live video for the WWU Rosario Beach Marine Laboratory.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C5, C6 |
| 4 | M2.5 | MountingHole:MountingHole_2.7mm_M2.5 | MK1, MK2, MK3, MK4 |
| 2 | 3k | Resistor_SMD:R_0805_2012Metric | R1, R2 |
| 2 | Conn_01x04_Male | Connector_Hirose:Hirose_DF13-04P-1.25DSA_1x04_P1.25mm_Vertical | J1, J2 |
| 1 | 10uF | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | 1k | Resistor_SMD:R_0805_2012Metric | R3 |
| 1 | AtlasOEM | Adafruit TSL2591:OEM Board | U5 |
| 1 | BME280 | Package_LGA:Bosch_LGA-8_2.5x2.5mm_P0.65mm_ClockwisePinNumbering | U2 |
| 1 | Conn_01x01_Male | Connector_Wire:SolderWirePad_1x01_Drill0.8mm | J4 |
| 1 | Conn_01x02_Male | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill0.8mm | J3 |
| 1 | Conn_02x20_Odd_Even | Connector_PinSocket_2.54mm:PinSocket_2x20_P2.54mm_Vertical | P1 |
| 1 | LIGHT_TSL2591 | Adafruit TSL2591:DFN6_TAOS | U3 |
| 1 | LTC2451CTS8-TRMPBF | footprints:LTC2451CTS8-TRMPBF | U6 |
| 1 | LTC4316IDDPBF | Package_SO:MSOP-10_3x3mm_P0.5mm | U4 |
| 1 | MPU-9250 | Sensor_Motion:InvenSense_QFN-24_3x3mm_P0.4mm | U1 |
noriakinakagawa/RasPi4-UART-RS485
Raspberry Pi 4 のUART 5chをRS485に変換したコマンド式サーボモータを動かすための基板データ

crnicholson/StratoSoar-MK2
StratoSoar is an engineering project that aims to be able to fly a glider (dropped from a high-altitude balloon), down to any selected coordinates.


ApoapsisHGV/CanSat2019-electronics
Circuit and PCB design files related to our 2019 CanSat competition


jonasbjurel/open_telemetry_HW
The OFT001v1 card has an L80-M39 GPS with a built-in patch antenna, and an optional connector for an external 50 Ohm active antenna; an MP-9250 3D axis for each of: Accelerometer, Gyroscope and Magnetometer; and a…

It measures 65 × 56 mm and has 2 copper layers, 1.6 mm thick.
24 parts, built around the BME280, MPU-9250 and M2.5. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the dakriy/Rosario-ROV repository on GitHub, at the commit this page was made from: the board is PCB/ROVPCB/ROVPCB.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).