4 layers80 × 100 mm
TempCtrl
charlesbaynham/DigitalTemperatureController
Schematic, PCB and source code for a high-precision digital temperature controller
186 parts14
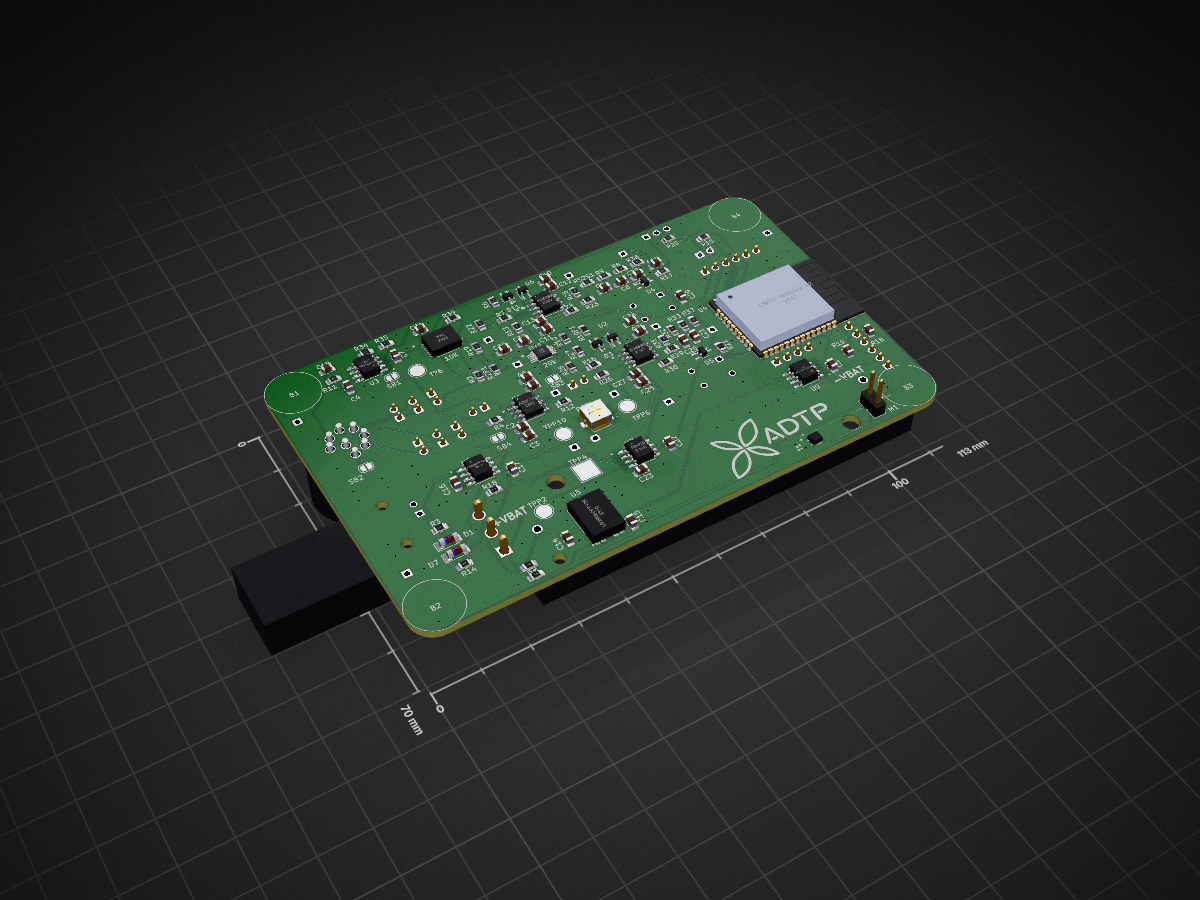
 benoitGIRAUD/NGL_PROTO_ST
Proto sous tarité en // du PCB usiné
NGL PROTO ST is an open-source printed circuit board by benoitGIRAUD, from the benoitGIRAUD/NGL_PROTO_ST repository on GitHub. It is a 2-layer board of 113 × 70 mm with 145 parts on 101 nets, routed with 922 tracks and 171 vias.
It is built around the ESP32-WROOM-32D-N16, AD8639AR and LD29080PT33R, with the MAX1680ESA+T, LL4148 and 1101M2S3CQE2 among its other parts. Its parts include 43 resistors, 32 capacitors, 11 ICs, 9 diodes and 6 connectors. It belongs with the ESP32 boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2, C4, C6, C7, C12, C13, C14, C19, C22, C23, C26, C27, C31, C32 |
| 11 | 10K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R8, R9, R11, R13, R24, R26, R30, R32, R33, R36, R37 |
| 8 | Jumper_NC_Small | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP1, JP2, JP3, JP4, JP8, JP9, JP10, JP11 |
| 7 | 4.7uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3, C5, C10, C11, C16, C24, C25 |
| 6 | 20K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6, R7, R16, R23, R27, R29 |
| 6 | 47uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8, C9, C20, C21, C28, C29 |
| 6 | D_Schottky | Lib_NGL_Proto:SOT-323_SC-70_Handsoldering | D2, D3, D4, D5, D6, D11 |
| 5 | 4.7K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R17, R18, R19, R20, R21 |
| 5 | 40K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R22, R25, R28, R31, R52S1 |
| 4 | 1M | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5, R12, R34, R35 |
| 4 | BUMPER | Lib_NGL_Proto:SJ5003 | B1, B2, B3, B4 |
| 4 | GND | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP9, TP10, TP13, TP14 |
| 3 | AD8639 | Lib_NGL_Proto:ADA4522-2ARZ | U1, U2, U8 |
| 3 | SB | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | SB1, SB3, SB4 |
| 2 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C15, C17 |
| 2 | 4.7K | Resistor_SMD:R_0805_2012Metric | R18, R19 |
| 2 | LL4148 | Diode_SMD:D_MiniMELF | D1, D7 |
| 2 | NC | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2P1, R10P1 |
| 2 | SW_Push | Lib_NGL_Proto:3-1825910-5 | SW3, SW4 |
| 1 | +3.3V | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP7 |
| 1 | +BATT | TestPoint:TestPoint_Pad_D3.0mm | TPP2 |
| 1 | -3.3V | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP8 |
| 1 | 0R | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R39 |
| 1 | 100K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4 |
| 1 | 1043 | Lib_NGL_Proto:BAT_1043 | BT1 |
| 1 | 10K | Lib_NGL_ST:max5481eud&plus_T | U10 |
| 1 | 1101M2S3CQE2 | Lib_NGL_Proto:SW_1101M2S3CQE2 | S1 |
| 1 | 127K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 1 | 1K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R14 |
| 1 | 1nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C18 |
| 1 | 1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C30 |
| 1 | 20k | Lib_NGL_ST:SOP50P490X110-10N | U11 |
| 1 | 227161-2 | Lib_NGL_Proto:TE_5227161-2 | J3 |
| 1 | 300K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1 |
| 1 | 348R | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2 |
| 1 | 43R | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R15 |
| 1 | 50k | Lib_NGL_Proto:3224X-1-502E | POT1 |
| 1 | 590 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R10 |
| 1 | AD620 | Lib_NGL_Proto:SOIC127P600X175-8N | U7 |
| 1 | CLK_GEN | TestPoint:TestPoint_Pad_D3.0mm | TP6 |
| 1 | Conn_01x03_Male | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | Conn_01x04_Male | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J2 |
| 1 | Conn_01x04_Male | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J5 |
| 1 | Conn_01x06_Male | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J4 |
| 1 | Conn_01x08_Male | Lib_NGL_Proto:8DIN_THT | J1 |
| 1 | ESP32-WROOM-32D-N16 | Lib_NGL_Proto:MODULE_ESP32-WROOM-32D | U4 |
| 1 | GND | TestPoint:TestPoint_Pad_4.0x4.0mm | TPP4 |
| 1 | IN | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP1 |
| 1 | IN_ADC | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP2 |
| 1 | IN_ADC_DIFF | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP4 |
| 1 | LD29080PT33R | Lib_NGL_ST:DPAK114P990X239-6N | U5 |
| 1 | LED_B | LED_THT:LED_D3.0mm | D10 |
| 1 | LOGO | Lib_NGL_ST:BGM_12345 | G*** |
| 1 | LOGO | Lib_NGL_EURO:logo_ADTP_Fskils | G1 |
| 1 | MAX1680ESA+T | Lib_NGL_ST:SOIC127P600X175-8N | U6 |
| 1 | MAX922CSAT | Lib_NGL_Proto:SOIC127P600X175-8N | U3 |
| 1 | MCP3426A0-E_SN | SOIC127P600X175-8N | U9 |
| 1 | OUT | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP3 |
| 1 | OUT_DIFF | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP11 |
| 1 | RECT | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP5 |
| 1 | RECT_DIFF | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP12 |
| 1 | ROB-08449 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | M1 |
| 1 | RU1C002UNTCL | Lib_NGL_ST:RU1C002UNTCL | T1 |
| 1 | SDO | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | TP15 |
| 1 | SolderJumper_2_Bridged | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | SB2 |
| 1 | TestPoint | TestPoint:TestPoint_Pad_D3.0mm | TPP6 |
| 1 | TestPointPad | TestPoint:TestPoint_Pad_D3.0mm | TPP10 |
charlesbaynham/DigitalTemperatureController
Schematic, PCB and source code for a high-precision digital temperature controller

houseofthe051010/ESP32-Walkie-Talkie-V2
This ESP32 Walkie Talkie is redesigned with a SX1262 radio, a PCB, and a full case redesign.

K0nradG/self-balancing-robot
Self-balancing robot powered by nRF52840 and Zephyr RTOS, with BLE control, OTA updates, and a Raspberry Pi camera interface designed for future autonomous navigation.

Dawn-Of-Justice/project-revgen
A voice-controlled system designed to help elderly people interact with electronic devices through natural language commands in their native language.

ezer-soltani/HellKitty-Autonomous-Robot
Professional firmware and hardware design for an autonomous mobile robot using STM32G431 and FreeRTOS. Features Lidar perception, ToF safety algorithms, and PID motor control.


mahdi-kh1265/780nm-ecdl-electronics
Control, interface, piezo-actuation, and power electronics for POSM's 780 nm Littrow external-cavity diode laser.

It measures 113 × 70 mm and has 2 copper layers, 1.6 mm thick.
145 parts, built around the ESP32-WROOM-32D-N16, AD8639AR, LD29080PT33R and MAX1680ESA+T. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the benoitGIRAUD/NGL_PROTO_ST repository on GitHub, at the commit this page was made from: the board is NGL_Proto_ST_PCB/NGL_Proto_ST.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask benoitGIRAUD before reusing the design.