4 layers55.9 × 83.8 mm
Stm32g474board
halherta/stm32g474board
EmbLynx Development board for the stm32G474RE microcontroller
70 partsMIT

 bachaaymene/stm32-flight-controller
Custom 4-layer flight controller PCB for an F450 quadcopter. STM32F405, LSM6DSO IMU, LPS22HB barometer, USB-C. Designed in KiCad.
Flight controller is an open-source printed circuit board by bachaaymene, from the bachaaymene/stm32-flight-controller repository on GitHub. It is a 4-layer board of 59 × 59 mm with 65 parts on 81 nets, routed with 677 tracks and 168 vias.
It is built around the AP63205WU, LPS22HB and USBLC6-2SC6, with the AO3401A and B340 among its other parts. Its parts include 25 capacitors, 11 resistors, 9 connectors, 5 ICs and 3 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


A 4-layer flight controller board for an F450 quadcopter frame, based on the STM32F405RGT6. Designed in KiCad 10 by SparkLab DZ.
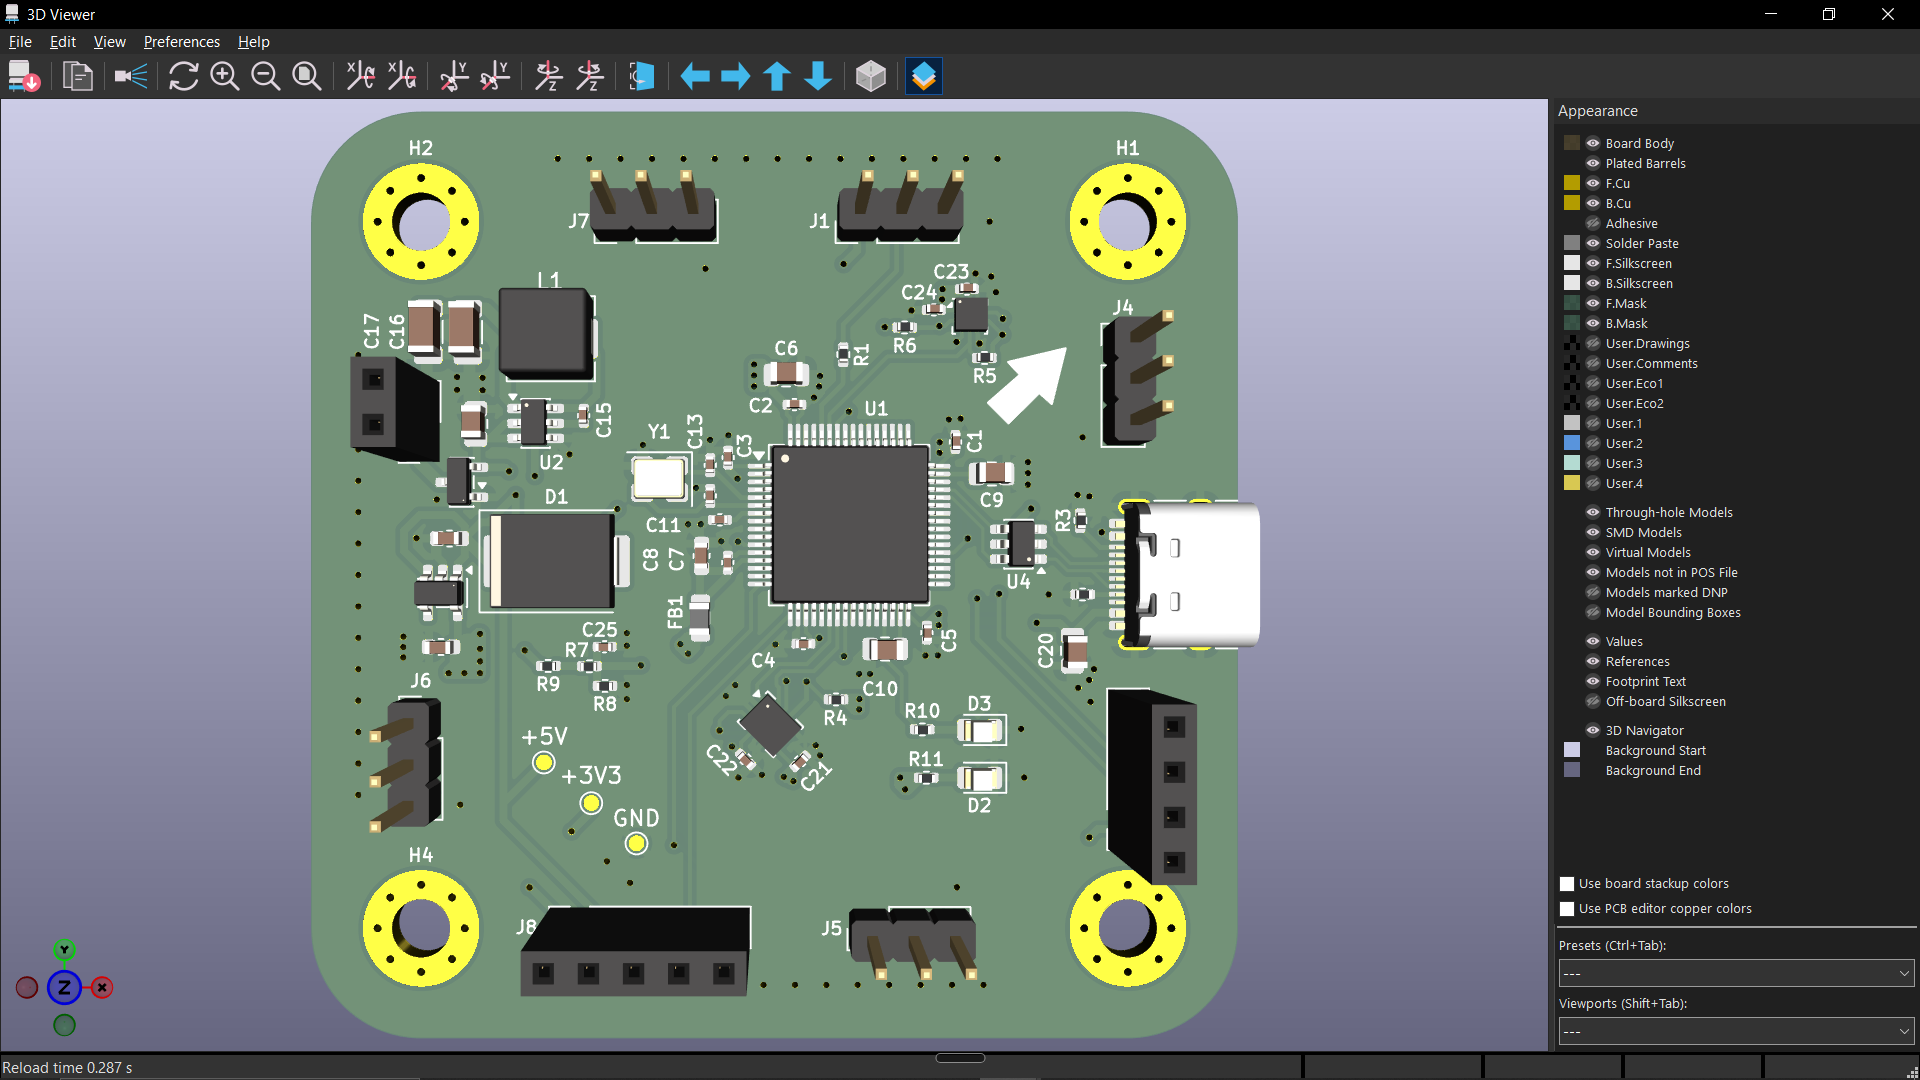
| Block | Part | Notes |
|---|---|---|
| MCU | STM32F405RGT6 (LQFP64) | Cortex-M4F, 168 MHz, 1 MB Flash |
| IMU | LSM6DSO | SPI1, INT1 on PC4 |
| Barometer | LPS22HB | I2C1, address 0x5C |
| Motor outputs | 4x ESC | PC6 to PC9 on TIM3 (DShot capable) |
| 5V regulator | AP63205WU-7 | Synchronous buck, 3S LiPo input, 4.7 uH inductor |
| 3.3V regulator | TLV70233 | LDO from 5V |
| USB | USB Type-C 16P | PA11 / PA12 |
| Battery sense | 33k / 10k divider | PA0 (ADC) |
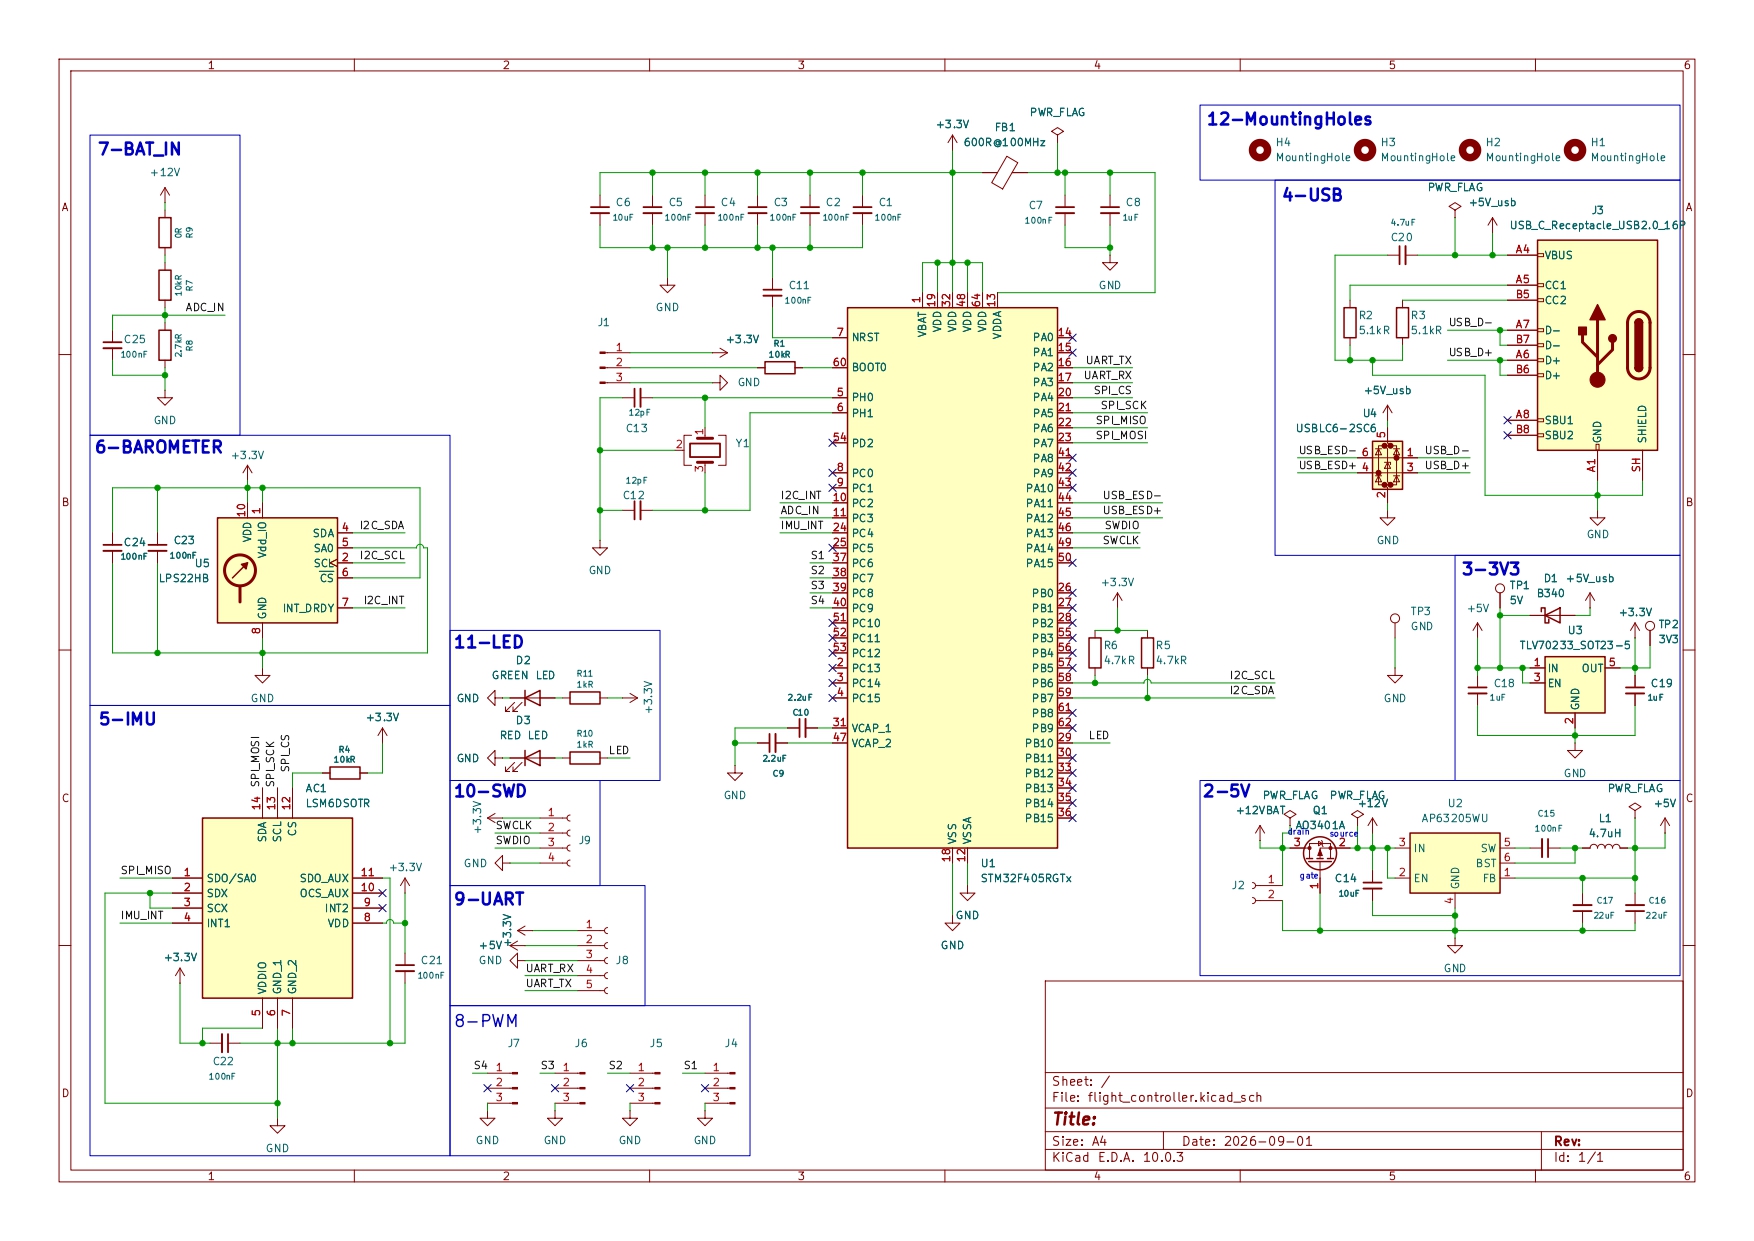
Full schematic as PDF: post/flight_controller.pdf
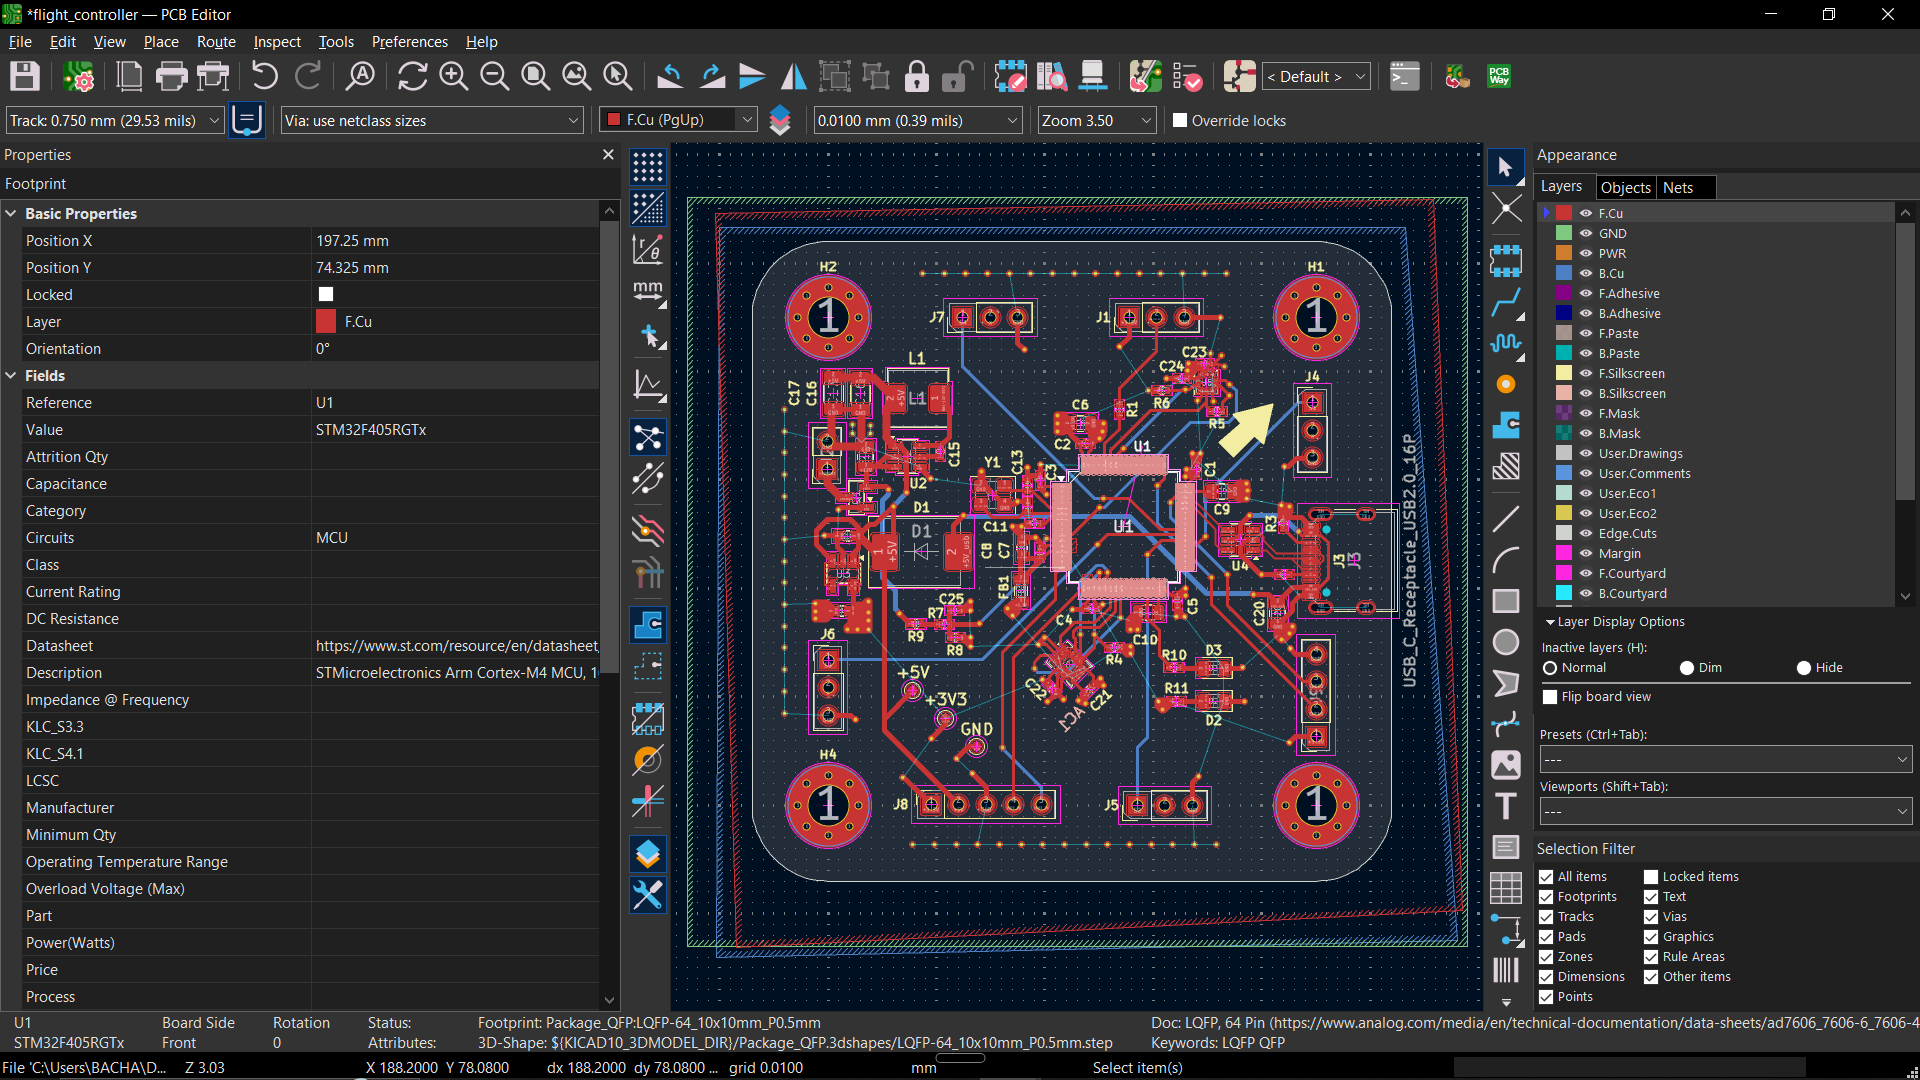
| Layer | Use |
|---|---|
| L1 | Signal + components |
| L2 | Solid GND plane |
| L3 | Power |
| L4 | Signal |
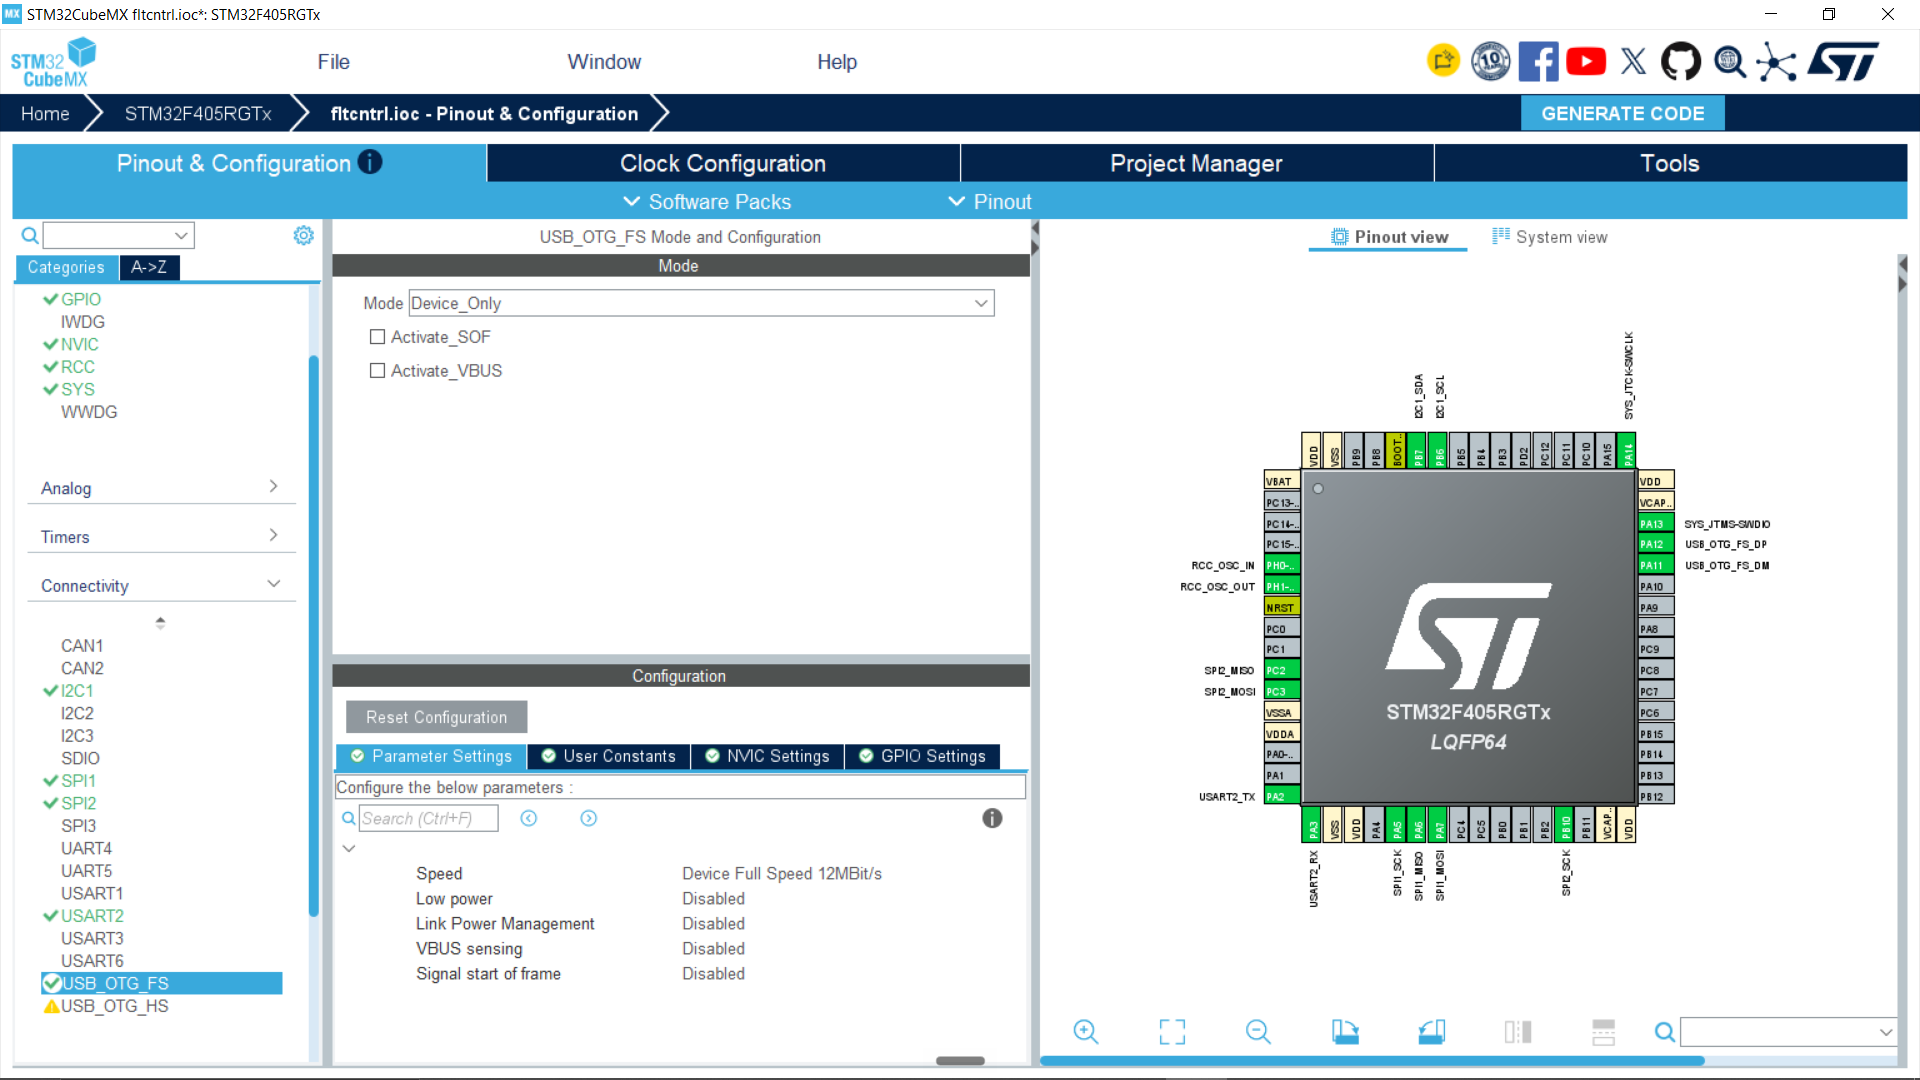
| Function | Pin(s) |
|---|---|
| IMU SPI1 (CS / SCK / MISO / MOSI) | PA4 / PA5 / PA6 / PA7 |
| IMU interrupt (INT1) | PC4 |
| Baro I2C1 (SCL / SDA) | PB6 / PB7 |
| ESC 1 to 4 | PC6 / PC7 / PC8 / PC9 |
| USB D- / D+ | PA11 / PA12 |
| Battery voltage | PA0 |
Pin configuration in STM32CubeIDE:
stm32-flight-controller/
├── datasheets/                      Component datasheets
├── libs/                            Project symbols, footprints and 3D models
├── post/                            Schematic PDF and images
├── flight_controller.kicad_pro      KiCad project
├── flight_controller.kicad_sch      Schematic
├── flight_controller.kicad_pcb      PCB layout
├── flight_controller.csv            Bill of materials
├── fabrication-toolkit-options.json Fabrication Toolkit plugin settings
├── sym-lib-table                    Project symbol library table
├── fp-lib-table                     Project footprint library table
├── .gitattributes                   Git LFS settings
└── .gitignoreRequirements: KiCad 10.0 or newer. Older versions cannot open these files.
The repository uses Git LFS for large files, so install it before cloning:
git lfs install
git clone https://github.com/bachaaymene/stm32-flight-controller.git
Then open flight_controller.kicad_pro in KiCad.
All symbols, footprints and 3D models are stored in libs/ with paths relative to the project (${KIPRJMOD}), so no external libraries are needed. If something appears missing, please open an issue.
The BOM is in flight_controller.csv.
Production files (Gerber, drill, BOM and CPL) for JLCPCB can be generated with the Fabrication Toolkit plugin. Install it from the KiCad Plugin and Content Manager, then run it from the PCB editor. The settings used for this board are saved in fabrication-toolkit-options.json.
This hardware design is released under the CERN-OHL-S-2.0 license.
Aymene Bacha, SparkLab DZ
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 100nF | flight_controller:C_0402_1005Metric | C1, C2, C3, C4, C5, C7, C11, C15, C21, C22, C23, C24, C25 |
| 5 | Conn_01x03_Pin | flight_controller:PinHeader_1x03_P2.54mm_Vertical | J1, J4, J5, J6, J7 |
| 4 | MountingHole | flight_controller:MountingHole_3.7mm_Pad_Via | H1, H2, H3, H4 |
| 3 | 10kR | flight_controller:R_0402_1005Metric | R1, R4, R7 |
| 3 | 1uF | flight_controller:C_0603_1608Metric | C8, C18, C19 |
| 2 | 10uF | flight_controller:C_0805_2012Metric | C6, C14 |
| 2 | 12pF | flight_controller:C_0402_1005Metric | C12, C13 |
| 2 | 1kR | flight_controller:R_0402_1005Metric | R10, R11 |
| 2 | 2.2uF | flight_controller:C_0805_2012Metric | C9, C10 |
| 2 | 22uF | flight_controller:C_1206_3216Metric | C16, C17 |
| 2 | 4.7kR | flight_controller:R_0402_1005Metric | R5, R6 |
| 2 | 5.1kR | flight_controller:R_0402_1005Metric | R2, R3 |
| 1 | 0R | flight_controller:R_0402_1005Metric | R9 |
| 1 | 2.7kR | flight_controller:R_0402_1005Metric | R8 |
| 1 | 3V3 | flight_controller:TestPoint_Pad_D1.0mm | 3V3 |
| 1 | 4.7uF | flight_controller:C_0805_2012Metric | C20 |
| 1 | 4.7uH | flight_controller:L_Sunlord_MWSA0503S | L1 |
| 1 | 5V | flight_controller:TestPoint_Pad_D1.0mm | 5V |
| 1 | 600R@100MHz | flight_controller:L_0805_2012Metric | FB1 |
| 1 | 8MHz Crystal_GND24 | flight_controller:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | AO3401A | flight_controller:SOT-23 | Q1 |
| 1 | AP63205WU | flight_controller:TSOT-23-6 | U2 |
| 1 | B340 | flight_controller:D_SMC | D1 |
| 1 | Conn_01x02_Socket | flight_controller:PinSocket_1x02_P2.54mm_Vertical | J2 |
| 1 | Conn_01x04_Socket | flight_controller:PinSocket_1x04_P2.54mm_Vertical | J9 |
| 1 | Conn_01x05_Socket | flight_controller:PinSocket_1x05_P2.54mm_Vertical | J8 |
| 1 | GND | flight_controller:TestPoint_Pad_D1.0mm | GND |
| 1 | GREEN LED | flight_controller:LED_0805_2012Metric | D2 |
| 1 | LPS22HB | flight_controller:ST_HLGA-10_2x2mm_P0.5mm_LayoutBorder3x2y | U5 |
| 1 | LSM6DSOTR | flight_controller:LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | AC1 |
| 1 | RED LED | flight_controller:LED_0805_2012Metric | D3 |
| 1 | STM32F405RGTx | flight_controller:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | TLV70233_SOT23-5 | flight_controller:SOT-23-5 | U3 |
| 1 | USBLC6-2SC6 | flight_controller:SOT-23-6 | U4 |
| 1 | USB_C_Receptacle_USB2.0_16P | flight_controller:USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J3 |
It measures 59 × 59 mm and has 4 copper layers, 1.42 mm thick.
65 parts, built around the AP63205WU, LPS22HB, USBLC6-2SC6 and AO3401A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bachaaymene/stm32-flight-controller repository on GitHub, at the commit this page was made from: the board is flight_controller.kicad_pcb and its schematic flight_controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask bachaaymene before reusing the design.
halherta/stm32g474board
EmbLynx Development board for the stm32G474RE microcontroller


CU-Rocketry/flight_computer
Competition Flight Computer Module 25-26

Quard/MLight
MLight is a compact, all-in-one control board designed to manage auxiliary tools for soldering equipment

Arkos-Engineering/HT-15_hardware
We can split this out into separate repos later, right now its very convenient to have everything here.

aqualinkd/aqualinkd-zero-hat
Raspberry HAT to provide RS485 I/O and Power from Jandy RS485 control panel.

ADVecu/ADV.dash
ADV.dash is a dashboard project built with LVGL and ESP32-S3. It is prepared to receive CAN bus data from rusEFI and, in the future, other programmable ECUs.