Data port x4
kartben/hw-testing-rack
3D-printed, tilted test shelf for 16 dev boards: sliding drawers, per-bay ESP32-S3 running Zephyr (USB/IP, power switching, metering), KiCad PCBs, OpenSCAD parts, BOM and an interactive 3D viewer

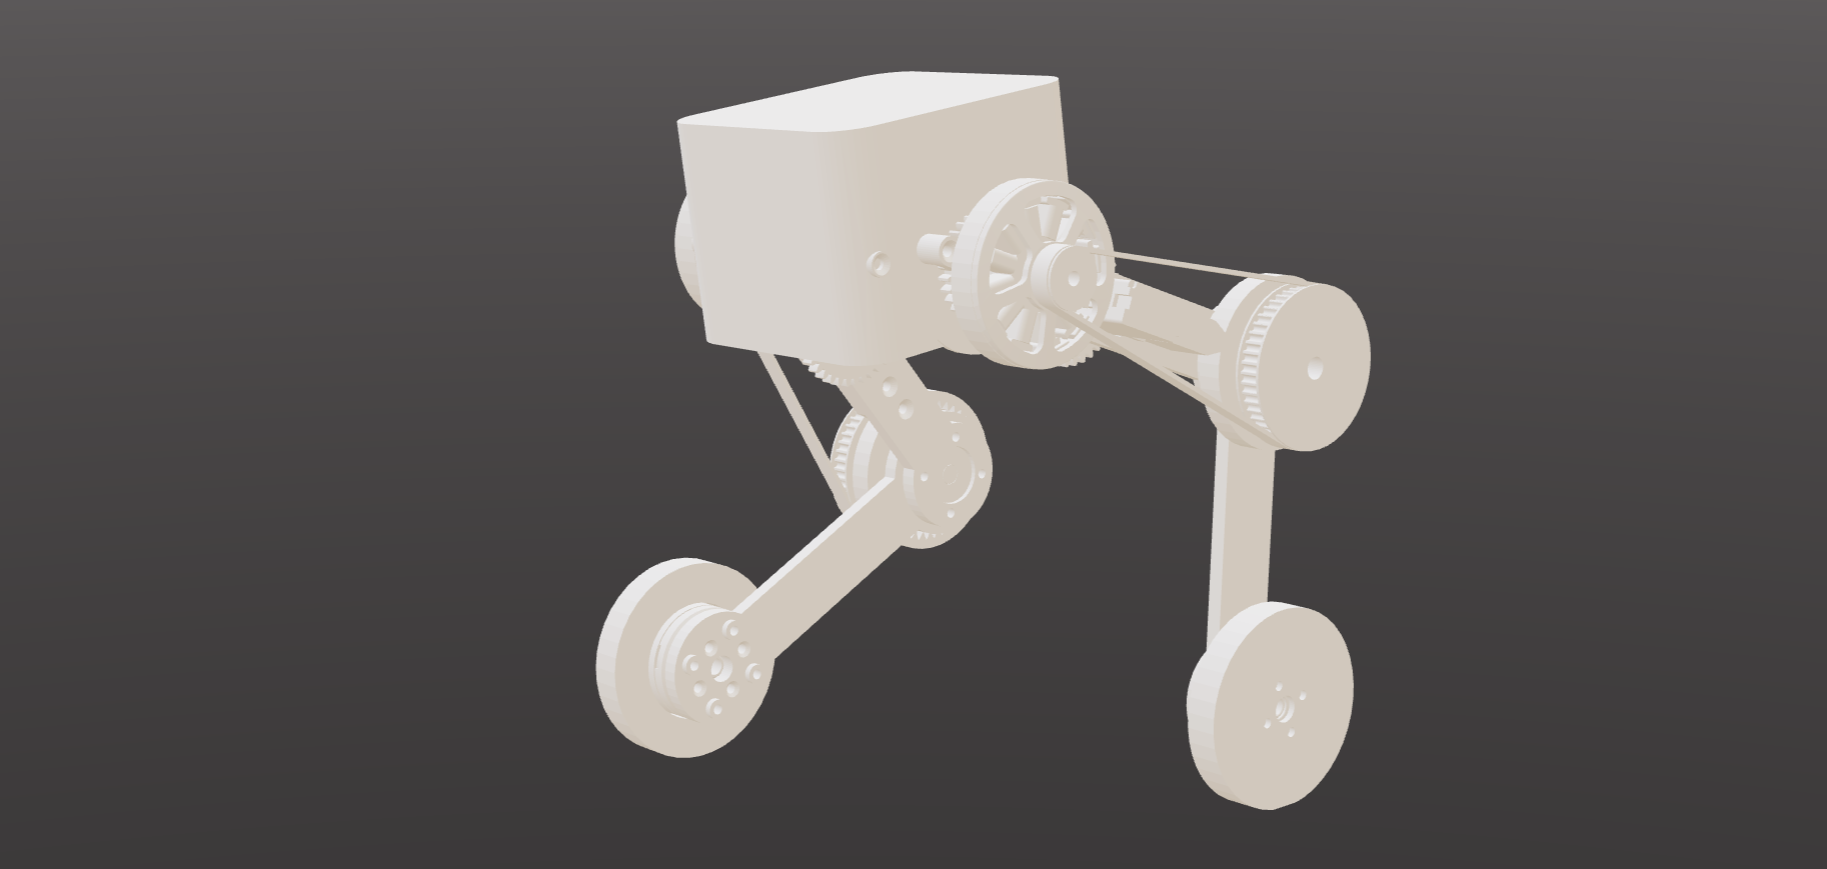
ria is a small wheeled biped built for jumping and fast ground motion.
Ria is an open-source printed circuit board by B44ken, from the B44ken/ria repository on GitHub. It is a 4-layer board of 50 × 69.5 mm with 107 parts on 135 nets, routed with 2,412 tracks and 259 vias.
It is built around the ESPS3-32-N4, SS6343M-QF-TP and TPS54331DR-JSM, with the CC0603KRX7R9BB104, SMR12M1FR010T and CL21B105KBFNNNE among its other parts.
ria is a small wheeled biped built for jumping and fast ground motion.

ria is built mostly from parts designed in cadquery. nearly every part has a flat face so it should be easy to 3d print. you'll also need some m3 screws of various sizes and a handful of bearings.
cd models
python3 main.pythe pcb is the most expensive part of the design, at roughly $100 (from jlcpcb assembly). i built it in backplane. the kicad project is at pcb/ria.kicad_pro
ria is trained and driven in botblocks.dev
cd software
botblocks import robot bot.json --save $MY_FORK/robot
botblocks run drive.py| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100nF | ria:C_0603_CURRENT | MOTOR1-CC1, MOTOR1-CC2, MOTOR2-CC1, MOTOR2-CC2, MOTOR3-CC1, MOTOR3-CC2, MOTOR4-CC1, MOTOR4-CC2 |
| 8 | 10mOhm 1% 1W | ria:SHUNT_1206_KELVIN | MOTOR1-RS1, MOTOR1-RS2, MOTOR2-RS1, MOTOR2-RS2, MOTOR3-RS1, MOTOR3-RS2, MOTOR4-RS1, MOTOR4-RS2 |
| 8 | INA241A3IDDFR | ria:INA241A3_DDF | MOTOR1-CS1, MOTOR1-CS2, MOTOR2-CS1, MOTOR2-CS2, MOTOR3-CS1, MOTOR3-CS2, MOTOR4-CS1, MOTOR4-CS2 |
| 5 | 1uF | ria:C_0805_2012Metric | ESP-C3, MOTOR1-C2, MOTOR2-C2, MOTOR3-C2, MOTOR4-C2 |
| 4 | 22uF | ria:C_1206_3216Metric | MOTOR1-C5, MOTOR2-C5, MOTOR3-C5, MOTOR4-C5 |
| 4 | SS6343M-QF-TP | ria:SS6343M-QF-TP | MOTOR1-U1, MOTOR2-U1, MOTOR3-U1, MOTOR4-U1 |
| 1 | 1.5kR 1% | ria:SENSE-R2 | SENSE-R2 |
| 1 | 100nF | ria:MOTOR4-C3 | MOTOR4-C3 |
| 1 | 100nF | ria:SERVO-C8 | SERVO-C8 |
| 1 | 100nF | ria:IMU-C2 | IMU-C2 |
| 1 | 100nF | ria:IMU-C1 | IMU-C1 |
| 1 | 100nF | ria:MOTOR2-C3 | MOTOR2-C3 |
| 1 | 100nF | ria:POWER-C3 | POWER-C3 |
| 1 | 100nF | ria:MOTOR3-C3 | MOTOR3-C3 |
| 1 | 100nF | ria:MOTOR1-C3 | MOTOR1-C3 |
| 1 | 10kR | ria:MOTOR-RS | MOTOR-R2 |
| 1 | 10kR | ria:MOTOR-RE | MOTOR-R1 |
| 1 | 10kR | ria:ESP-R1 | ESP-R1 |
| 1 | 10kR | ria:ESP-R2 | ESP-R2 |
| 1 | 10kR 1% | ria:SENSE-R1 | SENSE-R1 |
| 1 | 10nF | ria:SERVO-C10 | SERVO-C10 |
| 1 | 10nF | ria:POWER-C6 | POWER-C6 |
| 1 | 10nF | ria:POWER-C8 | POWER-C8 |
| 1 | 10nF | ria:SERVO-C11 | SERVO-C11 |
| 1 | 10uF | ria:ESP-C1 | ESP-C1 |
| 1 | 12kR | ria:SERVO-R3 | SERVO-R3 |
| 1 | 160kR 1% | ria:SERVO-R1 | SERVO-R1 |
| 1 | 161N-4BVS11 | ria:USB-J1 | USB-J1 |
| 1 | 22R | ria:ESP-R3 | ESP-R3 |
| 1 | 22R | ria:ESP-R4 | ESP-R4 |
| 1 | 22uF | ria:POWER-C1 | POWER-C1 |
| 1 | 22uF | ria:SERVO-C7 | SERVO-C7 |
| 1 | 22uF | ria:SERVO-C2 | SERVO-C2 |
| 1 | 22uF | ria:POWER-C5 | POWER-C5 |
| 1 | 22uF | ria:SERVO-C1 | SERVO-C1 |
| 1 | 22uF | ria:SERVO-C5 | SERVO-C5 |
| 1 | 22uF | ria:POWER-C4 | POWER-C4 |
| 1 | 22uF | ria:SERVO-C6 | SERVO-C6 |
| 1 | 24kR 1% | ria:POWER-R2 | POWER-R2 |
| 1 | 30kR 1% | ria:SERVO-R2 | SERVO-R2 |
| 1 | 330pF | ria:SERVO-C9 | SERVO-C9 |
| 1 | 330pF | ria:POWER-C7 | POWER-C7 |
| 1 | 4.7kR | ria:ENC-RD0 | ENC-RD0 |
| 1 | 4.7kR | ria:ENC-RC0 | ENC-RC0 |
| 1 | 4.7uF | ria:MOTOR4-C6 | MOTOR4-C6 |
| 1 | 4.7uF | ria:MOTOR2-C6 | MOTOR2-C6 |
| 1 | 4.7uF | ria:MOTOR1-C6 | MOTOR1-C6 |
| 1 | 4.7uF | ria:MOTOR3-C6 | MOTOR3-C6 |
| 1 | 5.1kR | ria:USB-RCC2 | USB-RCC2 |
| 1 | 5.1kR | ria:USB-RCC1 | USB-RCC1 |
| 1 | 6.8kR | ria:POWER-R3 | POWER-R3 |
| 1 | 6.8uH | ria:POWER-L1 | POWER-L1 |
| 1 | 6.8uH | ria:SERVO-L1 | SERVO-L1 |
| 1 | 75kR 1% | ria:POWER-R1 | POWER-R1 |
| 1 | ESPS3-32-N4 | ria:ESP-U1 | ESP-U1 |
| 1 | H5VU25UC | ria:USB-U2 | USB-U2 |
| 1 | ICM-42688-P(TOKMAS) | ria:IMU-U1 | IMU-U1 |
| 1 | PZ254V-11-03P | ria:SERVO-J2 | SERVO-J2 |
| 1 | PZ254V-11-03P | ria:MOTOR-J2 | MOTOR-J2 |
| 1 | PZ254V-11-03P | ria:SERVO-J1 | SERVO-J1 |
| 1 | PZ254V-11-03P | ria:MOTOR-J1 | MOTOR-J1 |
| 1 | SS34 | ria:POWER-D3 | POWER-D3 |
| 1 | SS34 | ria:POWER-D2 | POWER-D2 |
| 1 | SS34 | ria:SERVO-D1 | SERVO-D1 |
| 1 | SS34 | ria:POWER-D1 | POWER-D1 |
| 1 | TPS54331DR | ria:SERVO-U1 | SERVO-U1 |
| 1 | TPS54331DR | ria:POWER-U1 | POWER-U1 |
| 1 | TS-1088-AR02016 | ria:ESP-SW2 | ESP-SW2 |
| 1 | TS-1088-AR02016 | ria:ESP-SW1 | ESP-SW1 |
| 1 | XT60PB-M.G.Y | ria:POWER-J1 | POWER-J1 |
| 1 | motor wires | ria:MOTOR-J4B | MOTOR-J7 |
| 1 | motor wires | ria:MOTOR-J4A | MOTOR-J6 |
| 1 | motor wires | ria:MOTOR-J3A | MOTOR-J3 |
| 1 | motor wires | ria:MOTOR-J3C | MOTOR-J5 |
| 1 | motor wires | ria:MOTOR-J4C | MOTOR-J8 |
| 1 | motor wires | ria:MOTOR-J3B | MOTOR-J4 |
It measures 50 × 69.5 mm and has 4 copper layers, 1.6 mm thick.
107 parts, built around the ESPS3-32-N4, SS6343M-QF-TP, TPS54331DR-JSM and CC0603KRX7R9BB104. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the B44ken/ria repository on GitHub, at the commit this page was made from: the board is pcb/ria.kicad_pcb and its schematic pcb/ria-current.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask B44ken before reusing the design.

kartben/hw-testing-rack
3D-printed, tilted test shelf for 16 dev boards: sliding drawers, per-bay ESP32-S3 running Zephyr (USB/IP, power switching, metering), KiCad PCBs, OpenSCAD parts, BOM and an interactive 3D viewer


JacobBanghart/clickdeck
Custom Stream Deck-style USB controller: per-key images, micro switches, haptic knobs

OETSolutions/swc-module
Steering-wheel-controls adapter module — ESP32-S3, KiCad schematic/PCB, JLCPCB assembly

Person-0/Quad0
The board will be designed in a way such that it can fly with standard 8520 coreless motors and a tiny lipo battery for brushed mode.

spartacus-hf/spartacus_PCB_REV1
KiCad schematic and PCB project for the SPARTACUS-HF Chireix transceiver.


BarbourSmith/Maslow-Mini-Control-Board
A third KiCad project that puts both existing boards on one PCB: