4 layers37 × 37 mm
Flight controller
AQUA-Warrior/fpv-drone
Frame needs to be printed using nylon/nylon with carbon fiber only exclusions being ArmAbsorber1-4 and AntenaMount/GPSConnector.
125 parts3CC-BY-SA-4.0
 agg-85/flight-controller1
Custom STM32-based flight controller using KiCad.
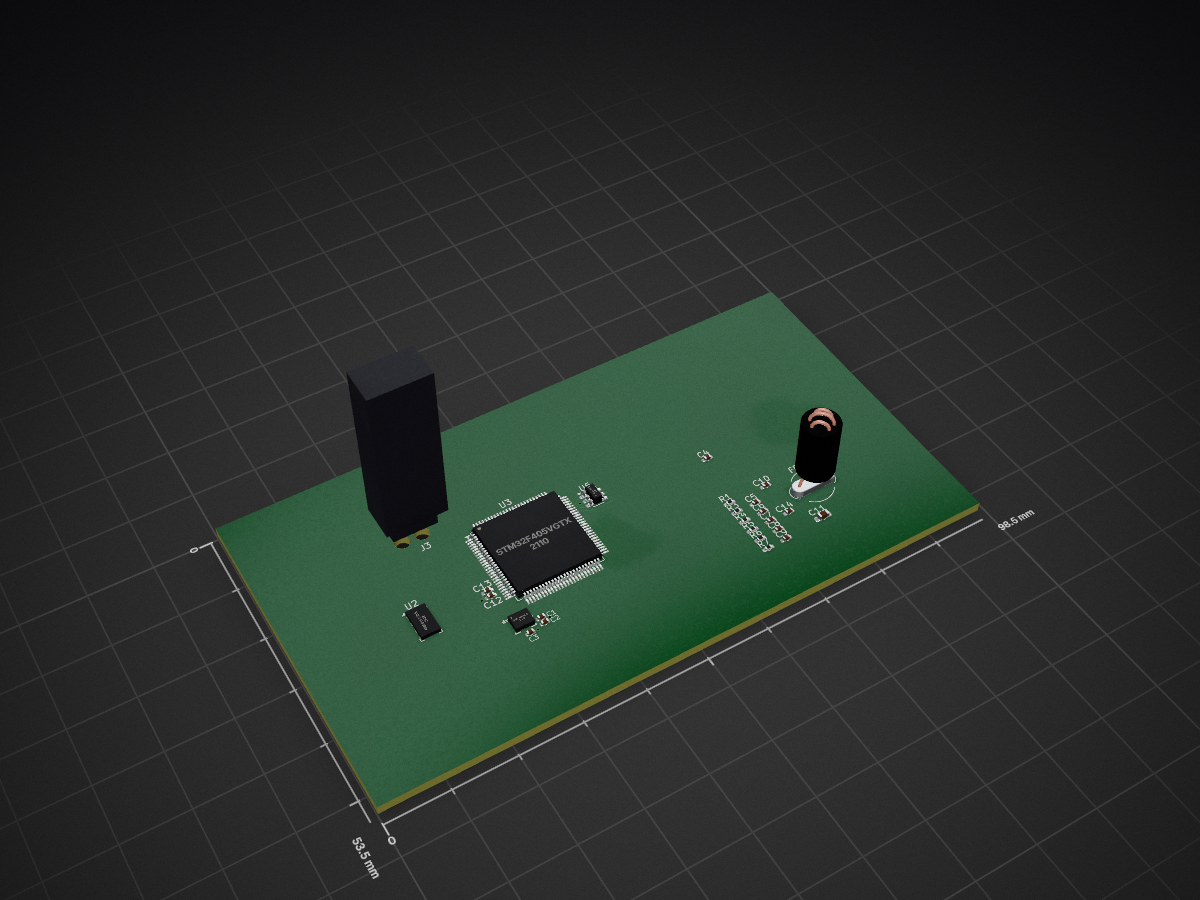
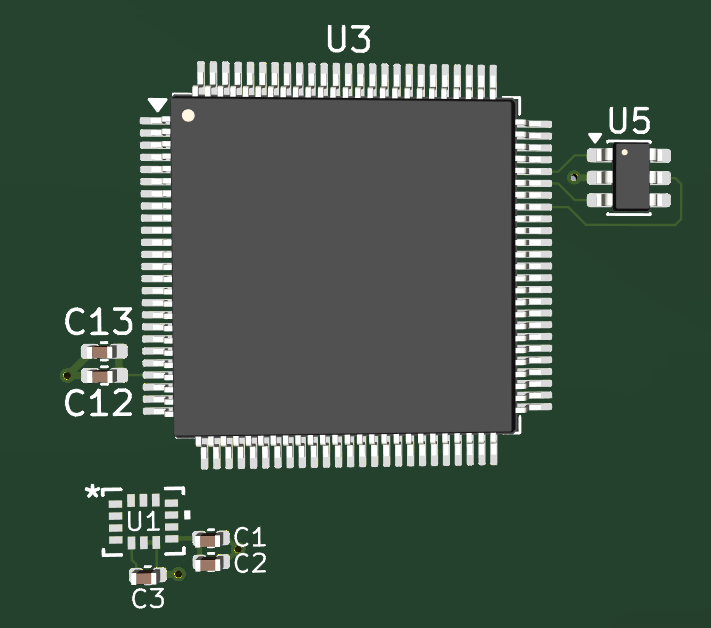
STM32FlightControllerV1 is an open-source printed circuit board by agg-85, from the agg-85/flight-controller repository on GitHub, published under the MIT licence. It is a 2-layer board of 98.5 × 53.5 mm with 26 parts on 112 nets, routed with 39 tracks and 4 vias.
It is built around the MS5611-01BA03, ICM-42688-P and USBLC6-2SC6. Its parts include 14 capacitors, 6 resistors, 4 ICs and 1 connector. It belongs with the STM32 boards of this library.


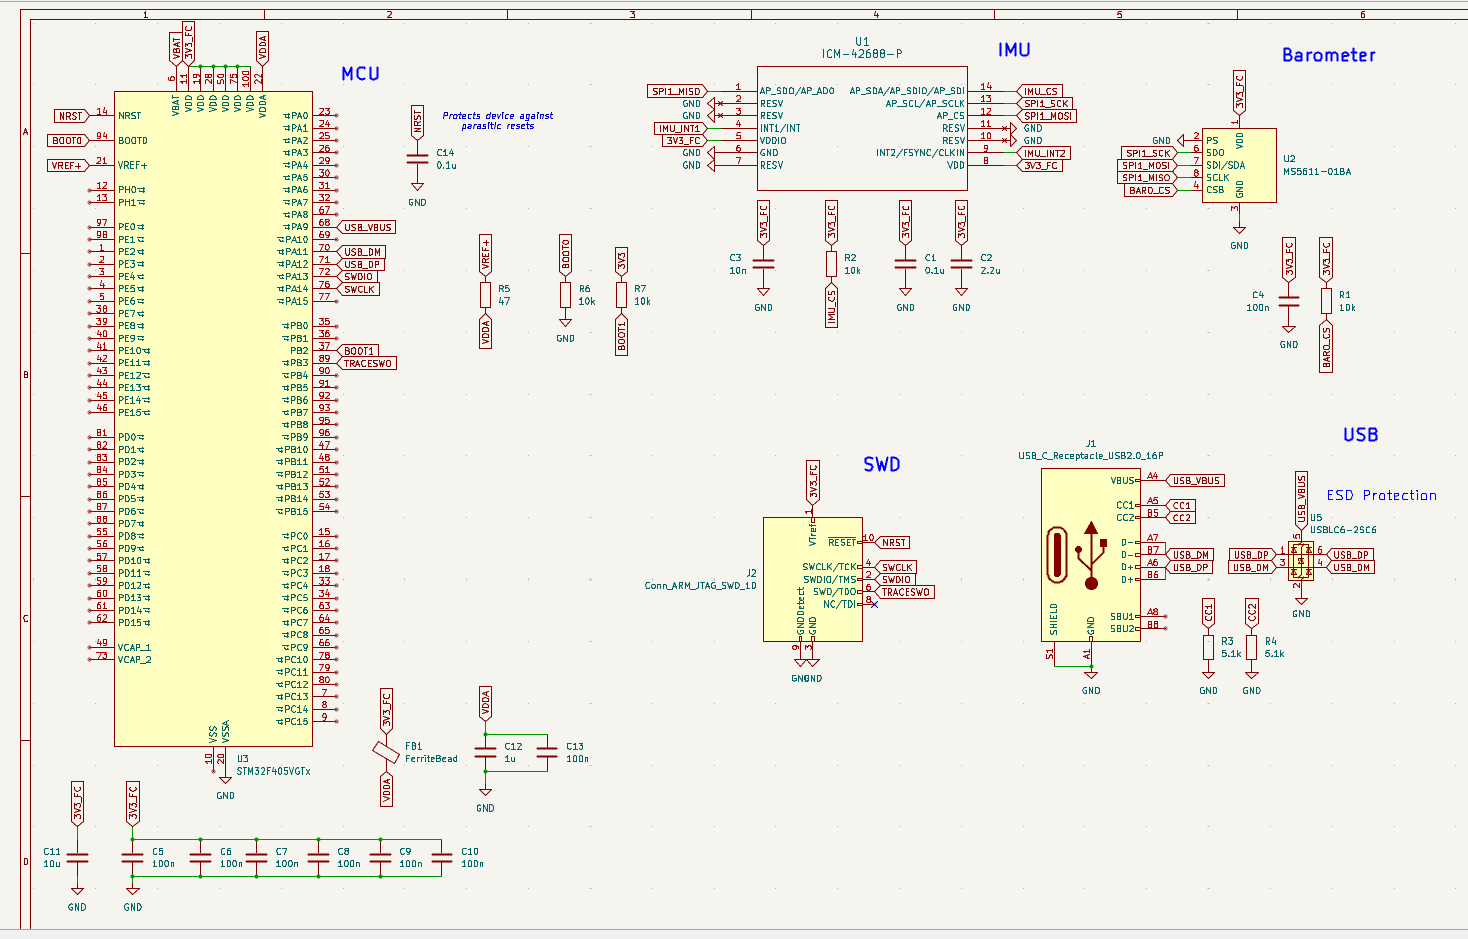
A custom STM32-based flight controller designed from the ground up for quadcopters. This project includes PCB design using KiCad and embedded firmware using Ardupilot.
| Component | Part |
|---|---|
| MCU | STM32F405, 168MHz, 1MB Flash |
| IMU | ICM-42688-P |
| Barometer | MS5611 |
Hardware
Firmware
Testing
The STM32F405 was selected because:
The objective of this project is to design a flight controller from scratch while learning PCB design, embedded systems, and hardware debugging.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100n | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C4, C5, C6, C7, C8, C9, C10, C13 |
| 3 | 10k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R1, R6, R7 |
| 2 | 5.1k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R3, R4 |
| 1 | 0.1u | Capacitor_SMD:C_0402_1005Metric | C1 |
| 1 | 0.1u | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C14 |
| 1 | 10n | Capacitor_SMD:C_0402_1005Metric | C3 |
| 1 | 10u | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C11 |
| 1 | 1u | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C12 |
| 1 | 2.2u | Capacitor_SMD:C_0402_1005Metric | C2 |
| 1 | 47 | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R5 |
| 1 | Conn_ARM_SWD_TagConnect_TC2030 | Connector:Tag-Connect_TC2030-IDC-FP_2x03_P1.27mm_Vertical | J3 |
| 1 | FerriteBead | Ferrite_THT:LairdTech_28C0236-0JW-10 | FB1 |
| 1 | ICM-42688-P | DroneFootprints:LGA14_2P5X3X0P91_TDK | U1 |
| 1 | MS5611-01BA | Package_LGA:LGA-8_3x5mm_P1.25mm | U2 |
| 1 | STM32F405VGTx | Package_QFP:LQFP-100_14x14mm_P0.5mm | U3 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U5 |
It measures 98.5 × 53.5 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the MS5611-01BA03, ICM-42688-P and USBLC6-2SC6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the agg-85/flight-controller repository on GitHub, at the commit this page was made from: the board is STM32FlightControllerV1/STM32FlightControllerV1.kicad_pcb and its schematic STM32FlightControllerV1/STM32FlightControllerV1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
AQUA-Warrior/fpv-drone
Frame needs to be printed using nylon/nylon with carbon fiber only exclusions being ArmAbsorber1-4 and AntenaMount/GPSConnector.


Ben-Blair/Rocket-Build
Senior capstone project: demonstrate closed-loop lateral guidance of a high power rocket using forward canards, and handle the canard-wake-on-aft-fin interference problem correctly.

liquid-rocketry-illinois/flight-computer-one-hw
SAME51-based flight computer with active control capabilities

codinga593/IRIS
A next generation model rocket focused on a precise propulsive landing on a tower.


