4 layers70 × 99.9 mm
Micromouse
UBIEEE/FrankenMouse
FrankenMouse is a MicroMouse robot that was designed, built, and programmed from scratch by members of the University at Buffalo's IEEE Student Branch.
99 parts6MIT

 UBIEEE/FrankenMouse6
FrankenMouse is a MicroMouse robot that was designed, built, and programmed from scratch by members of the University at Buffalo's IEEE Student Branch.
Micromouse is an open-source printed circuit board by UBIEEE, from the UBIEEE/FrankenMouse repository on GitHub, published under the MIT licence. It is a 4-layer board of 70 × 99.9 mm with 100 parts on 80 nets, routed with 561 tracks and 193 vias.
It is built around the STM32WB55CGU6, DLF162500LT-5028A1 and DRV8835DSS, with the ICM-42670-P, USBLC6-2SC6 and SFH 4545 among its other parts. Its parts include 28 capacitors, 24 resistors, 10 transistors, 6 ICs and 5 diodes. It belongs with the STM32 boards of this library.


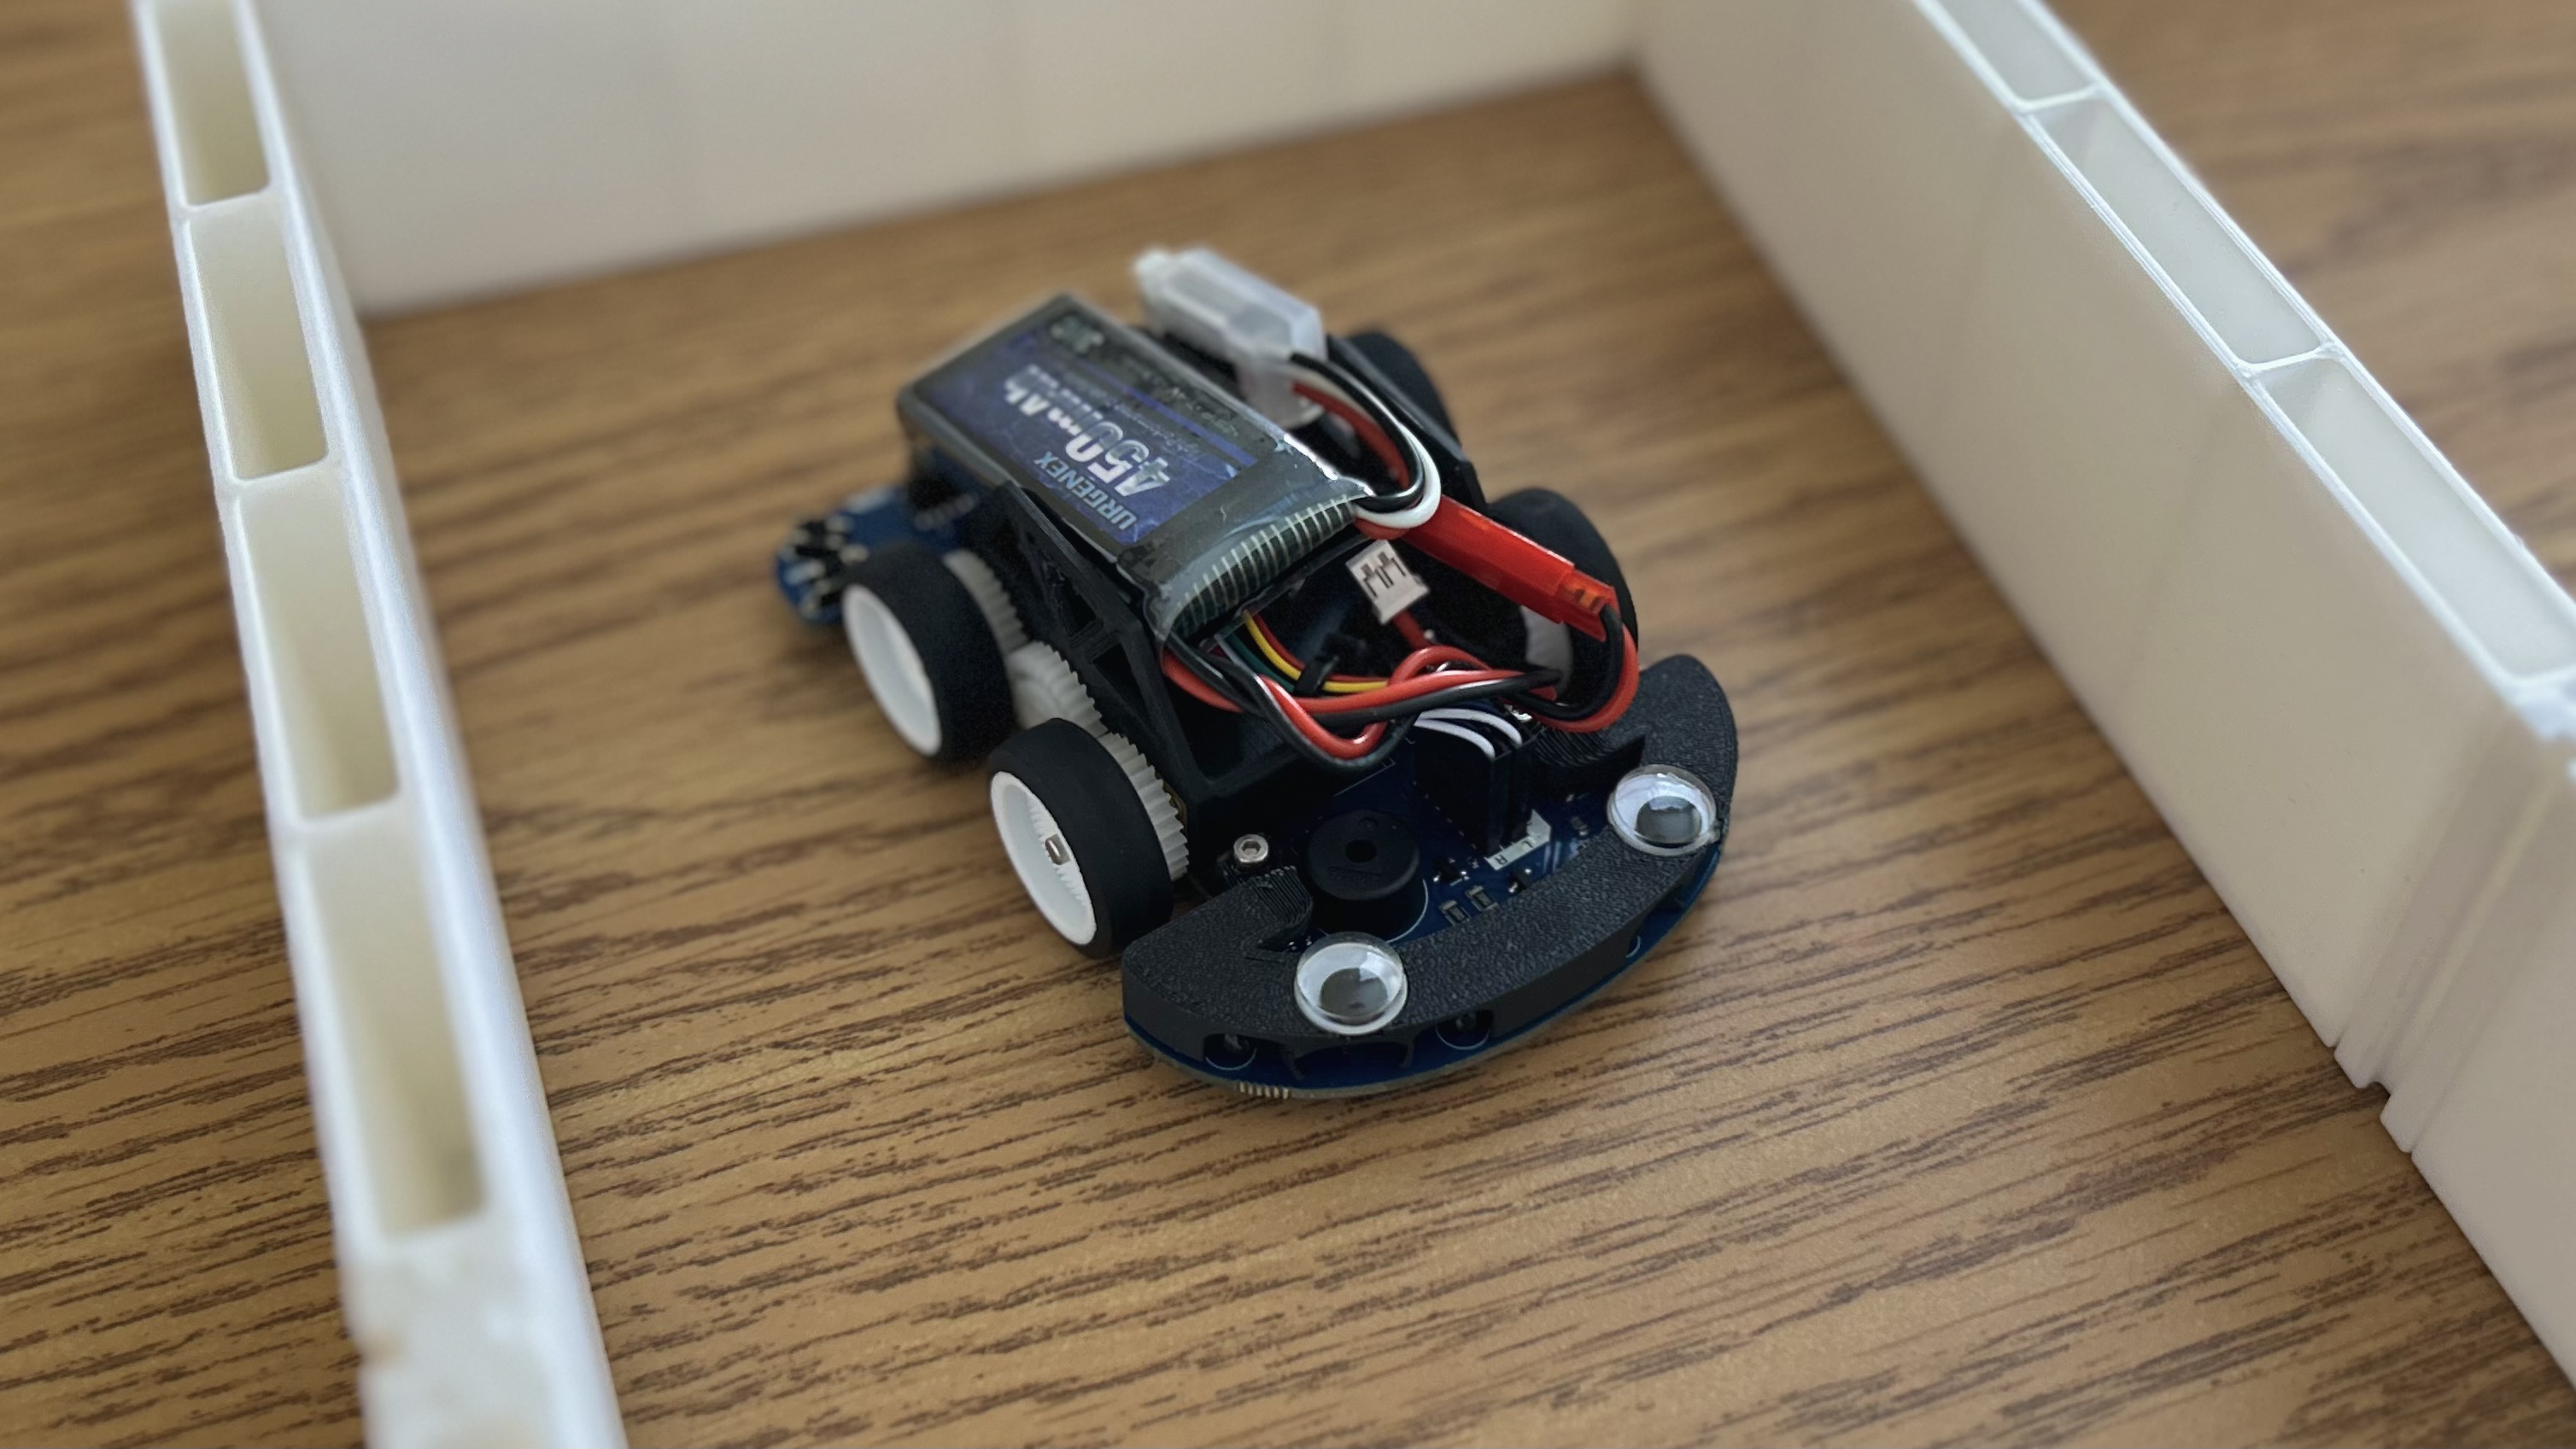
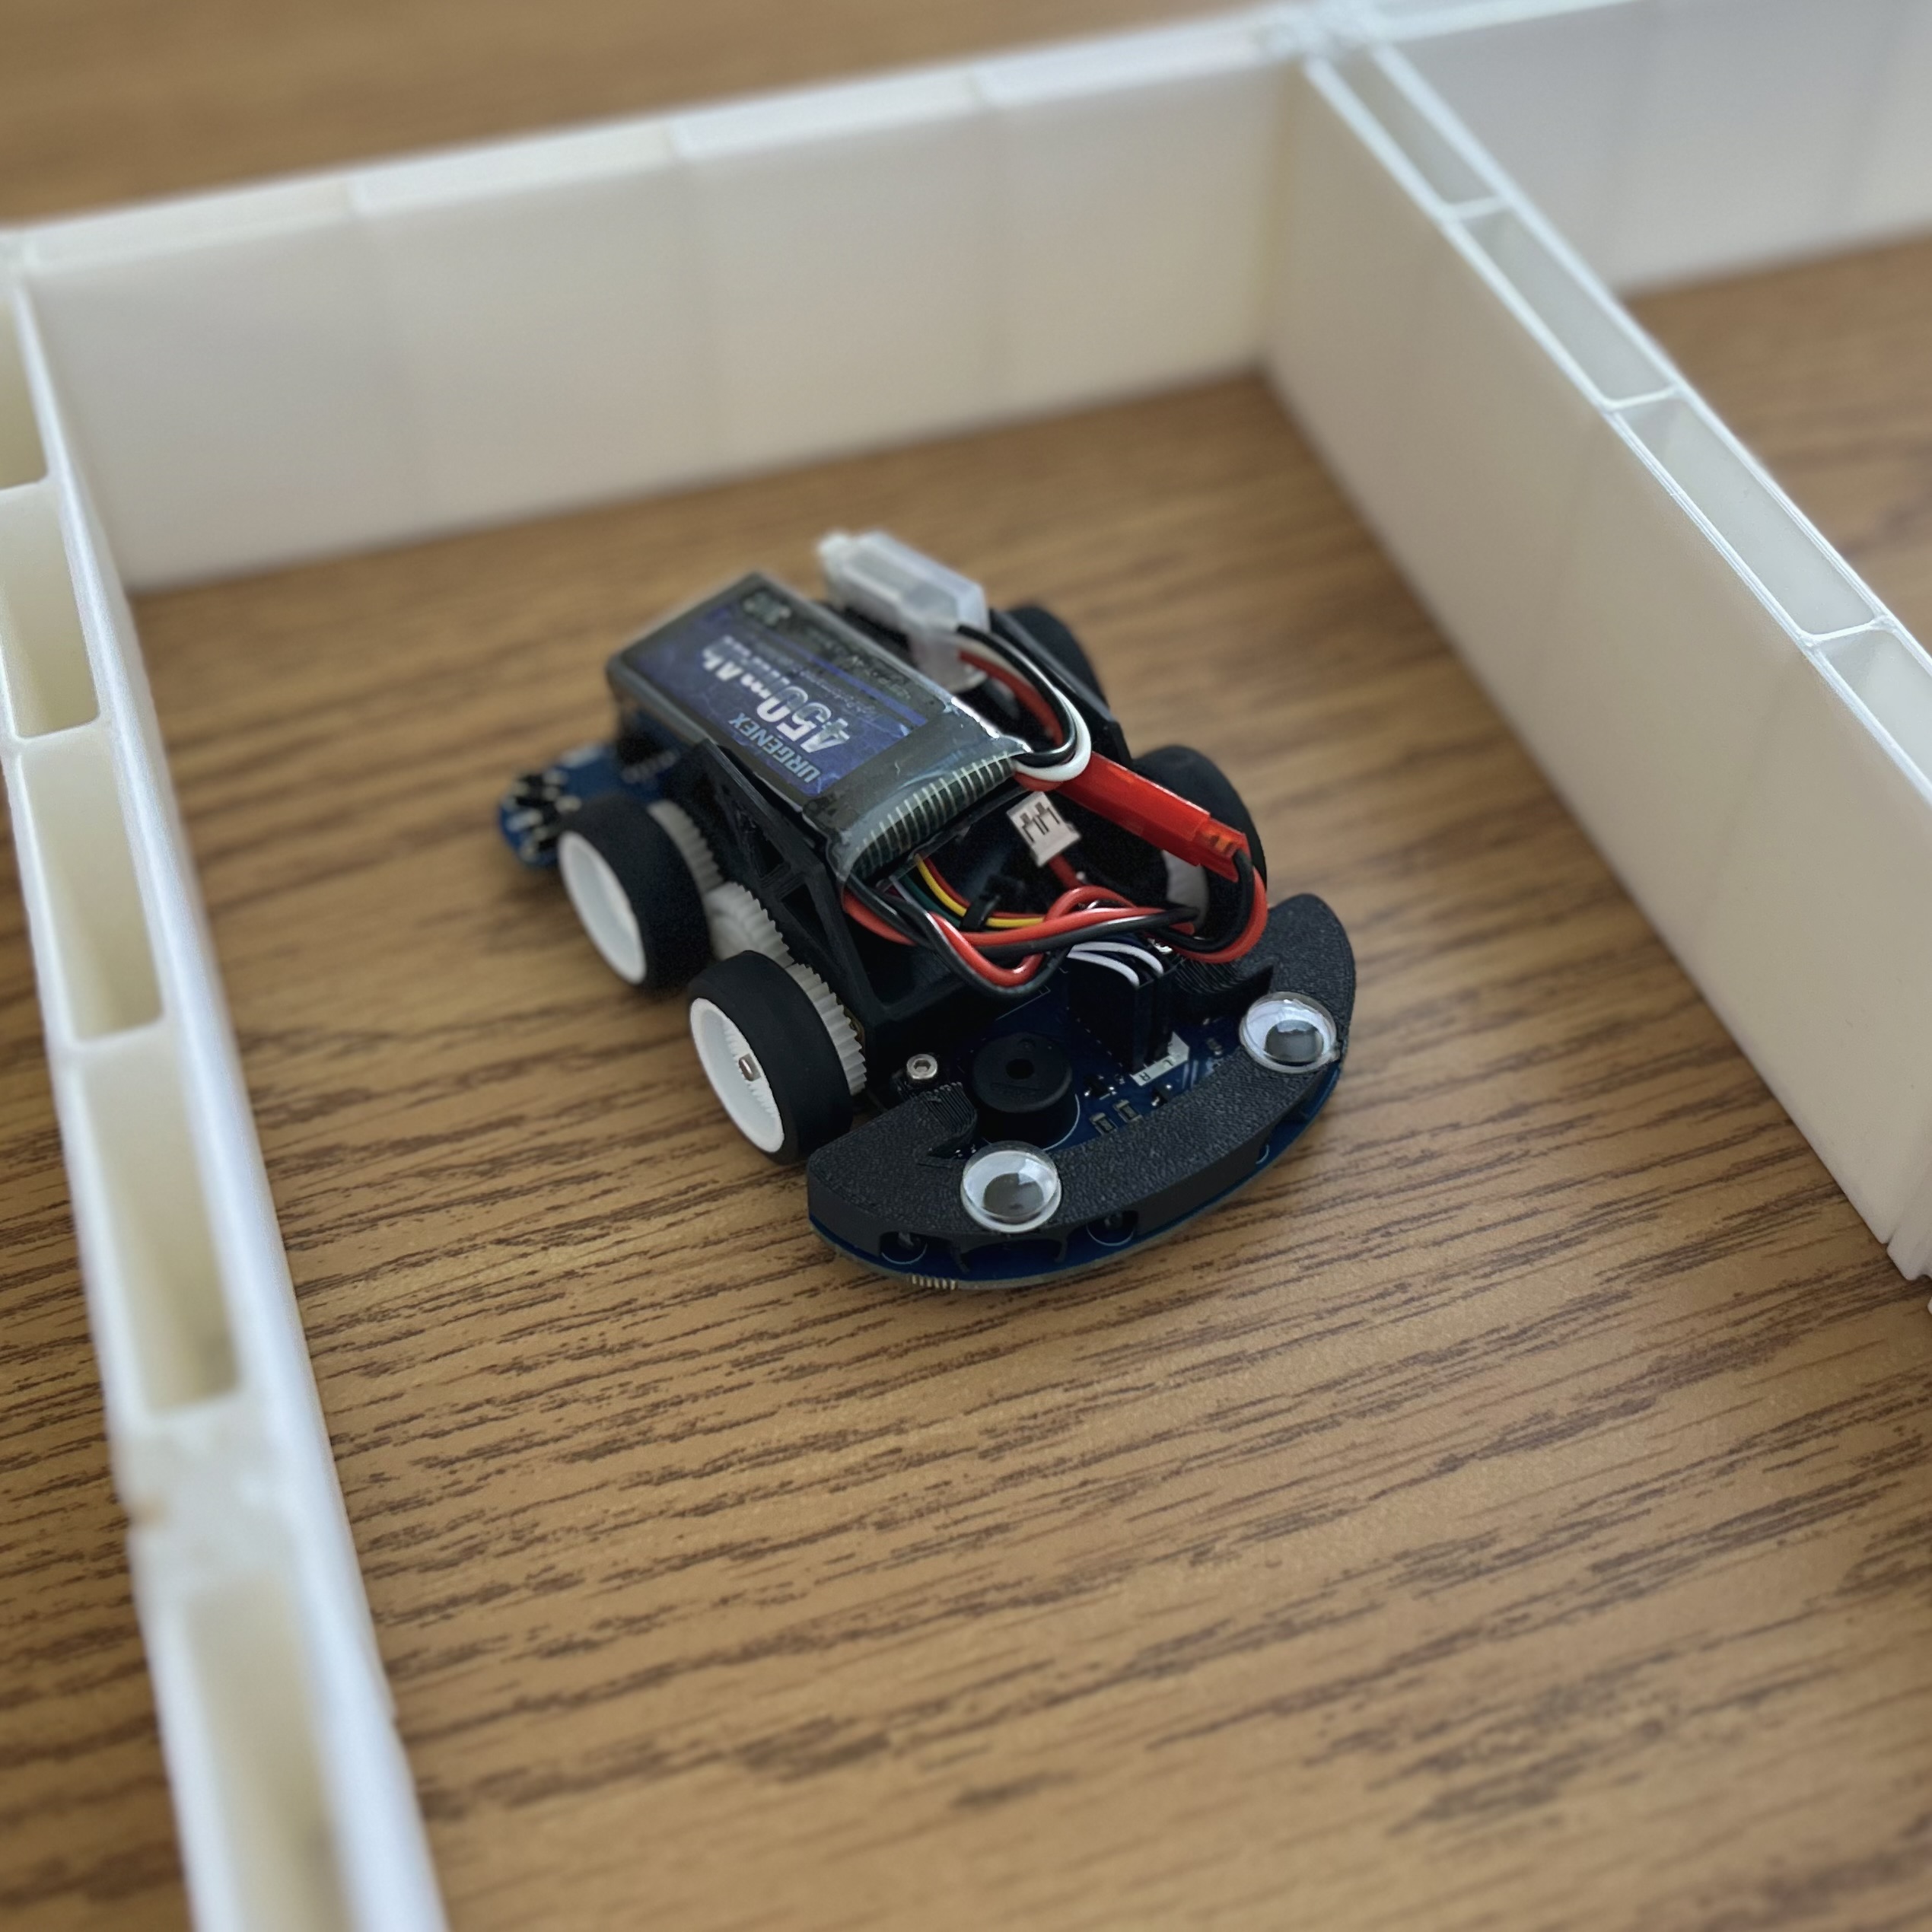
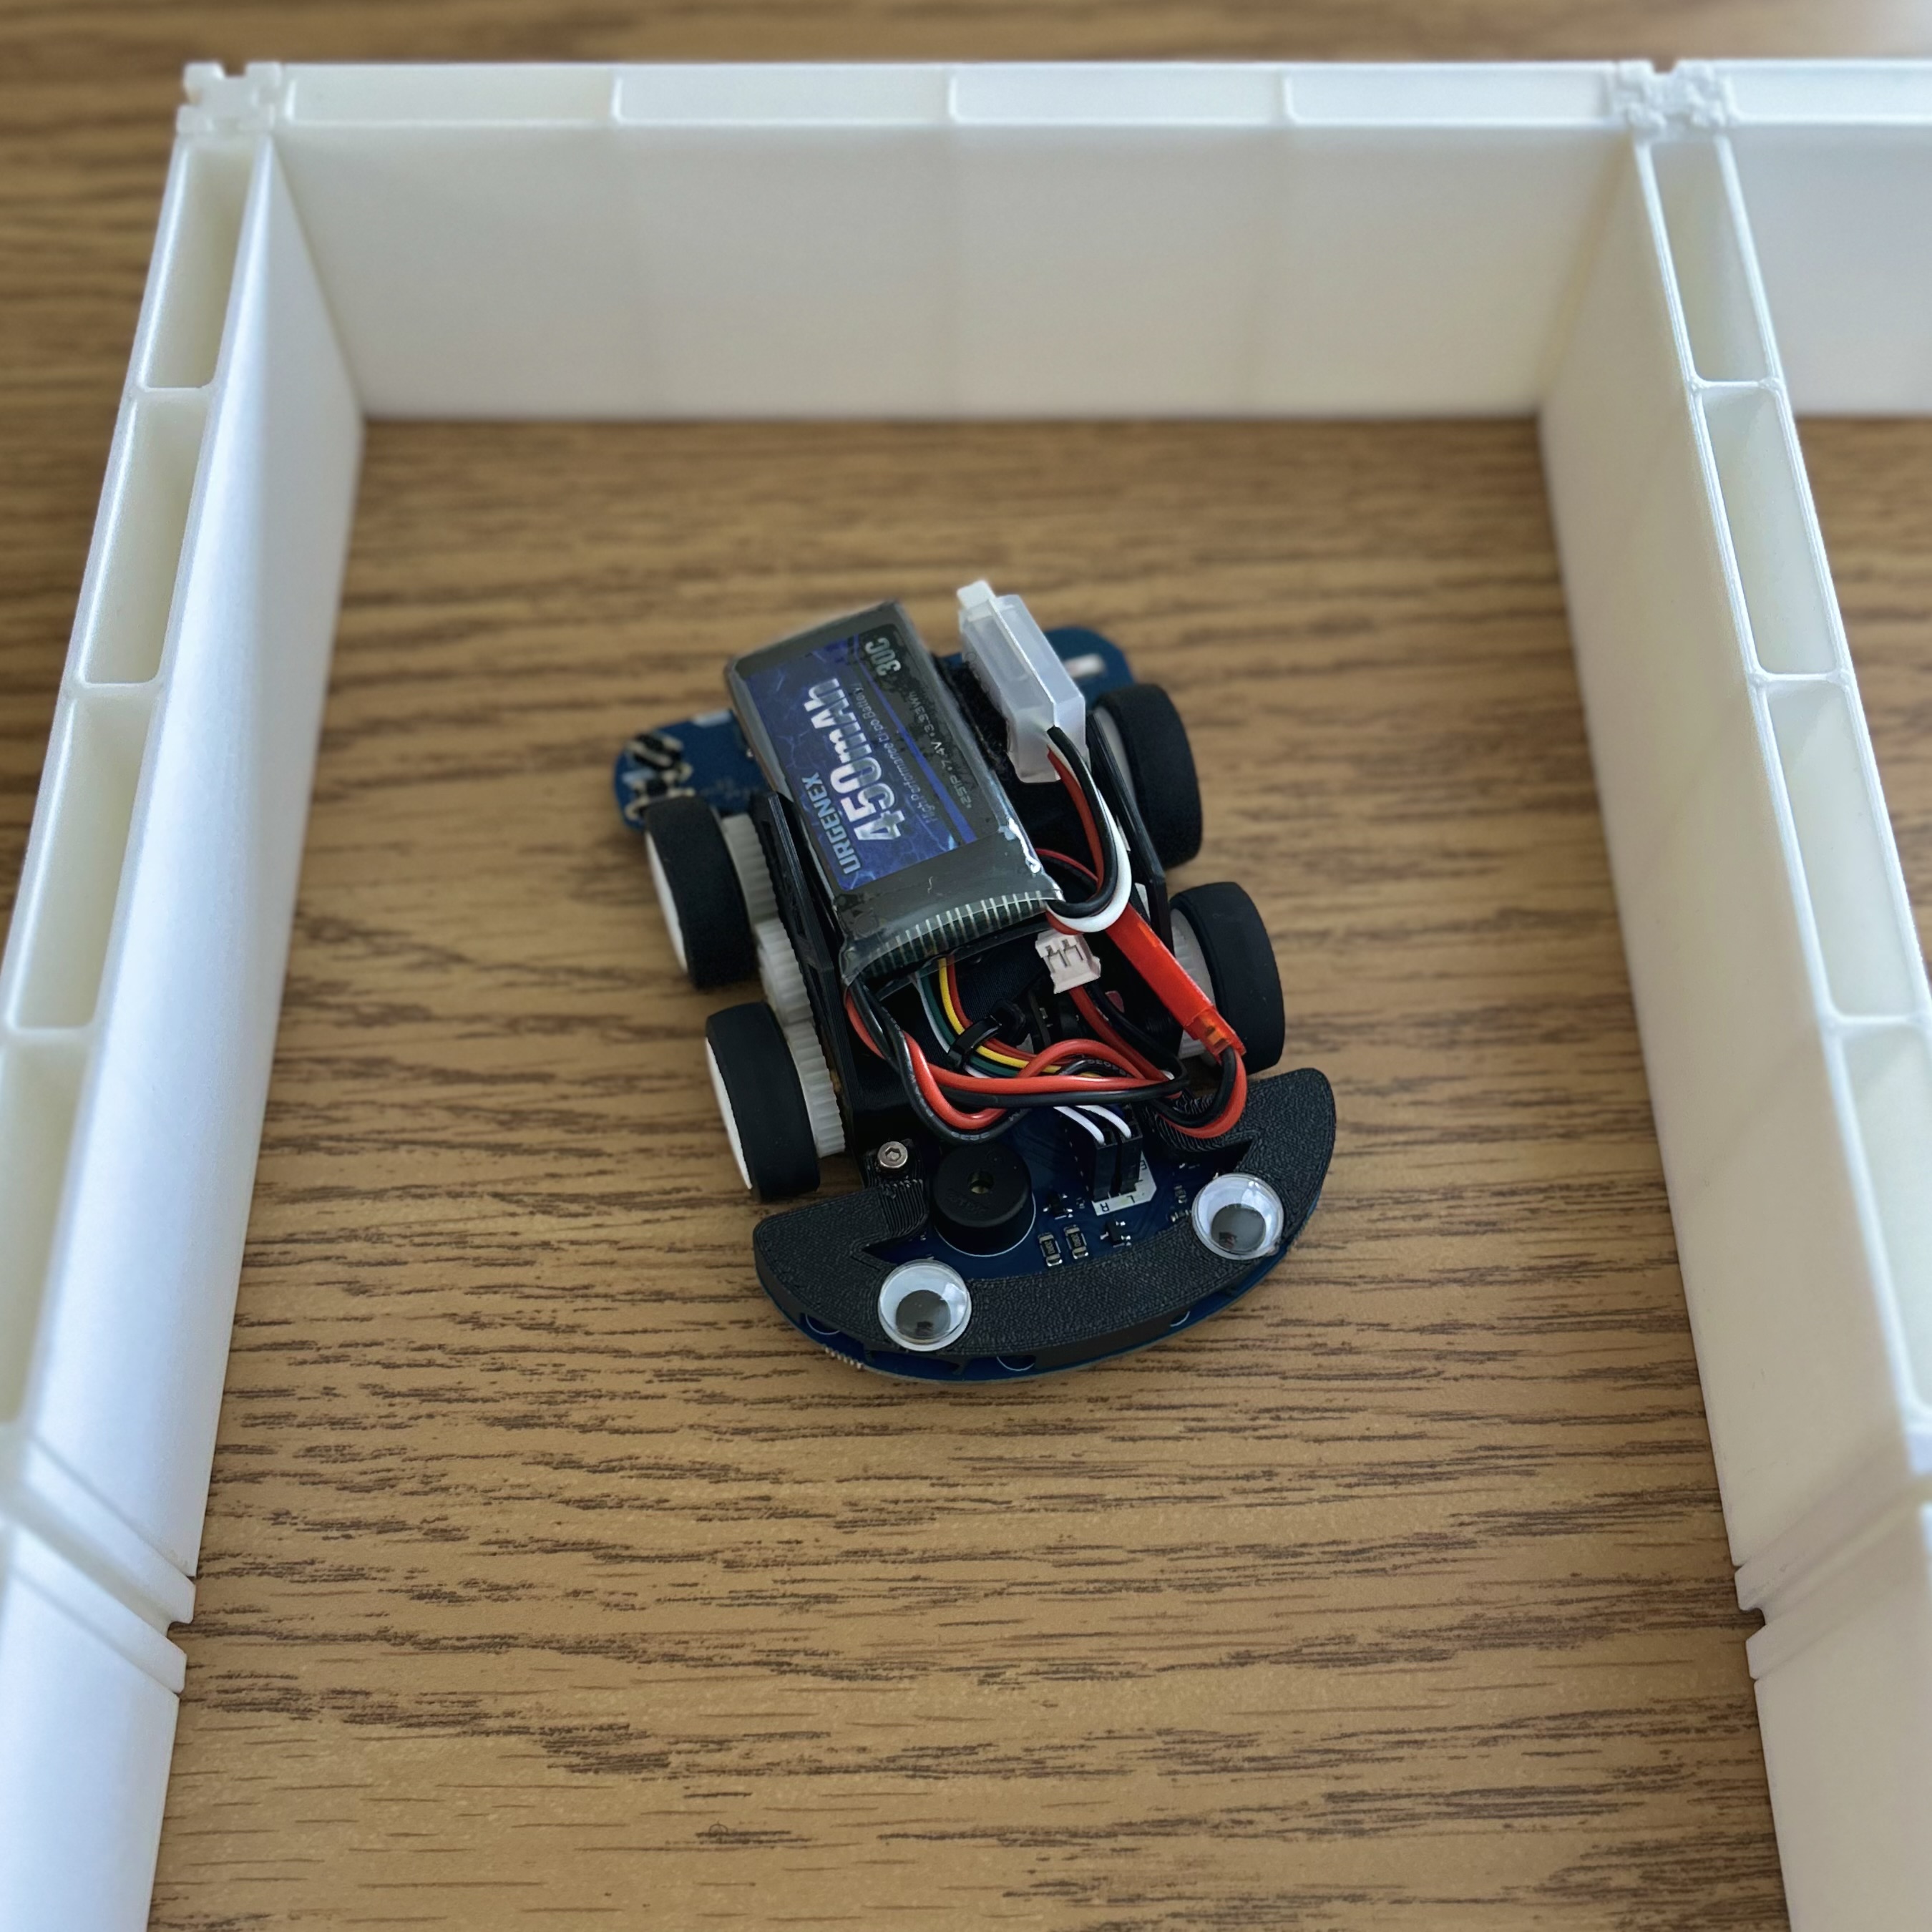
FrankenMouse is a MicroMouse robot that was designed, built, and programmed from scratch by members of the University at Buffalo's IEEE Student Branch.
Some might say that our robot resembles one of Dr. Victor Frankenstein's creations - smaller and more agile, yet equally terrifying. Thus, the name FrankenMouse was born.
The objective of a MicroMouse robot is to autonomously nativate and solve a 16x16 maze as fast as possible. To learn more about the MicroMouse competition, check out the excellent Veritasium Video on the topic.
| Name | FrankenMouse V2+3 |
|---|---|
| Length/Width/Height | 10cm/7cm/3.5cm |
| Weight | 69 g (w/o batt), 92 g (w/ batt) |
| MCU | STM32WB55CGU6 |
| Motors | 6V Micro Metal Gearmotor (20:1) |
| Encoders | Micro Metal Motor Encoder (6 pole magnetic discs) |
| Motor Driver | DRV8835 |
| IR Sensors | SFH4545 (Emitter) + TEFT4300 (Receiver) |
| IMU | ICM-42670-P |
| Tire Diameter | 2.5 cm |
| Buzzer | PS1240P02BT |
| Battery | 2S 450 mAh Li-Po |
| Voltage Regulator | TPS564208DDCR |
| Connectivity | SWD, BLE, USB-C (V2 only) |
firmware/ - Software running on the robothardware/ - PCB designs and mechanical CAD filessimulation/ - Godot-based desktop 3D simulation of the robotapp/ - iOS/macOS app for controlling the robot over BLEcli/ - Custom interactive shell with command-line tools for controlling the robot over BLEti84_controller - (Silly) TI-84 Plus CE program that communicates with the CLI over a serial connection, used to control the robotVersion 3:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 14 | 100n | Capacitor_SMD:C_0402_1005Metric | C3, C5, C6, C7, C8, C9, C10, C12, C16, C22, C23, C25, C27, C29 |
| 8 | 5k1 | Resistor_SMD:R_0402_1005Metric | R6, R8, R9, R10, R21, R22, R23, R24 |
| 6 | M2 | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4, H8, H9 |
| 5 | Q_NPN_BEC | Package_TO_SOT_SMD:SOT-23 | Q2, Q7, Q8, Q9, Q10 |
| 4 | 1k8 | Resistor_SMD:R_0603_1608Metric | R17, R18, R19, R20 |
| 4 | 20 | Resistor_SMD:R_1206_3216Metric | R13, R14, R15, R16 |
| 3 | 1.152mm | footprints:JLC_TOOLING_HOLE | H5, H6, H7 |
| 3 | 100 | Resistor_SMD:R_0402_1005Metric | R4, R5, R7 |
| 3 | 10k | Resistor_SMD:R_0402_1005Metric | R2, R11, R12 |
| 3 | 4u7 | Capacitor_SMD:C_0603_1608Metric | C4, C11, C17 |
| 2 | 10n | Capacitor_SMD:C_0402_1005Metric | C2, C26 |
| 2 | 10p | Capacitor_SMD:C_0402_1005Metric | C18, C19 |
| 2 | 22u | Capacitor_SMD:C_0805_2012Metric | C14, C15 |
| 2 | CONN_MOTOR_ENCODER | footprints:CONN_BM06B-SRSS-TB_JST | J4, J5 |
| 2 | SFH4545 | footprints:SFH4545_FLIPPED | D2, D4 |
| 2 | SFH4545 | footprints:SFH4545 | D3, D5 |
| 2 | SW_Push | Button_Switch_THT:SW_PUSH_1P1T_6x3.5mm_H5.0_APEM_MJTP1250 | SW1, SW2 |
| 2 | TEFT4300 | footprints:TEFT4300_FLIPPED | Q4, Q6 |
| 2 | TEFT4300 | footprints:TEFT4300 | Q3, Q5 |
| 2 | ~ | footprints:MOTOR_N20 | M1, M2 |
| 1 | 0p3 | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C21 |
| 1 | 0p8 | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C20 |
| 1 | 100@100MHz | Diode_SMD:D_0805_2012Metric | FB1 |
| 1 | 10n | Inductor_SMD:L_0402_1005Metric | L3 |
| 1 | 10u | Capacitor_SMD:C_1206_3216Metric | C13 |
| 1 | 10u | Inductor_SMD:L_0805_2012Metric | L2 |
| 1 | 1k | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | 1u | Capacitor_SMD:C_0603_1608Metric | C1 |
| 1 | 2n7 | Inductor_SMD:L_0402_1005Metric_Pad0.77x0.64mm_HandSolder | L4 |
| 1 | 2u2 | Inductor_SMD:L_0805_2012Metric | L1 |
| 1 | 2u2 | Capacitor_SMD:C_0603_1608Metric | C24 |
| 1 | 32MHz | footprints:XL7EL89CKI-111YLC-32M | X1 |
| 1 | 32kHz768 | Crystal:Crystal_SMD_3215-2Pin_3.2x1.5mm | X2 |
| 1 | 33k | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | AO3401A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | Antenna_Chip | footprints:ANT_2450AT42A100E | AE1 |
| 1 | Battery Conn | footprints:CONN_BATTERY | J1 |
| 1 | Conn_ST_STDC14 | footprints:SAMTEC_FTSH-107-01-L-DV-K-A | J3 |
| 1 | DLF162500LT-5028A1 | footprints:DLF162500LT-5028A1 | U3 |
| 1 | DRV8835 | footprints:DSS0012A | U6 |
| 1 | ICM-42670-P | footprints:ICM-42670-P | U4 |
| 1 | PS1240P02BT | footprints:PS1240P02BT | BZ1 |
| 1 | SS34 | Diode_SMD:D_SMA | D1 |
| 1 | STM32WB55CGU6 | Package_DFN_QFN:QFN-48-1EP_7x7mm_P0.5mm_EP5.6x5.6mm | U2 |
| 1 | TPS564208DDCR | Package_TO_SOT_SMD:TSOT-23-6 | U1 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U5 |
| 1 | USB_C_Receptacle_USB2.0_16P | footprints:USB_C_16P_QTGM027 | J2 |
UBIEEE/FrankenMouse
FrankenMouse is a MicroMouse robot that was designed, built, and programmed from scratch by members of the University at Buffalo's IEEE Student Branch.

vorlaxen-labs/AratMicro
High-performance, open-source micromouse robot platform built for Robosam and MEB Robot (Ministry of National Education Robotics Competition, Turkey).


arsovskiteodor/A.ProdDeck
Open-hardware macro pad (WIP): custom KiCad PCB with keys, encoders and a fader, plus firmware and a desktop configurator


ChristopherAwomolo/Nova-Micromouse
Newer version based off the Futura Micromouse


Maahi-V/26-27-UCI-Kit-Micromouse
Kit Mouse Schematic and Layout for the 2026-27 Micromouse IEEE program
It measures 70 × 99.9 mm and has 4 copper layers, 1.61 mm thick.
100 parts, built around the STM32WB55CGU6, DLF162500LT-5028A1, DRV8835DSS and ICM-42670-P. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the UBIEEE/FrankenMouse repository on GitHub, at the commit this page was made from: the board is hardware/mouse_v2/pcb/micromouse.kicad_pcb and its schematic hardware/mouse_v2/pcb/micromouse.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).