2 layers87.6 × 83.8 mm
ENEL200Group01
cva68/ESPBreadboardRobot
Peripheral and breakout board for the ESP-32, with firmware designed for use with Microsoft MakeCode
88 parts2MIT
 TheBroKendrick/Arduino-Turtle-Robot-
A project made in my First Professional Year of Electrical Engineering. This was made in collaboration with two other people and focussed on the basics of PCB design, 3D modelling, and basic embedded software development.
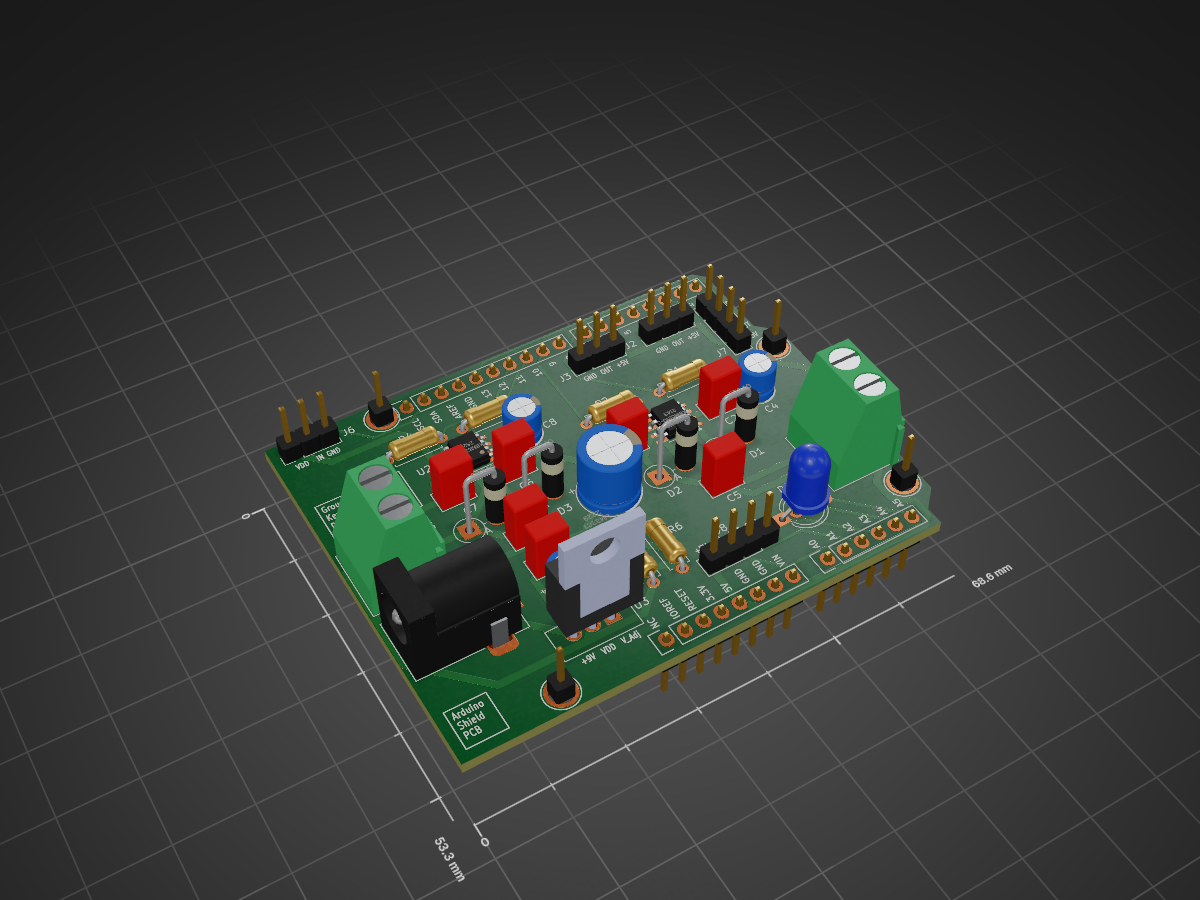
ENEL200ShieldGroup01 is an open-source printed circuit board by TheBroKendrick, from the TheBroKendrick/Arduino-Turtle-Robot- repository on GitHub. It is a 2-layer board of 68.6 × 53.3 mm with 41 parts on 41 nets, routed with 175 tracks and 0 vias.
It is built around the ZXBM5210-S, LM338T and SR240, with the SG90 among its other parts. Its parts include 12 connectors, 11 capacitors, 6 resistors, 5 diodes and 3 ICs.


The Logo programming language brought to life. Using simple commands such as "LEFT" and "RIGHT" you can command this robot to do exactly that. This was my first project integrating electronics, software, and mechanical engineering together. Many concepts were learned and applied such as interrupts, software debouncing, 3D modelling, and single-layer PCB design.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 100n | Capacitor_THT:C_Rect_L4.6mm_W3.0mm_P2.50mm_MKS02_FKP02 | C2, C3, C5, C6, C7, C9, C11 |
| 5 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2, R3, R4, R6 |
| 4 | CONN_01X01 | Socket_Arduino_Uno:Mounting_Hole | H1, H2, H3, H4 |
| 4 | SR240 | Diode_THT:D_DO-15_P3.81mm_Vertical_AnodeUp | D1, D2, D3, D4 |
| 2 | 10u | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C4, C8 |
| 2 | HC-020K | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J2, J3 |
| 2 | HC-SR04 U | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J7, J8 |
| 2 | UC_Screw_Terminal_01X02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J4, J5 |
| 2 | ZXBM5210-S | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1, U2 |
| 1 | 100u | Capacitor_THT:CP_Radial_D8.0mm_P3.50mm | C1 |
| 1 | 1uF | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C10 |
| 1 | 8.2k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R5 |
| 1 | Analog | Socket_Arduino_Uno:Socket_Strip_Arduino_1x06 | P2 |
| 1 | Barrel_Jack_Switch | Connector_BarrelJack:BarrelJack_Horizontal | J1 |
| 1 | Digital | Socket_Arduino_Uno:Socket_Strip_Arduino_1x10 | P3 |
| 1 | Digital | Socket_Arduino_Uno:Socket_Strip_Arduino_1x08 | P4 |
| 1 | LM338T | LM338T:TO254P1054X470X1955-3 | U3 |
| 1 | Power | Socket_Arduino_Uno:Socket_Strip_Arduino_1x08 | P1 |
| 1 | SG90 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | UC_LED_RGB | LED_THT:LED_D5.0mm-4_RGB_Wide_Pins | D5 |
cva68/ESPBreadboardRobot
Peripheral and breakout board for the ESP-32, with firmware designed for use with Microsoft MakeCode

TDLOGY/HW_AC-DC-Flyback-5W-5V1A-Reference-Design
AC DC Flyback 5W 5V1A Reference Design


varnikaa12/PSU-IME-1
Design of an MVP tabletop production cell that sorts small colored cylinders representing workpieces in a manufacturing line.


RoboticsBrno/Robutek
Robůtek je robotická platforma založená na čipu ESP32-S3. Je velice rozšitiřelný, ale ze základu umí jezdit, kreslit fixou, jezdit po čáře, pohybovat se bludištěm. Programování je přes Jaculus.
It measures 68.6 × 53.3 mm and has 2 copper layers, 1.6 mm thick.
41 parts, built around the ZXBM5210-S, LM338T, SR240 and SG90. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the TheBroKendrick/Arduino-Turtle-Robot- repository on GitHub, at the commit this page was made from: the board is Schematics/ENEL200ShieldGroup01.kicad_pcb and its schematic Schematics/ENEL200ShieldGroup01.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask TheBroKendrick before reusing the design.