2 layers86.4 × 54.6 mm

 PREDICT-EPFL/RoboCape4
This repository is dedicated to a Beaglebone cape extension developped at EPFL in the Automatic Control Laboratory.
RoboCape is an open-source printed circuit board by PREDICT-EPFL, from the PREDICT-EPFL/RoboCape repository on GitHub. It is a 4-layer board of 86.4 × 54.6 mm with 114 parts on 184 nets, routed with 1,288 tracks and 152 vias.
It is built around the SN65HVD232D, MS5611-01BA03 and PCA9685PW, with the BQ32000D, MPU-9250 and TPS22929DDBV among its other parts. Its parts include 40 resistors, 26 capacitors, 11 ICs, 6 diodes and 2 inductors.


This repository is dedicated to a Beaglebone cape extension developped at EPFL in the Automatic Control Laboratory. The idea of this platform is to allow the user to transform any mechanically actuated platform, for example a RC car or a quadcopter base, into a robotic vehicle that can be controlled by a remote server.
The repository contains all the design files of the Beaglebone cape extension.
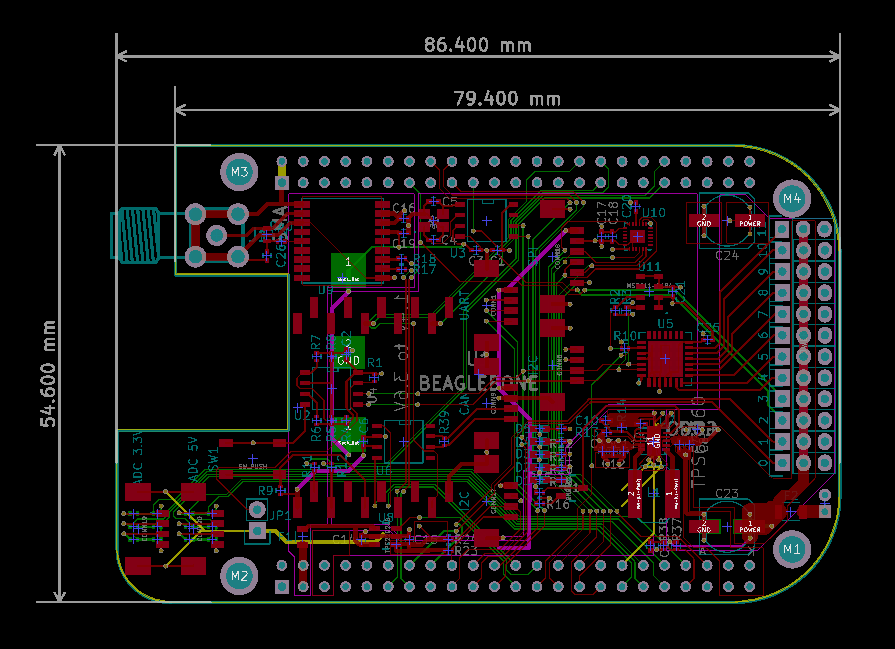
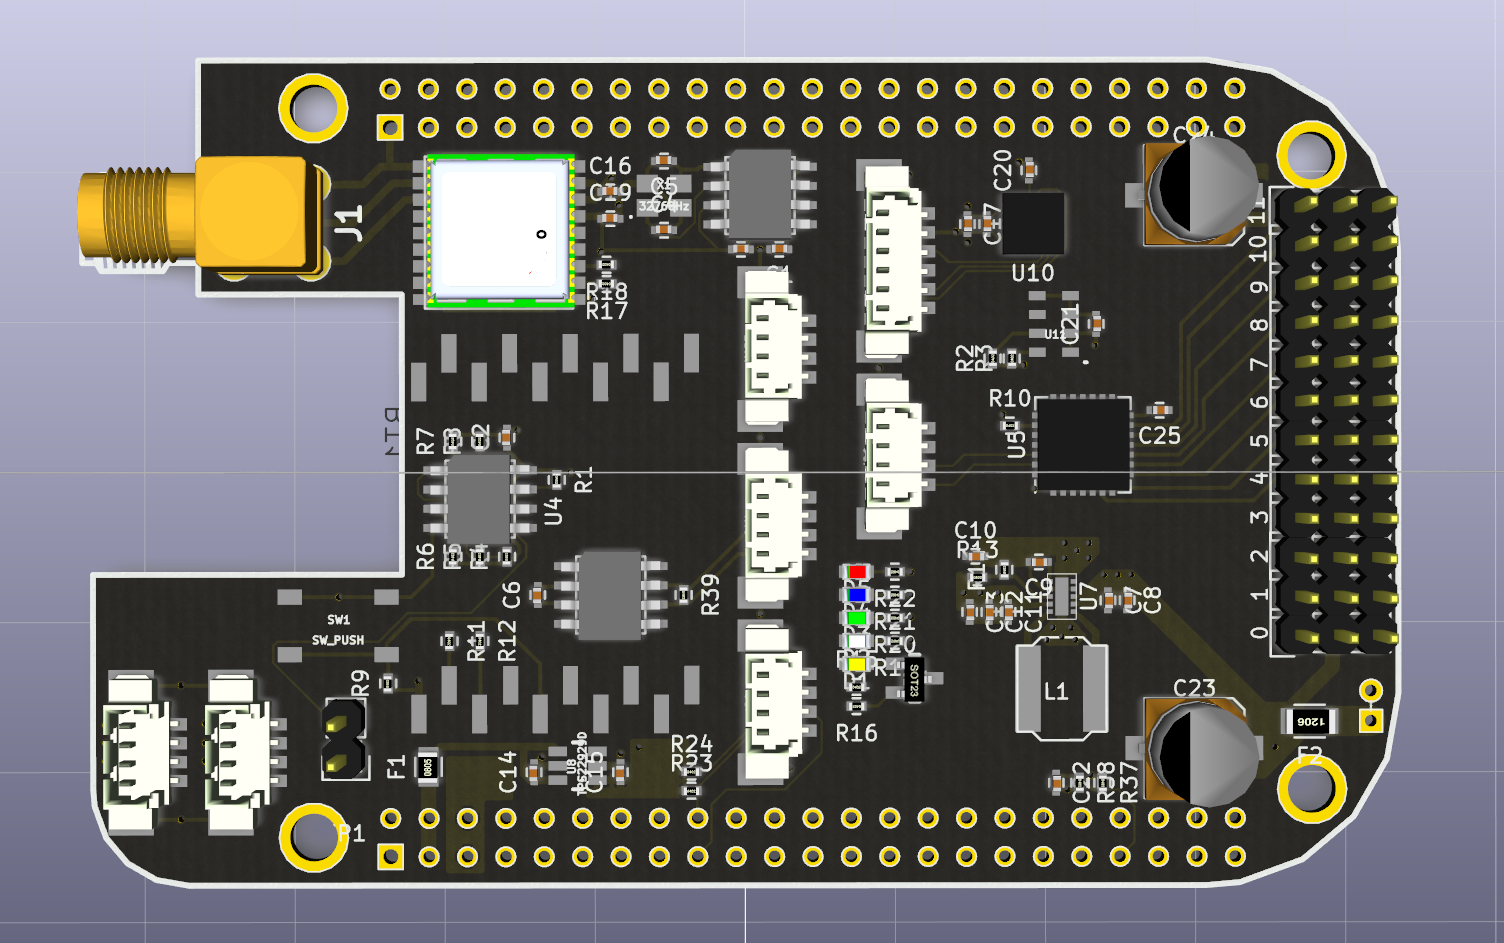
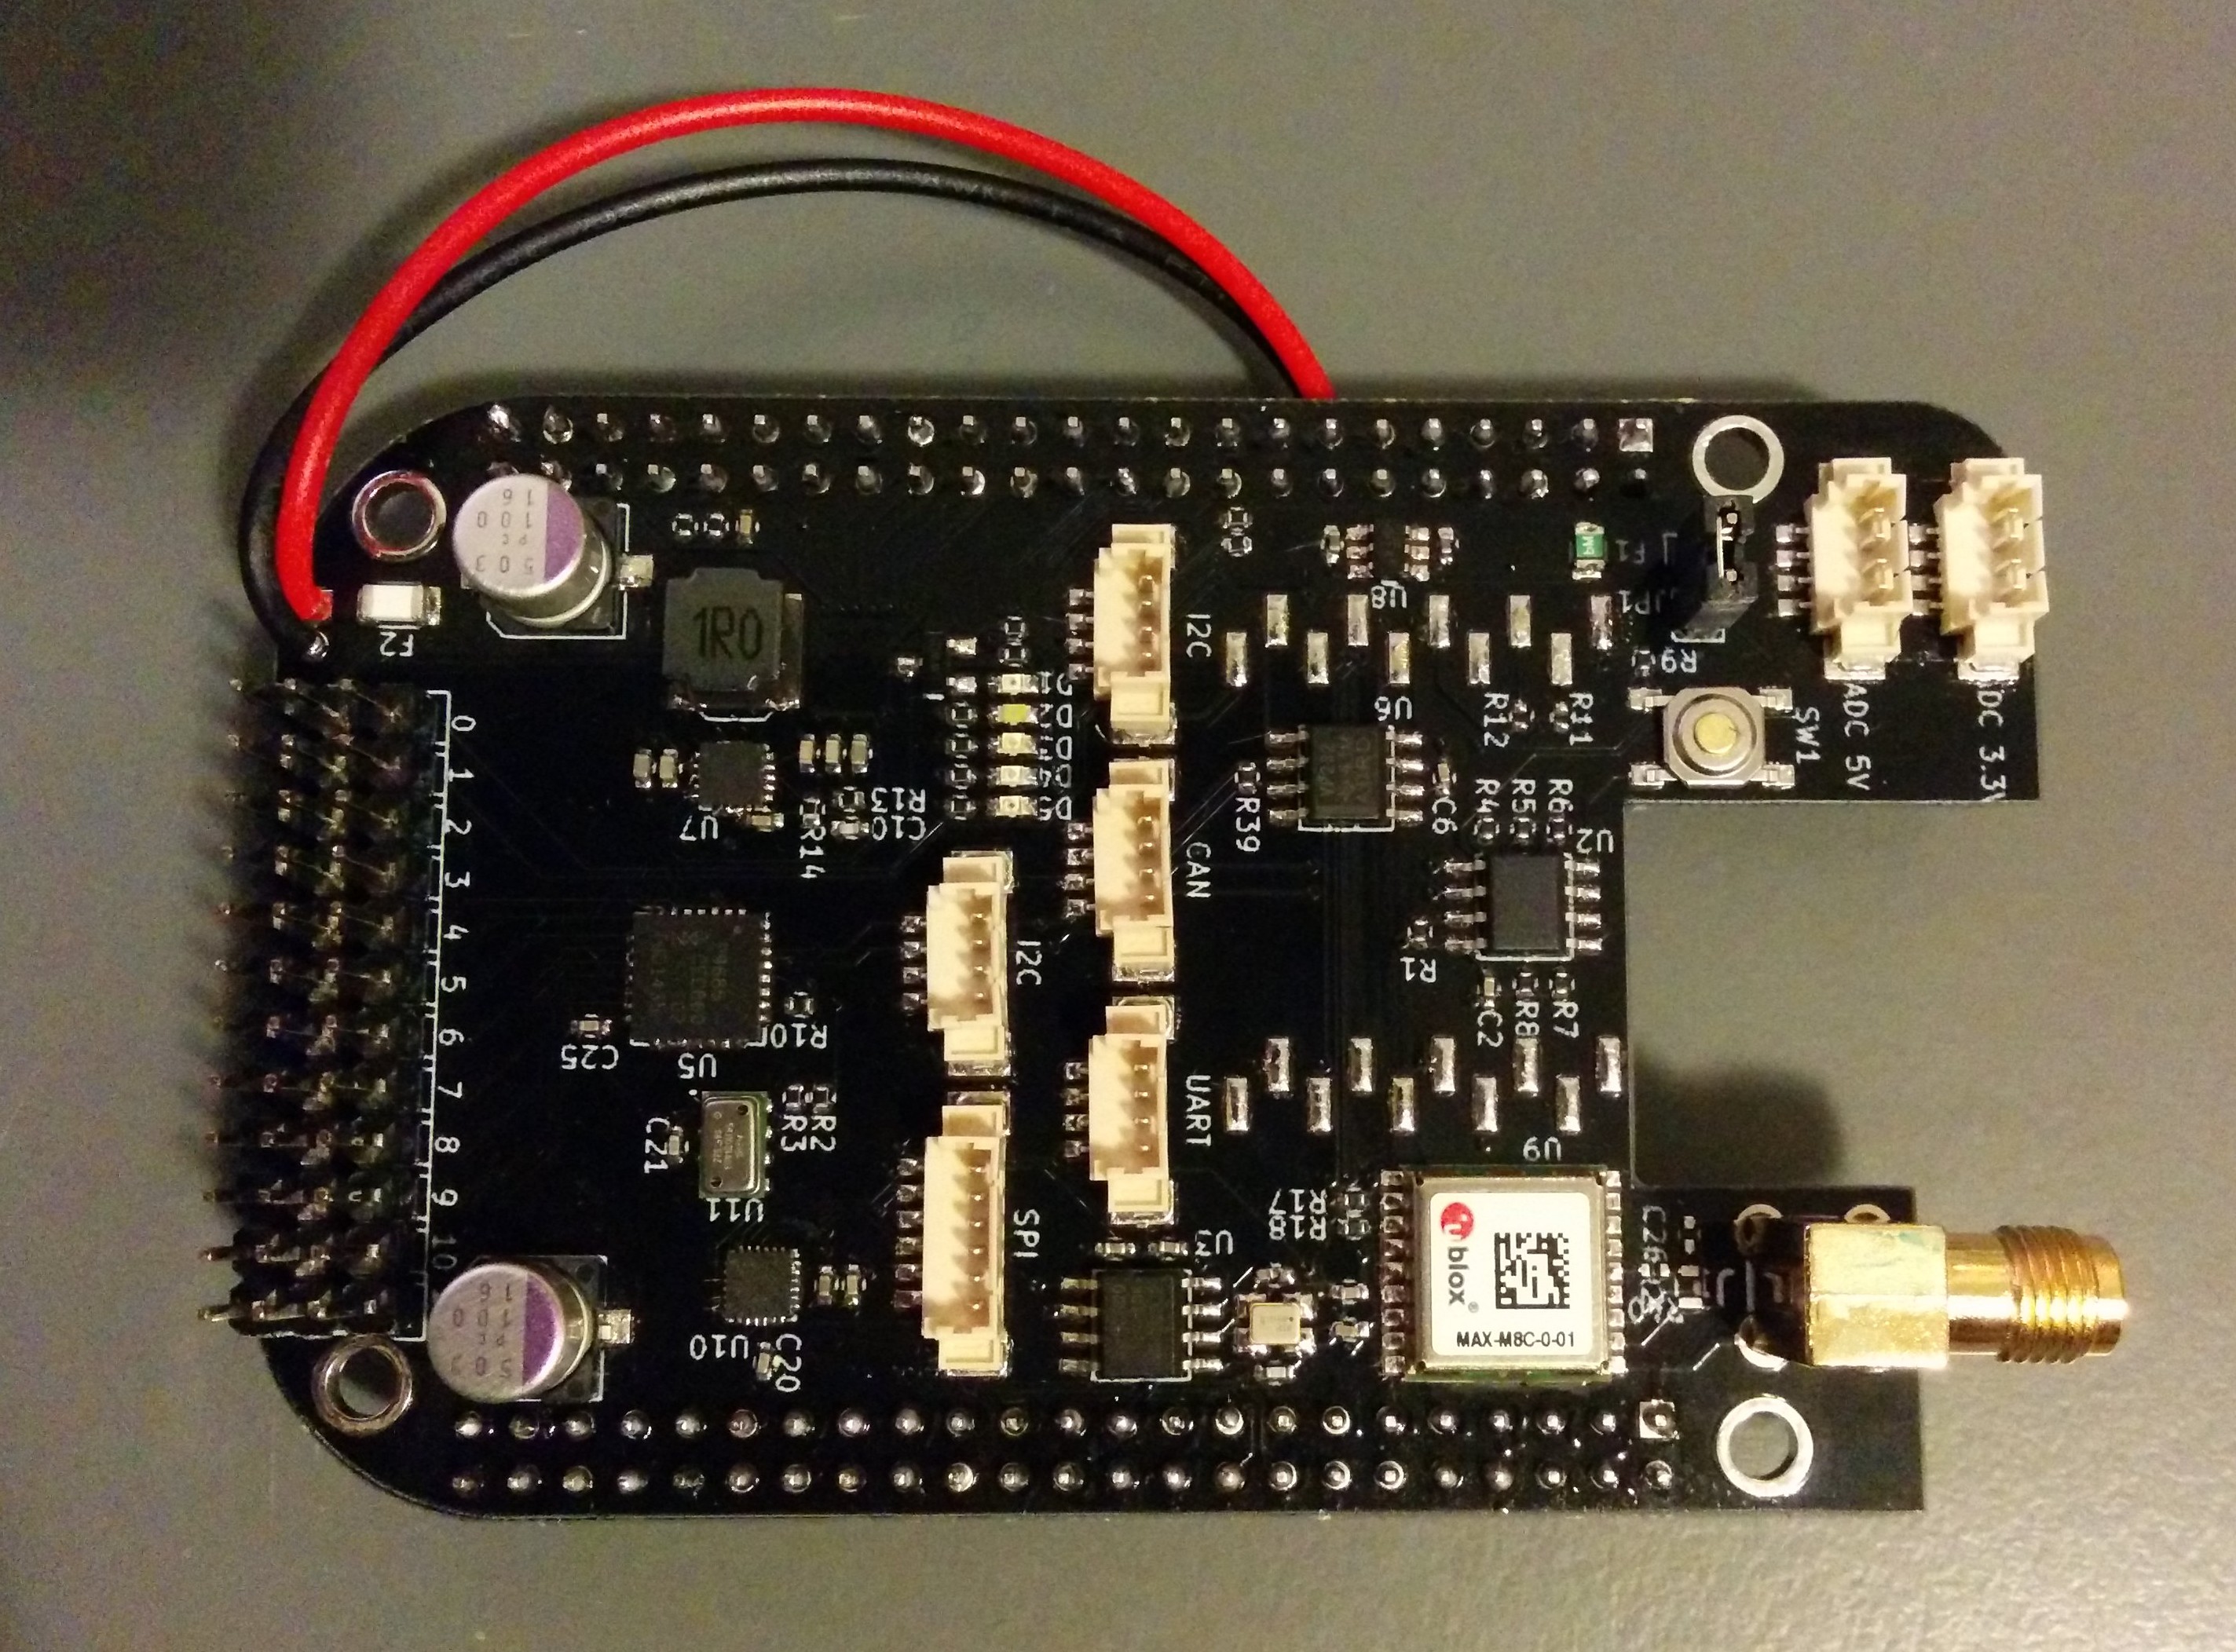

This project is released under the Creative Commons CC-BY-4.0 license. See http://creativecommons.org/licenses/by/4.0/ for details.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | SERVO | Pin_Headers:Pin_Header_Straight_1x03 | 0, 1, 2, 3, 4, 5, 6, 7, 8, 9, 10, 11 |
| 8 | 100n | Capacitors_SMD:C_0402 | C2, C6, C9, C17, C20, C21, C22, C25 |
| 8 | 4.7k | Resistors_SMD:R_0402 | R2, R3, R4, R5, R6, R23, R24, R37 |
| 7 | 820 | Resistors_SMD:R_0402 | R26, R28, R30, R32, R34, R36, R38 |
| 5 | 1k | Resistors_SMD:R_0402 | R16, R19, R20, R21, R22 |
| 4 | 330 | Resistors_SMD:R_0402 | R11, R12, R17, R18 |
| 3 | 1.47k | Resistors_SMD:R_0402 | R31, R33, R35 |
| 3 | 10p | Capacitors_SMD:C_0402 | C4, C5, C10 |
| 3 | 1u | Capacitors_SMD:C_0402 | C1, C14, C15 |
| 3 | 22u | Capacitors_SMD:C_0402 | C11, C12, C13 |
| 3 | 680 | Resistors_SMD:R_0402 | R25, R27, R29 |
| 2 | 0 | Resistors_SMD:R_0402 | R7, R8 |
| 2 | 0.1u | Capacitors_SMD:C_0402 | C16, C19 |
| 2 | 100u | Capacitors_SMD:c_elec_6.3x7.7 | C23, C24 |
| 2 | 10k | Resistors_SMD:R_0402 | R1, R10 |
| 2 | 10u | Capacitors_SMD:C_0402 | C7, C8 |
| 2 | 1M | Resistors_SMD:R_0402 | R13, R15 |
| 2 | I2C | _connectors:_Molex-PicoBlade-SMD-4 | CONN5, CONN17 |
| 1 | 1.4V to 3.6V | _connectors:BK-885 | BT1 |
| 1 | 10 | Resistors_SMD:R_0402 | R40 |
| 1 | 10A | Resistors_SMD:R_1206 | F2 |
| 1 | 10n | Capacitors_SMD:C_0402 | C18 |
| 1 | 111k | Resistors_SMD:R_0402 | R14 |
| 1 | 120 | Resistors_SMD:R_0402 | R39 |
| 1 | 1uH | inductors:Laird_TYS6045 | L1 |
| 1 | 220n | Capacitors_SMD:C_0402 | C3 |
| 1 | 2N7002 | _std:_SOT23-3 | Q1 |
| 1 | 32768Hz | _div:_TSX-3225-SMD-XTAL | X1 |
| 1 | 500mA | Resistors_SMD:R_0805 | F1 |
| 1 | 50k | Resistors_SMD:R_0402 | R9 |
| 1 | ADC 3.3V | _connectors:_Molex-PicoBlade-SMD-4 | CONN19 |
| 1 | ADC 5V | _connectors:_Molex-PicoBlade-SMD-4 | CONN20 |
| 1 | BEAGLEBONE | _beaglebone:BEAGLEBONE | U1 |
| 1 | BLUE | LEDs:LED-0603 | D4 |
| 1 | BQ32000 | SMD_Packages:SOIC-8-N | U3 |
| 1 | C | Capacitors_SMD:C_0402 | C26 |
| 1 | CAN | _connectors:_Molex-PicoBlade-SMD-4 | CONN9 |
| 1 | CAT24C256W | SMD_Packages:SOIC-8-N | U2 |
| 1 | GREEN | LEDs:LED-0603 | D3 |
| 1 | Jumper_NC_Small | Pin_Headers:Pin_Header_Straight_1x02 | JP1 |
| 1 | L | Resistors_SMD:R_0603 | L2 |
| 1 | LOGO | _logo:EPFL-LOGO | G*** |
| 1 | MAX-M8 | _sensors:MAX-M8 | U9 |
| 1 | MPU-9250 | Housings_DFN_QFN:QFN-24-1EP_3x3mm_Pitch0.4mm | U10 |
| 1 | MS5611-01BA | _sensors:_MS5611-01BA | U11 |
| 1 | PCA9685 | Housings_DFN_QFN:QFN-28-1EP_6x6mm_Pitch0.65mm | U5 |
| 1 | PWR | _connectors:_Pin2mm_2 | CONN16 |
| 1 | RED | LEDs:LED-0603 | D5 |
| 1 | SMA | _connectors:SMA-CONN | J1 |
| 1 | SN65HVD232D | SMD_Packages:SOIC-8-N | U6 |
| 1 | SPI | _connectors:_Molex-PicoBlade-SMD-6 | CONN18 |
| 1 | SW_PUSH | _div:_PTS525SK15-SMT-Pushbutton | SW1 |
| 1 | TPS22929D | _std:_TSOT23-6 | U8 |
| 1 | TPS63060 | _std:SON-10 | U7 |
| 1 | UART | _connectors:_Molex-PicoBlade-SMD-4 | CONN1 |
| 1 | WHITE | LEDs:LED-0603 | D2 |
| 1 | XBee_Header | _connectors:Xbee_Header_SMD | U4 |
| 1 | YELLOW | LEDs:LED-0603 | D1 |
| 1 | ZENER 12V | Diodes_SMD:Diode-SMA_Standard | D6 |


bouquettttt/custom-expansion-board
Custom PCB expansion board designed for Raspberry Pi 4 integration, featuring dsPIC18, optocouplers, and power regulation stages.


SunnyYoshimitsu/Reconfigurable-Space-Compute-Cluster
Here will be the repository for an "extremely reconfigurable satellite" aimed toward at competing in NASA Minds and hopefully assist Artemis in its missions.
It measures 86.4 × 54.6 mm and has 4 copper layers, 1.6 mm thick.
114 parts, built around the SN65HVD232D, MS5611-01BA03, PCA9685PW and BQ32000D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the PREDICT-EPFL/RoboCape repository on GitHub, at the commit this page was made from: the board is robocape.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask PREDICT-EPFL before reusing the design.