
8 layers35 × 35 mm
OpenAIO
OpenDrone-hw/OpenAIO
Open-source AIO for 2-6S toothpick quads: flight controller, 4-in-1 AM32 ESC and ExpressLRS receiver, 25.5x25.5 mm.
343 parts19CERN-OHL-S-2.0

 OpenDrone-hw/OpenAIO-Whoop13
Open-source 1S whoop AIO: flight controller, 4-channel brushless ESC, ExpressLRS receiver and analog VTX, 25.5x25.5 mm. Planned.
OpenAIO Whoop is an open-source printed circuit board by OpenDrone-hw, from the OpenDrone-hw/OpenAIO-Whoop repository on GitHub, published under the CERN-OHL-S-2.0 licence. It is an 8-layer board of 28.9 × 28.9 mm with 249 parts on 246 nets, routed with 1,207 tracks and 2,944 vias.
It is built around the EFM8BB51F16I-C-QFN20R, ESP32-PICO-V3 and RP2354A, with the RTC6705, SE5004L-R and 2450FM07D0034T among its other parts. Its parts include 96 capacitors, 67 resistors, 17 connectors, 14 transistors and 12 ICs. It belongs with the robots and motor control boards and the ESP32, RP2350, RISC-V and Silicon Labs (EFR32, EFM) boards of this library.


An all-in-one board for 1S: 65 and 75 mm tiny whoops, 1S toothpicks and 1S long range on an 18650. Flight controller, four brushless ESC channels, an ExpressLRS receiver and an onboard analog VTX on the 25.5 x 25.5 mm whoop mounting pattern. The 1S sibling of OpenAIO, which covers 3S to 6S on the same mounting pattern.
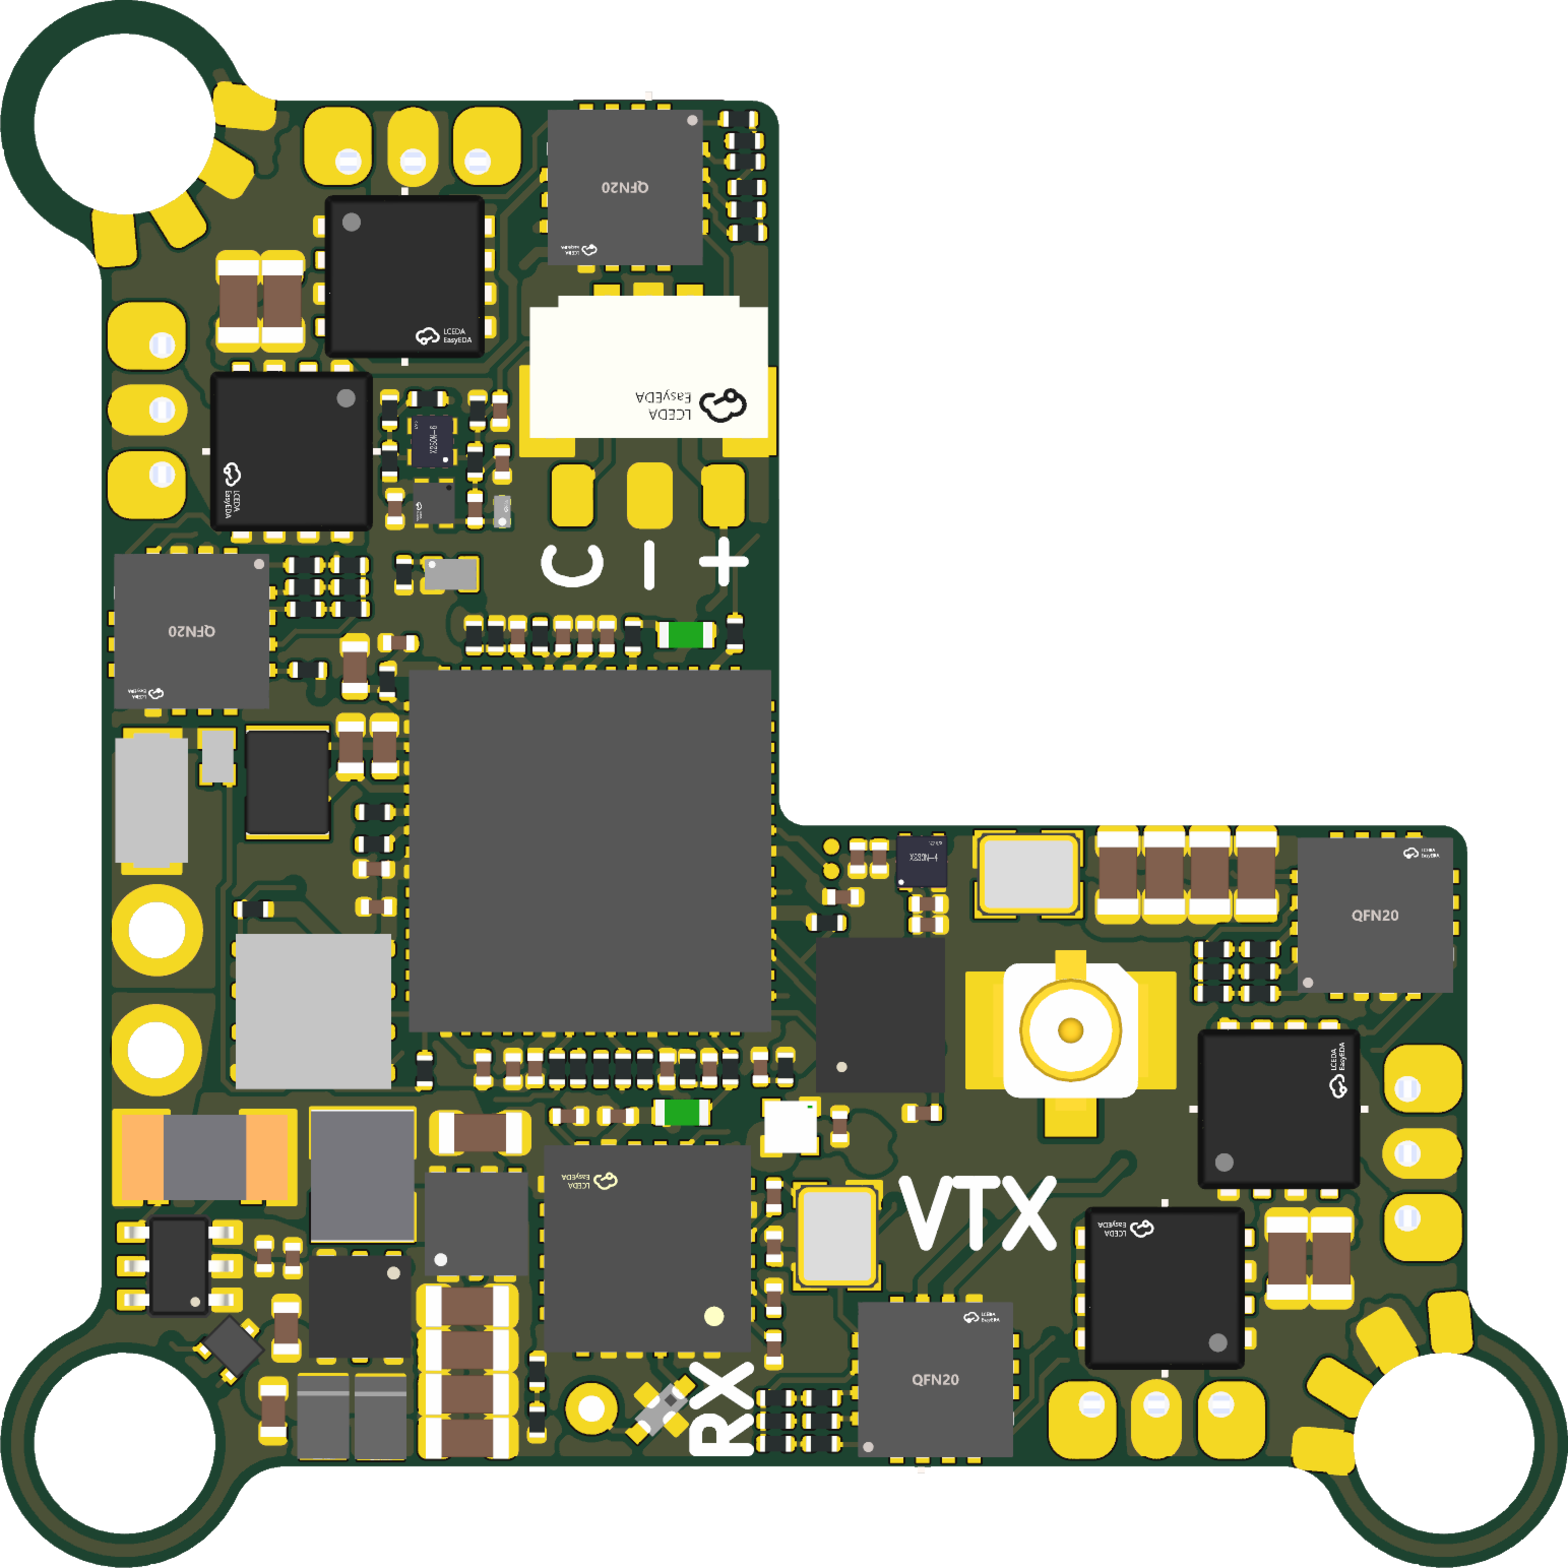
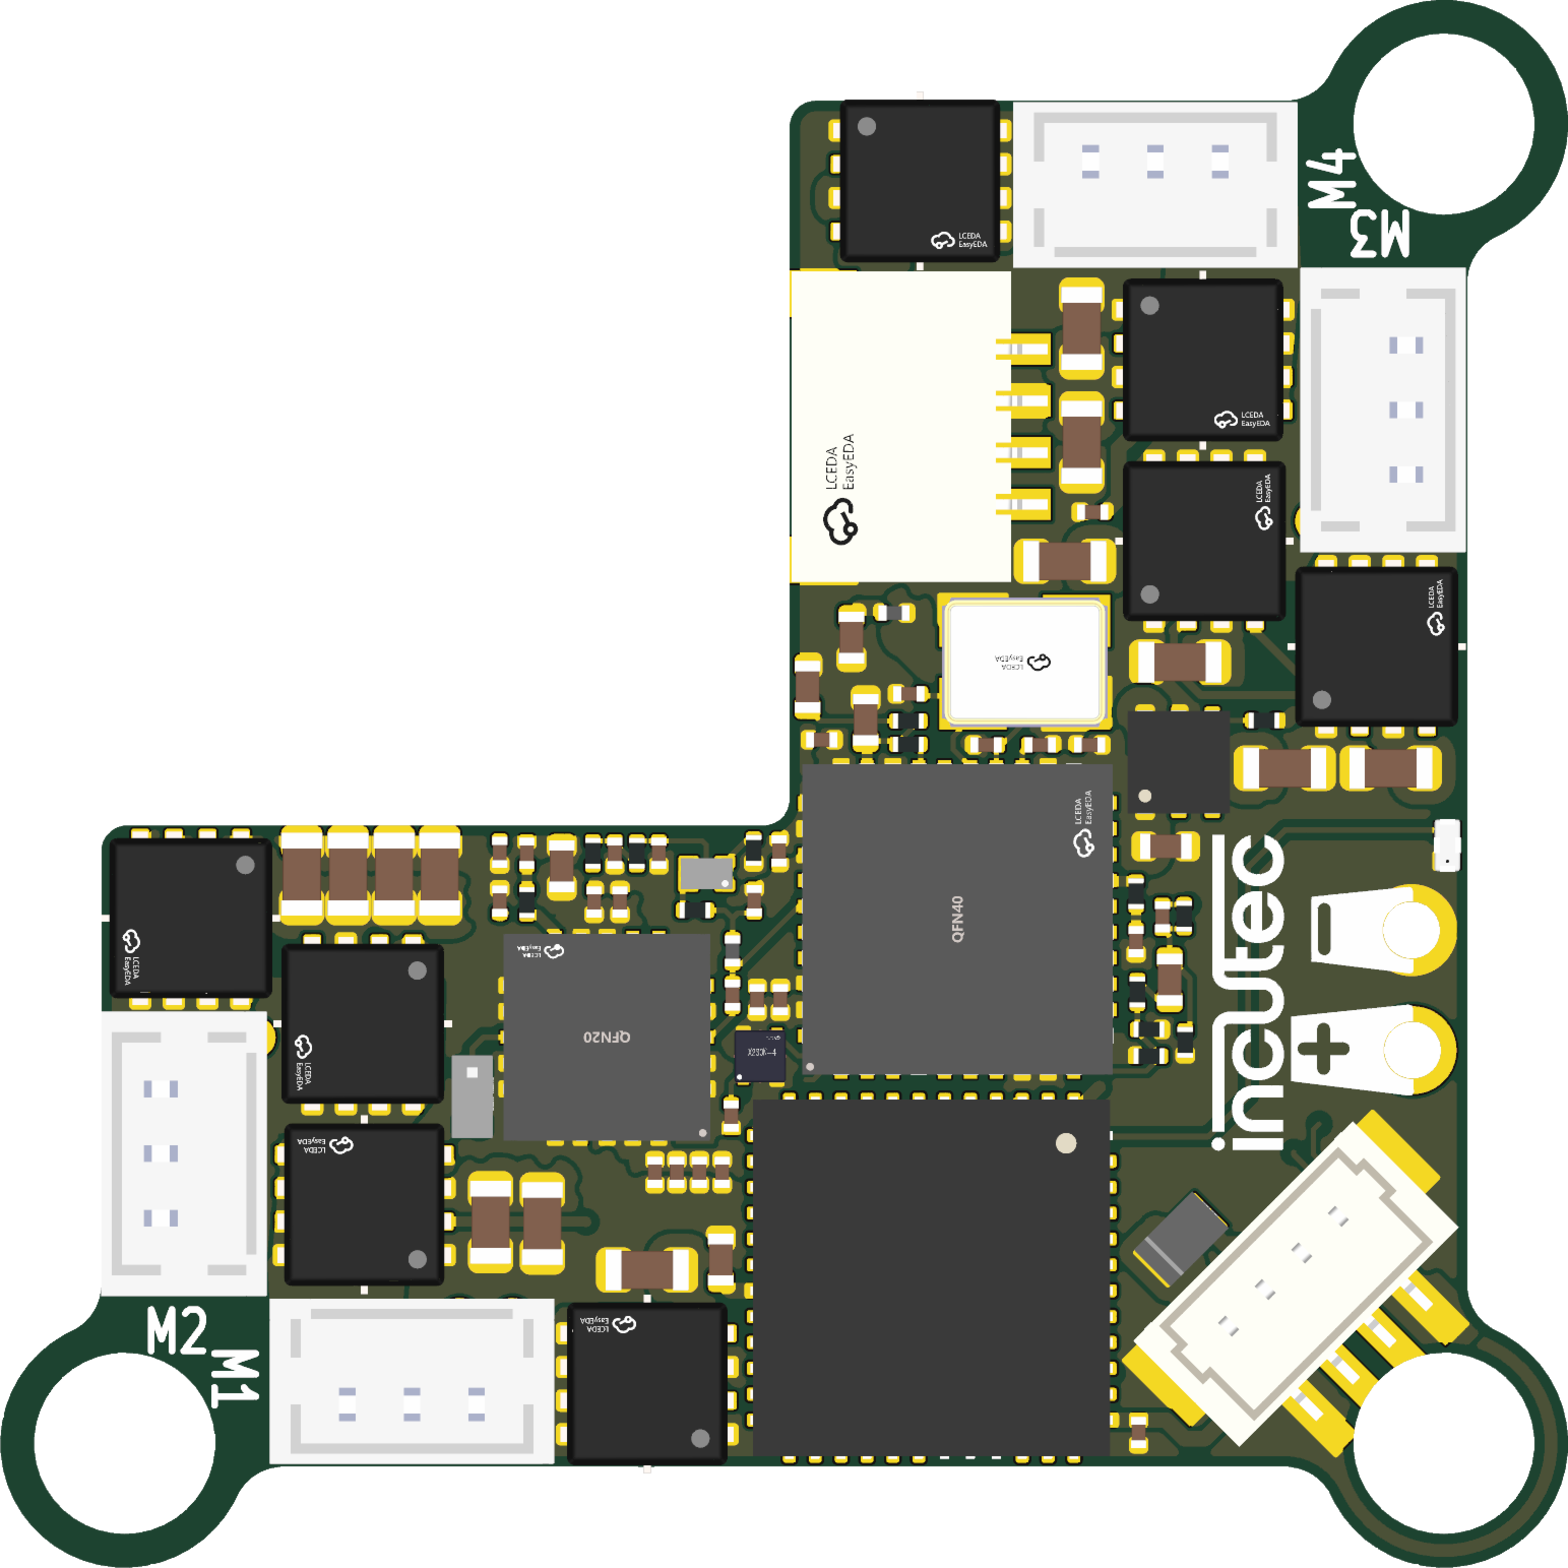

Whoops are where an AIO is not a convenience but the only option: there is no room for a stack and no weight budget for connectors. 2S and up is OpenAIO's range, so what is left for a second board is 1S, where the power tree starts from a single cell and everything above battery voltage has to be boosted.
Analog is the reason this board is separate rather than a variant. A 1S whoop is the last class still flying analog in volume, and an onboard VTX is what makes the board worth building instead of pointing people at a digital AIO with an HD port.
| Target class | 1S whoops, 65 to 85 mm |
| Mounting | 25.5 x 25.5 mm, three D3.55 ear holes |
| Board | 26.4 mm body, 8-layer HDI 1+6+1, 0.997 mm |
| Input | 1S LiPo, solder pads J2 (+) and J3 (-) |
| MCU | RP2354A, 2 MB in-package flash |
| IMU | BMI270 on SPI |
| Blackbox | 16 MB SPI NOR flash (PY25Q128HA) |
| ESC | 4 channels, EFM8BB51 + 3 AGM210MAP half-bridges each, bidirectional DShot, Bluejay |
| Current sense | 0.5 mohm shunt + INA186A3, 50 mV/A |
| Receiver | Onboard ExpressLRS 2.4 GHz, ESP32-PICO-V3 + SX1281, wire antenna |
| Video | Onboard analog VTX, RTC6705 + SE5004L PA, U.FL |
| OSD | Analog, PIO framebuffer |
| Digital video | DJI O4 Lite pads: J26 VHD (+5V_BST), J28 TX0, J29 RX0, J27 GND (UART0); JST SH 1.0 mm 4-pin plug J35 (1 VHD, 2 GND, 3 TX, 4 RX) |
| Motors | Molex PicoBlade 1.25 mm 3-pin lands, plug or solder |
| USB | JST SH 1.0 mm 4-pin, J31 |
| Camera | JST SUR 0.8 mm 3-pin plug J32, solder pads J23 and J24 |
| Firmware | Betaflight (target in this repo), Bluejay, ExpressLRS |
Technical write-up, part list and layout constraints: AGENTS.md. Pin map: research/PINMAP.md. Firmware: Betaflight target, ExpressLRS binding.
Open hardware/OpenAIO-Whoop.kicad_pro in KiCad 10 and keep the hardware folder together. The images above are renders of the routed board; this is not a manufacturing release.
| Item | Value |
|---|---|
| Protocol | ExpressLRS MSP-VTX, CRSF receiver on UART1 (GPIO8/9) |
| VTX owner | ESP32-PICO-V3 drives the RTC6705 over SPI and the SE5004L reference through PA_EN (ESP32 GPIO21) |
| Pit mode | Does not drop PA_EN and does not stop SPI activity (see firmware/expresslrs/README.md) |
| HD hold-off | RP2354A GPIO19 (HD_EN) high permits analog VTX power, low switches it off; fixed HD builds set pinio_config = 1,1,1,1 |
What pairs with what, and what is available: opendrone.be.
See CONTRIBUTING.md. KiCad files cannot be merged, so say what you intend to change before you do, on Discord.
Clone with the shared library:
git clone --recursive https://github.com/OpenDrone-hw/OpenAIO-Whoop
git submodule update --init      # after a plain git clone
Catalogue 3D models resolve through the project text variable OPENDRONE_LIB (${KIPRJMOD}/KiCad-Library), so without the submodule the 3D view shows bare pads.
A repository holds design files only. Sourcing (suppliers, prices, quotes, RFQs, contacts) is handled by Incutec and never lives in OpenDrone repositories.
Hardware licensed under CERN-OHL-S-2.0, see LICENSE.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 26 | 22uF | lib:C_0603_1608Metric_L | C10, C11, C20, C21, C22, C23, C24, C26, C27, C28, C29, C30, C32, C33, C34, C35 +10 |
| 25 | 100nF | lib:C_0201_0603Metric_L | C6, C42, C44, C45, C46, C47, C48, C49, C50, C51, C54, C59, C100, C101, C137, C138 +9 |
| 24 | 1k | lib:R_0201_0603Metric_L | R16, R17, R18, R23, R24, R25, R30, R31, R32, R37, R38, R39, R44, R47, R57, R66 +8 |
| 18 | 10k | lib:R_0201_0603Metric_L | R13, R14, R15, R20, R21, R22, R27, R28, R29, R34, R35, R36, R45, R46, R49, R50 +2 |
| 12 | AGM210MAP | lib:AGM_PDFN-8-2EP_3.3x3.3mm_AGM210MAP_L | Q29, Q30, Q31, Q32, Q33, Q34, Q35, Q36, Q37, Q38, Q39, Q40 |
| 7 | 100pF | lib:C_0201_0603Metric_L | C66, C102, C103, C111, C113, C115, C117 |
| 6 | 10uF | lib:C_0402_1005Metric_L | C12, C15, C82, C108, C118, C128 |
| 6 | 1uF | lib:C_0201_0603Metric_L | C68, C73, C124, C125, C135, C136 |
| 6 | 4.7uF | lib:C_0201_0603Metric_L | C14, C52, C61, C62, C122, C123 |
| 5 | 4.7uF | lib:C_0402_1005Metric_L | C56, C57, C58, C105, C107 |
| 4 | 1nF | lib:C_0201_0603Metric_L | C84, C112, C114, C116 |
| 4 | C2CK | lib:TestPoint_Pad_D0.8mm | TP2, TP4, TP6, TP8 |
| 4 | C2D | lib:TestPoint_Pad_D0.8mm | TP1, TP3, TP5, TP7 |
| 4 | EFM8BB51F16I | lib:QFN-20_3x3mm_P0.5mm_EFM8BB51_L | U6, U7, U8, U9 |
| 3 | 10nF | lib:C_0201_0603Metric_L | C86, C88, C109 |
| 3 | 27R | lib:R_0201_0603Metric_L | R41, R42, R43 |
| 3 | GND | lib:SolderPad_1.0x1.2mm | J25, J27, J33 |
| 3 | MS2A40LDF | lib:DFN1610-2_L1.6-W1.0-P1.05-RD | D9, D10, D11 |
| 2 | 1.2k | lib:R_0201_0603Metric_L | R58, R60 |
| 2 | 100k | lib:R_0201_0603Metric_L | R48, R63 |
| 2 | 10R | lib:R_0201_0603Metric_L | R65, R73 |
| 2 | 150R | lib:R_0201_0603Metric_L | R85, R86 |
| 2 | 15pF | lib:C_0201_0603Metric_L | C94, C95 |
| 2 | 270R | lib:R_0201_0603Metric_L | R54, R59 |
| 2 | 470nF | lib:C_0201_0603Metric_L | C87, C96 |
| 2 | 47k | lib:R_0201_0603Metric_L | R4, R64 |
| 2 | 5V | lib:SolderPad_1.0x1.2mm | J21, J24 |
| 1 | + | lib:BattPad_D1.7mm_PTH1.1 | J2 |
| 1 | - | lib:BattPad_D1.7mm_PTH1.1 | J3 |
| 1 | 0.5mR 2W | lib:R_1206_Kelvin_4Pad_NetTie_HCS1206_L | R2 |
| 1 | 0.68uH 6.5A | lib:IND-SMD_L2.5-W2.0_FTC252012_L | L1 |
| 1 | 10pF | lib:C_0201_0603Metric_L | C110 |
| 1 | 120R@100MHz 0.9A | lib:L_0201_0603Metric_L | FB1 |
| 1 | 12MHz | lib:OSC-SMD_4P-L2.0-W1.6-BL_YXC_YSO110TR_Dense | X1 |
| 1 | 1uF | lib:C_0402_1005Metric_L | C106 |
| 1 | 2.4k | lib:R_0201_0603Metric_L | R53 |
| 1 | 2450AT07A0100001T | lib:ANT-SMD_4P-L1.0-W0.5_Johanson_2450AT07A0100 | AE2 |
| 1 | 2450FM07D0034T | lib:FILTER-SMD_4P-L1.0-W0.5-L_W | FL1 |
| 1 | 3.3k | lib:R_0201_0603Metric_L | R90 |
| 1 | 3.3uH | lib:IND-SMD_L2.0-W1.6_AOTA-B201610S3R3-101-T_Dense | L2 |
| 1 | 33pF | lib:C_0201_0603Metric_L | C104 |
| 1 | 4.7nH | lib:L_0201_0603Metric_L | L3 |
| 1 | 470pF | lib:C_0201_0603Metric_L | C67 |
| 1 | 510k | lib:R_0201_0603Metric_L | R61 |
| 1 | 51R | lib:R_0201_0603Metric_L | R89 |
| 1 | 52MHz TCXO | lib:OSC-SMD_4P-L2.0-W1.6-BL_TXC_7Z_Dense | X3 |
| 1 | 560k | lib:R_0201_0603Metric_L | R62 |
| 1 | 6.2k | lib:R_0201_0603Metric_L | R5 |
| 1 | 680R | lib:R_0201_0603Metric_L | R55 |
| 1 | 75R | lib:R_0201_0603Metric_L | R51 |
| 1 | 820R | lib:R_0201_0603Metric_L | R52 |
| 1 | 8MHz 10pF | lib:CRYSTAL-SMD_4P-L3.2-W2.5-BL_Dense | X4 |
| 1 | ANT | lib:AE_WireHole_PTH0.5mm | AE1 |
| 1 | AP1606 | lib:DFN-3L_L1.0-W0.6-P0.65-BR_W | Q26 |
| 1 | BC857BM | lib:DFN-3L_L1.0-W0.6-P0.65-BR_W | Q27 |
| 1 | BMI270 | lib:LGA-14_L3.0-W2.5-P0.50-BR_W | U11 |
| 1 | BPF 5.15-5.95G | lib:Walsin_RFBPF1608060K98Q1C | FL2 |
| 1 | BZ- | lib:SolderPad_1.0x1.2mm | J22 |
| 1 | CAM | lib:JST_SUR_SM03B-SURS-TF_1x03-1MP_P0.80mm_Horizontal | J32 |
| 1 | CAM | lib:SolderPad_1.0x1.2mm | J23 |
| 1 | CLK | lib:TestPoint_Pad_D0.30mm_MicroVia_L | TP12 |
| 1 | DIO | lib:TestPoint_Pad_D0.30mm_MicroVia_L | TP13 |
| 1 | ESP32-PICO-V3 | lib:LGA-48_7x7mm_P0.5mm_EP_ESP32-PICO_L | U16 |
| 1 | HD VTX | lib:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | J35 |
| 1 | INA186A3 | lib:SOT-363_SC-70-6_Dense | U1 |
| 1 | LED | lib:SolderPad_1.0x1.2mm | J20 |
| 1 | LP5912-3.3 | lib:WSON-6-1EP_2x2mm_P0.65mm_EP1x1.6mm_L | U21 |
| 1 | M1 | lib:MotorPad_PicoBlade_1x03_P1.25mm_PTH0.5 | J4 |
| 1 | M2 | lib:MotorPad_PicoBlade_1x03_P1.25mm_PTH0.5 | J7 |
| 1 | M3 | lib:MotorPad_PicoBlade_1x03_P1.25mm_PTH0.5 | J10 |
| 1 | M4 | lib:MotorPad_PicoBlade_1x03_P1.25mm_PTH0.5 | J13 |
| 1 | PY25Q128HA-DFH-IR | lib:USON-8_3x3mm_P0.8mm_EP_PY25Q128HA_L | U13 |
| 1 | RGB WS2812 | lib:LED-SMD_4P-L1.0-W1.0-TL_XL-1010RGBC-WS2812B_Dense | D4 |
| 1 | RP2354A | lib:QFN-60_L7.0-W7.0-P0.40-TL-EP3.4_L | U10 |
| 1 | RTC6705 | lib:QFN-40_6x6mm_P0.5mm_EP_RTC6705_L | U19 |
| 1 | RX0 | lib:SolderPad_1.0x1.2mm | J29 |
| 1 | SDM02M30CLP3 | lib:X2-DFN1006-3_L1.0-W0.6_SDM02M30CLP3 | D8 |
| 1 | SDM02U30LP3 | lib:X3-DFN0603-2_L0.6-W0.3-RD_W | D3 |
| 1 | SE5004L | lib:QFN-20_4x4mm_P0.5mm_EP_SE5004L_L | U20 |
| 1 | SKUBAAE010 | lib:SW_Alps_SKUBAAE010_2.4x1.4mm | SW1 |
The 234 most common of 249 parts.
OpenDrone-hw/OpenAIO
Open-source AIO for 2-6S toothpick quads: flight controller, 4-in-1 AM32 ESC and ExpressLRS receiver, 25.5x25.5 mm.

OpenDrone-hw/OpenFC-Lite-Mini
Open-source Betaflight flight controller. RP2354A, 20x20 mm, 6-layer, 3-6S, CERN-OHL-S-2.0.

OpenDrone-hw/OpenFC-Lite
Open-source Betaflight flight controller. RP2354B, 30.5x30.5 mm, 6-layer, 3-8S, CERN-OHL-S-2.0.

OpenDrone-hw/OpenRX
OpenRX open-source ExpressLRS receiver family hub; board sources live in four dedicated hardware repositories.

aprskalo1/nano24-elrs-receiver
nano24: compact 2.4 GHz ExpressLRS receiver prototype with ESP32-C3, SX1281, CRSF and a printed Wi-Fi antenna. KiCad sources, BOM, Gerbers and validation notes.

flipperdevices/flipperzero-good-faps
Flipper Zero Official Apps maintained by Flipper Team and Friends


mikewen2024/Eyeliner
A 1lb (antweight) melty-brain combat robot. A melty-brain spins the entire chassis at 1,000–2,000 RPM while pulsing drive motors 100 times/second to achieve controlled translational movement — maximum hitting power, and…
It measures 28.9 × 28.9 mm and has 8 copper layers, 1 mm thick.
249 parts, built around the EFM8BB51F16I-C-QFN20R, ESP32-PICO-V3, RP2354A and RTC6705. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the OpenDrone-hw/OpenAIO-Whoop repository on GitHub, at the commit this page was made from: the board is hardware/OpenAIO-Whoop.kicad_pcb and its schematic hardware/OpenAIO-Whoop.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-S-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).