8 layers100.2 × 55 mm
Jetson nano baseboard
antmicro/jetson-nano-baseboard
Antmicro's open hardware baseboard for the NVIDIA Jetson Nano, TX2 NX and Xavier NX
391 parts548Apache-2.0

 CopperPilot/Jetson-AI-Cam-CopperPilot15
A carrier for Jetson Nano, Xavier NX and TX2 NX with two IMX219 cameras on a 39 mm stereo baseline, dual 4K outputs and CAN.
Jetson AI Cam CopperPilot is an open-source printed circuit board by CopperPilot, from the CopperPilot/Jetson-AI-Cam-CopperPilot repository on GitHub. It is an 8-layer board of 78 × 55 mm with 305 parts on 429 nets, routed with 3,427 tracks and 617 vias.
It is built around the 74LVC1G07GV,125-JSM, FT232RQ-REEL and LMQ62440BPPQRJRRQ1, with the PCA9517ADP, PCA9547BS,118 and TPD8S009DSMR among its other parts. Its parts include 121 resistors, 91 capacitors, 16 ICs, 15 diodes and 10 connectors. It belongs with the computers and single-board computers and interfaces and adapters boards of this library.




An open-source, production-grade 8-layer carrier board for NVIDIA Jetson Nano, Xavier NX, and TX2 NX System-on-Modules (SoM). Engineered specifically for autonomous robotics, stereoscopic depth perception, and edge AI vision workloads, this carrier integrates dual on-board Sony IMX219 camera sensors (39.00 mm optical baseline with industrial M12 lens mounts), dual 4K display outputs (Mini DisplayPort and Micro-HDMI), USB 3.0 Type-C, dedicated USB-to-UART debugging, a CAN bus vehicle telemetry interface, and high-efficiency power delivery in an ultra-compact 82.26 mm x 55.00 mm form factor.
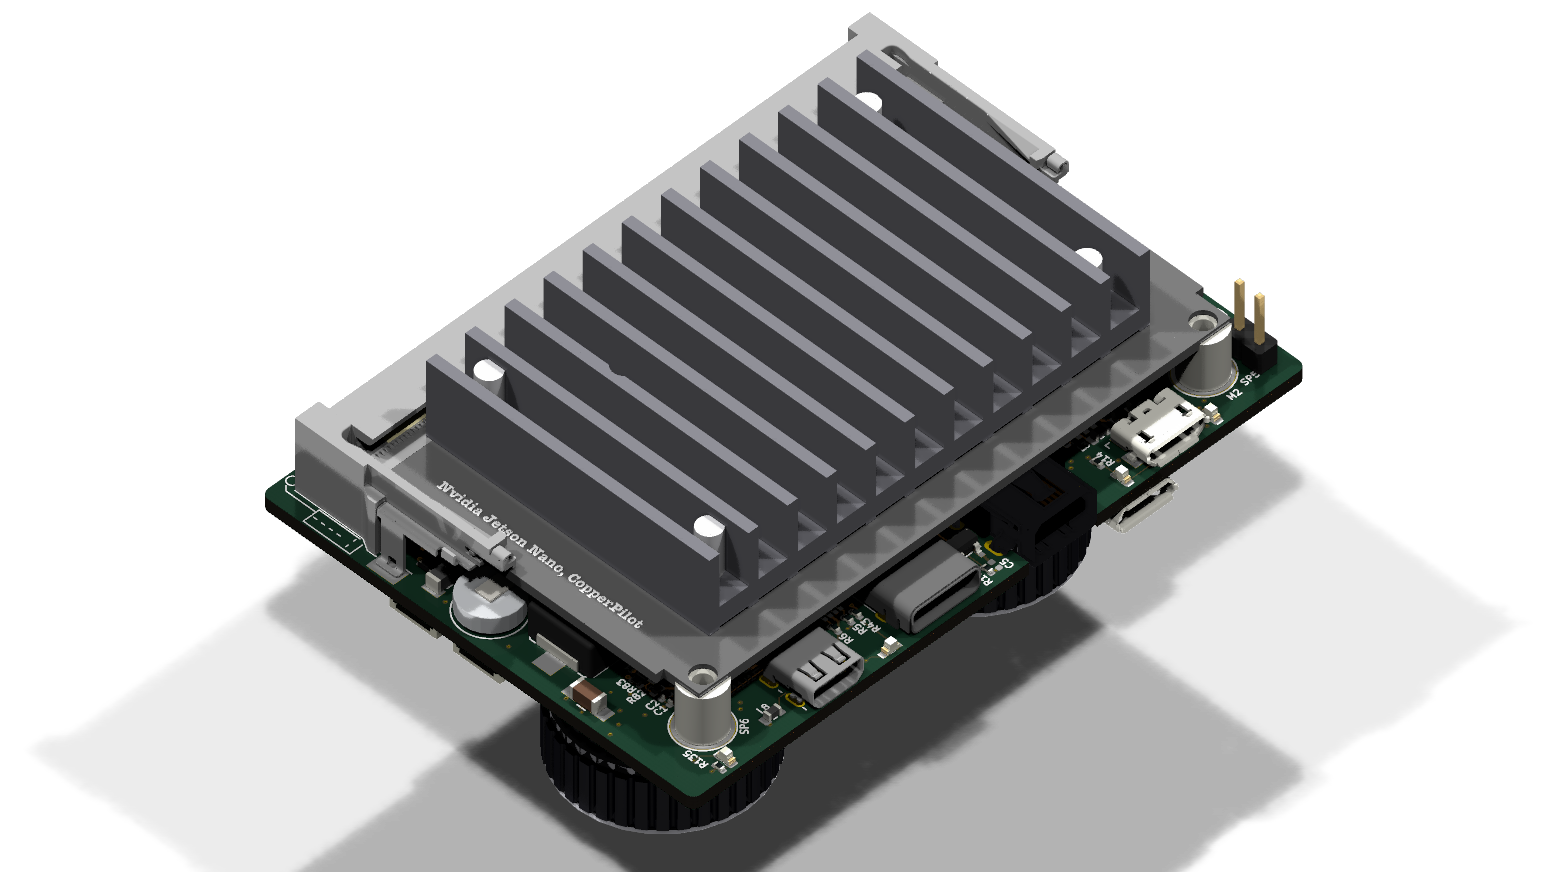
Figure 1: Complete 3D CAD visualization showing SODIMM-260 module socket, dual on-board IMX219 stereo camera sensors (B.Cu), CAN bus interface, dual display ports, and USB-C power delivery.
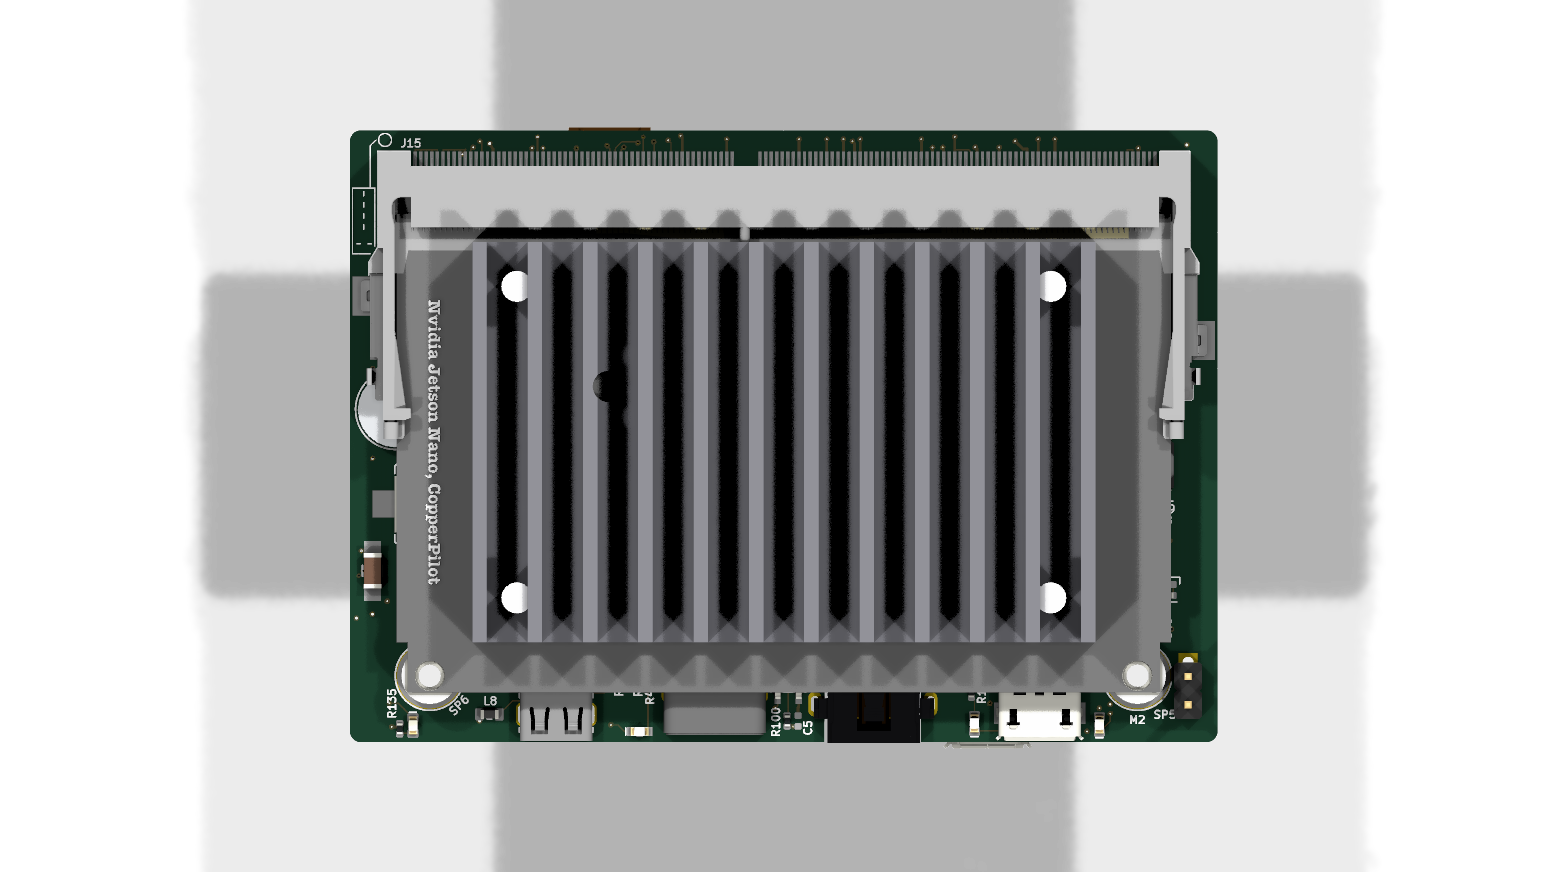
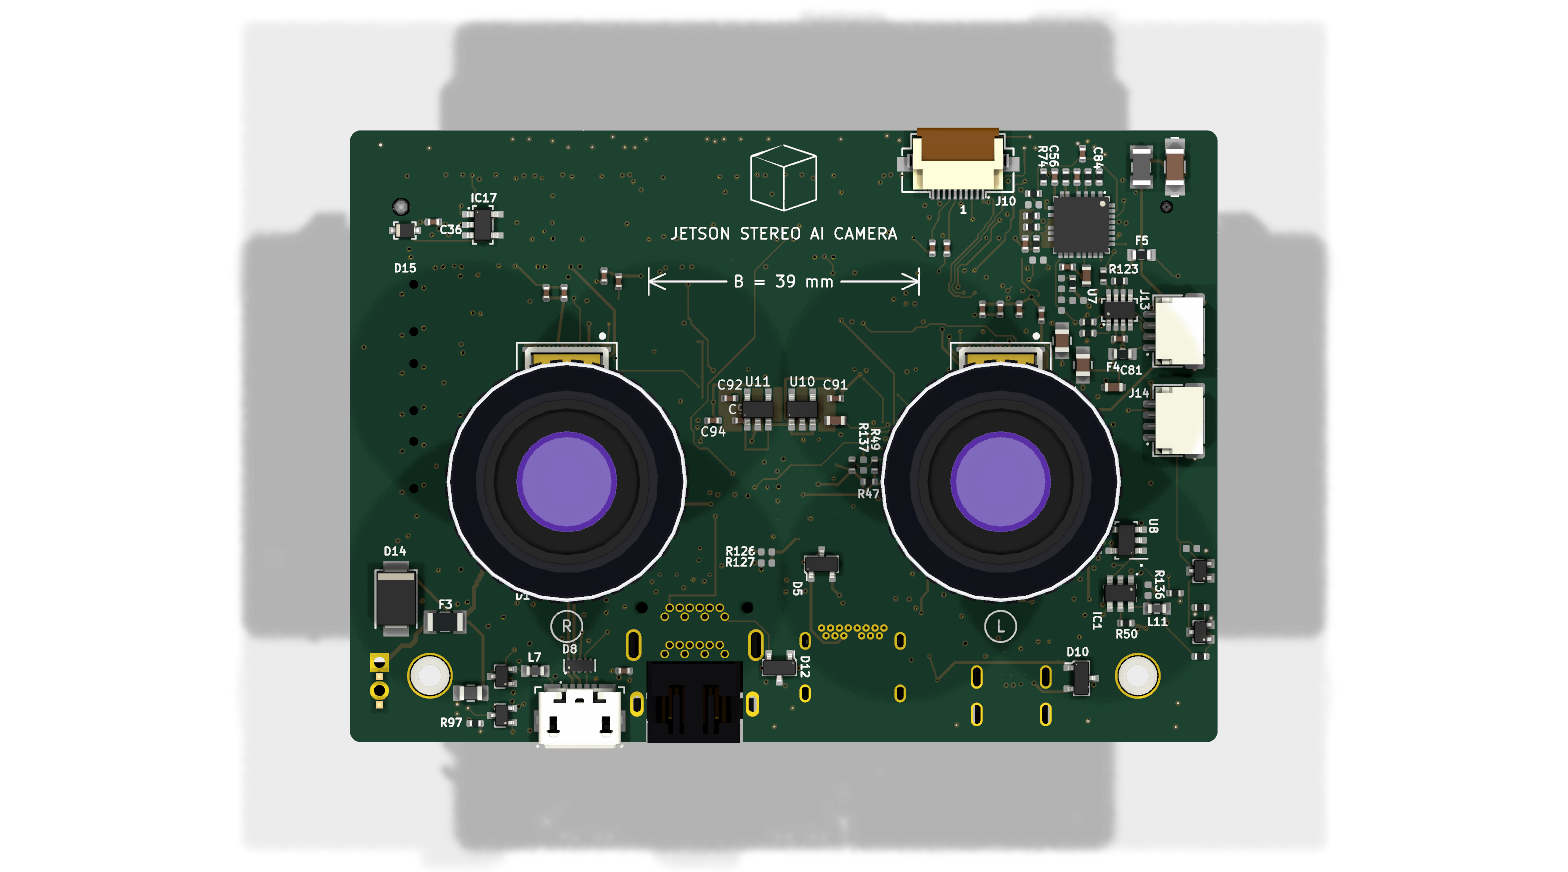
Figure 2: Component placement on Top (F.Cu) and Bottom (B.Cu) layers.
This project takes its initial architectural inspiration and baseline reference from the open-source Antmicro Jetson Nano Baseboard. While the Antmicro board serves as an excellent general-purpose breakout for desktop evaluation, our team re-architected and engineered this board specifically for compact autonomous robotics, drones, and edge stereoscopic vision.
Direct On-Board Stereo Camera Integration:
CAM_L and CAM_R) directly onto the bottom layer (B.Cu) with a precision 39.00 mm stereoscopic baseline (B = 39 mm) and standard M12 lens assemblies. This eliminates ribbon cable vibration artifacts, reduces electromagnetic radiation, and provides a rigid optical alignment.Dedicated Low-Noise Camera Power Architecture:
SWaP Optimization for Robotics (Size, Weight, and Power):
Integrated CAN Bus for Vehicle Telemetry:
Upgraded Power Delivery Stage:
5V0_SYS), paired with a secondary LM3671 (U1) synchronous buck converter for 3.3 V system logic and power path sequencing.Automated Verification & Manufacturing Compliance (DFM):
review/verify.sh). +---------------------------------------------+
| DC Power Input |
| 2-Pin Header (J4) / USB-C VBUS (5-24V) |
+----------------------+----------------------+
|
+----------v----------+
| Vishay SiC477 Buck |
| 5.0V / 6.0A SYS_VIN |
+----+-----------+----+
| |
+------------------+ +------------------+
| |
+----------v----------+ +----------v----------+
| LM3671 Buck Conv. | | TLV75512 / TPS7A05 |
| 3.3V / 1.0A Rail | | Camera LDOs (1.2/2.8)|
+----------+----------+ +----------+----------+
| |
+-----------------------------v-------------------------------------------------v-----------------------------+
| NVIDIA Jetson SoM (260-Pin SODIMM Socket) |
| Nano / Xavier NX / TX2 NX Series |
+-----------------+-----------------------+----------------------+-----------------------+--------------------+
| | | |
MIPI CSI-2 | (2x 2-Lane Direct) | CAN 2.0B / Telemetry | DP 1.2 Video Output | HDMI 2.0 Output
v v v vThe PCB utilizes a symmetrical 8-layer stackup with two solid, continuous internal ground planes (In4_GND and In6_GND) to guarantee low return-loop inductance, robust EMI immunity, and tight impedance control across all high-speed differential and single-ended signals.
| Layer | Type | Copper Weight | Thickness | Material / Function |
|---|---|---|---|---|
| F.SilkS | Silkscreen | - | - | Top Silkscreen Legend |
| F.Mask | Solder Mask | - | 0.010 mm | High-TG Soldermask (Green) |
| F.Cu (L1) | Signal | 1.0 oz (35 µm) | 0.035 mm | RF, High-Speed Differential Pairs, USB 3.0 |
| Dielectric 1 | Prepreg | - | 0.099 mm | FR4-3313 (εr = 4.05) |
| In1.Cu (L2) | Power/Signal | 0.5 oz (15 µm) | 0.015 mm | 5V0_SYS_VIN Power Plane |
| Dielectric 2 | Core | - | 0.200 mm | FR4 (εr = 4.60) |
| In2.Cu (L3) | Signal | 0.5 oz (15 µm) | 0.015 mm | High-Speed Internal Signals & Camera Clocks |
| Dielectric 3 | Prepreg | - | 0.200 mm | FR4-2116 (εr = 4.16) |
| In3.Cu (L4) | Signal | 0.5 oz (15 µm) | 0.015 mm | DisplayPort Main Link & HDMI TMDS Routing |
| Dielectric 4 | Core | - | 0.450 mm | FR4 (εr = 4.60) Center Core |
| In4.Cu (L5) | Ground Plane | 0.5 oz (15 µm) | 0.015 mm | Continuous Solid GND Reference Plane |
| Dielectric 5 | Prepreg | - | 0.200 mm | FR4-2116 (εr = 4.16) |
| In5.Cu (L6) | Power/Signal | 0.5 oz (15 µm) | 0.015 mm | 3V3_SYS Power Plane & Low-Speed Control |
| Dielectric 6 | Core | - | 0.200 mm | FR4 (εr = 4.60) |
| In6.Cu (L7) | Ground Plane | 0.5 oz (15 µm) | 0.015 mm | Continuous Solid GND Reference Plane |
| Dielectric 7 | Prepreg | - | 0.099 mm | FR4-3313 (εr = 4.05) |
| B.Cu (L8) | Signal | 1.0 oz (35 µm) | 0.035 mm | MIPI CSI-2 Differential Pairs, Decoupling, Sensor Pours |
| B.Mask | Solder Mask | - | 0.010 mm | High-TG Soldermask (Green) |
| B.SilkS | Silkscreen | - | - | Bottom Silkscreen Legend |
Total finished board thickness: 1.61 mm ± 10% (JLCPCB JLC08161H-3313 / 7628 impedance standard).
CAM0_*, CAM1_*), DisplayPort Main Link pairs, HDMI TMDS differential pairs.USB_D+/USB_D-, SS_TX_P/SS_TX_N, SS_RX_P/SS_RX_N).All copper geometries, hole sizes, and clearances adhere strictly to JLCPCB Multilayer manufacturing capabilities:
| Constraint | JLCPCB Multilayer Floor | Board Implementation | Margin | Status |
|---|---|---|---|---|
| Track Width | 0.090 mm (3.5 mil) | ≥ 0.127 mm (fine pitch) / 0.150 mm (std) | +41% to +66% | Verified |
| Trace-to-Trace Spacing | 0.090 mm (3.5 mil) | ≥ 0.150 mm (6.0 mil) | +66% | Verified |
| Through Via Drill / Diameter | 0.150 / 0.250 mm | 0.300 / 0.600 mm (0.15 mm annular ring) | +100% / +140% | Verified |
| Microvia Drill / Diameter | 0.100 mm drill | 0.100 mm drill / 0.250 mm pad | Standard HDI | Verified |
| Copper to Board Edge | 0.200 mm | ≥ 0.350 mm | +75% | Verified |
| Solder Mask Dam | 0.100 mm | ≥ 0.120 mm | +20% | Verified |
| Silkscreen Text Height | 0.800 mm | 1.000 mm standard | +25% | Verified |
| Silkscreen Min Line Width | 0.150 mm | 0.150 mm | Compliant | Verified |
.
├── Makefile                        # Unified build, test, lint, and verification runner
├── .gitignore                      # Clean exclusion rules (ignores caches, temporaries, and internal logs)
├── LICENSE                         # CERN Open Hardware Licence v2 - Permissive (CERN-OHL-P)
├── README.md                       # Technical overview, usage instructions, and hardware documentation
├── Jetson-AI-Cam-CopperPilot.kicad_pro  # KiCad 10 project settings, netclasses, and stackup
├── Jetson-AI-Cam-CopperPilot.kicad_sch  # Top-level hierarchical schematic sheet
├── Jetson-AI-Cam-CopperPilot.kicad_pcb  # 8-layer board layout (100% routed, 0 DRC violations)
├── Jetson-AI-Cam-CopperPilot.kicad_dru  # Custom KiCad design rules
├── csi.kicad_sch                   # Subsheet: Dual IMX219 stereo cameras, LDOs, & I2C switch
├── display.kicad_sch               # Subsheet: Mini DisplayPort & Micro-HDMI video pipelines
├── id-serial.kicad_sch             # Subsheet: Board ID EEPROM, strapping, status LEDs, RTC cell
├── interfaces.kicad_sch            # Subsheet: CAN bus transceiver (MAX3051EKA) & expansion ports
├── som.kicad_sch                   # Subsheet: Jetson 260-pin SODIMM connector & module power control
├── supply.kicad_sch                # Subsheet: SiC477 5V buck converter & LM3671 3.3V regulators
├── usb-debug.kicad_sch             # Subsheet: USB 3.0 Type-C & FT232RQ debug UART interface
├── fp-lib-table                    # Project-local footprint library table (${KIPRJMOD})
├── sym-lib-table                   # Project-local symbol library table (${KIPRJMOD})
├── libs/                           # Local symbol definitions (.kicad_sym)
├── jetson-footprints.pretty/       # Local footprint definitions (.kicad_mod)
├── 3dmodels/                       # Self-contained STEP and WRL 3D CAD models
├── docs/                           # High-resolution documentation assets and 3D renders
├── manufacturing/                  # Ready-to-order fabrication & assembly deliverables
│ ├── gerbers.zip # RS-274X Gerber & Excellon drill release archiveThis project is authored in KiCad 10 and is fully backward-compatible with KiCad 9. All symbol and footprint libraries are entirely self-contained within the repository and use ${KIPRJMOD} project-relative paths.
git clone https://github.com/<owner>/Jetson-AI-Cam.git
cd Jetson-AI-CamJetson-AI-Cam-CopperPilot.kicad_pro in KiCad:
.kicad_pro file or launch via KiCad: File -> Open Project.Jetson-AI-Cam-CopperPilot.kicad_sch) to view the hierarchical schematics.Jetson-AI-Cam-CopperPilot.kicad_pcb) to inspect the layout, stackup, and 3D CAD visualization (View -> 3D Viewer).The repository includes a complete verification pipeline verifying electrical rule checks (ERC), design rule checks (DRC), manufacturing constraints, and physical geometries.
# Run the complete test suite (21-point PyTest suite + 11-point acceptance tests)
make test

# Run only the automated PyTest hardware verification suite
make test-pcb

# Run the official 11-point acceptance verification script
make verify

# Run KiCad CLI Electrical Rule Check (ERC)
make erc

# Run KiCad CLI Design Rule Check (DRC) with zone refilling
make drc

# Verify manufacturing deliverables (Gerbers, BOM, CPL, ORDER_SPEC)
make fab

# Clean test caches and temporary outputs
make cleanreview/verify.sh)| Test ID | Verification Target | Pass Condition | Result |
|---|---|---|---|
| T1 | Schematic ERC | 0 Errors, 0 Warnings, 0 Unapproved Exclusions | PASS |
| T2 | Layout DRC | 0 Errors, 0 Warnings, 0 Unconnected, 0 Parity Mismatches | PASS |
| T3 | JLCPCB Rules | All design rules meet or exceed target thresholds | PASS |
| T4 | Rule Integrity | No constraints loosened compared to baseline | PASS |
| T5 | Severity Levels | No checks downgraded from error/warning to ignore | PASS |
| T6 | BOM Completeness | 100% of SMT components have Value, Footprint, MPN, and LCSC # | PASS |
| T7 | Manufacturing Outputs | Complete Gerbers, Excellon NC drills, BOM, and CPL generated | PASS |
| T8 | Issue Register | All 10 engineering issues resolved and closed | PASS |
| T9 | Visual Evidence | Every non-waived issue has deterministic before/after/diff crops | PASS |
| T10 | Parity & Visual Diff | Zero unexplained visual changes across all sheets and layers | PASS |
| T11 | Repository Hygiene | Project-local paths only, clean git tree, no cached artifacts | PASS |
For interactive visual layer diffs and audit logs, open review/index.html in any web browser.
Production files are pre-generated and located under manufacturing/:
Fabrication (Gerbers & Drills):
manufacturing/gerbers.zip directly to JLCPCB.manufacturing/ORDER_SPEC.md:
JLC08161H-3313 (Standard 8-layer controlled impedance)SMT Assembly (PCBA):
manufacturing/BOM.csv for parts list (100% mapped with LCSC part numbers).manufacturing/CPL.csv for centroid pick-and-place component coordinates.Electrical Continuity Testing:
manufacturing/Jetson-AI-Cam-CopperPilot.d356 for flying-probe electrical test verification.This project is licensed under the CERN Open Hardware Licence Version 2 - Permissive (CERN-OHL-P). See the LICENSE file for complete license terms.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 46 | C_100n_0402 | jetson-footprints:C_0402_1005Metric | C12, C13, C26, C27, C30, C33, C36, C39, C40, C42, C43, C44, C100, C101, C103, C104 +30 |
| 45 | R_0R_0402 | jetson-footprints:R_0402_1005Metric | R12, R101, R103, R104, R105, R106, R107, R108, R109, R110, R121, R124, R125, R126, R127, R129 +29 |
| 15 | R_10k_0402 | jetson-footprints:R_0402_1005Metric | R39, R44, R46, R50, R54, R72, R85, R95, R120, R122, R131, R133, R134, R137, R138 |
| 12 | R_100k_0402 | jetson-footprints:R_0402_1005Metric | R26, R30, R47, R69, R91, R96, R100, R102, R112, R113, R118, R139 |
| 12 | R_2k_0402 | jetson-footprints:R_0402_1005Metric | R5, R6, R11, R34, R35, R37, R55, R73, R74, R81, R83, R88 |
| 9 | BSS138PW | jetson-footprints:SC70-3 | T1, T2, T3, T4, T5, T6, T7, T8, T9 |
| 8 | R_5R6_0402 | jetson-footprints:R_0402_1005Metric | R1, R2, R3, R4, R7, R8, R9, R10 |
| 7 | FB_120Z_3A_Murata-BLM18SG_0603 | jetson-footprints:FB_0603_1608Metric | L2, L3, L7, L8, L9, L10, L11 |
| 5 | C_2u2_0402 | jetson-footprints:C_0402_1005Metric | C16, C60, C67, C98, C102 |
| 5 | C_4u7_0402 | jetson-footprints:C_0402_1005Metric | C1, C2, C3, C4, C62 |
| 5 | LED_G_0603_LG_L29K-G2J1-24-Z | jetson-footprints:LED_0603_1608Metric_G | BOOT1, LED1, LED2, PWR1, USER1 |
| 5 | PESD2USB5UV-TR | jetson-footprints:SOT-23-3 | D3, D5, D10, D11, D12 |
| 5 | R_470R_0402 | jetson-footprints:R_0402_1005Metric | R14, R43, R97, R111, R135 |
| 4 | 4.7k | jetson-footprints:R_0402_1005Metric | R140, R141, R142, R143 |
| 4 | C_10u_0603 | jetson-footprints:C_0603_1608Metric | C23, C35, C63, C81 |
| 4 | C_10u_1206_50V | jetson-footprints:C_1206_3216Metric | C17, C19, C21, C22 |
| 4 | C_1u_0402 | jetson-footprints:C_0402_1005Metric | C65, C66, C84, C87 |
| 4 | C_47u_0805 | jetson-footprints:C_0805_2012Metric | C20, C34, C59, C64 |
| 4 | R_1k_0402 | jetson-footprints:R_0402_1005Metric | R16, R36, R45, R87 |
| 4 | R_200k_0402 | jetson-footprints:R_0402_1005Metric | R53, R67, R84, R86 |
| 3 | 1N4148WS | jetson-footprints:D_SOD-323F | D13, D15, D17 |
| 3 | F_1.25A_0603 | jetson-footprints:F_0603_1608Metric | F1, F4, F5 |
| 3 | SW_TL3340AF160QG_SMD | jetson-footprints:SW_TL3340AF160QG_SMD | REC1, RST1, USR1 |
| 3 | TPD4E05U06QDQARQ1 | jetson-footprints:USON-10_2.5x1mm_P0.5mm | D6, D7, D8 |
| 2 | 100k | jetson-footprints:R_0402_1005Metric | R144, R145 |
| 2 | 1uF_0402 | jetson-footprints:C_0402_1005Metric | C91, C93 |
| 2 | 2.2uF_0402 | jetson-footprints:C_0402_1005Metric | C92, C94 |
| 2 | B0520W | jetson-footprints:D_SOD-323F | D2, D4 |
| 2 | C_1n2_50V_0402 | jetson-footprints:C_0402_1005Metric | C61, C82 |
| 2 | C_47p_0402 | jetson-footprints:C_0402_1005Metric | C15, C29 |
| 2 | C_Pol_330u_6.3V_KEMET-T520-B | jetson-footprints:C_Pol_EIA-B | C10, C11 |
| 2 | ESD5B5_0ST1G | jetson-footprints:SOD-523_NP | D1, D9 |
| 2 | FB_10Z_10A_WE-MPSB_1206 | jetson-footprints:FB_1206_3216Metric | FB1, FB2 |
| 2 | IMX219_30P | jetson-footprints:Camera_Module_IMX219-D160 | CAM_L, CAM_R |
| 2 | JST_SH_1x4_SM04B-SRSS-TB-LF-SN | jetson-footprints:Conn_JST_SH_1x4_SM04B-SRSS-TB-LF-SN | J13, J14 |
| 2 | NCP380LSNAJAAT1G | jetson-footprints:SOT-23-6 | IC1, IC3 |
| 2 | R_1M_0402 | jetson-footprints:R_0402_1005Metric | R31, R32 |
| 2 | R_22R_0402 | jetson-footprints:R_0402_1005Metric | R20, R41 |
| 2 | Spacer_Drill3.7mm_H6mm_9774060151R | jetson-footprints:Spacer_Drill3.7mm_H6mm_9774060151R | SP5, SP6 |
| 2 | TPD8S009DSMR | jetson-footprints:R-PDSO-N15 | IC2, IC18 |
| 2 | TPS7A0518P_SOT23-5 | jetson-footprints:SOT-23-5 | IC4, IC15 |
| 2 | USB-Micro-B_Molex_473460001 | jetson-footprints:USB-Micro-B_Receptacle_Molex_473460001 | J5, J9 |
| 1 | 74HC00_TSSOP | jetson-footprints:TSSOP-14_4.4x5mm_P0.65mm | IC12 |
| 1 | 74LVC1G07_SOT-753 | jetson-footprints:SOT-753 | U8 |
| 1 | AT24CS01_SOT23 | jetson-footprints:SOT-23-5 | IC17 |
| 1 | Battery_Holder_MS621FE-FL11E | jetson-footprints:MS621FE-FL11E | BAT1 |
| 1 | Bus_DDR4_SODIMM_CUSTOM_Jetson-Nano-H9.2mm-socket | jetson-footprints:TE_2309413 | J15 |
| 1 | C_100n_50V_0402 | jetson-footprints:C_0402_1005Metric | C56 |
| 1 | C_100u_1206 | jetson-footprints:C_1206_3216Metric | C31 |
| 1 | C_10u_0402 | jetson-footprints:C_0402_1005Metric | C32 |
| 1 | C_10u_0805 | jetson-footprints:C_0805_2012Metric | C25 |
| 1 | C_270p_25V_0402 | jetson-footprints:C_0402_1005Metric | C28 |
| 1 | C_33n_0402 | jetson-footprints:C_0402_1005Metric | C58 |
| 1 | C_47n_0402 | jetson-footprints:C_0402_1005Metric | C41 |
| 1 | C_4u7_0603 | jetson-footprints:C_0603_1608Metric | C85 |
| 1 | C_6p_0402 | jetson-footprints:C_0402_1005Metric | C24 |
| 1 | Conn_01x02 | jetson-footprints:PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | Conn_FFC_Molex_5051101097 | jetson-footprints:Conn_FFC_Molex_5051101097 | J10 |
| 1 | DisplayPort-Mini_TE_2129320-3 | jetson-footprints:DisplayPort-Mini_Receptacle_TE_2129320-3 | J2 |
| 1 | FB_180Z_3.1A_WE-MPSB_0805 | jetson-footprints:FB_0805_2012Metric | FB3 |
| 1 | FT232R_QFN | jetson-footprints:QFN-32-1EP_5x5mm | IC5 |
| 1 | F_12A_1206 | jetson-footprints:F_1206_3216Metric | F3 |
| 1 | HD3SS3220RNH | jetson-footprints:WQFN-30-1EP_4.6x2.6mm_P0.4mm | IC7 |
| 1 | HDMI-Micro-D_Molex_467561001 | jetson-footprints:HDMI-Micro-D_Receptacle_Molex_467651001 | J1 |
| 1 | Jetson-Nano | jetson-footprints:Module_Jetson-Nano | M2 |
| 1 | LM3671MF-3.3_SOT | jetson-footprints:SOT-23-5 | U1 |
| 1 | LM62440-Q1 | jetson-footprints:VQFN-HR-14_3.5x4mm | U2 |
| 1 | L_2u2_1.6A_1210 | jetson-footprints:L_1210_3225Metric | L5 |
| 1 | L_2u2_8A_Coilcraft-XFL4020 | jetson-footprints:L_Coilcraft-XFL4020 | L1 |
| 1 | L_3u3_9.2A_Vishay-IHLP-3232DZ-01 | jetson-footprints:L_Vishay-IHLP3232DZ | L4 |
| 1 | MAX3051EKA | jetson-footprints:SOT-23-8 | U7 |
| 1 | Molex_PicoBlade_1x4_0533980471 | jetson-footprints:Conn_Molex_PicoBlade_1x4_0533980471 | J12 |
| 1 | PCA9517ADP | jetson-footprints:TSSOP-8_3x3mm_P0.65mm | IC6 |
| 1 | PCA9547_VQFN | jetson-footprints:VQFN-24-1EP_3.8x3.8x1.0mm_P0.5mm | U4 |
| 1 | R_100R_0402 | jetson-footprints:R_0402_1005Metric | R70 |
| 1 | R_120R_0402 | jetson-footprints:R_0402_1005Metric | R123 |
| 1 | R_26k7_0402 | jetson-footprints:R_0402_1005Metric | R90 |
| 1 | R_316k_0402 | jetson-footprints:R_0402_1005Metric | R75 |
| 1 | R_3R3_0402 | jetson-footprints:R_0402_1005Metric | R89 |
| 1 | R_44k2_0402 | jetson-footprints:R_0402_1005Metric | R119 |
The 293 most common of 305 parts.
antmicro/jetson-nano-baseboard
Antmicro's open hardware baseboard for the NVIDIA Jetson Nano, TX2 NX and Xavier NX

antmicro/ecp5-dc-scm
Experimental Lattice ECP5-driven Data Center Security Communication Module


antmicro/jetson-orin-baseboard
Baseboard targetting the NVIDIA Jetson Orin Nano and Jetson Orin NX

NessieCircuits/Riotee_Board
The Riotee board is a development board for battery-free wireless devices. The on-board wireless microcontroller runs off energy harvested from, for example, a solar panel and uses only tiny capacitors as energy…

dshills/KiCadAI
AI-assisted KiCad design toolkit with Go CLI, direct schematic/PCB writers, validation, and pinmap checks.

NessieCircuits/Riotee_ProbeHardware
The Riotee probe lets you program a Riotee module that is soldered onto your PCB or plugged into a breadboard. It has a standard 10-pin 0.1" connector compatible with the popular Tag-Connect cables that allow in-circuit…

It measures 78 × 55 mm and has 8 copper layers, 1.61 mm thick.
305 parts, built around the 74LVC1G07GV,125-JSM, FT232RQ-REEL, LMQ62440BPPQRJRRQ1 and PCA9517ADP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CopperPilot/Jetson-AI-Cam-CopperPilot repository on GitHub, at the commit this page was made from: the board is Jetson-AI-Cam-CopperPilot.kicad_pcb and its schematic Jetson-AI-Cam-CopperPilot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask CopperPilot before reusing the design.