

2 layers91.6 × 60 mm
EV Control System
CanGulmez/EV-Control-System
Linux based EV Control System developed for BeagleBone Black Rev C
15 partsMIT
 CanGulmez/EV-Control-System
Linux based EV Control System developed for BeagleBone Black Rev C
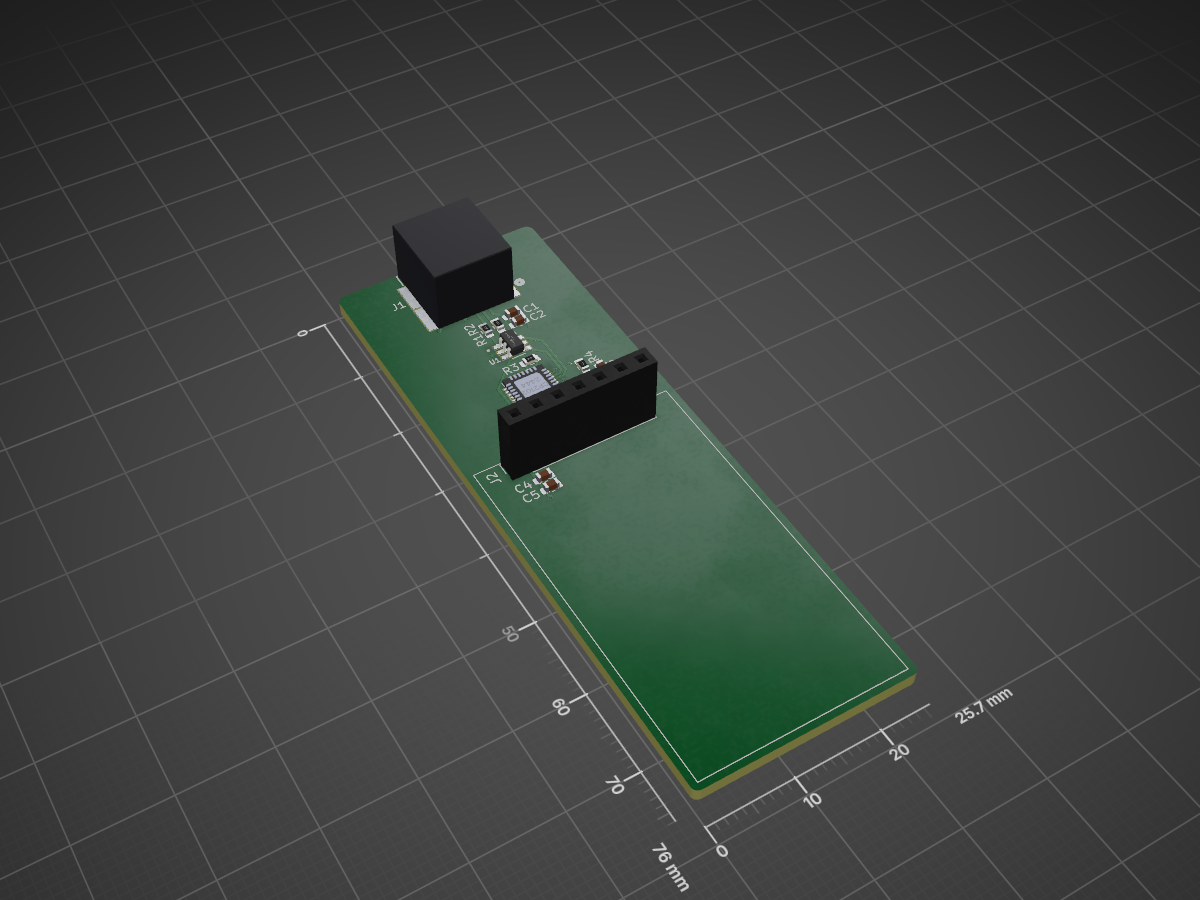
Telemetry is an open-source printed circuit board by CanGulmez, from the CanGulmez/EV-Control-System repository on GitHub, published under the MIT licence. It is a 2-layer board of 25.7 × 76 mm with 16 parts on 34 nets, routed with 90 tracks and 9 vias.
It is built around the CP2102 and USBLC6-2SC6. Its parts include 6 resistors, 5 capacitors, 2 ICs, 2 connectors and 1 diode.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C5 |
| 3 | 4k7 | Resistor_SMD:R_0603_1608Metric | R3, R5, R6 |
| 2 | 22 | Resistor_SMD:R_0603_1608Metric | R1, R2 |
| 1 | 220 | Resistor_SMD:R_0603_1608Metric | R4 |
| 1 | 565790576 | 565790576:56579-0576_MOL | J1 |
| 1 | CP2102 | CP2102:QFN50P500X500X100-29N | U2 |
| 1 | Conn_01x07_Socket | Connector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_Vertical | J2 |
| 1 | LED | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | USBLC6-2SC6 | USBLC6-2SC6:SOT95P280X145-6N | U1 |
CanGulmez/EV-Control-System
Linux based EV Control System developed for BeagleBone Black Rev C


UT8IFG/PTT-USB-Cable
A simple galvanically isolated USB-PTT interface for amateur radio equipment

laser-game/router-hw
Devices for route wireless communication between the control computer and laser game devices.


pacman314159/OISP-Drone-Research
mermaid stateDiagram-v2 [] --> POWERON POWERON --> BOOTINIT: Power Applied / Reset BOOTINIT --> SENSORCALIBRATION: Hardware Self-Test Pass BOOTINIT --> SYSTEMERROR: Self-Test Fail SENSORCALIBRATION --> DISARMED…


ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards

leafai-io/leaf-node-v3.x
Modular node for sensor monitoring and device control in grow environments.
It measures 25.7 × 76 mm and has 2 copper layers, 1.6 mm thick.
16 parts, built around the CP2102 and USBLC6-2SC6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CanGulmez/EV-Control-System repository on GitHub, at the commit this page was made from: the board is KiCAD/Telemetry/Telemetry.kicad_pcb and its schematic KiCAD/EV Control System/EV Control System.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).