4 layers110 × 50 mm
OpenHand v1
AleksaHeler/OpenHand
Our attempt at a prosthetic hand using STM32 microcontroller with custom PCB and mechanics
214 parts13MIT

 AleksaHeler/OpenHand13
Our attempt at a prosthetic hand using STM32 microcontroller with custom PCB and mechanics
OpenHand v2 is an open-source printed circuit board by AleksaHeler, from the AleksaHeler/OpenHand repository on GitHub, published under the MIT licence. It is a 4-layer board of 100 × 50 mm with 172 parts on 135 nets, routed with 947 tracks and 204 vias.
It is built around the DRV8833PWP, TL084 and ICL7660N, with the AMS1117-3.3, SS14 and AO3401A among its other parts. Its parts include 53 resistors, 42 capacitors, 13 connectors, 10 ICs and 6 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


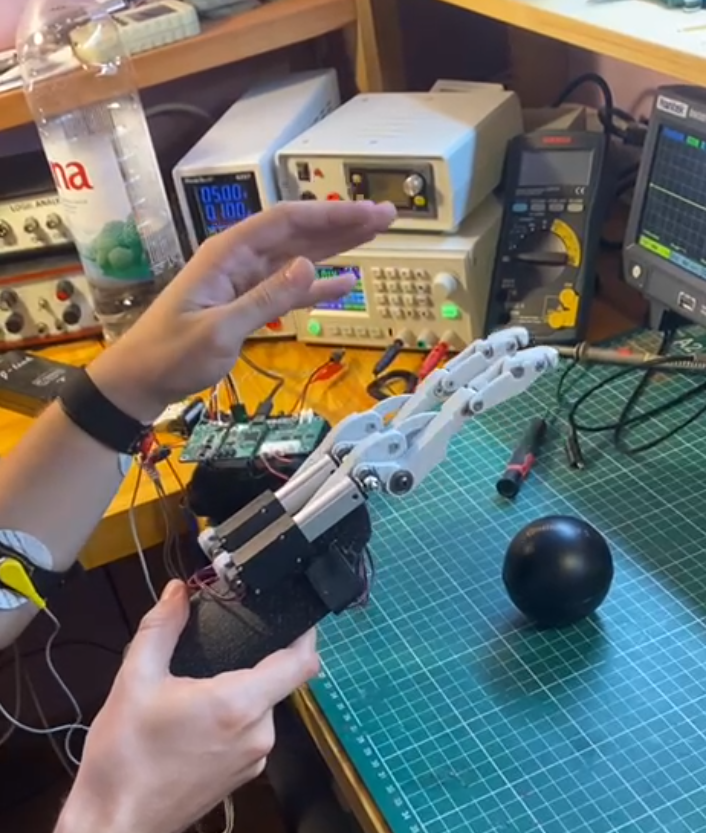
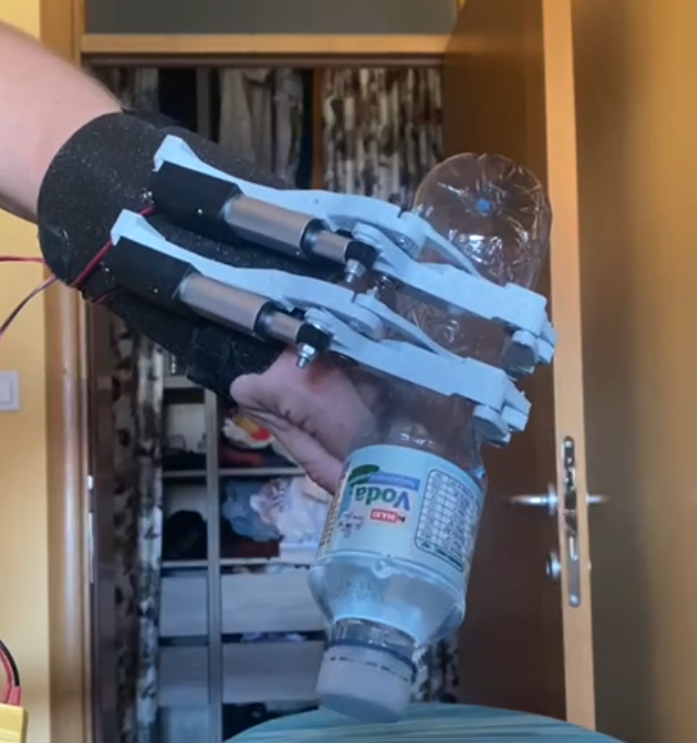
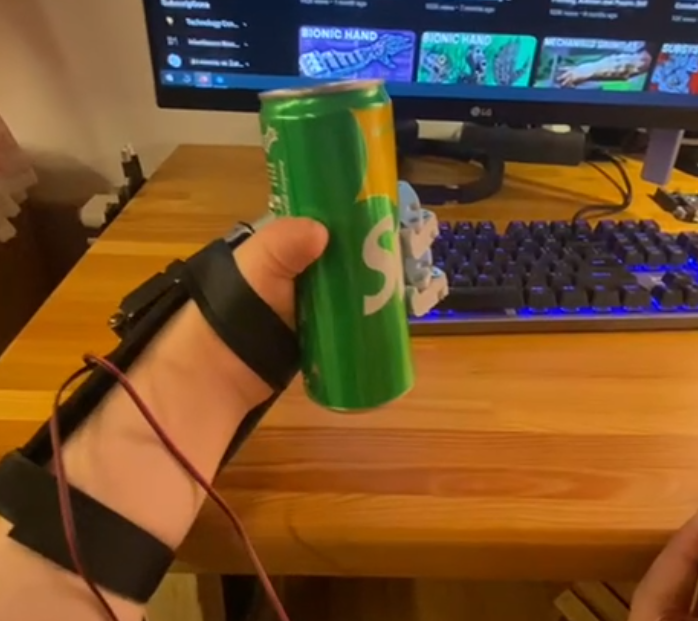
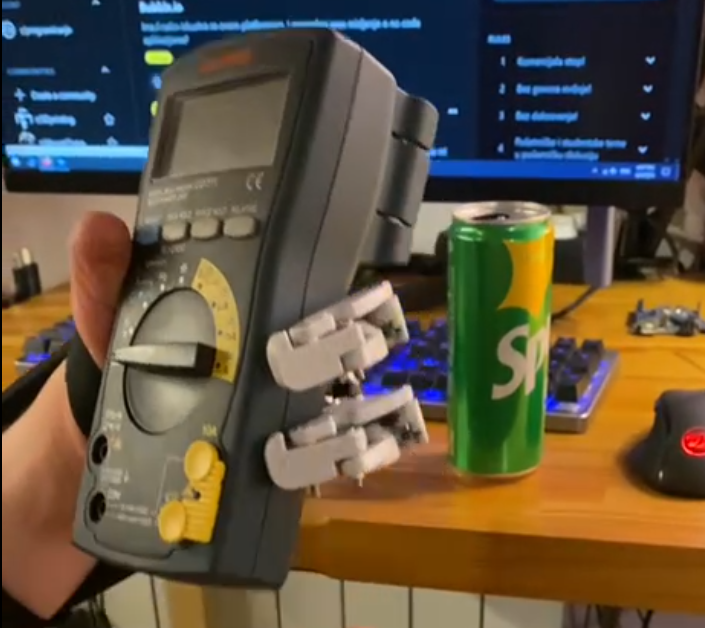
Our attempt at a prosthetic hand controlled by muscle EMG sensors, using linear actuators to move mechanically linked fingers. Implementing our own 3D models (ME), schematic & PCB design of main control board (EE) and software solution (SW).
Our (actually second) proof of concept, is using our own PCBs with STM32, our own mechanical design, and some basic software running on STM32 reacting on button press or EMG sensor activation.
For now, this approach seems promising, and only thing left to be changed is the motors used. We use linear actuators, which seem to be exactly what we need, but for now they don't have any position feedback. To solve that we will be using motors with built-in encoders in future, and monitoring their position with STM32 HW timer functions for encoders. Preliminary testing for that worked perfectly, we could always know the position of the motor based on the encoder value, and using endstops we can also calibrate the travel, and using current limiting H bridge motor drivers, we can control the force applied.
Here are some screenshots of the current status:
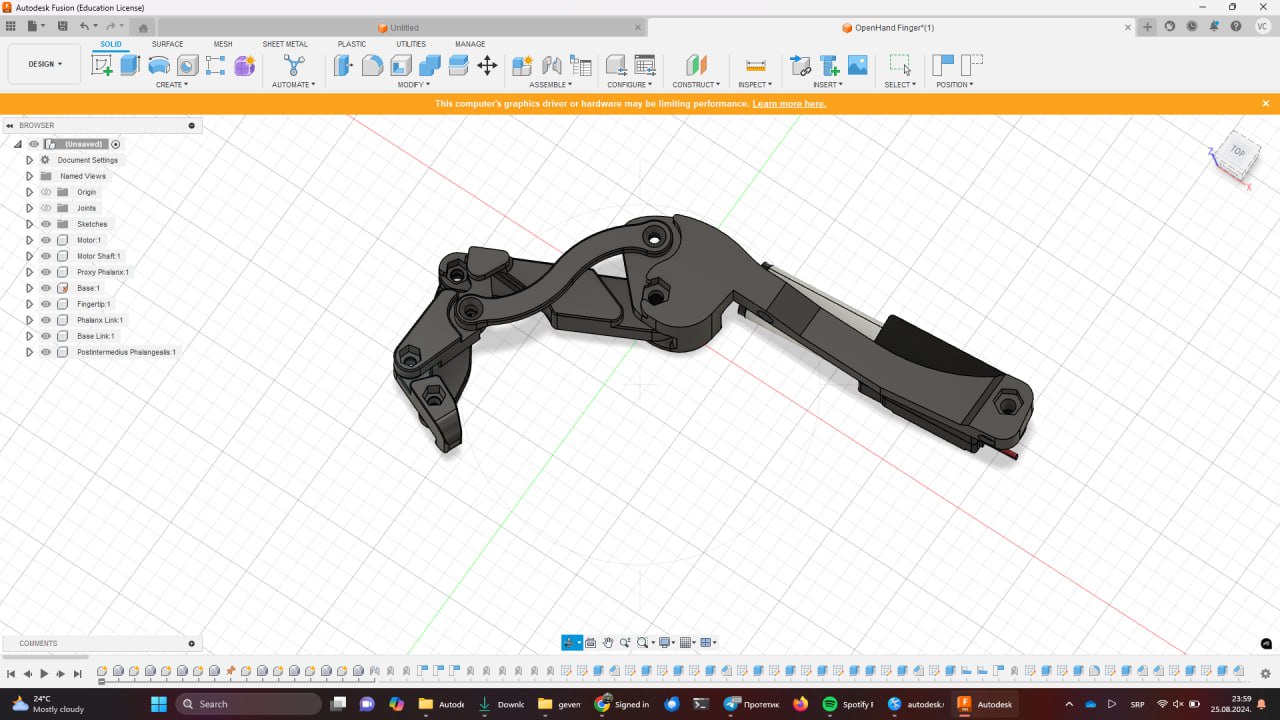
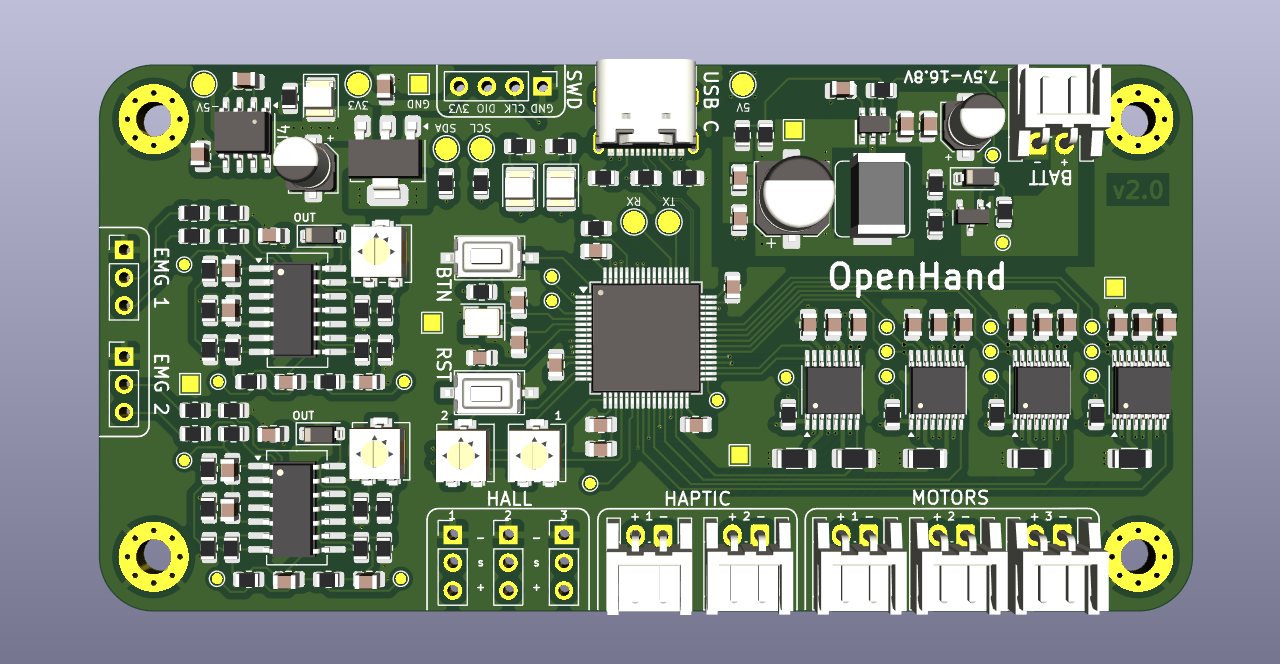
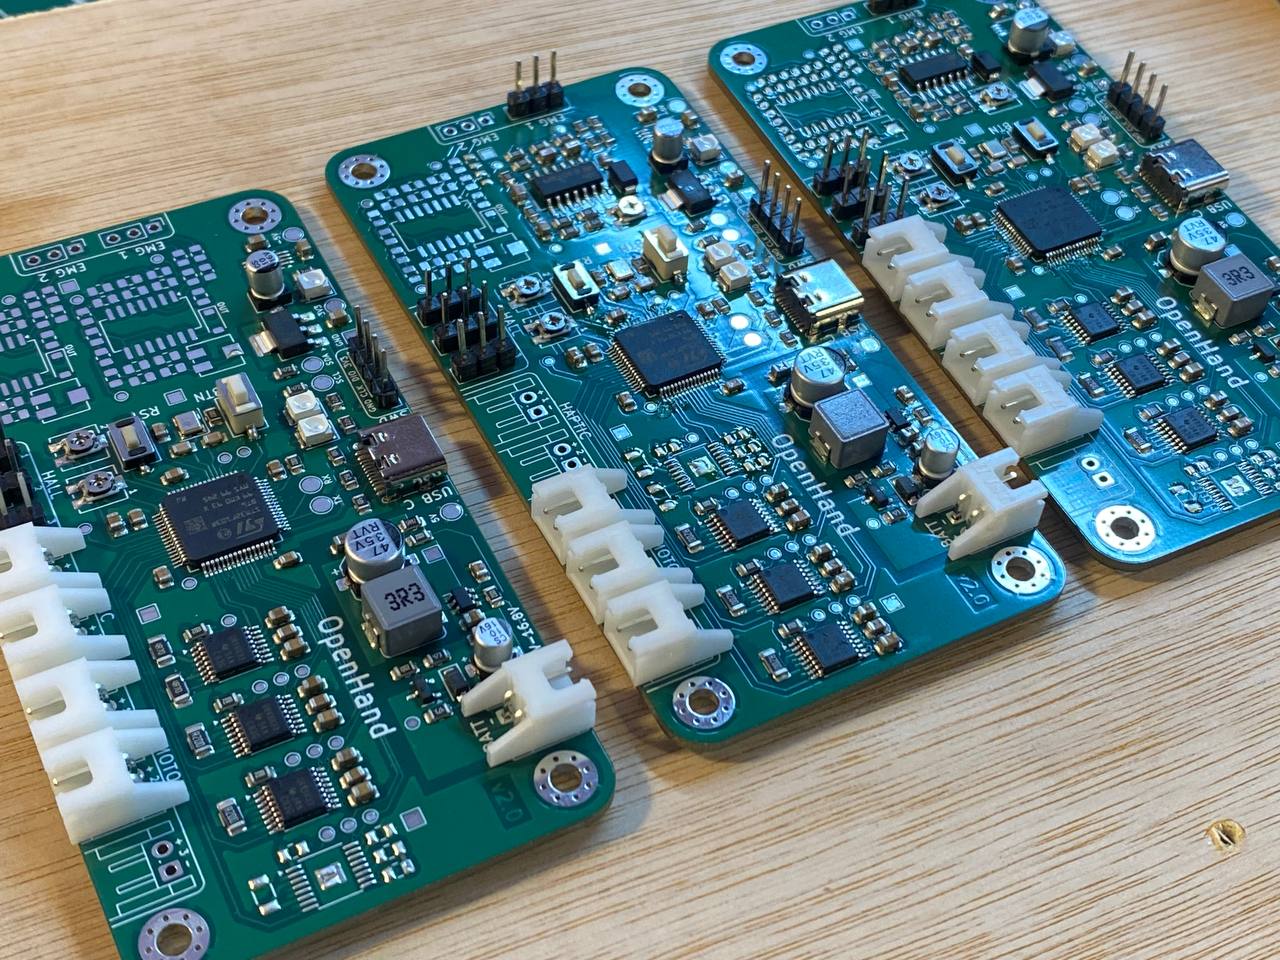
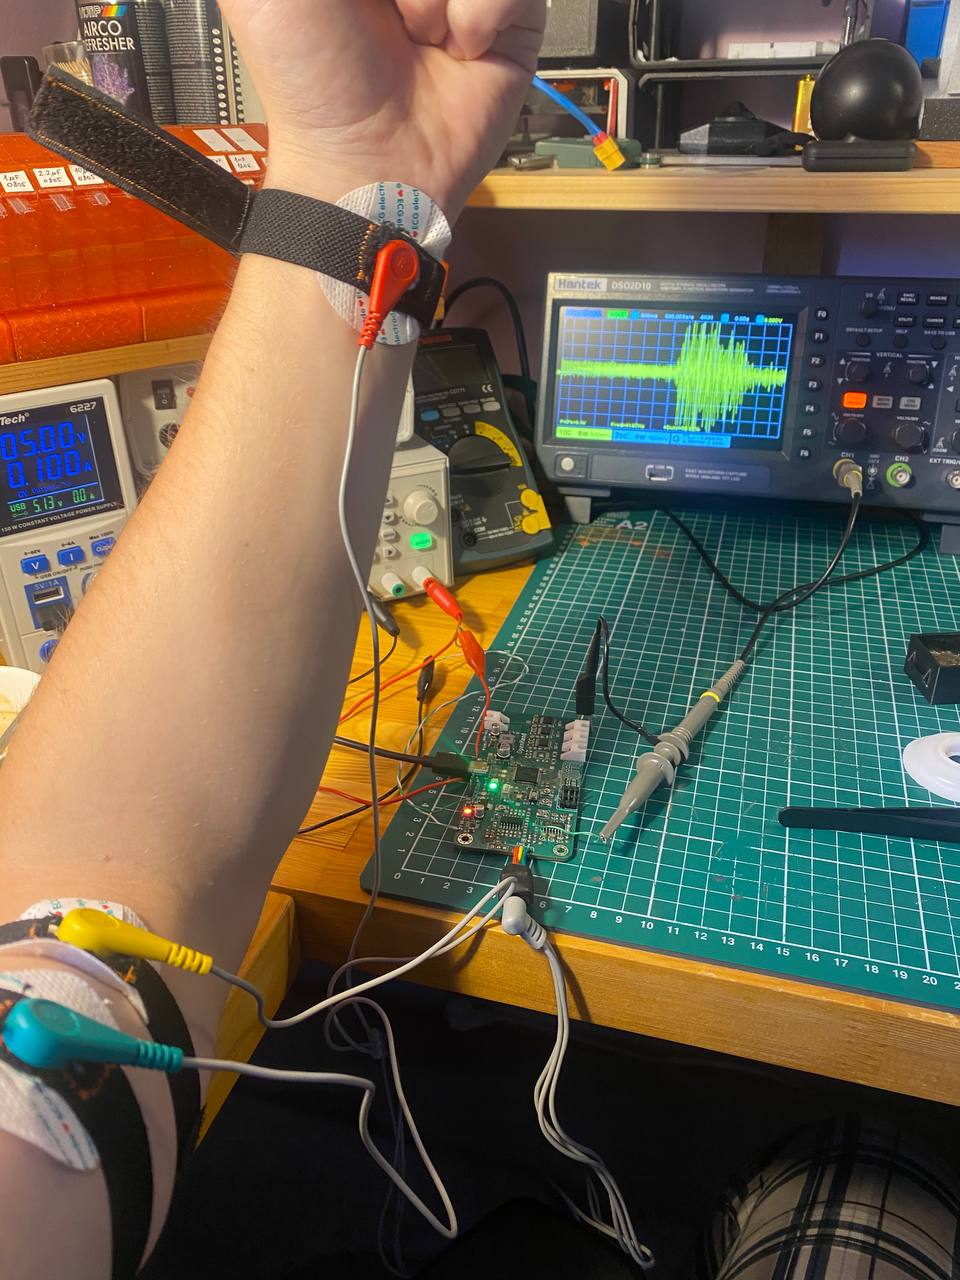
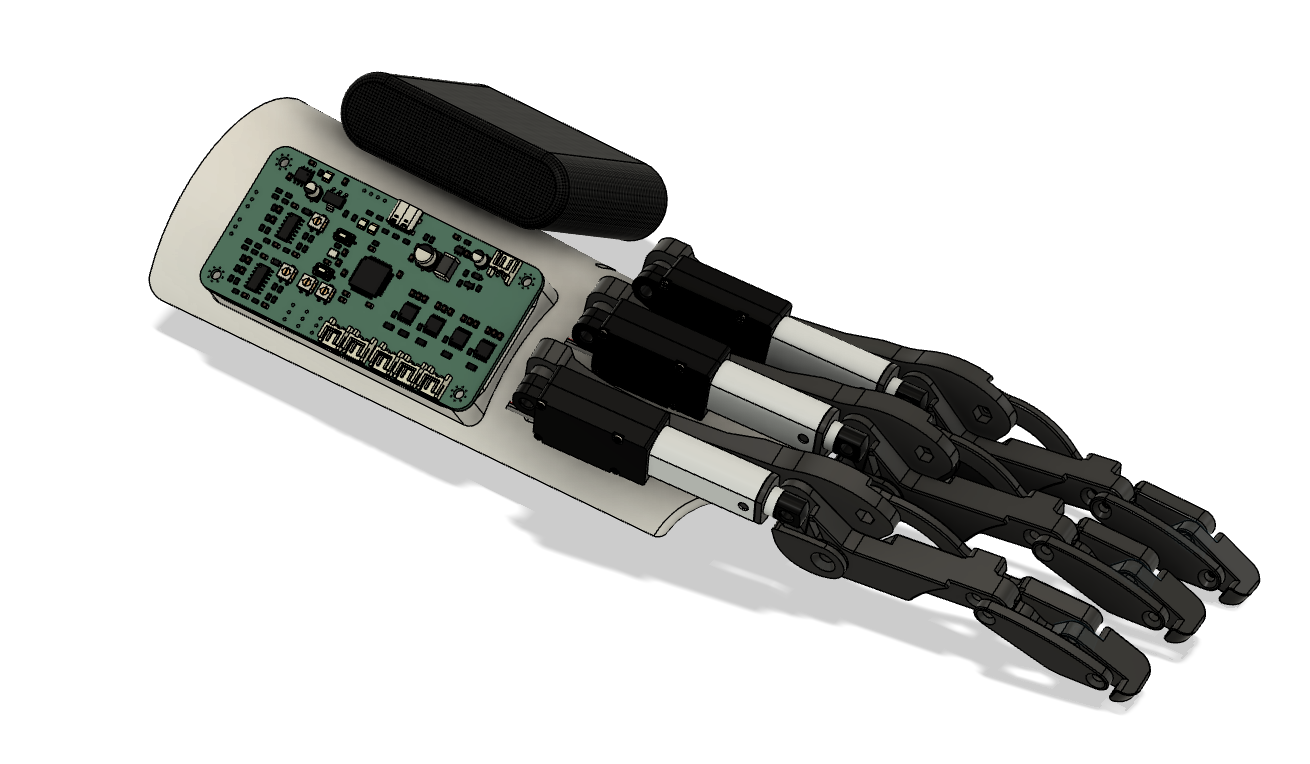
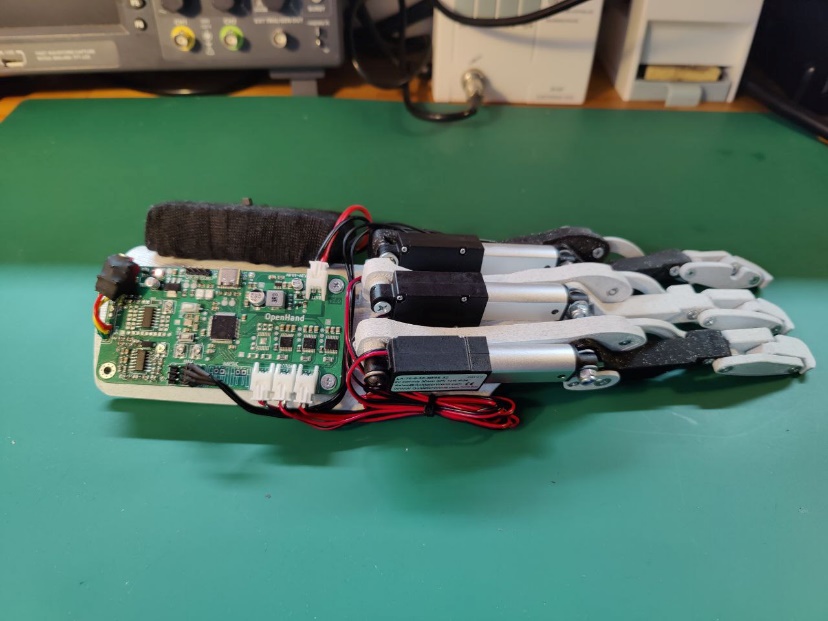
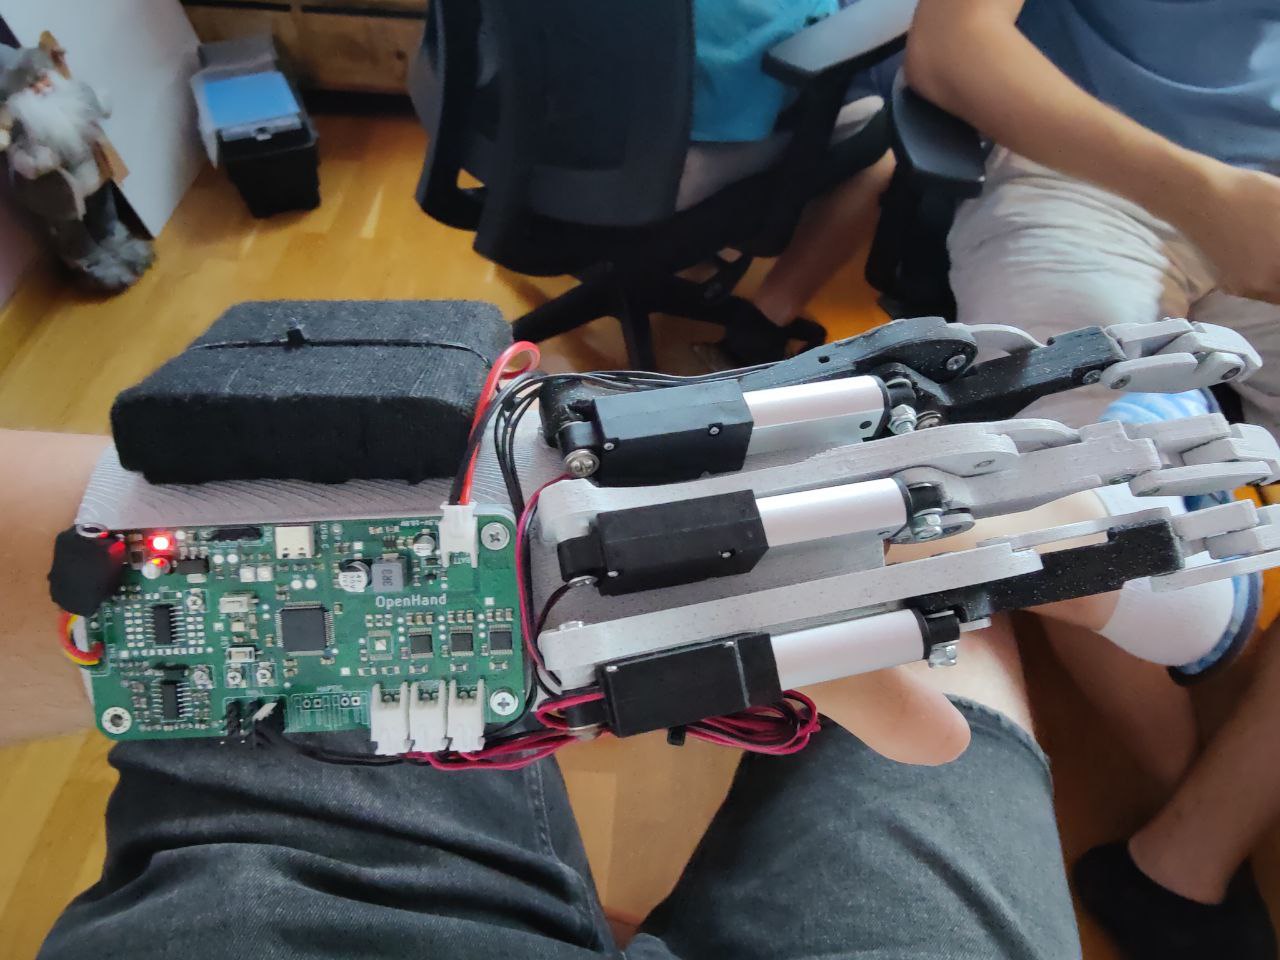
Here are some videos of the project for now. Nice to see it finally come together, although this is still early in development, and some things will be changed, and a lot of things will be made to look even prettier.
Note: you might have to download .mp4 videos if GitHub doesn't support playback in browser.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 14 | 10k | Resistor_SMD:R_0805_2012Metric | R6, R8, R9, R11, R12, R16, R29, R32, R41, R42, R45, R46, R49, R50 |
| 10 | 1k | Resistor_SMD:R_0805_2012Metric | R21, R22, R23, R24, R25, R26, R35, R36, R39, R40 |
| 9 | 100n | Capacitor_SMD:C_0805_2012Metric | C1, C2, C3, C4, C5, C6, C13, C21, C22 |
| 8 | 10u | Capacitor_SMD:C_0805_2012Metric | C11, C17, C18, C20, C35, C36, C41, C42 |
| 8 | 47k | Resistor_SMD:R_0805_2012Metric | R10, R14, R17, R19, R27, R30, R37, R38 |
| 4 | 10n | Capacitor_SMD:C_0805_2012Metric | C33, C34, C39, C40 |
| 4 | 15k | Resistor_SMD:R_0805_2012Metric | R18, R20, R28, R31 |
| 4 | 18k | Resistor_SMD:R_0805_2012Metric | R33, R34, R43, R44 |
| 4 | 2u2 | Capacitor_SMD:C_0805_2012Metric | C31, C32, C37, C38 |
| 4 | 330n | Capacitor_SMD:C_0805_2012Metric | C27, C28, C29, C30 |
| 4 | 470n | Capacitor_SMD:C_0805_2012Metric | C23, C24, C25, C26 |
| 4 | 4k7 | Resistor_SMD:R_0805_2012Metric | R4, R5, R7, R15 |
| 4 | DRV8833PWP | Package_SO:HTSSOP-16-1EP_4.4x5mm_P0.65mm_EP3.4x5mm_Mask2.46x2.31mm_ThermalVias | U7, U8, U9, U10 |
| 4 | M3_Hole | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H1, H2, H3, H4 |
| 3 | 0R2 | Resistor_SMD:R_1206_3216Metric | R47, R48, R52 |
| 3 | 1u | Capacitor_SMD:C_0805_2012Metric | C7, C12, C16 |
| 2 | 100k | Potentiometer_SMD:Potentiometer_Vishay_TS53YJ_Vertical | RV3, RV4 |
| 2 | 10p | Capacitor_SMD:C_0805_2012Metric | C8, C9 |
| 2 | 10u | Capacitor_SMD:CP_Elec_4x5.4 | C10, C19 |
| 2 | 4R7 | Resistor_SMD:R_1206_3216Metric | R51, R53 |
| 2 | 5k1 | Resistor_SMD:R_0805_2012Metric | R1, R2 |
| 2 | RED | LED_SMD:LED_1210_3225Metric | D1, D4 |
| 2 | SS14 | Diode_SMD:D_SOD-123 | D5, D6 |
| 2 | TL084 | Package_SO:SO-14_5.3x10.2mm_P1.27mm | U5, U6 |
| 1 | 1.5k | Resistor_SMD:R_0805_2012Metric | R3 |
| 1 | 16MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 22u | Capacitor_SMD:C_0805_2012Metric | C15 |
| 1 | 3.3uH | Inductor_SMD:L_Bourns_SRP7028A_7.3x6.6mm | L1 |
| 1 | 47u | Capacitor_SMD:CP_Elec_6.3x5.4 | C14 |
| 1 | 54.9k | Resistor_SMD:R_0805_2012Metric | R13 |
| 1 | 5V Zener | Diode_SMD:D_SOD-123 | D3 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U3 |
| 1 | AO3401A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | BTN_RST | Button_Switch_SMD:SW_Tactile_SPST_NO_Straight_CK_PTS636Sx25SMTRLFS | SW1 |
| 1 | CONN_BATT | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J3 |
| 1 | CONN_EMG_1 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | CONN_EMG_2 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J11 |
| 1 | CONN_FDBK_1 | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J7 |
| 1 | CONN_FDBK_2 | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J10 |
| 1 | CONN_MOTOR_1 | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J1 |
| 1 | CONN_MOTOR_2 | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J2 |
| 1 | CONN_MOTOR_3 | Connector_JST:JST_EH_S2B-EH_1x02_P2.50mm_Horizontal | J6 |
| 1 | CONN_POS_1 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | CONN_POS_2 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | CONN_POS_3 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J13 |
| 1 | CONN_SWD | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J12 |
| 1 | CONN_USB_C | Connector_USB:USB_C_Receptacle_G-Switch_GT-USB-7010ASV | J5 |
| 1 | GREEN | LED_SMD:LED_1210_3225Metric | D2 |
| 1 | ICL7660 | Package_SO:SOP-8_3.9x4.9mm_P1.27mm | U4 |
| 1 | STM32F103RETx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | SW_Push | Button_Switch_SMD:SW_Tactile_SPST_NO_Straight_CK_PTS636Sx25SMTRLFS | SW2 |
| 1 | TPS565201DDCR | TPS565201DDCR:TPS565201DDCR_L | U2 |
| 1 | TP_BATT_P | TestPoint:TestPoint_Pad_D1.0mm | TP15 |
| 1 | TP_EMG_1_AMP | TestPoint:TestPoint_Pad_D1.0mm | TP20 |
| 1 | TP_EMG_1_HP | TestPoint:TestPoint_Pad_D1.0mm | TP22 |
| 1 | TP_EMG_1_LP | TestPoint:TestPoint_Pad_D1.0mm | TP24 |
| 1 | TP_EMG_2_AMP | TestPoint:TestPoint_Pad_D1.0mm | TP21 |
| 1 | TP_EMG_2_HP | TestPoint:TestPoint_Pad_D1.0mm | TP23 |
| 1 | TP_EMG_2_LP | TestPoint:TestPoint_Pad_D1.0mm | TP25 |
| 1 | TP_FDBK_MOT_EN | TestPoint:TestPoint_Pad_D1.0mm | TP33 |
| 1 | TP_GND_1 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP6 |
| 1 | TP_GND_2 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP7 |
| 1 | TP_GND_3 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP8 |
| 1 | TP_GND_4 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP9 |
| 1 | TP_GND_5 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP10 |
| 1 | TP_GND_6 | TestPoint:TestPoint_Pad_1.5x1.5mm | TP11 |
| 1 | TP_MOT_1_EN | TestPoint:TestPoint_Pad_D1.0mm | TP26 |
| 1 | TP_MOT_1_UC1 | TestPoint:TestPoint_Pad_D1.0mm | TP28 |
| 1 | TP_MOT_1_UC2 | TestPoint:TestPoint_Pad_D1.0mm | TP30 |
| 1 | TP_MOT_2_EN | TestPoint:TestPoint_Pad_D1.0mm | TP27 |
| 1 | TP_MOT_2_UC1 | TestPoint:TestPoint_Pad_D1.0mm | TP29 |
| 1 | TP_MOT_2_UC2 | TestPoint:TestPoint_Pad_D1.0mm | TP31 |
| 1 | TP_MOT_3_EN | TestPoint:TestPoint_Pad_D1.0mm | TP32 |
| 1 | TP_MOT_3_UC1 | TestPoint:TestPoint_Pad_D1.0mm | TP34 |
| 1 | TP_MOT_3_UC2 | TestPoint:TestPoint_Pad_D1.0mm | TP35 |
| 1 | TP_UC_PA6 | TestPoint:TestPoint_Pad_D1.0mm | TP1 |
| 1 | TP_UC_PB12 | TestPoint:TestPoint_Pad_D1.0mm | TP14 |
| 1 | TP_UC_PC13 | TestPoint:TestPoint_Pad_D1.0mm | TP4 |
| 1 | TP_UC_PC15 | TestPoint:TestPoint_Pad_D1.0mm | TP5 |
| 1 | TP_UC_RX | TestPoint:TestPoint_Pad_D2.0mm | TP3 |
The 163 most common of 172 parts.
AleksaHeler/OpenHand
Our attempt at a prosthetic hand using STM32 microcontroller with custom PCB and mechanics

AleksaHeler/OpenHand
Our attempt at a prosthetic hand using STM32 microcontroller with custom PCB and mechanics

AleksaHeler/OpenHand
Our attempt at a prosthetic hand using STM32 microcontroller with custom PCB and mechanics

dragonlock2/kicadboards
Offsite backup for the miscellaneous KiCad boards that don't fit elsewhere

KushlaVR/models-heart
Можливості: Керування через WIFI з телефона або ПК 5 незалежних каналів (світлодіоди/сервомотори) 1 Н-міст для підключення мотора (піковий струм до 3А) Вмонтована BMS 1S та контроллер заряду Li-Ion акумулятора з…

BojanSof/BluePillWaveGen
DDS function generator build around STM32 BluePill board


supsenpaii/iot-classroom
Website lớp học tương tác: React, Express, SQLite và giao thức WebSocket kết nối ESP32. Chưa kèm firmware.


kokhaie/Smart-Refrigerator-Demo
The KiCad-generated BOM is mirrored into the documentation site under docs/ so it can be published through GitHub Pages.
It measures 100 × 50 mm and has 4 copper layers, 1.6 mm thick.
172 parts, built around the DRV8833PWP, TL084, ICL7660N and AMS1117-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the AleksaHeler/OpenHand repository on GitHub, at the commit this page was made from: the board is hardware/OpenHand_v2/OpenHand_v2.kicad_pcb and its schematic hardware/DevBoard/ProstheticHandV2.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).