2 layers62 × 60 mm
Shield basic
dreamster/dreamster-board
Specialized Arduino board which is the heart of the Dreamster Robot.
53 parts1

 wuehr1999/micromouse
Micromouse competition robot
Micromouse is an open-source printed circuit board by wuehr1999, from the wuehr1999/micromouse repository on GitHub, published under the MIT licence. It is a 2-layer board of 80 × 80.2 mm with 83 parts on 77 nets, routed with 571 tracks and 197 vias.
It is built around the ESP32-WROOM-32U, DRV8833PW and BNO055, with the BC847 among its other parts. Its parts include 32 resistors, 22 capacitors, 13 connectors, 5 ICs and 4 switches. It belongs with the robots and motor control boards and the ESP32 boards of this library.


This micromouse (or at least wall follower :)) is constructed for the Istrobot micromouse competition held in Bratislava, Slowenia. As beginners are welcome, the maze will always be solvable by just following the left or right wall, so this should be the first big milestone to achieve.
The mouse is built by the following components, all connected on a custom PCB by Jonas Wühr:
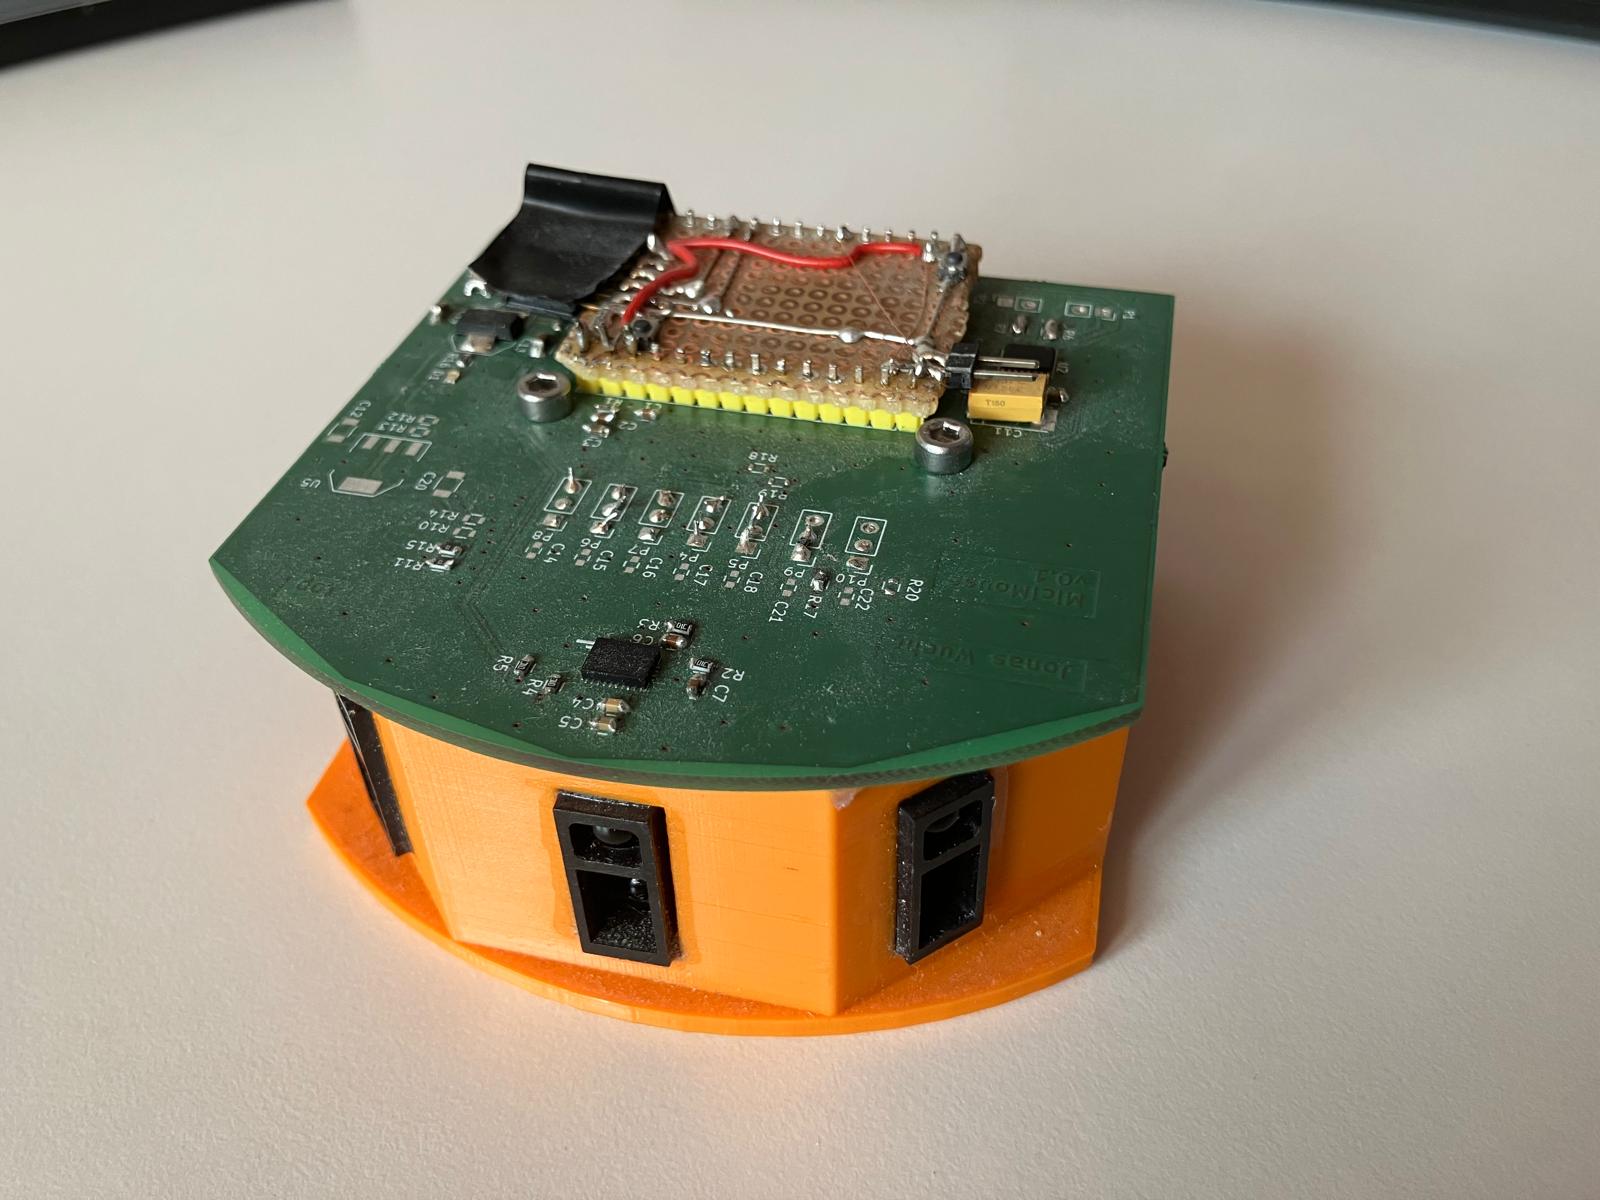
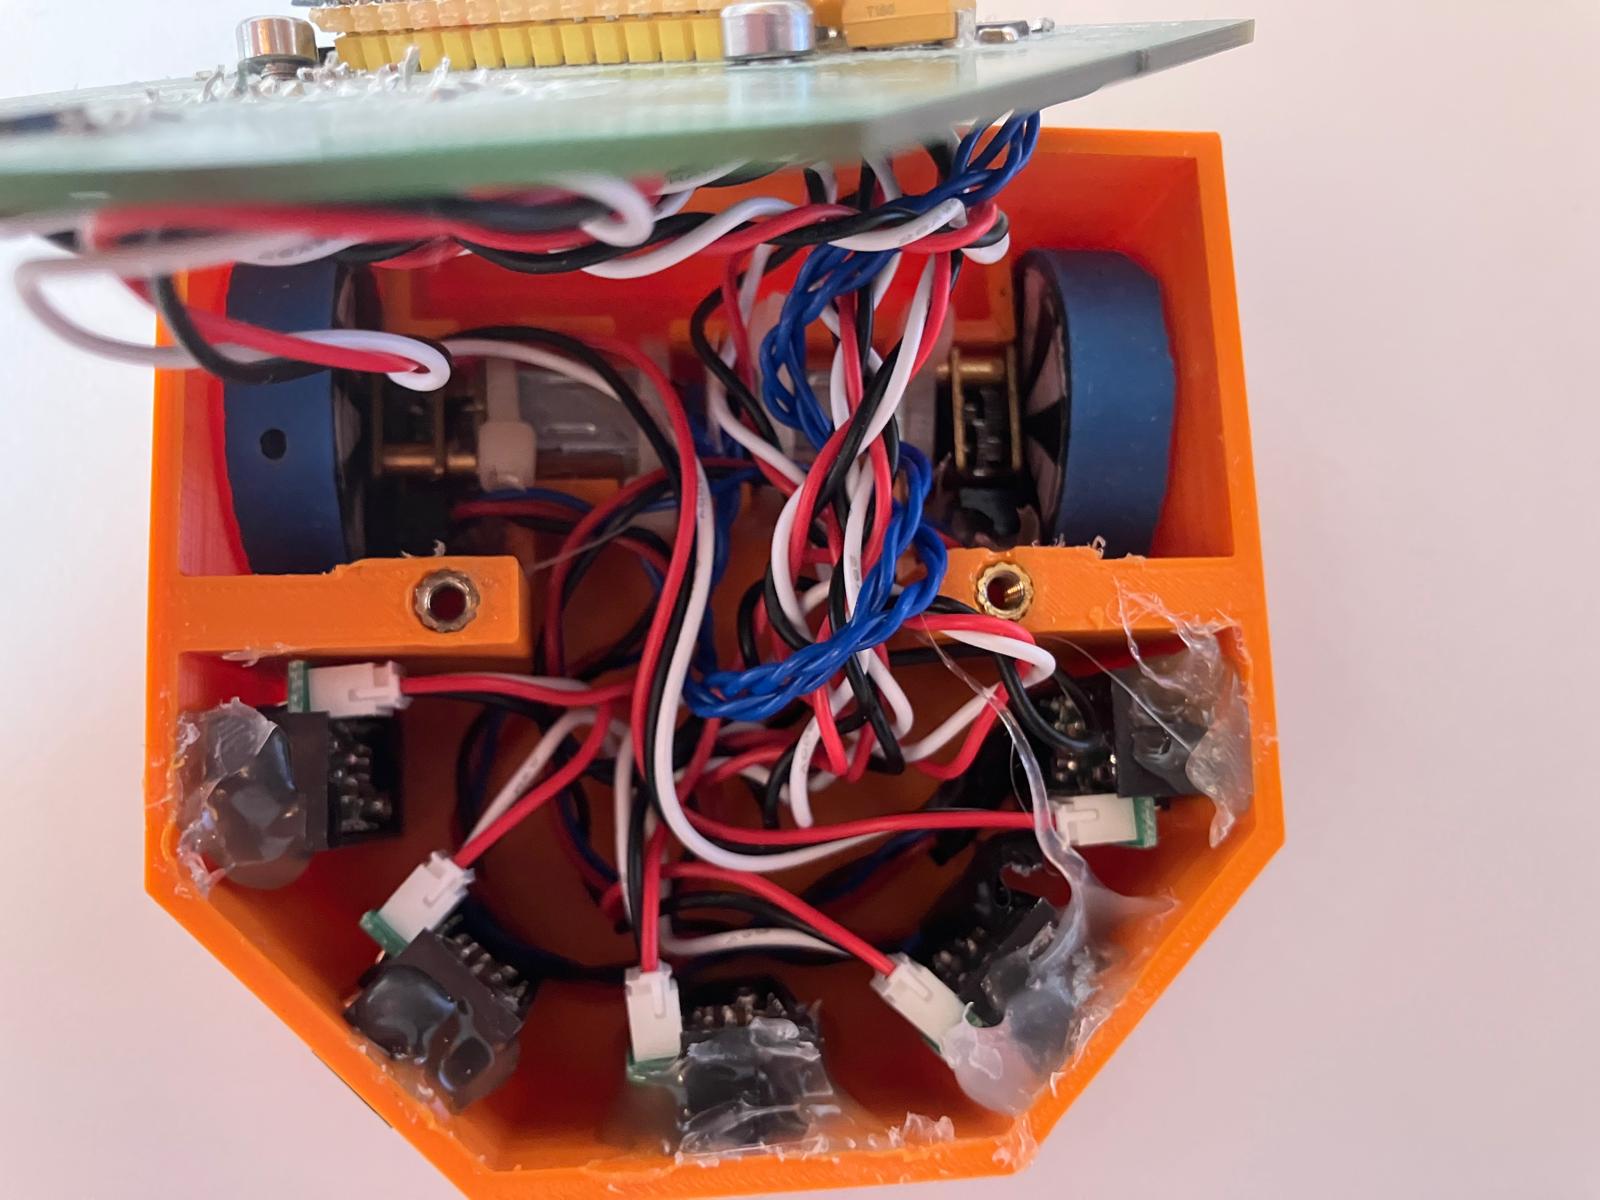
There will most probably be at least be two different softwares, one from Jonas and one from Steven, plus maybe some optional enhanced variants.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 0R0 | resistors:R_0603 | R8, R11, R12, R15, R28, R31, R33, R35, R37 |
| 9 | dnp | resistors:R_0603 | R9, R10, R13, R14, R16, R17, R18, R19, R20 |
| 7 | CONN_01X03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | P4, P5, P6, P7, P8, P9, P10 |
| 6 | 10k | resistors:R_0603 | R2, R3, R4, R5, R26, R27 |
| 5 | dnp | capacitors:C_0603 | C1, C14, C15, C16, C17 |
| 4 | 22u | capacitors:C_1206 | C12, C13, C19, C20 |
| 3 | 100nF | capacitors:C_0603 | C6, C7, C10 |
| 3 | 1k | resistors:R_0603 | R1, R21, R22 |
| 3 | CONN_01X02 | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | P1, P2, P3 |
| 3 | SW_PUSH | mechanical-switches:smd_push | SW2, SW3, SW4 |
| 2 | 100R | resistors:R_0805 | R6, R7 |
| 2 | 100n | capacitors:C_0603 | C21, C22 |
| 2 | CONN_01X14 | Connector_PinHeader_2.54mm:PinHeader_1x14_P2.54mm_Vertical | P11, P12 |
| 2 | CP_Small | capacitors:TantalC_SizeX_EIA-7343 | C11, C23 |
| 2 | C_0603 | capacitors:C_0603 | C2, C3 |
| 2 | LT1117 | SOT_TO:SOT-223 | U3, U5 |
| 2 | Led_Small | LEDs:LED_0603 | D2, D3 |
| 2 | MHP_3.2_5.0 | MECH_mounting_holes:MHP_3.2_5.0 | MECH1, MECH2 |
| 2 | R_0603 | resistors:R_0603 | R23, R24 |
| 1 | 10nF | capacitors:C_0603 | C9 |
| 1 | 120nF | capacitors:C_0603 | C5 |
| 1 | 2.2uF | capacitors:C_0603 | C8 |
| 1 | 4k7 | resistors:R_0603 | R25 |
| 1 | 6.8nF | capacitors:C_0603 | C4 |
| 1 | BC847 | SOT_TO:SOT-23 | Q1 |
| 1 | BNO055 | LGA:LGA-28-5832 | U4 |
| 1 | CONN_01X04 | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | P13 |
| 1 | DRV8833 | SSOP:TSSOP-16-1EP_4.4x5mm_Pitch0.65mm | U2 |
| 1 | ESP32_WROOM_32 | MODULE_compute:ESP32-WROOM-32 | U1 |
| 1 | LED_Small | LEDs:LED_0603 | D1 |
| 1 | SPEAKER | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | SP1 |
| 1 | switches:Würth_WS-SLTV | mechanical-switches:WE_450404015514 | SW1 |
dreamster/dreamster-board
Specialized Arduino board which is the heart of the Dreamster Robot.

MAWoodMain/ESP-Reflow-Oven
A retro fit of a Lidl middle aisle mini oven into a home reflow oven


Project-SkyFall/CanSat-2023
This is repository for Czech CanSat team Project SkyFall


RoboticsBrno/Robutek
Robůtek je robotická platforma založená na čipu ESP32-S3. Je velice rozšitiřelný, ale ze základu umí jezdit, kreslit fixou, jezdit po čáře, pohybovat se bludištěm. Programování je přes Jaculus.

It measures 80 × 80.2 mm and has 2 copper layers, 1.6 mm thick.
83 parts, built around the ESP32-WROOM-32U, DRV8833PW, BNO055 and BC847. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the wuehr1999/micromouse repository on GitHub, at the commit this page was made from: the board is kicad/pcb/micromouse/micromouse.kicad_pcb and its schematic kicad/pcb/micromouse/micromouse.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).