4 layers95.9 × 96.5 mm

 walmis/BLDC-Servo43
FOC Motor Controller for 57BLF0x NEMA brushless motor
BLDC driver is an open-source printed circuit board by walmis, from the walmis/BLDC-Servo repository on GitHub. It is a 2-layer board of 40 × 24 mm with 107 parts on 87 nets, routed with 1,101 tracks and 383 vias.
It is built around the STM32L412CBU6, SN75176AD and MIC5504-3.3YM5, with the FDMS8018, BC807 and SMAJ24A among its other parts. Its parts include 37 capacitors, 37 resistors, 9 ICs, 7 transistors and 4 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


This project implements a FOC motor controller board for 57BLF0x series NEMA brushless motor.
The project goals are:
The main components are:
The board attaches directly to the motor casing with mosfets in direct contact (with thermal paste). This makes a good heatsink for power dissipation.
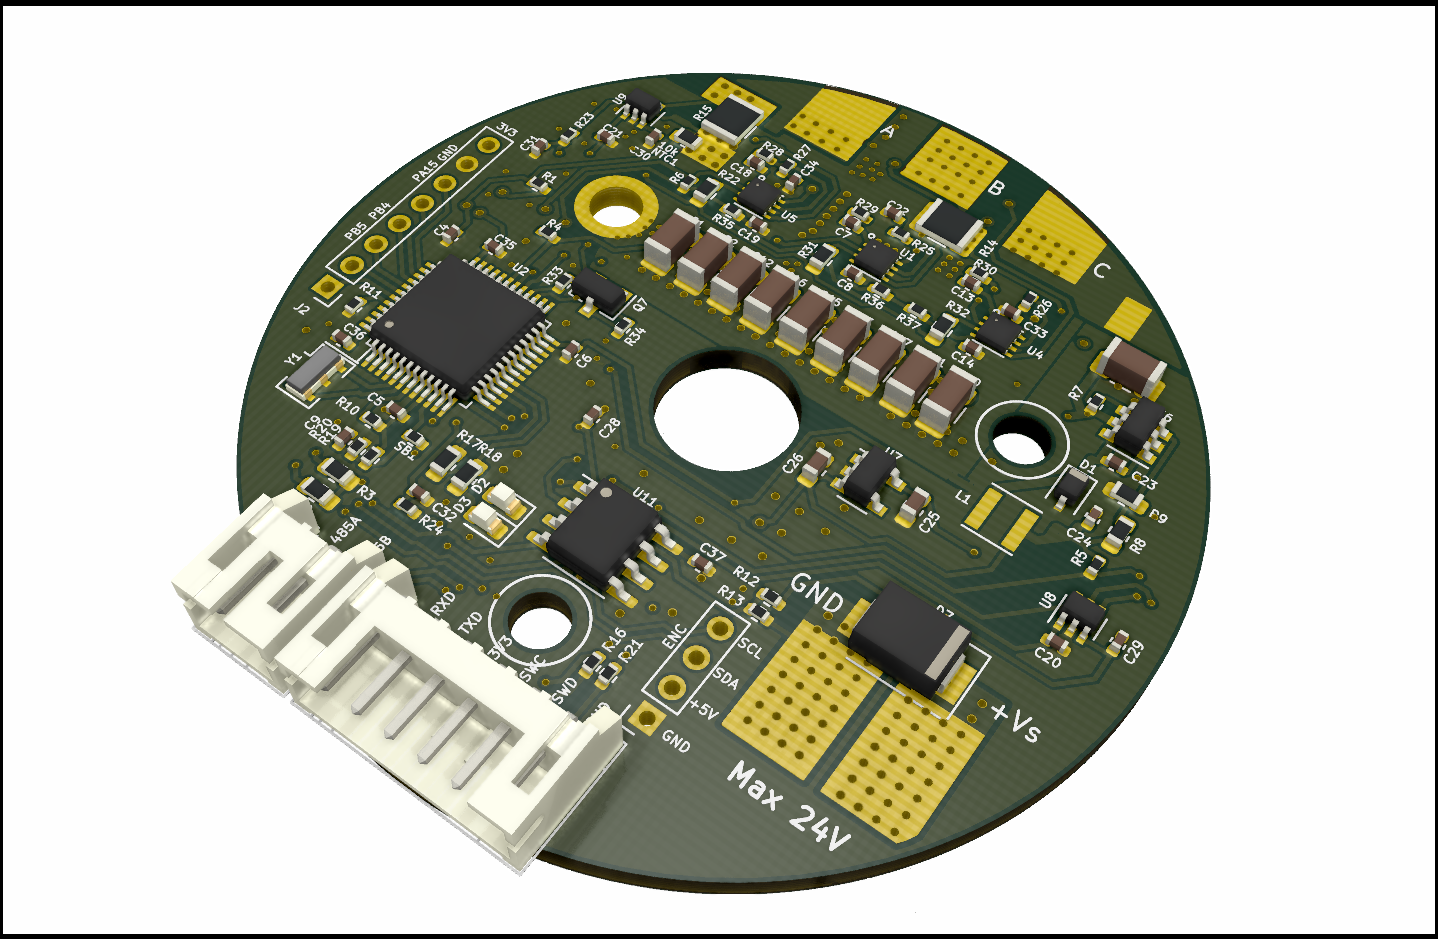
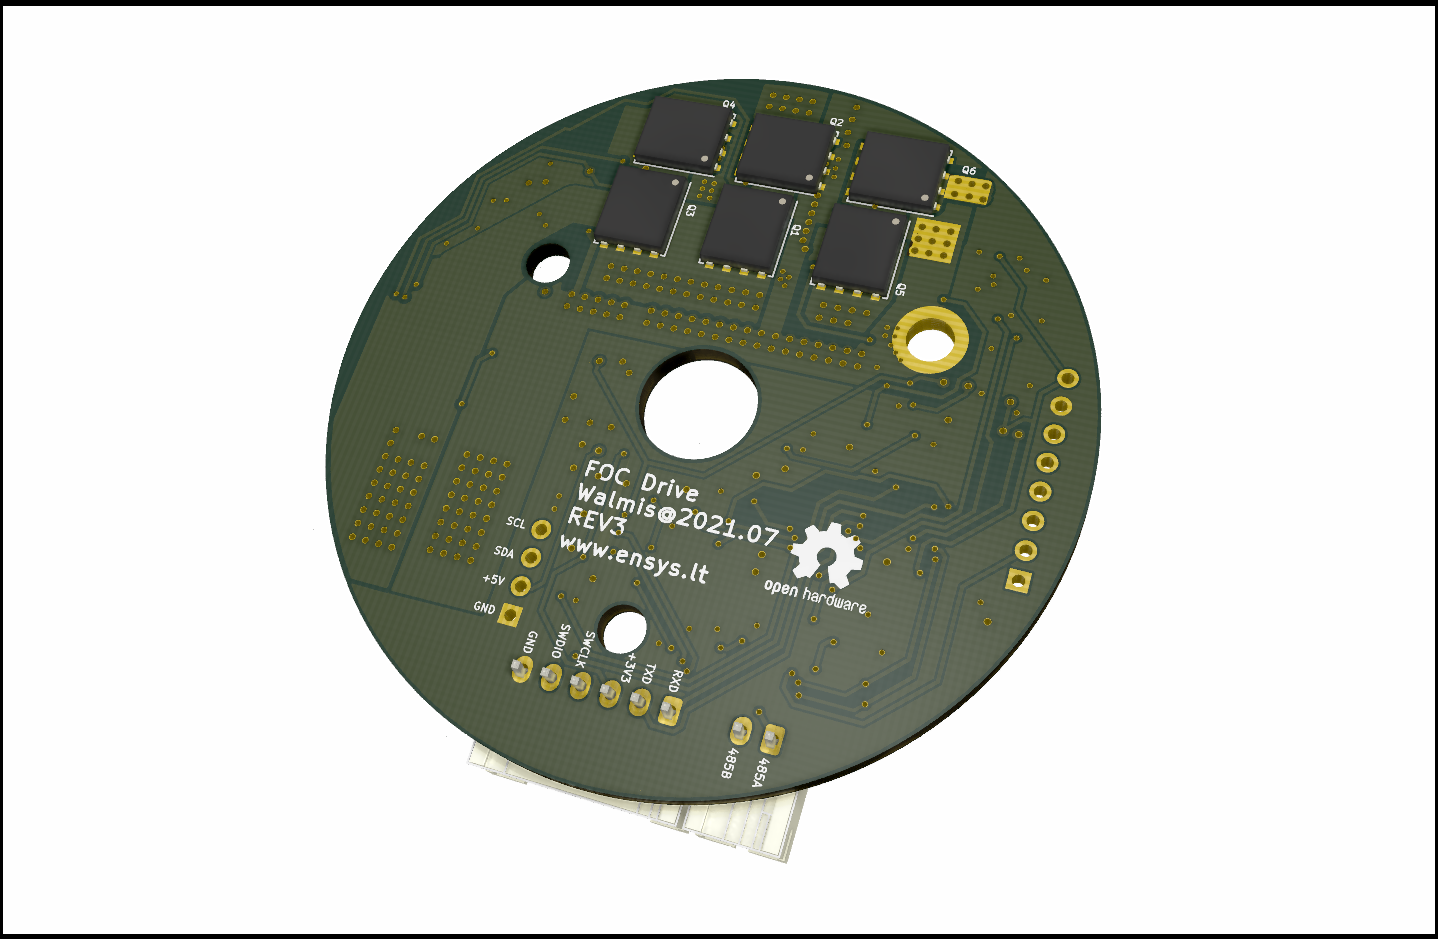
| Qty | Value | Footprint | References |
|---|---|---|---|
| 16 | 100nF | Capacitor_SMD:C_0402_1005Metric | C4, C5, C6, C7, C9, C13, C18, C20, C21, C23, C28, C29, C30, C35, C36, C37 |
| 10 | 10uF | Capacitor_SMD:C_1206_3216Metric | C1, C2, C3, C10, C11, C12, C15, C16, C17, C27 |
| 7 | 1k | Resistor_SMD:R_0402_1005Metric | R4, R5, R6, R19, R20, R33, R34 |
| 6 | FDMS8018 | Package_TO_SOT_SMD:TDSON-8-1 | Q1, Q2, Q3, Q4, Q5, Q6 |
| 4 | 100 | Resistor_SMD:R_0402_1005Metric | R16, R21, R23, R24 |
| 4 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R10, R11, R13 |
| 4 | 1uF | Capacitor_SMD:C_0402_1005Metric | C8, C14, C19, C24 |
| 3 | 0 | Resistor_SMD:R_0603_1608Metric | R22, R31, R32 |
| 3 | 1 | Resistor_SMD:R_0402_1005Metric | R35, R36, R37 |
| 3 | 10 | Resistor_SMD:R_0402_1005Metric | R28, R29, R30 |
| 3 | 1R | Resistor_SMD:R_0402_1005Metric | R25, R26, R27 |
| 3 | 22nF | Capacitor_SMD:C_0402_1005Metric | C22, C33, C34 |
| 3 | NCP81151B | Package_DFN_QFN:DFN-8-1EP_2x2mm_P0.5mm_EP0.9x1.5mm | U1, U4, U5 |
| 3 | Net-Tie_2 | NetTie:NetTie-2_SMD_Pad0.5mm | NT1, NT2, NT3 |
| 2 | 0.001 | Resistor_SMD:R_1210_3225Metric | R14, R15 |
| 2 | 100k | Resistor_SMD:R_0402_1005Metric | R7, R12 |
| 2 | 1k | Resistor_SMD:R_0603_1608Metric | R17, R18 |
| 2 | 1nF | Capacitor_SMD:C_0402_1005Metric | C31, C32 |
| 2 | 1uF | Capacitor_SMD:C_0603_1608Metric | C25, C26 |
| 2 | 2.2k | Resistor_SMD:R_0603_1608Metric | R2, R3 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D2, D3 |
| 2 | NCS213RSQT2G | Package_TO_SOT_SMD:SOT-363_SC-70-6 | U8, U9 |
| 1 | 0 | Resistor_SMD:R_0402_1005Metric | SB1 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | NTC1 |
| 1 | 30V | Diode_SMD:D_SOD-323 | D1 |
| 1 | 33k | Resistor_SMD:R_0603_1608Metric | R8 |
| 1 | 4.7uH | Inductor_SMD:L_Taiyo-Yuden_MD-3030 | L1 |
| 1 | 6.2k | Resistor_SMD:R_0603_1608Metric | R9 |
| 1 | 8MHz | Crystal:Resonator_SMD_muRata_CSTxExxV-3Pin_3.0x1.1mm | Y1 |
| 1 | BC807 | Package_TO_SOT_SMD:SOT-23 | Q7 |
| 1 | Conn_01x02 | Connector_JST:JST_PH_S2B-PH-K_1x02_P2.00mm_Horizontal | J3 |
| 1 | Conn_01x06 | Connector_JST:JST_PH_S6B-PH-K_1x06_P2.00mm_Horizontal | J1 |
| 1 | Conn_01x06 | Connector_PinHeader_2.00mm:PinHeader_1x08_P2.00mm_Vertical | J2 |
| 1 | Encoder | Connector_PinSocket_2.00mm:PinSocket_1x04_P2.00mm_Vertical | J4 |
| 1 | MIC5504-3.3YM5 | Package_TO_SOT_SMD:SOT-23-5 | U7 |
| 1 | MP2359 | Package_TO_SOT_SMD:SOT-23-6 | U6 |
| 1 | MountingHole_Pad | MountingHole:MountingHole_3.2mm_M3_DIN965_Pad | H1 |
| 1 | SMAJ24A | Diode_SMD:D_SMB | D7 |
| 1 | SN75176AD | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U11 |
| 1 | STM32L412CB | Package_QFP:LQFP-48_7x7mm_P0.5mm | U2 |
The 106 most common of 107 parts.
It measures 40 × 24 mm and has 2 copper layers, 1.6 mm thick.
107 parts, built around the STM32L412CBU6, SN75176AD, MIC5504-3.3YM5 and FDMS8018. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the walmis/BLDC-Servo repository on GitHub, at the commit this page was made from: the board is BLDC-driver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask walmis before reusing the design.

MR-DOS/MWGEN-G1
12.5 MHz - 6400 MHz (LMX2572) or even up to 20 GHz (LMX2595) generator board with int./ext. reference.

dermatoid-collab/EVC_FW
Progetto hardware e firmware del sistema di controllo di un ascensore domestico a trazione (TTF) di LiftingItalia s.r.l. Quattro schede basate su STM32F446, collegate in CAN; il motore è comandato da un VFD.


ay2718/RadomeMotorController
The Radome CAN protocol is very simple. Send azimuth commands to address 0x1 and elevation commands to address 0x2. Azimuth and elevation reply back from addresses 0x101 and 0x102 respectively.


Aiyin4Da-2/Main_Ctrl_H7
STM32H723VGT6 MainCtrlBoard Author: Aiyin4DaGLD · Hardware: v1.2 · Updated: 2026-08-21