2 layers99.1 × 44.5 mm

 VectorSpaceHQ/VS_combat_robot5
A combat robot RC system using the ESP32.
Receiver is an open-source printed circuit board by VectorSpaceHQ, from the VectorSpaceHQ/VS_combat_robot repository on GitHub. It is a 4-layer board of 41 × 41 mm with 25 parts on 26 nets, routed with 76 tracks and 4 vias.
It is built around the RZ7886 and UA78M33CDCYRG3. Its parts include 4 resistors, 3 ICs, 2 capacitors and 1 inductor. It belongs with the robots and motor control boards and the ESP32 and RISC-V boards of this library.


This is an open source, low cost, DIY combat robot kit. It is designed for use with antweight (1lb) and beetleweight (3lb) combat robots.
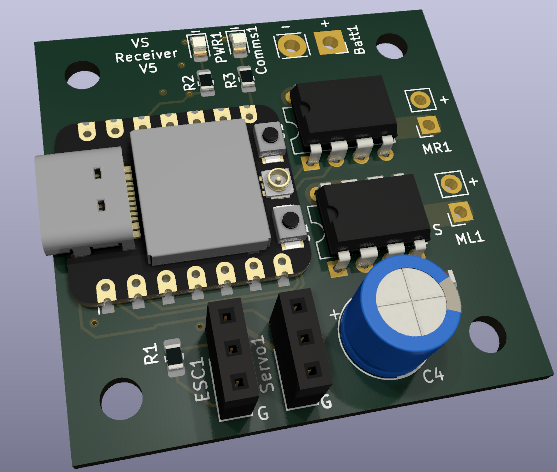
This repository includes PCB designs for the transmitter and receiver, the associated software, as well as a simple 3d printable chassis and controller design.
If the following error occurs when trying to upload to the ESP32, the fix is to hold pin D9 to ground while powering on the board.
A fatal error occurred: Invalid head of packet (0x01): Possible serial noise or corruption. Failed uploading: uploading error: exit status 2
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 3 | 680 ohm | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R3, R4 |
| 3 | LED | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | Comms1, Comms2, PWR1 |
| 2 | Conn_01x02_Female | custom:battery_pads | Batt1, ESC_PWR1 |
| 2 | RZ7886 | Package_DIP:DIP-8_W7.62mm | U1, U2 |
| 1 | .1 uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C3 |
| 1 | 10k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1 |
| 1 | 470 uF | Capacitor_THT:CP_Radial_D8.0mm_P3.80mm | C4 |
| 1 | Conn_01x02_Female | custom:DC_motor_output | ML1 |
| 1 | ESC | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | ESC_logic1 |
| 1 | L7806 | Package_TO_SOT_SMD:TO-263-2_TabPin1 | L7806 |
| 1 | LOGO | VS-Logo:VS-Logo_small | G*** |
| 1 | Servo | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | Servo1 |
| 1 | UA78M33CDCYRG3 | ua78-vreg:SOT230P700X180-4N | PS1 |
| 1 | XIAO ESP32C3 | XIAO_ESP32C3:xiao_esp32c3 | U3 |
| 1 | motor_output | custom:DC_motor_output | MR1 |


failsmakes/RC_Receiver_PCB_ESP32-WROOM
Bu proje, RC-Receiver-ESP yazılımı için tasarlanmış ESP32-WROOM tabanlı RC alıcı devresinin PCB çizimini içerir. Tasarım KiCad 10.0.1 ile hazırlanmıştır.

menloresearch/asimov-1
v1 of Asimov, an open-source humanoid robot

opentac/opentac
OpenTac: open tools to design, fabricate, read and simulate flex-PCB tactile skins that sense normal and shear force, for any robot surface.

ManiacalLabs/AllPixel
Firmware and Board Designs for the AllPixel LED Controller Board: Please direct questions and support requests to https://forum.maniacallabs.com/c/hardware - The Issues list here should be reserved for actual bugs.


kounocom/Mumo
A compact 13×18mm IMU module featuring the TDK InvenSense ICM-45686 6-axis IMU with integrated 32.768kHz clock and QST QMC6309H 3-axis magnetometer.
It measures 41 × 41 mm and has 4 copper layers, 1.6 mm thick.
25 parts, built around the RZ7886 and UA78M33CDCYRG3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the VectorSpaceHQ/VS_combat_robot repository on GitHub, at the commit this page was made from: the board is receiver/pcb/receiver.kicad_pcb and its schematic receiver/pcb/receiver.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask VectorSpaceHQ before reusing the design.