4 layers116.8 × 56.7 mm
Engine Controller
SunDevilRocketry/Liquid-Engine-Controller
Main microcontroller board for embedded control of SDR's liquid bipropellant engine.
119 parts1

 SunDevilRocketry/Flight-Computer5
General purpose flight computer for high powered rocketry projects.
Flight Computer is an open-source printed circuit board by SunDevilRocketry, from the SunDevilRocketry/Flight-Computer repository on GitHub. It is a 4-layer board of 93.7 × 43.7 mm with 113 parts on 167 nets, routed with 1,381 tracks and 165 vias.
It is built around the CP2102-GMR, BMM150 and BMP390, with the SST25VF040B-50-4I-S2AE-T, TS391IYLT and BMI323 among its other parts. Its parts include 36 resistors, 25 capacitors, 12 ICs, 12 connectors and 10 diodes. It belongs with the STM32 boards of this library.


Current PCB Revision: 2.0
PCB Part Number: A0002
The Avionics team aims to produce a general purpose flight computer for use in high powered rocketry projects that require an embedded processor specialized for state estimation and control system implementation. The Avionics flight computer PCB uses an ARM Microcontroller with embedded control and navigation sensors to provide a computationally capable embedded protoyping platform for high powered rocketry projects with minimal wiring and a small form factor.
Working Directory Structure:
doc: documentation
src: source design files, e.g. schematic and board files
lib: libraries for schematic symbols and footprints
production: files needed for pcb fabrication, e.g. gerbers, profile, drill fi le
sim: simulation files
cad: 3d models
img: images of circuit/footprints for github display
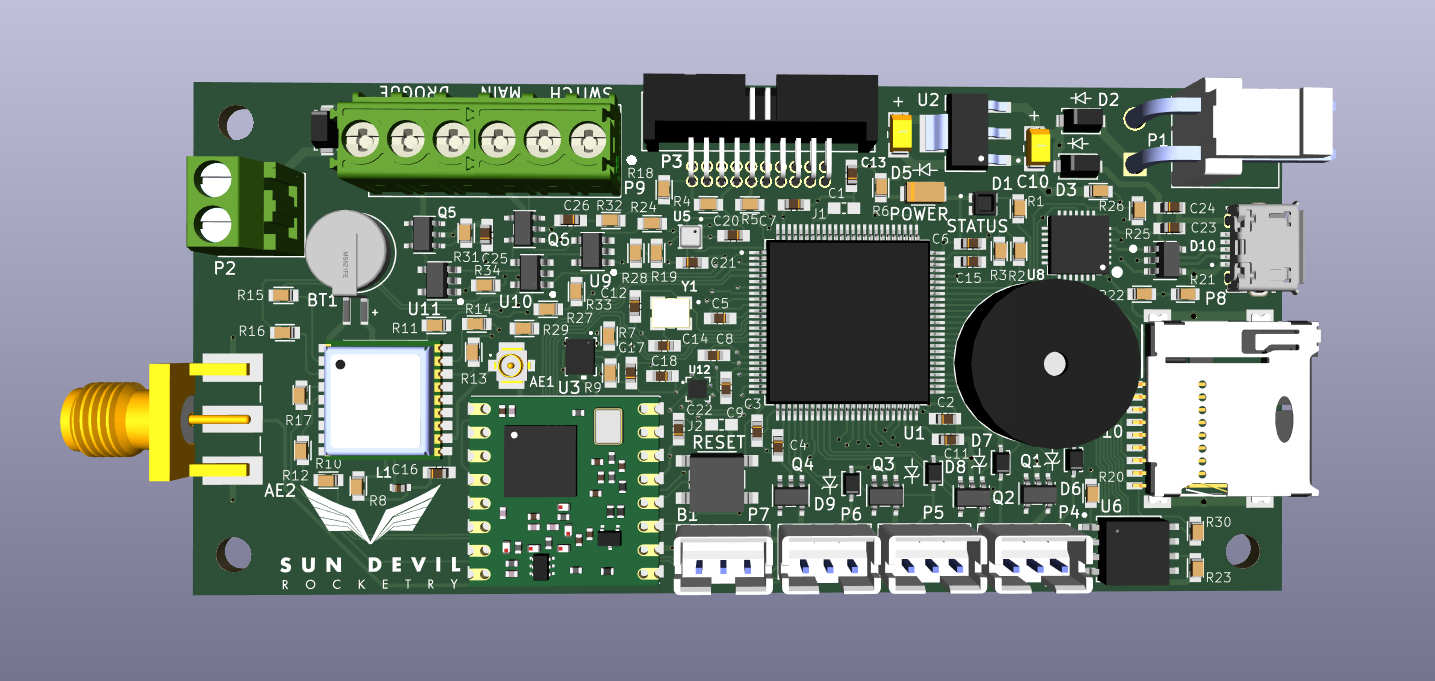
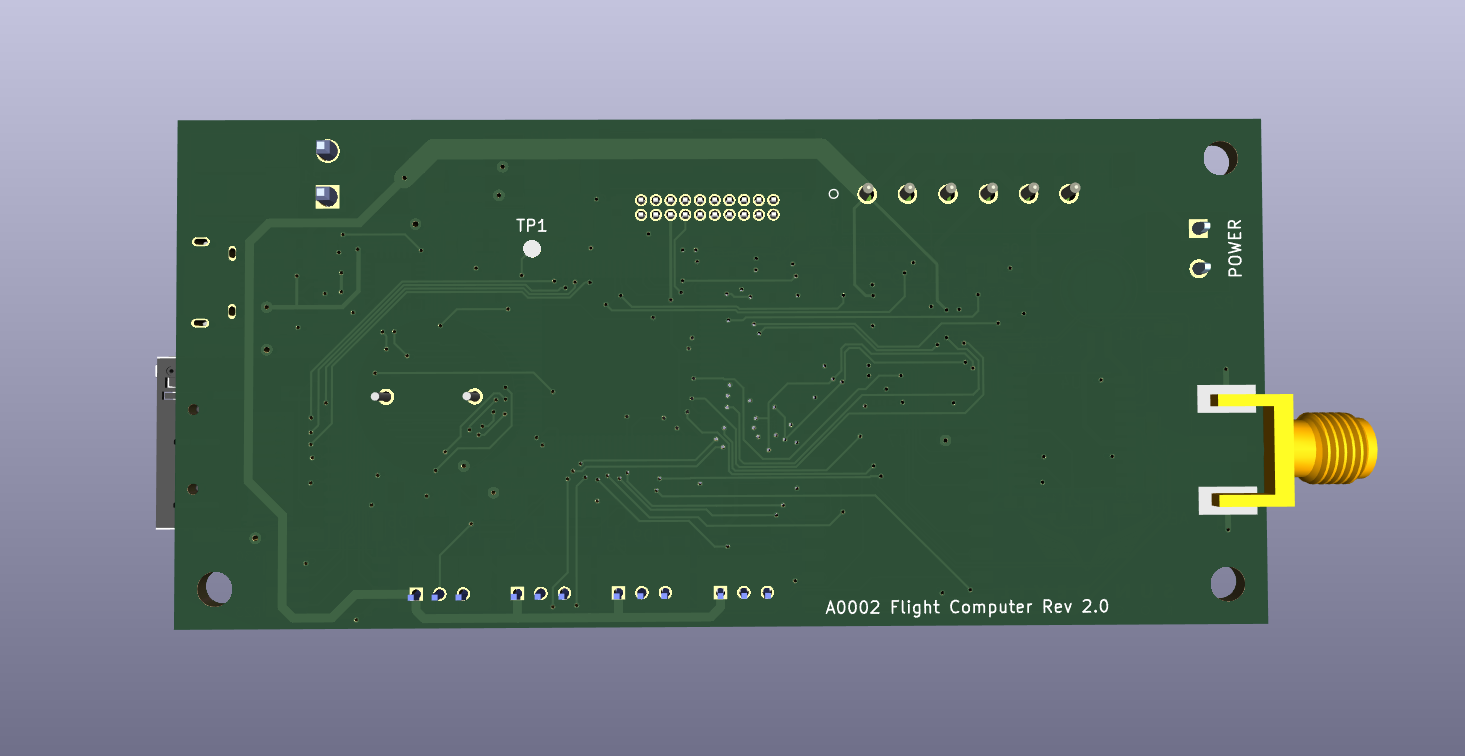
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 0.1uF | Flight-Computer:CAP_0603 | C2, C3, C4, C5, C6, C7, C8, C17, C18, C20, C21, C22, C24 |
| 12 | 10k | Flight-Computer:RES_0603 | R20, R21, R23, R24, R26, R28, R29, R30, R33, R34, R35, R36 |
| 8 | 33 | Flight-Computer:RES_0603 | R10, R11, R12, R13, R14, R15, R16, R17 |
| 6 | QS5U17TR | Flight-Computer:QS5U17TR | Q1, Q2, Q3, Q4, Q5, Q6 |
| 4 | 100k | Flight-Computer:RES_0603 | R4, R5, R31, R32 |
| 4 | 1uF | Flight-Computer:CAP_0603 | C9, C23, C25, C26 |
| 4 | 440054-3 | Flight-Computer:440054-3 | P4, P5, P6, P7 |
| 4 | MM3Z3V3B | Flight-Computer:MM3Z3V3B | D6, D7, D8, D9 |
| 3 | 4.7k | Flight-Computer:RES_0603 | R18, R19, R25 |
| 3 | Mounting-Hole | Flight-Computer:MountingHole_3mm | H1, H2, H3 |
| 3 | SM5819PL-TP | Flight-Computer:SM5819PL-TP | D2, D3, D4 |
| 3 | TS391IYLT | Flight-Computer:TS391IYLT | U9, U10, U11 |
| 2 | 10k | Engine-Controller:RES_0603 | R7, R9 |
| 2 | 10uF | Flight-Computer:T491A106K010AT | C10, C13 |
| 2 | 2.2uF | Flight-Computer:CAP_0603 | C11, C15 |
| 2 | 8pF | Flight-Computer:CAP_0603 | C12, C14 |
| 1 | 0.01uF | Flight-Computer:CAP_0603 | C16 |
| 1 | 0734120110 | Flight-Computer:73412-0110 | AE1 |
| 1 | 10 | Flight-Computer:RES_0603 | R8 |
| 1 | 142-0701-851 | Flight-Computer:142-0701-851 | AE2 |
| 1 | 1546551-2 | Flight-Computer:1546551-2 | P2 |
| 1 | 1984659 | Flight-Computer:1984659 | P9 |
| 1 | 1k | Flight-Computer:RES_0603 | R27 |
| 1 | 20k | Flight-Computer:RES_0603 | R22 |
| 1 | 240 | Flight-Computer:RES_0603 | R6 |
| 1 | 27nH | Flight-Computer:L-07C27NJV6T | L1 |
| 1 | 280 | Flight-Computer:RES_0603 | R3 |
| 1 | 3220-20-0200-00 | Flight-Computer:3220-20-0200-00 | P3 |
| 1 | 4.7uF | Flight-Computer:CAP_0603 | C1 |
| 1 | 647676-2 | Flight-Computer:647676-2 | P1 |
| 1 | 68 | Flight-Computer:RES_0603 | R1 |
| 1 | 82 | Flight-Computer:RES_0603 | R2 |
| 1 | AT-1438-TWT-R | Flight-Computer:AT-1438-TWT-R | BZ1 |
| 1 | BMI323 | Flight-Computer:BMI323 | U3 |
| 1 | BMM150 | Flight-Computer:BMM150 | U12 |
| 1 | BMP390 | Flight-Computer:BMP390 | U5 |
| 1 | CLMVC-FKA-CL1D1L71BB7C3C3 | Flight-Computer:CLMVC-FKA-CL1D1L71BB7C3C3 | D1 |
| 1 | CP2102-GMR(QFN28) | Flight-Computer:CP2012-GMR | U8 |
| 1 | ECS-240-18-33-JGN-TR | Flight-Computer:ECS-240-18-33-JGN-TR | Y1 |
| 1 | Jumper_NO | Engine-Controller:Jumper-NO | J2 |
| 1 | Jumper_NO | Flight-Computer:Jumper-NO | J1 |
| 1 | LMS8117AMP-3.3_NOPB | Flight-Computer:LMS8117AMP-3.3NOPB | U2 |
| 1 | Logo | Flight-Computer:Logo | LOGO1 |
| 1 | MAX-8C-0-10 | Flight-Computer:MAX-8C-0 | U4 |
| 1 | MS614SE-FL28E | Flight-Computer:MS621FE-FL11E | BT1 |
| 1 | Micro_SD_Card | Flight-Computer:MEM2075-00-140-01-A | P10 |
| 1 | PTS647SM38SMTR2LFS | Flight-Computer:PTS647SM38SMTR2LFS | B1 |
| 1 | RFM95W-868S2 | Flight-Computer:RFM95 | U7 |
| 1 | SML-LX1206GC-TR | Flight-Computer:SML-LX1206GC-TR | D5 |
| 1 | SP0504BAHTG | Flight-Computer:SP0504BAHTG | D10 |
| 1 | SST25VF040B-50-4I-S2AE-T | Flight-Computer:SST25VF040B-50-4I-S2AE-T | U6 |
| 1 | STM32H750VBTx | Flight-Computer:STM32H750VBT6 | U1 |
| 1 | TP | Flight-Computer:TP | TP1 |
| 1 | USB | Flight-Computer:10118194-0001LF | P8 |
It measures 93.7 × 43.7 mm and has 4 copper layers, 1.6 mm thick.
113 parts, built around the CP2102-GMR, BMM150, BMP390 and SST25VF040B-50-4I-S2AE-T. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the SunDevilRocketry/Flight-Computer repository on GitHub, at the commit this page was made from: the board is src/Flight-Computer/Flight-Computer.kicad_pcb and its schematic src/Flight-Computer/Connectors.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask SunDevilRocketry before reusing the design.
SunDevilRocketry/Liquid-Engine-Controller
Main microcontroller board for embedded control of SDR's liquid bipropellant engine.

cacost12/SDR-Flight-Computer-Lite-PCB
Current PCB Revision: 1.0 PCB Part Number: A0007

cacost12/SDR-Ground-Station-Telemetry-PCB
Current PCB Revision: 1.0 PCB Part Number: A0005

cacost12/SDR-Liquid-Engine-Controller-PCB
Current PCB Revision: 4.0 PCB Part Number: L0002


SunDevilRocketry/Wheatstone-Bridge
Pressure transducer signal emulation board to facilitate electronics testing

SunDevilRocketry/Valve-Controller
Controller for managing the liquid engine's solenoid valves and servo-actuated ball valves.

GonzaCerv/noah-hardware
This repo contains all the hardware description for the Noah project. Here lies 3D models, electronics PCB and Firmware software of the robot.