4 layers36 × 50.2 mm
Racer
StuckAtPrototype/Racer
These are structured into their own files. I could have used submodules, but decided against it.
83 parts3.8kApache-2.0
 StuckAtPrototype/Racer3.8k
These are structured into their own files. I could have used submodules, but decided against it.
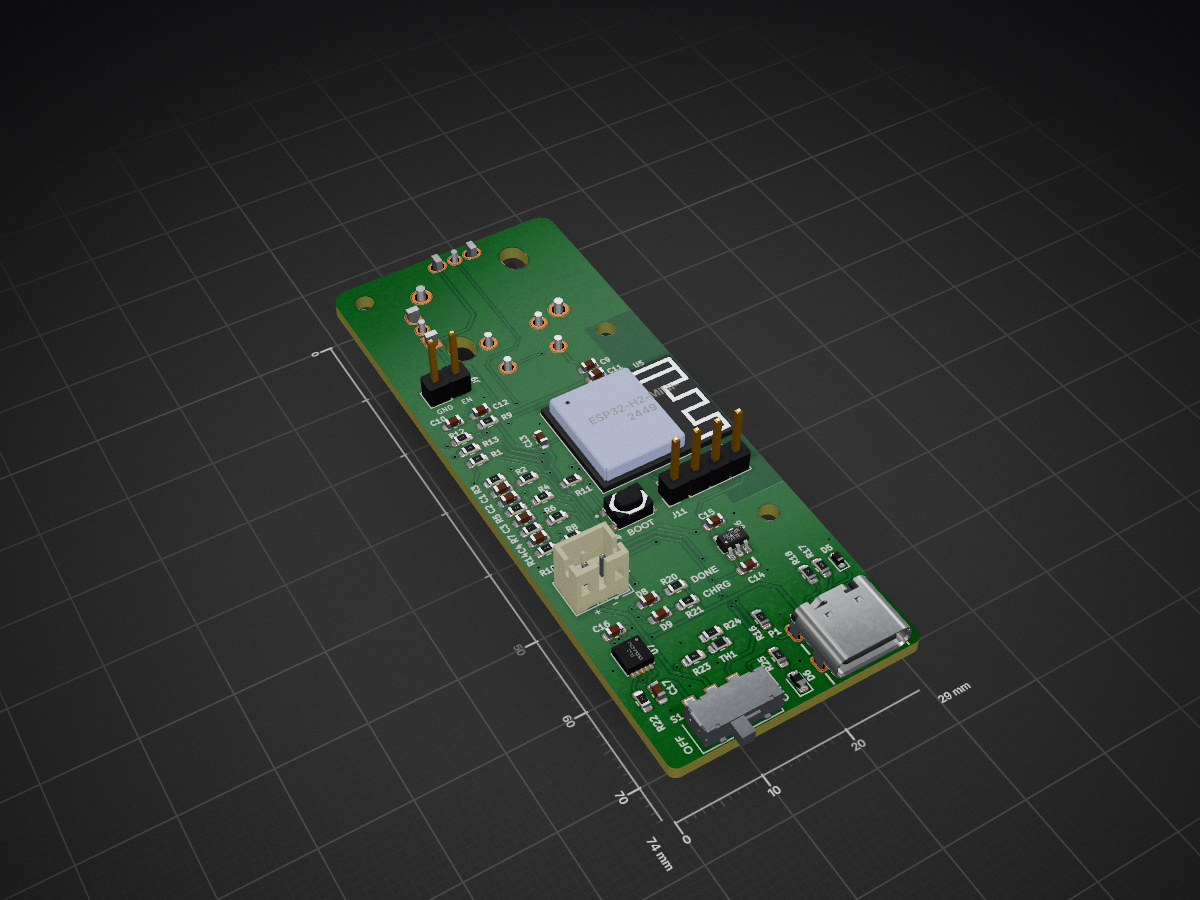
Controller is an open-source printed circuit board by StuckAtPrototype, from the StuckAtPrototype/Racer repository on GitHub, published under the Apache-2.0 licence. It is a 4-layer board of 29 × 74 mm with 66 parts on 57 nets, routed with 430 tracks and 62 vias.
It is built around the ESP32-H2-MINI-1U, MCP73833 and THB001P, with the TL4100AF240QG, JS102011SAQN and TPD1E10B06DPYR among its other parts. Its parts include 23 resistors, 13 capacitors, 7 diodes, 6 switches and 4 ICs. It belongs with the ESP32 and RISC-V boards of this library.


thank you for the overwhelmingly positve support!! such an inspiration to keep making fun open source content!
Lots of new improvements and I am now selling a kit for these! Check out the video here:
https://www.youtube.com/watch?v=FulhEs5R5WU

A bit of a back-story of how this project came to be.
Sub if you like what you see.
Some pictures of the project
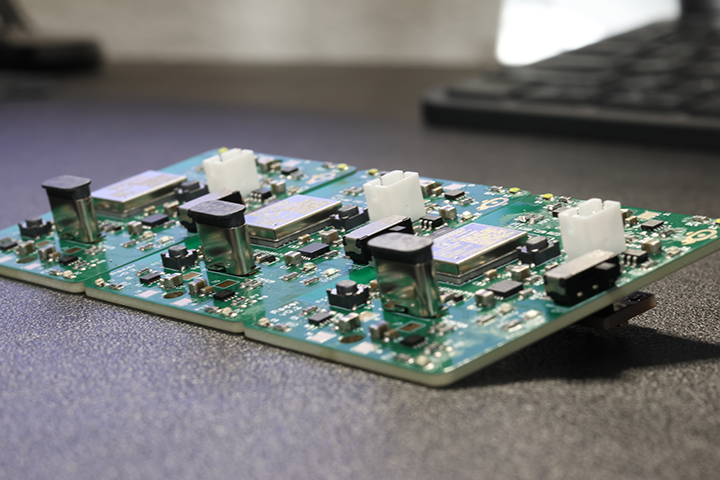
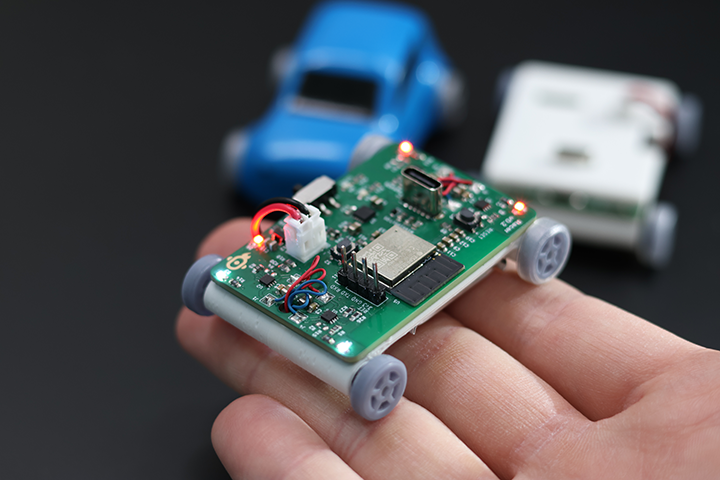
https://github.com/StuckAtPrototype/Thumbtroller
The project consists of
These are structured into their own files. I could have used submodules, but decided against it.
Code for the little car. This lives on the ESP32
PDF schematic included for your viewing pleasure.
All the gerber files you'd need to send to a fab house.
All the files you'd need to expand and work on this further. If you'd like.
All the step files you need to make one of these. Extrusion printer works well for this part.
A bit of caution on this one.. you'll need an SLA printer.
Did anyone say neural networks?
This folder has all the python code you'd need to train up your own neural network for the car. It also consists scripts that let you drive it using a keyboard -- just in case you dont want to make a physical controller.
Training the neural network is as simple as running the training script with the data in the color_data.txt file. For data format see the sample data in the file. You need to stick to the formatting.
To train run python trainer.py
To run the script python controller.py
Use w s a d for control. Modify the script for different speeds, etc
Protocol for motor control
60,1,60,1,5 -- translates to:
motor side A: speed 60, direction forward
motor side B: speed 60, direction forward
500 miliseconds run time
See firmware file motor.c if you need more details
Let me know if you ever make one of these, I'd love to see it. Seriously, that'd be exciting and inspiring to keep making my projects open source!
http://www.apache.org/licenses/LICENSE-2.0
Thanks to Michael Angerer for his open sourced esp32_ble_ota project. I used it to get BLE running in this project. His blog post and github repo are a great resource. Check it out. https://github.com/michael-angerer/esp32_ble_ota
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 10k | Resistor_SMD:R_0603_1608Metric | R2, R4, R6, R8, R9, R10, R11 |
| 5 | 1uF 25V | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C10 |
| 5 | LED | Capacitor_SMD:C_0603_1608Metric | D1, D2, D3, D8, D9 |
| 5 | TL4100AF240QG_ | kicad_reformed_custom_IC:SW_PTS810_SJM_250_SMTR_LFS | S2, S3, S4, S5, S6 |
| 4 | 100k | Resistor_SMD:R_0603_1608Metric | R3, R5, R7, R14 |
| 4 | 200 | Resistor_SMD:R_0603_1608Metric | R1, R12, R13, R25 |
| 3 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | C11, C12, C13 |
| 2 | 1.43K | Resistor_SMD:R_0603_1608Metric | R22, R23 |
| 2 | 10uF | Capacitor_SMD:C_0603_1608Metric | C15, C16 |
| 2 | 470 | Resistor_SMD:R_0603_1608Metric | R20, R21 |
| 2 | 5k1 | Resistor_SMD:R_0603_1608Metric | R17, R18 |
| 1 | 0_IN1 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP1 |
| 1 | 0_IN2 | TestPoint:TestPoint_Pad_1.0x1.0mm | TP2 |
| 1 | 1M | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | 2.2uF | Capacitor_SMD:C_0603_1608Metric | C14 |
| 1 | 22uF | Capacitor_SMD:C_0603_1608Metric | C17 |
| 1 | 47uF | Capacitor_SMD:C_0603_1608Metric | C9 |
| 1 | 75K | Resistor_SMD:R_0603_1608Metric | R24 |
| 1 | AP2204 | kicad_reformed_custom_IC:AP2204 | U6 |
| 1 | Chip Enable | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J9 |
| 1 | ESP32-H2-MINI-1 | kicad_reformed_custom_IC:MODULE_ESP32-H2-MINI-1-H2 | U5 |
| 1 | JS102011SAQN | kicad_reformed_custom_IC:SW_JS102011SAQN | S1 |
| 1 | JST 2.0 BATT | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J12 |
| 1 | LOGO | kicad_reformed_custom_IC:LOGO_6mm_microDMG | G*** |
| 1 | MCP73833 | kicad_reformed_custom_IC:SON50P300X300X100-11N | U7 |
| 1 | PWLED | Diode_SMD:D_0603_1608Metric | D6 |
| 1 | TH 10k | Resistor_SMD:R_0603_1608Metric | TH1 |
| 1 | THB001P | kicad_reformed_custom_IC:CNK_THB001P | U1 |
| 1 | TP | TestPoint:TestPoint_Pad_D1.0mm | TP3 |
| 1 | TPD1E10B06DPYR | Diode_SMD:D_SOD-523 | D5 |
| 1 | UART | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J11 |
| 1 | USB_C_Plug_USB2.0 | kicad_reformed_custom_IC:GCT_USB4105-GF-A | P1 |
The 62 most common of 66 parts.
It measures 29 × 74 mm and has 4 copper layers, 1.66 mm thick.
66 parts, built around the ESP32-H2-MINI-1U, MCP73833, THB001P and TL4100AF240QG. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the StuckAtPrototype/Racer repository on GitHub, at the commit this page was made from: the board is hardware/thumbtroller/controller.kicad_pcb and its schematic hardware/racer-sensors/sensors.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Apache-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
StuckAtPrototype/Racer
These are structured into their own files. I could have used submodules, but decided against it.

StuckAtPrototype/Racer
These are structured into their own files. I could have used submodules, but decided against it.


johndoe6345789/Racer
These are structured into their own files. I could have used submodules, but decided against it.

StuckAtPrototype/PCB_business_card_remake
A custom PCB based "business" card that lets you play a version of Flappy Bird.

cubistmind/__pCennnBeist
A custom PCB based "emniii😞😞" card that lets you play a version of Flappy Bird

andreesc/BLE-Temp-Sensor
Hardware, Firmware, and Mechanical Design Files for a Temperature Sensor Board featuring the HDC1080 sensor and Bluetooth Low Energy (BLE) connectivity.

dmcke5/ZenDeck
This is the second revision of my Mini PC based handheld Gaming PC! It is designed for a Beelink SER 5 Mini PC but could be adapted to other systems by changing the mounting brackets and outlet plate.

dmcke5/MiniPC_BMS
An all in one power managment solution for powering mini pc's with batteries!

StuckAtPrototype/AirCube
Works standalone out of the box. Pairs with Home Assistant in minutes. Other platforms are supported through community-contributed extensions.