2 layers100 × 100 mm
Flipdot H Bridge
comakingspace/FlipDotDisplay
They were bought at the Makerfaire Hannover 2016.
76 parts3
 Spacha/mobrob
Datasheets for components are found in Datasheets folder.
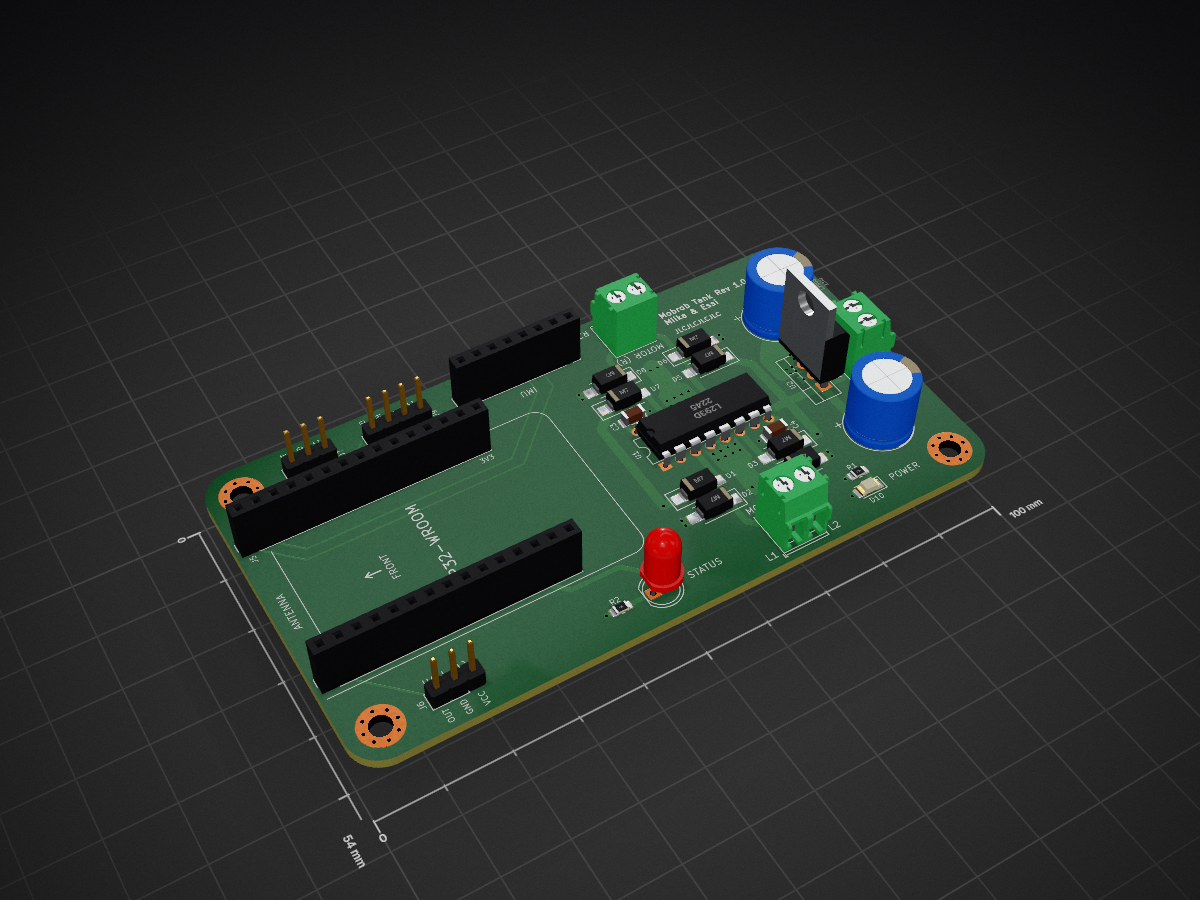
Mobrob is an open-source printed circuit board by Spacha, from the Spacha/mobrob repository on GitHub. It is a 4-layer board of 100 × 54 mm with 31 parts on 40 nets, routed with 115 tracks and 60 vias.
It is built around the L293D and L7805. Its parts include 10 diodes, 9 connectors, 4 capacitors, 2 resistors and 2 ICs. It belongs with the ESP32 boards of this library.


A mobile robot
Datasheets for components are found in Datasheets folder.
Processor & connectivity: ESP8266 | datasheet
Dual H-bridge motor driver: L293D | datasheet
Power management:
Motors & chassis: Dual motor tank chassis (3-7V)
Sensors (both for proximity and distance, and other):

I am not sure if either ESP32 or ESP8266 come in QFP format (only in QFN, no-leads). I guess JLCPCB and others also assemble these devices so maybe this is not an issue.
ESP32 would be considerably better than ESP8266. It has a lot more functionality and also has 8MB of onboard flash (ESP32-S3FN8, see ESP32-S3 datasheet, p.11).
https://www.youtube.com/watch?v=WWIy6a0T7WM&ab_channel=PlumPot
Decoupling caps (as close of the pins as possible)
External crystal? (see Phil's lab)
Note the antenna/RF part!
Careful with differential pairs
https://en.wikipedia.org/wiki/ESP32#ESP32-S3:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | M7 | Diode_SMD:D_SMA_Handsoldering | D1, D2, D3, D4, D5, D6, D7, D8 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_3.2mm_M3_Pad_Via | H1, H2, H3, H4 |
| 2 | 0.1uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C3, C4 |
| 2 | 150 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2 |
| 2 | LHALL | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6, J7 |
| 1 | 0.1uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C2 |
| 1 | 0.22uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C1 |
| 1 | ESP32_1 | Connector_PinSocket_2.54mm:PinSocket_1x15_P2.54mm_Vertical | J4 |
| 1 | ESP32_2 | Connector_PinSocket_2.54mm:PinSocket_1x15_P2.54mm_Vertical | J5 |
| 1 | IMU | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J8 |
| 1 | L293D | Package_DIP:DIP-16_W7.62mm | U1 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Vertical | U2 |
| 1 | LED_POWER | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D10 |
| 1 | LED_STATUS | LED_THT:LED_D5.0mm | D9 |
| 1 | LMOTOR | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J2 |
| 1 | POWER | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J3 |
| 1 | RMOTOR | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J1 |
| 1 | UT | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J9 |
It measures 100 × 54 mm and has 4 copper layers, 1.6 mm thick.
31 parts, built around the L293D and L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Spacha/mobrob repository on GitHub, at the commit this page was made from: the board is robot_hw/mobrob_v1.0/mobrob.kicad_pcb and its schematic robot_hw/mobrob_v1.0/mobrob.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Spacha before reusing the design.
comakingspace/FlipDotDisplay
They were bought at the Makerfaire Hannover 2016.


Yourself1011/sumo-bot
The code for Li Feng Yin and Daniel Zhang's sumo robot, for TEJ3MI


mrpossoms/openturret
Opensource designs and software for autonomously aiming gimble