
2 layers
LM80C R6
leomil72/LM80C
A Z80-based homebrew computer withTMS9918, AY-3-8910, Z80 CTC, Z80 PIO, and Z80 SIO
153 parts123GPL-3.0
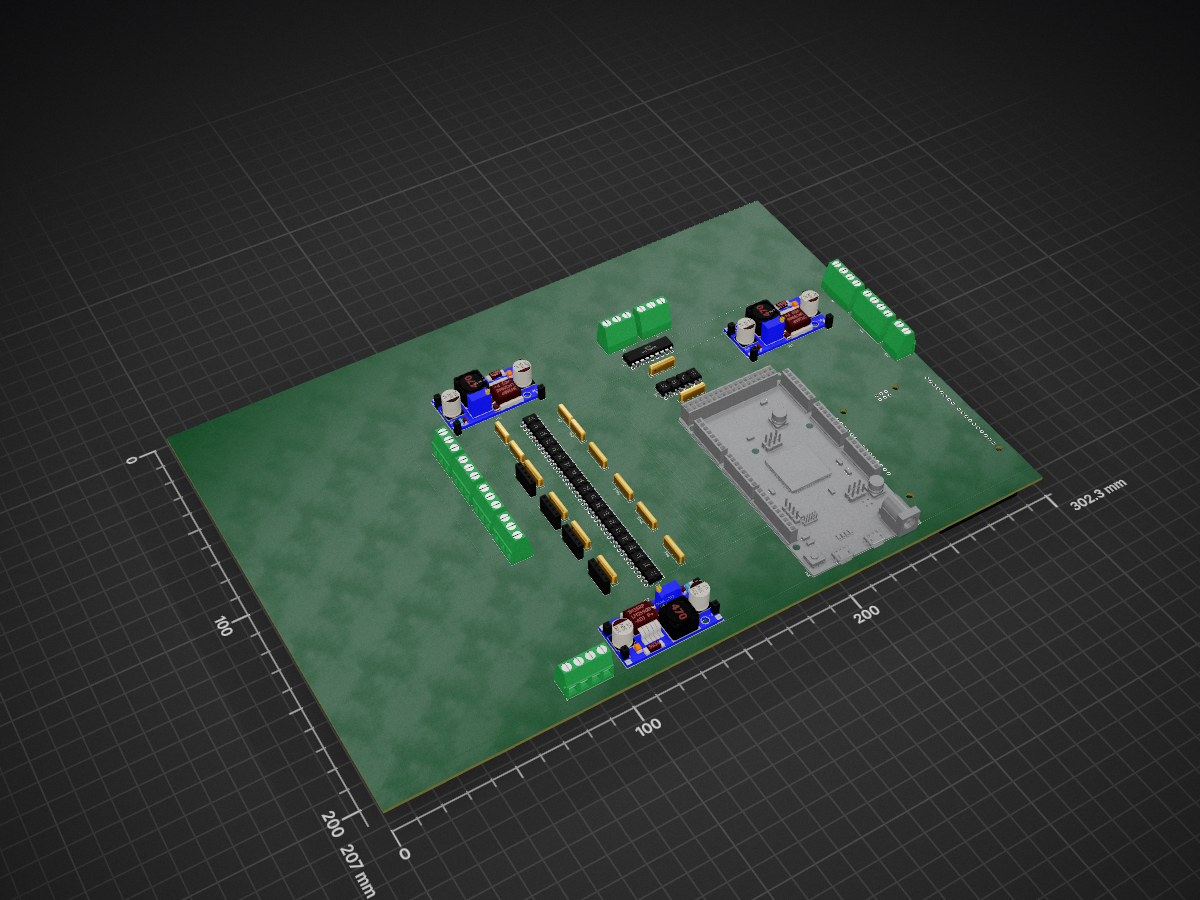
 sohamn22/Integrated-Robotics-Control-PCB
Developed a robot control system using Arduino Due and a USB Host Shield for real-time control of motors and actuators. Implemented embedded firmware, power regulation, and optocoupler isolation, and led PCB design, debugging, and system validation for reliable hardware performance.
Stage 1 proto is an open-source printed circuit board by sohamn22, from the sohamn22/Integrated-Robotics-Control-PCB repository on GitHub. It is a 2-layer board with 70 parts on 154 nets, routed with 257 tracks and 0 vias.
It is built around the ULN2803A. Its parts include 28 ICs and 14 connectors. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.
Developed a robot control system using Arduino Due and a USB Host Shield for real-time control of motors and actuators. Implemented embedded firmware, power regulation, and optocoupler isolation, and led PCB design, debugging, and system validation for reliable hardware performance.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 24 | PC817 | Package_DIP:DIP-4_W7.62mm | U1, U2, U3, U14, U15, U16, U17, U23, U24, U25, U26, U27, U28, U29, U30, U31 +8 |
| 12 | TestPoint | Connector_PinSocket_2.54mm:PinSocket_1x01_P2.54mm_Vertical | TP2, TP4, TP6, TP8, TP9, TP10, TP11, TP12, TP13, TP14, TP15, TP16 |
| 6 | Conn_01x03_Pin | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J2, J3, J6, J7, J8, J9 |
| 5 | 1k ohm | Resistor_THT:R_Array_SIP5 | RN2, RN4, RN12, RN14, RN16 |
| 5 | 220 ohm | Resistor_THT:R_Array_SIP5 | RN1, RN3, RN11, RN13, RN15 |
| 4 | Conn_01x05_Pin | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | J1, J12, J13, J14 |
| 3 | Conn_01x04_Pin | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-4_1x04_P5.00mm_Horizontal | J4, J5, J15 |
| 3 | YAAJ_DCDC_StepDown_LM2596 | LM2596 pretty:YAAJ_DCDC_StepDown_LM2596 | U11, U12, U13 |
| 2 | 1k ohm | Resistor_THT:R_Array_SIP4 | RN6, RN8 |
| 2 | 220 ohm | Resistor_THT:R_Array_SIP4 | RN5, RN7 |
| 1 | Arduino_Due_Shield | Arduino:Arduino_Due_Shield | XA1 |
| 1 | Arduino_Uno_HostShield | Arduino:Arduino_101_Shield | XA2 |
| 1 | Conn_01x02_Pin | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J10 |
| 1 | ULN2803A | Package_DIP:DIP-18_W7.62mm | U7 |
leomil72/LM80C
A Z80-based homebrew computer withTMS9918, AY-3-8910, Z80 CTC, Z80 PIO, and Z80 SIO

OverInvented/Flippy
The code needed to build a mechanical 7-segment display that uses electromagnets to display characters


crgarcia12/electronics-homeassistant-lightscontroll
A smart lighting controller PCB that integrates seamlessly with ESPHome and Home Assistant while maintaining full compatibility with traditional mechanical switches.


70 parts, built around the ULN2803A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the sohamn22/Integrated-Robotics-Control-PCB repository on GitHub, at the commit this page was made from: the board is stage_1_proto.kicad_pcb and its schematic stage_1_proto.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask sohamn22 before reusing the design.