2 layers
Encoder
byrantech/laptop
anyon_e, a highly integrated, high end, open source laptop. Attempt the impossible.
7 parts4.3kMIT
 sequenceplanner/unicorn_drivers
ROS and ROS2 packages for controller unicorn demo with HRP and SP. Also includes microcontroller code for controlling lights, actuators and distance sensors.
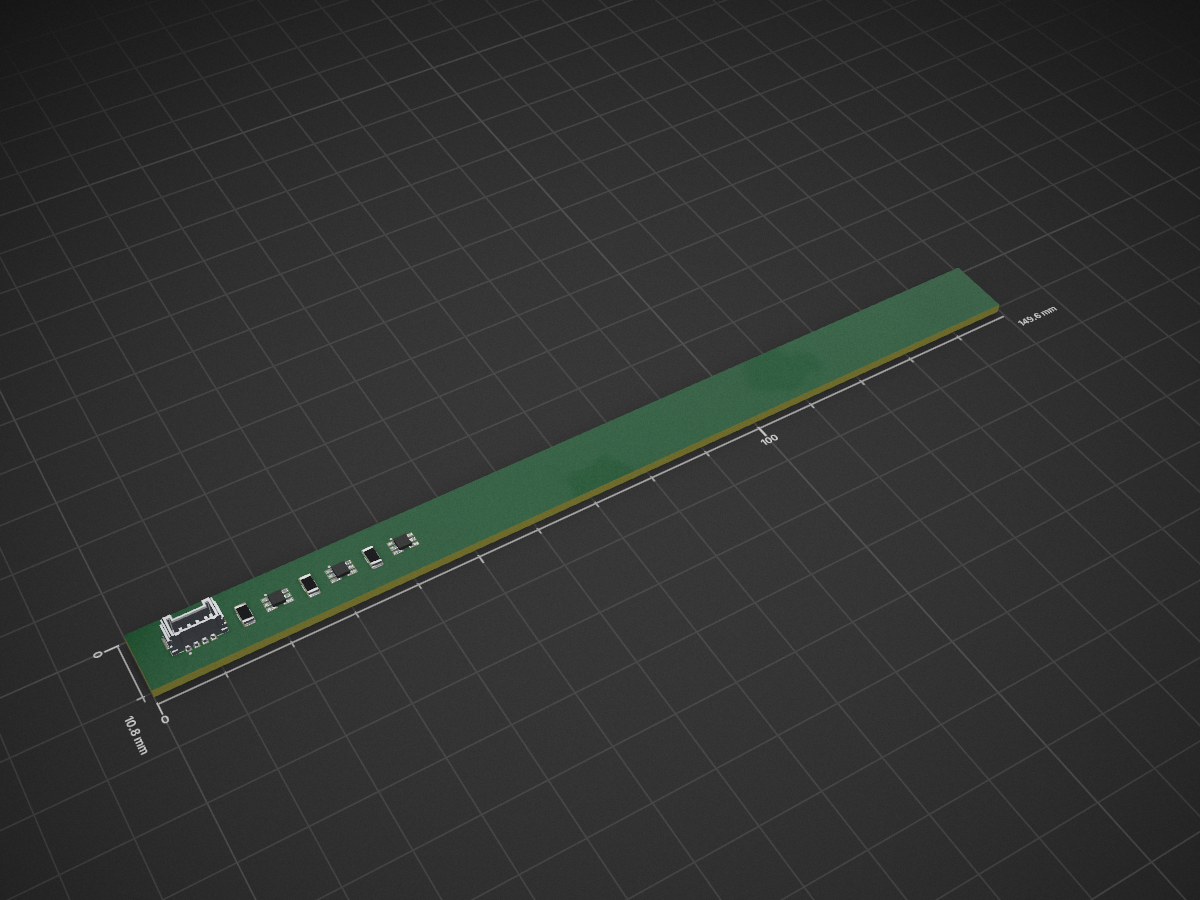
Rgb led pcb is an open-source printed circuit board by sequenceplanner, from the sequenceplanner/unicorn_drivers repository on GitHub. It is a 2-layer board of 149.6 × 10.8 mm with 7 parts on 13 nets.
Its parts include 3 resistors, 3 diodes and 1 connector. It belongs with the lEDs and displays boards of this library.
ROS and ROS2 packages for controller unicorn demo with HRP and SP. Also includes microcontroller code for controlling lights, actuators and distance sensors.
catkin_ws
colcon_ws
hw_controller:
ROS2 node that communicates via serial to the microcontroller that is responsible for interfacing with the garbage tipper, garbage sensors (detects if there is garbage placed on the platform), distance sensors for collision avoidance and LED light strips for status indication.
unicorn_hrp:
ROS2 node that controls the HRP hardware
hrp_msgs:
Custom ROS messages
hw-interface
The current system has been tested on either a Nvidia Jetson Nano or Jetson Xavier NX. The following dependencies need to be installed for the system to work properly:
Used to run a dynamic bridge that translates topics between the ROS2 and ROS. Can be installed by running:
sudo apt-get update
sudo apt install ros-eloquent-ros1-bridgeNeeded for serial communication with the microcontroller hardware.
GNU Screen
Used for the hrp_start.sh script that starts up the system Check out this Quick Reference on how to use Screen.
By default Ubuntu does not allow users access to system serial ports. To solve this we need to add the current user to the dialout group:
sudo usermod -a -G dialout $USERPreparing the HRP for startup
Run the startup shell script from the repository root folder
./hrp_startup.shThis will launch and automatically connect to a screen sessions with the following windows:
ros-bash
Regular terminal window with bash and ROS sourced
am_driver
Driver used to communicate with the HRP hardware
ros1_bridge
Bridge used to bidirectionally translate topics from ROS2 and ROS
teleop
Teleoperation and status of the HRP hardware
ros2_hw_controller
ROS2 node for interfacing with microcontroller
ros2_hrp_controller
ROS2 node for interfacing with am_driver
Troubleshooting:
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | ARGB1313HSTR | local:ARGB1313HSTR | D1, D2, D3 |
| 3 | R | Resistor_SMD:R_1206_3216Metric | R1, R2, R3 |
| 1 | Conn_01x04_MountingPin | local:Molex_Micro_Lock_1x4_Vertical_5055680471 | J1 |
It measures 149.6 × 10.8 mm and has 2 copper layers, 1.6 mm thick.
7 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the sequenceplanner/unicorn_drivers repository on GitHub, at the commit this page was made from: the board is hardware/rgb-led-pcb/rgb-led-pcb.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask sequenceplanner before reusing the design.
byrantech/laptop
anyon_e, a highly integrated, high end, open source laptop. Attempt the impossible.


AxxAxx/AxxSolder
STM32 Based soldering station for JBC cartridges, 9-24 VDC and USB-PD power


jamro/tiny-engineer
A small desktop robot that brings an AI coding assistant to life, physically acting out when it reads files, thinks, writes code, and finishes work.

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI
