Skip to the content
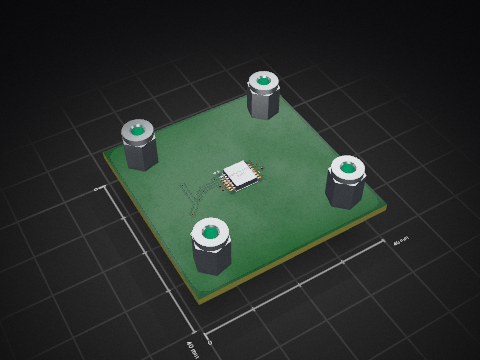
4 layers42 × 42 mmNema 17 stepper driver, the printed circuit board in 3D

Nema 17 stepper driver

Sarwan1494/Sarwan1494.github.io

Plain HTML / CSS / JS, no build step, no framework, no dependencies except KiCanvas (loaded from kicanvas.org via on the project pages) for the in-browser KiCad viewer.

Size
42 × 42 mm
Copper layers
4
Thickness
1.6 mm
Parts
75
Nets
76
Pads
286
Tracks, vias
667, 176
Pours
13
Routed
Yes
KiCad
KiCad 8.0 (file 20240108)
Created
7 Oct 2026
Updated
12 Oct 2026

Overview

Nema 17 stepper driver is an open-source printed circuit board by Sarwan1494, from the Sarwan1494/Sarwan1494.github.io repository on GitHub. It is a 4-layer board of 42 × 42 mm with 75 parts on 76 nets, routed with 667 tracks and 176 vias.

It is built around the STM32F103CBT6, TJA1051T/3/1 and AS5048A-HTSP, with the DRV8844PWPR, TPS54202DDC and AMS1117 among its other parts. Its parts include 27 capacitors, 11 resistors, 10 connectors, 8 ICs and 5 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.

Main components

9

README

README.md

Portfolio

Plain HTML / CSS / JS, no build step, no framework, no dependencies except KiCanvas (loaded from kicanvas.org via <script type="module"> on the project pages) for the in-browser KiCad viewer.

text
portfolio/
├── index.html                          # home page (about, project grid, contact)
├── projects/
│   ├── so101-robot-arm.html            # ROS 2 / MoveIt 2 project (webm video)
│   ├── mars-rover.html                 # Ackermann rover, Arduino + ROS 2 (webm video, inline SVG diagrams)
│   ├── vacuum-robot-simscape.html      # master's thesis, Simscape vacuum robot model (3 webm videos)
│   ├── nema17-stepper-driver.html      # project detail + KiCanvas embed
│   ├── cylinder-assembly.html          # CAD animation (webm video)
│   ├── delta-robot.html                # CAD animation (webm video)
│   ├── two-wheel-robot.html            # wiring schematic (png)
│   └── inverted-pendulum.html          # CAD animation (webm video)
├── assets/
│   ├── css/style.css
│   ├── js/main.js                      # theme toggle + viewer tab logic
│   ├── img/                            # renders / screenshots / video posters
│   ├── video/                          # project animations (.webm)
│   └── kicad/                          # .kicad_sch / .kicad_pcb / .kicad_pro served as static files
└── downloads/                          # schematic PDF, gerbers, interactive BOM, STEP model

Running locally

KiCanvas fetches the .kicad_sch / .kicad_pcb files over fetch(), which browsers block on file://. Serve the folder over HTTP instead:

bash
cd portfolio
python3 -m http.server 8000
# open http://localhost:8000

Adding a new project

  1. Duplicate projects/nema17-stepper-driver.html as a starting point.
  2. Drop images in assets/img/, KiCad source in assets/kicad/, downloadables in downloads/.
  3. Add a card to the .projects-grid in index.html.

Before publishing

  • Replace the LinkedIn / GitHub placeholder links in index.html (#contact).
  • downloads/nema17-3d-model.step is ~16 MB. Most static hosts (GitHub Pages, Netlify, Vercel) are fine with that per file, but if you're using git, consider Git LFS or dropping the STEP download if repo size matters.
  • Everything else is small and framework-free, so it deploys to any static host (GitHub Pages, Netlify, Vercel, S3, ...) with no build step.

Parts

75
QtyValueFootprintReferences
8100nFCapacitor_SMD:C_0402_1005MetricC1, C3, C7, C8, C14, C23, C25, C26
510uFCapacitor_SMD:C_0805_2012MetricC2, C4, C20, C24, C29
422uFCapacitor_SMD:C_0805_2012MetricC10, C11, C17, C18
4Conn_01x01_PinTestPoint:TestPoint_Keystone_5019_MinatureJ10, J11, J12, J13
4MountingHoleMountingHole:MountingHole_3.2mm_M3_ISO7380_PadH1, H2, H3, H4
30.1uFCapacitor_SMD:C_0402_1005MetricC5, C6, C9
20.01uFCapacitor_SMD:C_0402_1005MetricC27, C28
210pFCapacitor_SMD:C_0402_1005MetricC15, C16
21uFCapacitor_SMD:C_0402_1005MetricC13, C22
2200mResistor_SMD:R_1206_3216MetricR5, R7
2Conn_01x02_PinConnector_Molex:Molex_PicoBlade_53048-0210_1x02_P1.25mm_HorizontalJ6, J7
2INA181Package_TO_SOT_SMD:SOT-23-6U4, U8
1100kResistor_SMD:R_0603_1608MetricR11
110kResistor_SMD:R_0603_1608MetricR1
110nCapacitor_SMD:C_0402_1005MetricC12
1120Resistor_SMD:R_0603_1608MetricR2
1120RInductor_SMD:L_0603_1608MetricFB1
113.3kResistor_SMD:R_0603_1608MetricR12
115uHInductor_SMD:L_0603_1608MetricL1
116MHzCrystal:Crystal_SMD_3225-4Pin_3.2x2.5mmY1
11k5Resistor_SMD:R_0603_1608MetricR3
11k5Resistor_SMD:R_0402_1005MetricR4
149.9Resistor_SMD:R_0603_1608MetricR13
1510kResistor_SMD:R_0603_1608MetricR9
182kResistor_SMD:R_0603_1608MetricR10
1A+TestPoint:TestPoint_Pad_D1.0mmTP1
1A-TestPoint:TestPoint_Pad_D1.0mmTP2
1AMS1117Package_TO_SOT_SMD:SOT-223-3_TabPin2U3
1AS5048A-HTSPAS5048A-HTSP:SOP65P640X120-14NU6
1B+TestPoint:TestPoint_Pad_D1.0mmTP3
1B-TestPoint:TestPoint_Pad_D1.0mmTP4
1BootButton_Switch_SMD:SW_SPST_B3U-1100PBoot1
1Conn_01x02_PinJumper:SolderJumper-2_P1.3mm_Open_TrianglePad1.0x1.5mmJ3
1Conn_01x04_PinConnector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_VerticalJ4
1DRV8844PWPRDRV8844PWPR:IC_DRV8844PWPRU9
1ESD5ZxxDiode_SMD:D_SOD-523D2
1LEDLED_SMD:LED_0603_1608MetricD1
1PMEG6020AELRDiode_SMD:Nexperia_CFP3_SOD-123WD3
1PRTR5V0U2XPackage_TO_SOT_SMD:SOT-143D4
1Polyfuse_SmallMF-MSMF050-2:FUSM4632X85F2
1ResetButton_Switch_SMD:SW_SPST_B3U-1100PReset1
1SMBJ26ASMBJ26A:DIOM4336X265ND6
1STM32F103CBT6Package_QFP:LQFP-48_7x7mm_P0.5mmU1
1Stepper motorConnector_Molex:Molex_PicoBlade_53048-0410_1x04_P1.25mm_HorizontalJ5
1TJA1051T-3Package_SO:SOIC-8_3.9x4.9mm_P1.27mmU2
1TPS54202DDCPackage_TO_SOT_SMD:SOT-23-6U5
1USB_B_MicroConnector_USB:USB_Micro-B_Wuerth_629105150521J1

Similar boards

  • 2 layers40 × 40 mmEncoder Module PCB, the printed circuit board in 3D

    Encoder Module PCB

    arthur-wirjo/FOC_v1_project

    A custom-designed, 60V 50A Field Oriented Control (FOC) BLDC motor controller built from scratch. Designed for high-performance robotics, featuring a 4-layer power PCB, isolated USB telemetry, and CAN bus communication.

    8 partsMIT
  • 6 layers100 × 50 mmArchive, the printed circuit board in 3D

    Archive

    sikaxn/FRC-Custom-CAN-Sensor

    If you are looking for IronMaple ESP32‐FRC‐devkit resources, please switch branch to dev-board.

    92 parts12GPL-3.0
  • 2 layers42 × 42 mmNEMA17 FOC Driver, the printed circuit board in 3D

    NEMA17 FOC Driver

    maxmunzner/NEMA17_FOC_Driver

    A Stepper Driver project with a PCB that acts as the driver and encoder.

    37 parts1MIT
  • 2 layersTemalabor, the printed circuit board in 3D

    Temalabor

    domipapp/LIN-Driver-Linking

    27 parts
  • 4 layers56.6 × 39 mmMultimodal Actuator mk2, the printed circuit board in 3D

    Multimodal Actuator mk2

    TheUnknownAlias/betr_kicad_resources

    This repository contains shared KiCad symbols and footprints for our projects.

    91 parts
  • 4 layers95 × 24 mmBoardyMcBoardFace, the printed circuit board in 3D

    BoardyMcBoardFace

    akhilveeraghanta/the-bots-mainboard

    The main board for the the bots SSL robocup team

    115 parts1
  • 4 layers100.3 × 50.3 mmGreenmobi drive, the printed circuit board in 3D

    Greenmobi drive

    G-Pereira/greenmobi-drive

    A FOC motor drive compatible with VESC

    160 parts1CERN-OHL-S-2.0

Questions

How big is the Nema 17 stepper driver PCB?

It measures 42 × 42 mm and has 4 copper layers, 1.6 mm thick.

What parts does the Nema 17 stepper driver use?

75 parts, built around the STM32F103CBT6, TJA1051T/3/1, AS5048A-HTSP and DRV8844PWPR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Nema 17 stepper driver KiCad files?

From the Sarwan1494/Sarwan1494.github.io repository on GitHub, at the commit this page was made from: the board is assets/kicad/Nema_17_stepper_driver.kicad_pcb and its schematic assets/kicad/Nema_17_stepper_driver.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Nema 17 stepper driver design in my own project?

Its repository states no licence, so its author keeps all rights: ask Sarwan1494 before reusing the design.