| 9 | 0.22uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C5, C12, C13, C18, C19, C20, C21, C22, C26 |
| 8 | 0.1uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C29, C30, C31, C34, C35, C37, C39, C40 |
| 8 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R17, R19, R20, R22, R24, R26, R28, R30 |
| 8 | Fiducial | Fiducial:Fiducial_1mm_Mask2mm | FID1, FID2, FID3, FID4, FID5, FID6, FID7, FID8 |
| 7 | 4.7k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R6, R8, R14, R15, R16, R18, R32 |
| 6 | 470 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R4, R5, R7, R9, R11, R12 |
| 6 | LOGO | LOGO | G***, G***, G***, G***, G***, G*** |
| 5 | 4.7uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C8, C14, C15, C16, C27 |
| 4 | 10uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C1, C7, C11, C28 |
| 3 | 7 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R21, R25, R29 |
| 3 | 7.32k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R23, R27, R31 |
| 3 | DMG3406L | Package_TO_SOT_SMD:SOT-23 | Q1, Q2, Q3 |
| 3 | TestPoint_2Pole | TestPoint:TestPoint_2Pads_Pitch2.54mm_Drill0.8mm | TP1, TP2, TP3 |
| 2 | 10nF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C17, C25 |
| 2 | 10pF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C23, C24 |
| 2 | 120 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | FB1, FB2 |
| 2 | 18pF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C9, C10 |
| 2 | 1uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C3, C36 |
| 2 | 22pF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C32, C33 |
| 2 | 32.768kHz | Crystal:Crystal_SMD_2012-2Pin_2.0x1.2mm_HandSoldering | Y1, Y3 |
| 2 | 5.1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2 |
| 1 | | | |
| 1 | 100k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13 |
| 1 | 1725711 | footprint:1725711 | ScrewTerminal1 |
| 1 | 1M | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3 |
| 1 | 2.2M | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10 |
| 1 | 2.2uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C6 |
| 1 | 200G ACC LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D5 |
| 1 | 22uF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C2 |
| 1 | 3.3V LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1 |
| 1 | 3.3Vreg | footprint:TPS62111RSAR | TPS62111RSAR1 |
| 1 | 32.768kHz | footprint:830050789 | Y4 |
| 1 | 4.7uH | Inductor_SMD:L_0805_2012Metric_Pad1.05x1.20mm_HandSolder | L2 |
| 1 | 470uf | Capacitor_THT:C_Radial_D6.3mm_H11.0mm_P2.50mm | C41 |
| 1 | 6.8uH | Inductor_SMD:L_1008_2520Metric_Pad1.43x2.20mm_HandSolder | L1 |
| 1 | 6A | Fuse:Fuse_1206_3216Metric | F1 |
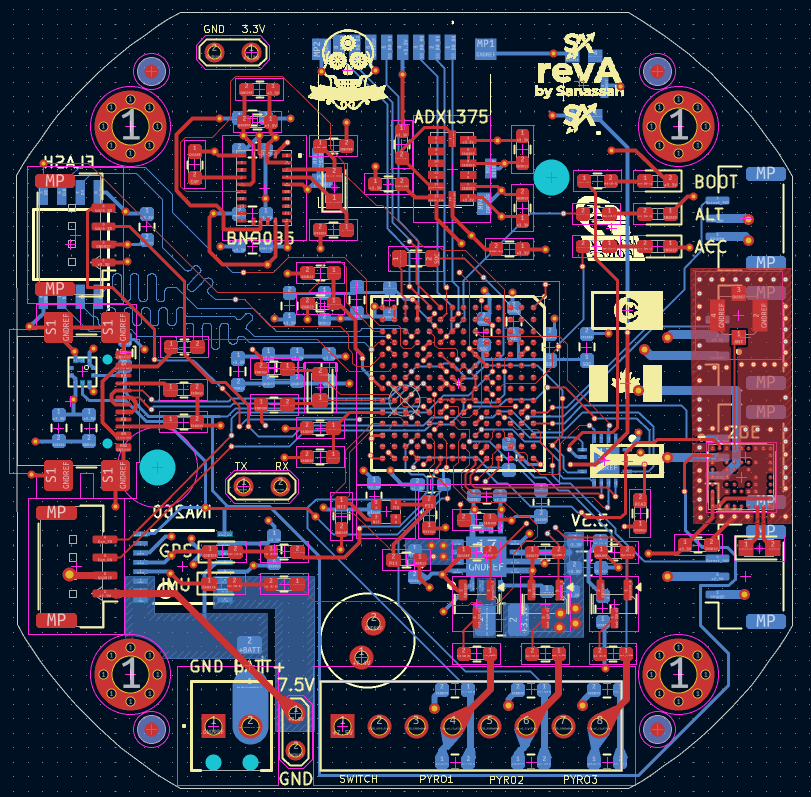
| 1 | ACC | footprint:ADXL375BCCZRL | ADXL1 |
| 1 | ALTIMETER | BMP390:BMP388 | BMP1 |
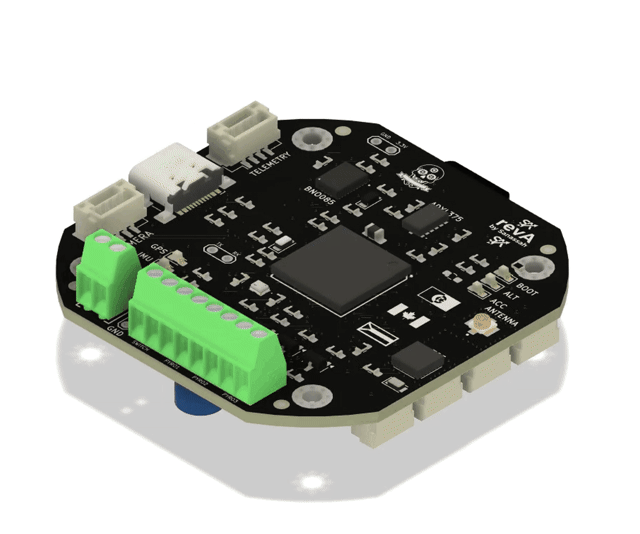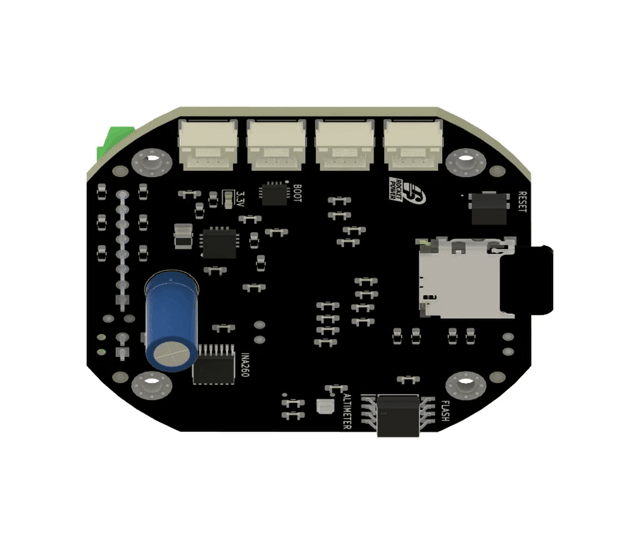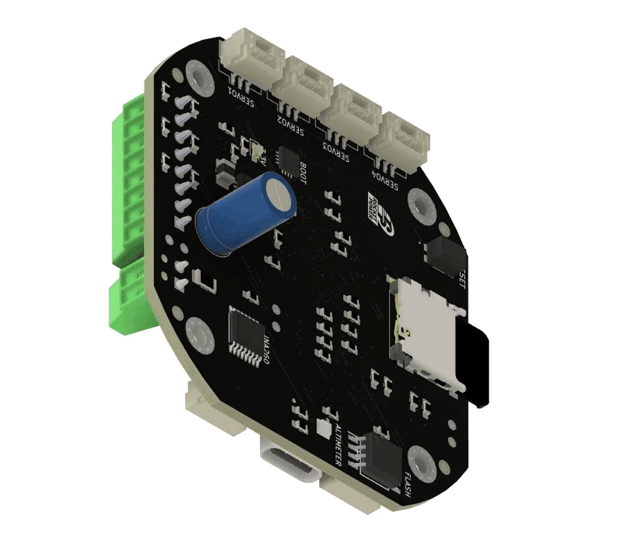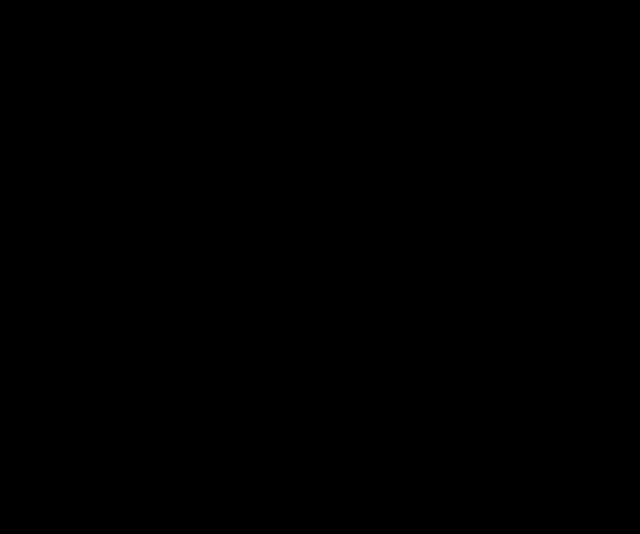
| 1 | ANTENNA | footprint:CONMHF1SMDGT | CONMHF1-SMD-G-T1 |
| 1 | Altimeter LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D4 |
| 1 | BATT | footprint:1725656 | ScrewTerminal2 |
| 1 | BOOT | footprint:QFN50P300X300X65-17N-D | MKL02Z32VFG1 |
| 1 | BOOT LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D2 |
| 1 | CAMERA | Connector_JST:JST_GH_BM04B-GHS-TBT_1x04-1MP_P1.25mm_Vertical | JST-GH-2 |
| 1 | GD25Q64ESIG | footprint:GD25Q64ESIG | FLASH1 |
| 1 | GPS | ZOE-M8Q:UBLOX_ZOE_M8-0-10 | U-BLOX_ZOE_M8Q-0-1 |
| 1 | GPS LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D3 |
| 1 | IMU | footprint:BNO085 | BNO1 |
| 1 | IMU LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D6 |
| 1 | INA260 | INA260:TSSOP16 | INA1 |
| 1 | MCU | footprint:BGA196C80P14X14_1200X1200X152 | MIMXRT1062DVL6B1 |
| 1 | MicroSD | DM3DSF:DM3DSF | DM3D-SF1 |
| 1 | RESET | footprint:KMR421GULCLFS | KMR241GLFS1 |
| 1 | SERVO1 | Connector_JST:JST_GH_BM03B-GHS-TBT_1x03-1MP_P1.25mm_Vertical | SERVO1 |
| 1 | SERVO2 | Connector_JST:JST_GH_BM03B-GHS-TBT_1x03-1MP_P1.25mm_Vertical | SERVO2 |
| 1 | SERVO3 | Connector_JST:JST_GH_BM03B-GHS-TBT_1x03-1MP_P1.25mm_Vertical | SERVO3 |
| 1 | SERVO4 | Connector_JST:JST_GH_BM03B-GHS-TBT_1x03-1MP_P1.25mm_Vertical | SERVO4 |
| 1 | TELEMETRY | Connector_JST:JST_GH_BM04B-GHS-TBT_1x04-1MP_P1.25mm_Vertical | JST-GH-1 |
| 1 | USBc | Connector_USB:USB_C_Receptacle_GCT_USB4110 | USB_C_Receptacle_USB2.0_14P1 |
| 1 | XRCGB24M000F2P29R0 | footprint:XRCGB | Y5 |