2 layers150 × 40 mm
 sailframes/core8
Open-source sailboat racing data logger and analytics platform.
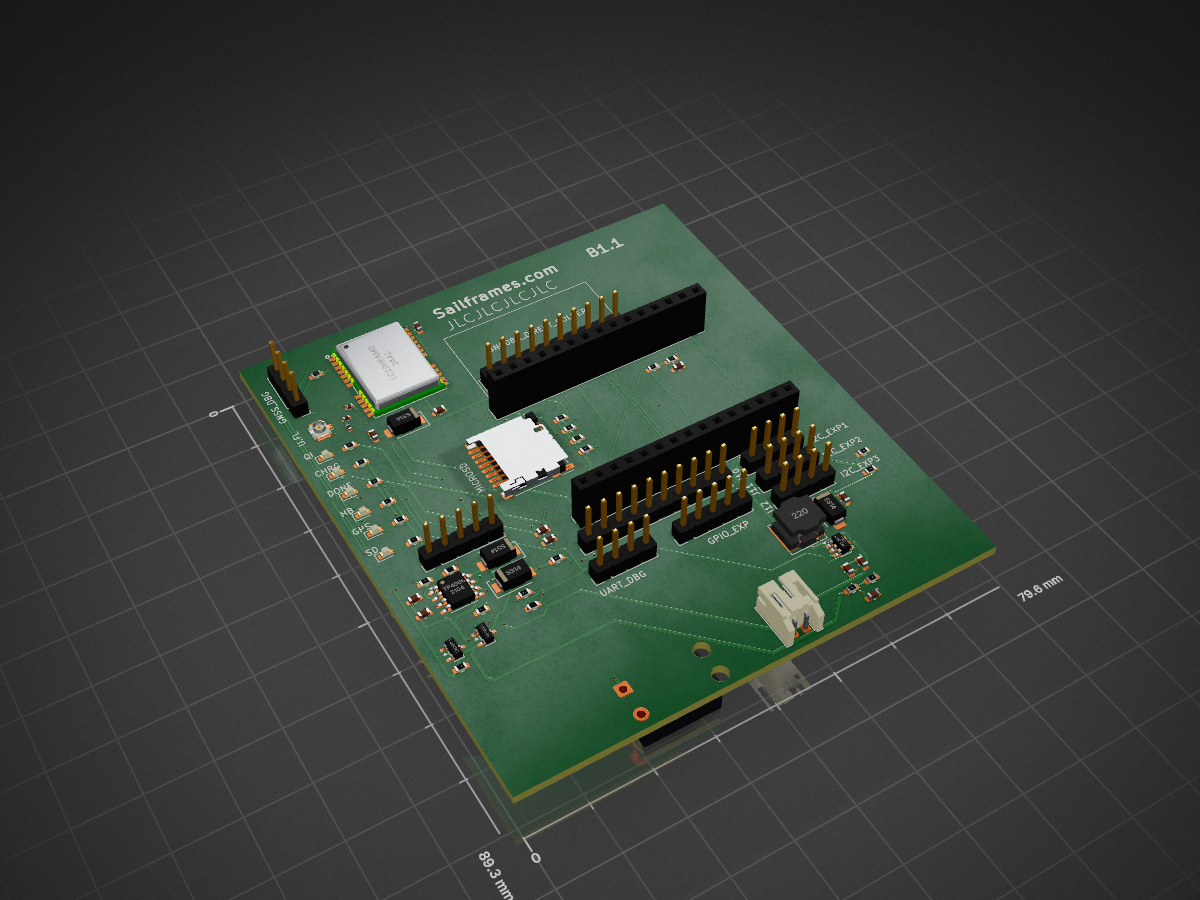
Kicad sailframes b1 is an open-source printed circuit board by sailframes, from the sailframes/core repository on GitHub. It is a 2-layer board of 79.8 × 89.3 mm with 72 parts on 76 nets, routed with 752 tracks and 107 vias.
It is built around the LC29HEAMD, MT3608 and TP4056, with the SS14 and AO3401A among its other parts. Its parts include 25 resistors, 15 capacitors, 14 connectors, 10 diodes and 3 ICs.


Open-source sailboat racing data logger and analytics platform.
sailframes.com | github.com/sailframes | Apache 2.0 License
SailFrames is a self-contained, waterproof data acquisition device for competitive sailboat racing. It captures high-precision GPS tracks, wind speed and direction, boat motion (heel/pitch/heading), barometric pressure, and cockpit video — all synchronized with GPS timestamps. Data syncs to AWS after each session for web-based race analysis and replay.
sailframes/core/
├── edge-s/            # Raspberry Pi edge device
│   ├── services/      # Sensor acquisition (GPS, IMU, wind, pressure, camera)
│   ├── scripts/       # Install, start, stop, Wi-Fi mode
│   ├── config/        # Device configuration
│   └── tests/         # Sensor connectivity tests
├── edge-e/            # ESP32 edge device
│   ├── hardware/      # KiCad PCB designs
│   └── firmware/      # ESP32 Arduino firmware
├── web/               # Dashboard web application
│   ├── api/           # Backend API
│   └── frontend/      # React frontend
├── lambda/            # AWS Lambda functions
├── processing/        # Post-race data processing
├── infrastructure/    # AWS CDK/Terraform
├── scripts/           # Utility scripts
├── services/          # Systemd service definitions
├── config/            # Shared configuration
└── tests/ # Integration tests| Component | Part | Interface |
|---|---|---|
| Compute | Raspberry Pi 5 | — |
| GPS | u-blox ZED-F9P | USB |
| Wind | Calypso Ultrasonic Mini | BLE 5.1 |
| IMU | BNO085 (GY-BNO08X) | I2C @ 0x4A |
| Pressure | DPS310 | I2C @ 0x77 |
| Camera | Pi Camera 3 Wide | CSI |
| Display | 1602 LCD + PCF8574T | I2C @ 0x27 |
| Enclosure | IP67 sealed | Gore-Tex vent |
# Clone the repo
git clone https://github.com/sailframes/core.git
cd core

# Run the installer on Raspberry Pi
sudo bash edge-s/scripts/install.sh

# Test all sensors
python3 edge-s/tests/test_gps.py
python3 edge-s/tests/test_imu.py
python3 edge-s/tests/test_pressure.py
python3 edge-s/tests/test_wind.py
python3 edge-s/tests/test_camera.py

# Start all services
sudo bash edge-s/scripts/start.sh

# Check status
sudo systemctl status sailframes-*All sensor data is timestamped with GPS time (UTC):
/mnt/sailframes-data/
├── 2026-03-15/
│   ├── gps/
│   │   └── track_20260315_140000.csv
│   ├── imu/
│   │   └── imu_20260315_140000.csv
│   ├── pressure/
│   │   └── pressure_20260315_140000.csv
│   ├── wind/
│   │   └── wind_20260315_140000.csv
│   └── video/
│ └── cockpit_20260315_140000.mp4Apache 2.0
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 10k | Resistor_SMD:R_0603_1608Metric | R7, R14, R16, R23, R24, R25, R26 |
| 6 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C3, C5, C13, C16, C17 |
| 5 | 100k | Resistor_SMD:R_0603_1608Metric | R1, R2, R10, R15, R30 |
| 5 | 10uF | Capacitor_SMD:C_0603_1608Metric | C2, C4, C7, C12, C15 |
| 5 | 1k | Resistor_SMD:R_0603_1608Metric | R8, R9, R17, R18, R19 |
| 4 | SS14 | Diode_SMD:D_SMA | D7, D8, D9, D10 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric | R21, R22 |
| 2 | BLUE | LED_SMD:LED_0603_1608Metric | D1, D6 |
| 2 | Conn_01x15 | Connector_PinSocket_2.54mm:PinSocket_1x15_P2.54mm_Vertical | J1, J4 |
| 1 | 0 | Resistor_SMD:R_0603_1608Metric | R28 |
| 1 | 100pF | Capacitor_SMD:C_0402_1005Metric | C11 |
| 1 | 10nF | Capacitor_SMD:C_0402_1005Metric | C10 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric | C14 |
| 1 | 13.7k | Resistor_SMD:R_0603_1608Metric | R11 |
| 1 | 22uF | Capacitor_SMD:C_0603_1608Metric | C8 |
| 1 | 22uH | Inductor_SMD:L_Bourns_SRN6045TA | L1 |
| 1 | 2N3904 | Package_TO_SOT_SMD:SOT-23 | Q_INV1 |
| 1 | 2k | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | 33nH | Inductor_SMD:L_0402_1005Metric | L2 |
| 1 | 470 | Resistor_SMD:R_0603_1608Metric | R20 |
| 1 | 47k | Resistor_SMD:R_0603_1608Metric | R31 |
| 1 | 68k | Resistor_SMD:R_0603_1608Metric | R32 |
| 1 | AO3401A | Package_TO_SOT_SMD:SOT-23 | Q_PWR1 |
| 1 | BNO085_DIRECT_SOLDER | Connector_PinHeader_2.54mm:PinHeader_1x10_P2.54mm_Vertical | J8 |
| 1 | GNSS_DBG | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J16 |
| 1 | GPIO_EXP | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J13 |
| 1 | GREEN | LED_SMD:LED_0603_1608Metric | D3 |
| 1 | HOSYOND_3.5_TFT | Connector_PinHeader_2.54mm:PinHeader_1x10_P2.54mm_Vertical | J9 |
| 1 | I2C_EXP1 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J10 |
| 1 | I2C_EXP2 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J11 |
| 1 | I2C_EXP3 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J12 |
| 1 | JST_PH_BAT | Connector_JST:JST_PH_S2B-PH-K_1x02_P2.00mm_Horizontal | J2 |
| 1 | LATCH_DBG | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J17 |
| 1 | LC29HEAMD | B1_JLC:GPSM-SMD_24P-L16.0-W12.2-P1.10-TL | U1 |
| 1 | MICROSD | Connector_Card:microSD_HC_Hirose_DM3D-SF | J5 |
| 1 | MT3608 | Package_TO_SOT_SMD:SOT-23-6 | U3 |
| 1 | QI_PADS | Connector_Wire:SolderWire-0.5sqmm_1x02_P4.6mm_D0.9mm_OD2.1mm_Relief | J_QI1 |
| 1 | RED | LED_SMD:LED_0603_1608Metric | D4 |
| 1 | TP4056 | Package_SO:SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm_ThermalVias | U2 |
| 1 | U.FL | Connector_Coaxial:U.FL_Hirose_U.FL-R-SMT-1_Vertical | J3 |
| 1 | UART_DBG | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J14 |
| 1 | WHITE | LED_SMD:LED_0603_1608Metric | D5 |
| 1 | YELLOW | LED_SMD:LED_0603_1608Metric | D2 |
It measures 79.8 × 89.3 mm and has 2 copper layers, 1.6 mm thick.
72 parts, built around the LC29HEAMD, MT3608, TP4056 and SS14. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the sailframes/core repository on GitHub, at the commit this page was made from: the board is edge-b/hardware/kicad_sailframes-b1.kicad_pcb and its schematic edge-b/hardware/kicad_sailframes-b1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask sailframes before reusing the design.

MateoHadzimustafic/VCO
Voltage Controlled Oscillator (Square and Triangle Generator)


chithigun23/ANUFS-Telemetry
To use custom hardware to measure parameters and dynamics of an ICE Formula SAE car.

rtymk/RT_Open_GPS_Board
Open source RTK GPS board for agricultural applications. LC29HEA GNSS reciever, E22 -900m33s LoRa Radio, 1x RS232 Out, 1x RS232 In, 2x CAN Trasncievers


Ruthvik-reddy-A/PCB-design-projects
Welcome to my curated collection of hardware design projects focused on practical, compact, and beginner-to-intermediate level printed circuit board (PCB) designs.

yvolodym/18650-3v3-supply
KiCad: stabile 3,3-V-Versorgung aus 18650-Li-Ion-Akku – TP4056-Ladung, DW01A/FS8205A-Schutz, MT3608-Boost, AP2112K-LDO