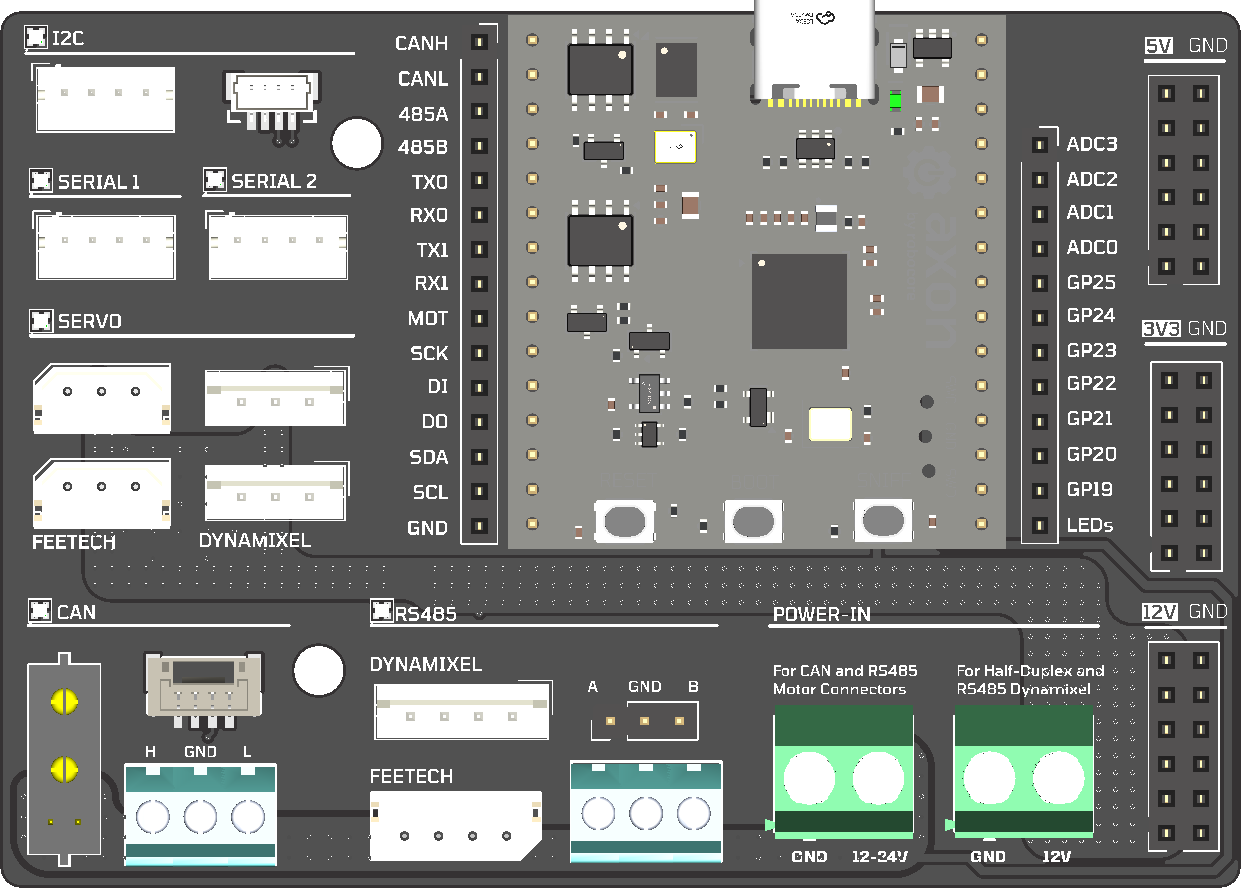
Link101 carrier
robocore-labs/link101-hardware
link101 is a multi-protocol USB interface board. One Type-C cable gives you CAN-FD, RS485, Dynamixel, Feetech, UART, I2C, and MIT Cheetah-protocol ports, all as stable Linux devices.

link101 is a multi-protocol USB interface board. One Type-C cable gives you CAN-FD, RS485, Dynamixel, Feetech, UART, I2C, and MIT Cheetah-protocol ports, all as stable Linux devices.
Link101 is an open-source printed circuit board by robocore-labs, from the robocore-labs/link101-hardware repository on GitHub, published under the CERN-OHL-S-2.0 licence. It is a 2-layer board of 39.2 × 36.6 mm with 71 parts on 85 nets, routed with 844 tracks and 128 vias.
It is built around the RP2354A, SN65HVD230D and SN74LVC1G125DCKR-GK, with the SN74LVC1G126DBVR-TP, AP2112K-3.3 and SP3485EN-Y among its other parts. Its parts include 25 capacitors, 20 resistors, 7 ICs, 6 diodes and 3 connectors. It belongs with the interfaces and adapters boards and the RP2350 boards of this library.

link101 is a multi-protocol USB interface board. One Type-C cable gives you CAN-FD, RS485, Dynamixel, Feetech, UART, I2C, and MIT Cheetah-protocol ports, all as stable Linux devices.
The LINK101 system consists of two boards:
The brains of the system. A Raspberry Pi RP2354A (dual Cortex-M33 at 150 MHz, 520 KB SRAM, 2 MB flash) with onboard peripherals:
| Feature | Detail |
|---|---|
| USB | USB Type-C composite device (CDC serial, SocketCAN, debug) |
| CAN | MCP2518FD CAN-FD controller + SN65HVD230 transceiver |
| RS485 | SP3485EN half-duplex transceiver with DE control |
| GPIO | 7× GPIO, 4× ADC exposed via pin headers |
| I2C | Hardware I2C bus (SCL/SDA) |
| SPI | Hardware SPI (MOSI/MISO/SCK) |
| UART | 2× full-duplex UART (UART0, UART1) |
| NeoPixel | WS2812B-compatible output |
| Power | VBUS input, onboard 3.3V LDO (AP2112K-3.3), 1.1V core supply |
| Protection | ESD protection on CAN (PESD1CAN), USB (USBLC6-2SC6), and RS485 (PRTR5V0U2X) |
| Debug | SWD header, USB boot select |
Files: link101.kicad_pro (project), link101.kicad_sch (schematic), link101.kicad_pcb (layout), link101_Module.kicad_sym (symbol), link101_Module.kicad_mod (footprint)
Breaks out every signal from the module into real-world connectors, adds sensors, neopixel status LEDs, and power regulation:
| Section | Details |
|---|---|
| Power | XT30 input → LMR16006 5V buck regulator → SS54 reverse protection → servo power rail |
| CAN-FD | Screw terminals, MCP2518FD via module SPI |
| RS485 | Screw terminals, hardware UART with DE pin |
| UART0 | 5V-level full-duplex serial (XH2.54 connector) |
| UART1 | 3.3V-level full-duplex serial (2.54mm pin header) |
| Half-Duplex UART | Feetech SCS/STS, Dynamixel Protocol 1.0/2.0, FashionStar bus servos (XH2.54 + Dynamixel connectors) |
| I2C | Qwiic/STEMMA QT connector (JST-GH 4-pin) |
| SPI | 2.54mm pin header |
| MIT Cheetah | XT30(2+2) connector for Damiao, CubeMars, Unitree, MyActuator |
| ODrive | JST-GH 4-pin connector |
| IMU | Onboard LSM6DSOX 6-axis IMU + MMC5983MA magnetometer via SPI |
| NeoPixels | WS2812B ×4 — one per bus (CAN, RS485, serial, servo) |
| GPIO/ADC | 7× GPIO + 4× ADC breakout pin headers |
Files: link101_carrier.kicad_pro (project), link101_carrier.kicad_sch (schematic), link101_carrier.kicad_pcb (layout)
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | 100n | Capacitor_SMD:C_0402_1005Metric | C2, C6, C9, C11, C12, C13, C14, C15, C16, C17, C18, C19, C21, C22, C24 |
| 4 | 1k | Resistor_SMD:R_0402_1005Metric | R14, R15, R17, R29 |
| 4 | 4.7u | Capacitor_SMD:C_0402_1005Metric | C7, C8, C10, C23 |
| 3 | 10k | Resistor_SMD:R_0402_1005Metric | R6, R7, R8 |
| 3 | SMD_4.2x3.2mm_h2.5mm | PCM_SparkFun-Switch:Push_SMD_4.2x3.2mm | SW1, SW2, SW4 |
| 2 | 10kΩ | PCM_JLCPCB:R_0402 | R12, R30 |
| 2 | 10u | Capacitor_SMD:C_0805_2012Metric | C20, C25 |
| 2 | 120Ω | PCM_JLCPCB:R_0402 | R25, R26 |
| 2 | 15p | Capacitor_SMD:C_0402_1005Metric | C4, C5 |
| 2 | 22pF | PCM_JLCPCB:C_0402 | C1, C26 |
| 2 | 27 | Resistor_SMD:R_0402_1005Metric | R18, R19 |
| 2 | 5.1k | PCM_SparkFun-Resistor:R_0402_1005Metric | R27, R28 |
| 2 | 560Ω | PCM_JLCPCB:R_0402 | R9, R10 |
| 2 | Conn_01x15_Socket | Connector_PinHeader_2.54mm:PinHeader_1x15_P2.54mm_Vertical | J3, J7 |
| 2 | SolderJumper_2_Bridged | Jumper:SolderJumper-2_P1.3mm_Bridged_Pad1.0x1.5mm | JP1, JP2 |
| 1 | 20k | Resistor_SMD:R_0402_1005Metric | R5 |
| 1 | 3.3uH | PCM_SparkFun-Coil:0806_Polarized | L1 |
| 1 | 33 | Resistor_SMD:R_0402_1005Metric | R16 |
| 1 | 330Ω | PCM_JLCPCB:R_0402 | R1 |
| 1 | 40MHz, 15pF | PCM_JLCPCB:OSC-SMD_4P-L3.2-W2.5-BL_SIT8008BI | X1 |
| 1 | ABM8-272-T3 | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | AP2112K-3.3 | PCM_SparkFun-Semiconductor-Standard:SOT23-5 | U10 |
| 1 | Conn_01x03 | PCM_SparkFun-Connector:1x03_P2.54mm_Locking | J12 |
| 1 | Green | PCM_SparkFun-LED:LED_0603_1608Metric_Green | D1 |
| 1 | MCP2518FD-xQBB | Package_DFN_QFN:DFN-14-1EP_3x4.5mm_P0.65mm_EP1.65x4.25mm | U1 |
| 1 | PESD1CAN,215 | easyeda2kicad:SOT-23_L2.9-W1.3-P1.90-LS2.4-BR | D9 |
| 1 | PESD5V0S2BT,215 | easyeda2kicad:SOT-23_L2.9-W1.3-P1.90-LS2.4-BR | D10 |
| 1 | PRTR5V0U2X | Package_TO_SOT_SMD:SOT-143 | D11 |
| 1 | RP2354A | Package_DFN_QFN:QFN-60-1EP_7x7mm_P0.4mm_EP3.4x3.4mm | U8 |
| 1 | SN65HVD230 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U7 |
| 1 | SN74LVC1G125DCKR | easyeda2kicad:SOT-353_L2.2-W1.4-P0.65-LS2.4-BR | U15 |
| 1 | SN74LVC1G126DBVR | easyeda2kicad:SOT-23-5_L3.0-W1.7-P0.95-LS2.8-BR | U4 |
| 1 | SP3485EN | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U9 |
| 1 | SS14HE | easyeda2kicad:SOD-323HE_L1.9-W1.3-LS2.5-RD | D4 |
| 1 | SS8550 | Package_TO_SOT_SMD:SOT-23 | Q2 |
| 1 | USB-TYPE-C-018 | easyeda2kicad:USB-C_SMD-TYPE-C-31-M-12 | USB1 |
| 1 | USBLC6-2SC6 | easyeda2kicad:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | D8 |

robocore-labs/link101-hardware
link101 is a multi-protocol USB interface board. One Type-C cable gives you CAN-FD, RS485, Dynamixel, Feetech, UART, I2C, and MIT Cheetah-protocol ports, all as stable Linux devices.


okbrainhq/sMove
Applied to power.kicadsch, compute.kicadsch and smove-r2-main.kicadsch:

aminewe898/nexus-pear-reva
NEXUS PEAR Rev A hardware design, schematics, PCB, manufacturing review exports and engineering documentation

V2gkr/industrial_hat_rpi4
hat to communicate via rs232, rs485, can fd with galvanic isolation

ArielRobotti/MagneticFieldDetector
Detector de polaridad de campo magnético para Mago :)

sergeyvfx/GPSDOMonitor
A tiny module which is connecting to a databus of GPSDO modules with the goal to visualize when the PLL is locked, GPS time is stabilized and things like this.

It measures 39.2 × 36.6 mm and has 2 copper layers, 1.6 mm thick.
71 parts, built around the RP2354A, SN65HVD230D, SN74LVC1G125DCKR-GK and SN74LVC1G126DBVR-TP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the robocore-labs/link101-hardware repository on GitHub, at the commit this page was made from: the board is link101/link101.kicad_pcb and its schematic link101/._Bolt.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-S-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).