2 layers

 QUT-EESS/OmniBot
EESS Modular Robotics Platform
SystemController is an open-source printed circuit board by QUT-EESS, from the QUT-EESS/OmniBot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board with 61 parts on 80 nets.
It is built around the STM32F103CBT6, LM317 and SI2343CDS. Its parts include 20 resistors, 15 capacitors, 9 diodes, 6 connectors and 2 ICs. It belongs with the robots and motor control boards and the STM32 boards of this library.


EESS Modular Robotics Platform
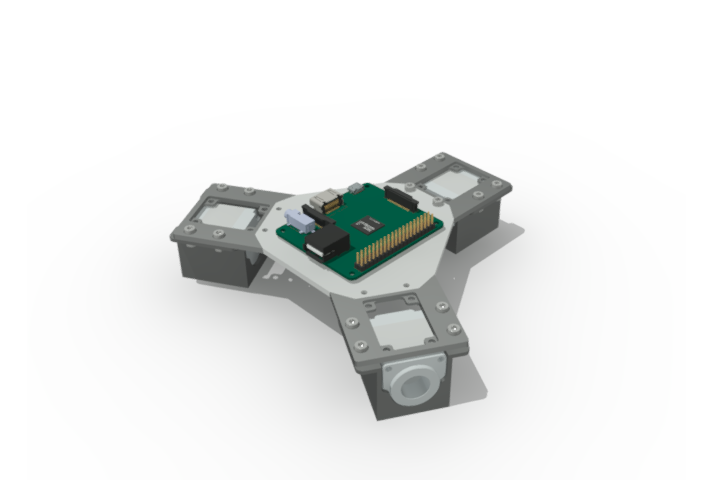
An open source modular robotics platform designed with KiCAD and FreeCAD. Custom designed Chassis designed to be laser cut/3d printed/CnC Milled. Custom fit stepper motor mounts with embedded motor controller PCB.
Main Processor unit consists of a Raspberry Pi A+ for path planning and general computation. An STM32 ARM microcontroller system controller will handle the stepper motor control via communication with the RPi A+ board and motor controllers.
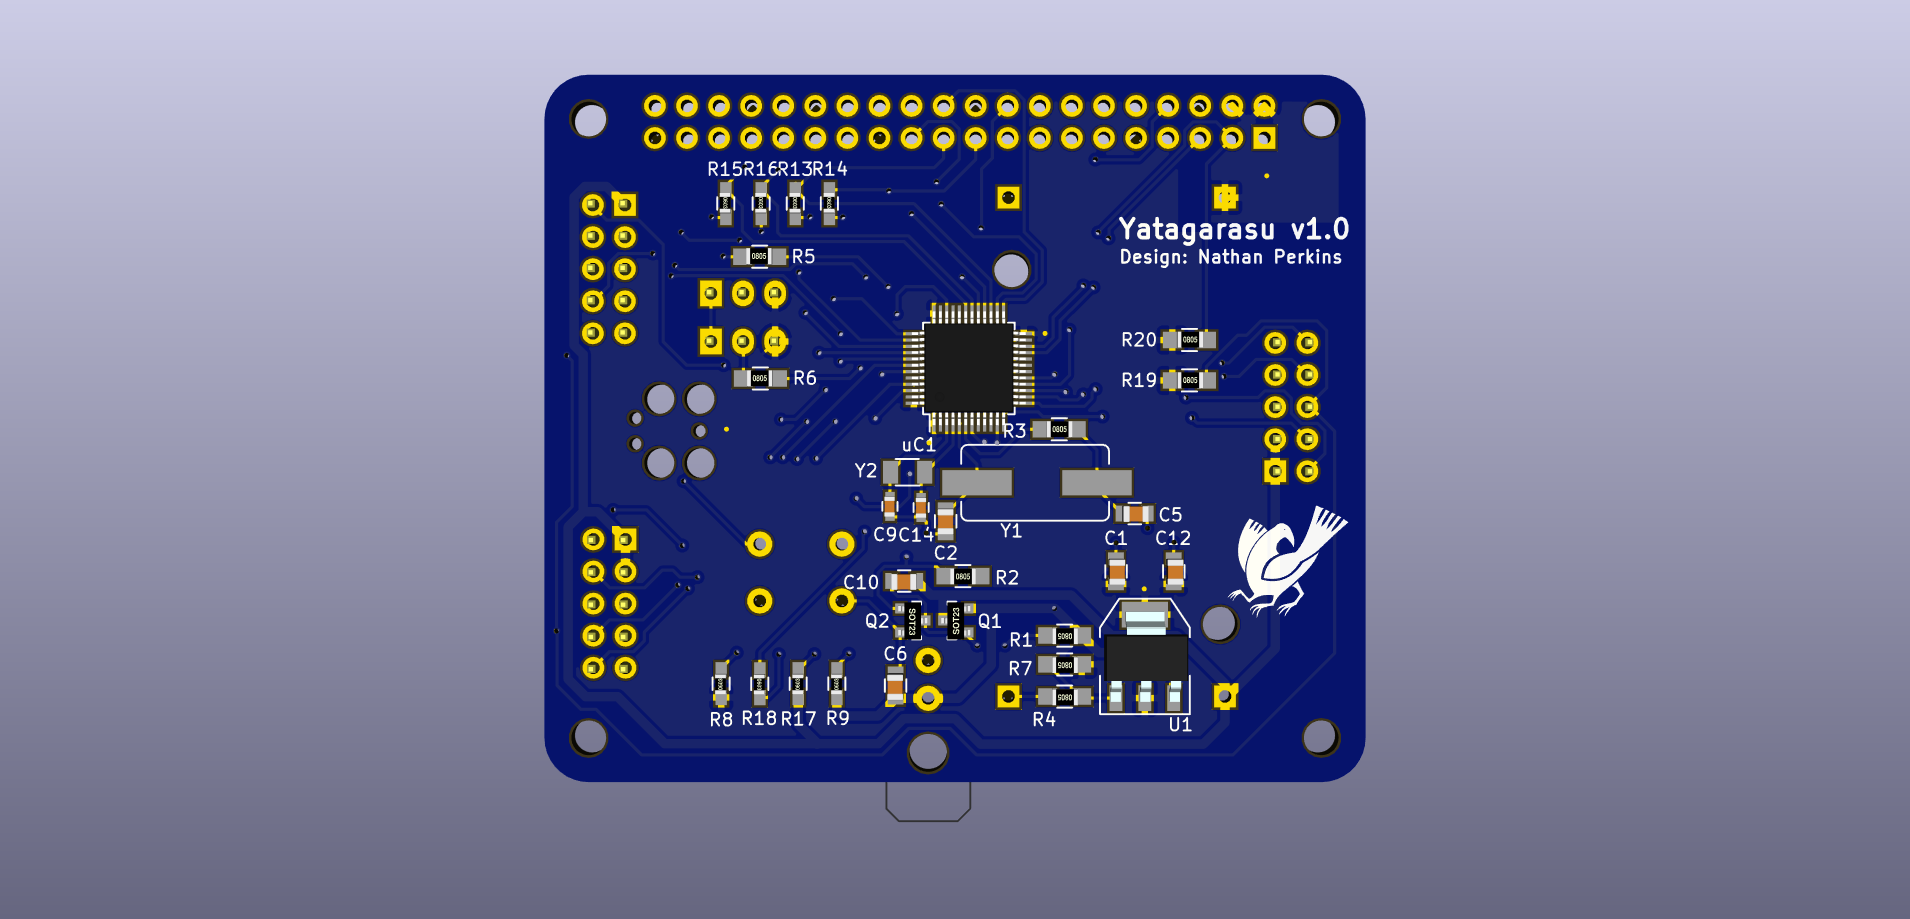
1: System Controller
Requirements: The Electronics design require the following footprint libraries for KiCAD
https://github.com/NathanielPerkins/NPFootprints.pretty
2: Mechanical
Chassis design for overall OmniBot frame, and motor mount system
3: Motor Controller
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | LED | LEDs:LED_0805 | D1, D2, D3, D4, D5, D6, D7, D8, D9 |
| 6 | 100nF | Capacitors_SMD:C_0805 | C1, C3, C4, C7, C11, C15 |
| 6 | 68 | Resistors_SMD:R_0603_HandSoldering | R8, R13, R14, R15, R16, R18 |
| 4 | 10K | Resistors_SMD:R_0805_HandSoldering | R1, R2, R5, R6 |
| 3 | 1uF | Capacitors_SMD:C_0805 | C6, C12, C13 |
| 3 | Harwin-10P | Pin_Headers:Pin_Header_Straight_2x05 | P4, P5, P6 |
| 2 | 22pF | Capacitors_SMD:C_0805 | C2, C5 |
| 2 | 4.7pF | Capacitors_SMD:C_0603 | C9, C14 |
| 2 | 560 | Resistors_SMD:R_0603_HandSoldering | R9, R17 |
| 2 | R | Resistors_SMD:R_0603_HandSoldering | R10, R11 |
| 2 | R_I2C | Resistors_SMD:R_0805_HandSoldering | R19, R20 |
| 1 | 10uF | Capacitors_SMD:C_0805 | C8 |
| 1 | 150 | Resistors_SMD:R_0603_HandSoldering | R12 |
| 1 | 1nF | Capacitors_SMD:C_0805 | C10 |
| 1 | 240 | Resistors_SMD:R_0805_HandSoldering | R7 |
| 1 | 2N7002 | TO_SOT_Packages_SMD:SOT-23 | Q1 |
| 1 | 32kHz | NPFootprints:QTC3_Series_Crystal | Y2 |
| 1 | 390 | Resistors_SMD:R_0805_HandSoldering | R4 |
| 1 | 8MHz | NPFootprints:HC49SDLF_Crystal_Series | Y1 |
| 1 | 910 | Resistors_SMD:R_0805_HandSoldering | R3 |
| 1 | BOOT0 | Pin_Headers:Pin_Header_Straight_1x03 | JP1 |
| 1 | BOOT1 | Pin_Headers:Pin_Header_Straight_1x03 | JP2 |
| 1 | Battery Input | NPFootprints:Molex_MicroFit_3.0_RightAngle | P1 |
| 1 | LM317 | TO_SOT_Packages_SMD:SOT-223 | U1 |
| 1 | Raspberry Pi A+ Connectors | NPFootprints:Raspberry_Pi_A+ | P3 |
| 1 | STM32F103CBT6 | Housings_QFP:LQFP-48_7x7mm_Pitch0.5mm | uC1 |
| 1 | SWD | NPFootprints:Tag-Connect_6P_Leads | P2 |
| 1 | SW_PUSH | NPFootprints:B3F-1025_Tactile_Switch | SW1 |
| 1 | Seeedstudio_Buck_5v | NPFootprints:Seeedstudio_5V_Buck | U2 |
| 1 | Si2343CDS | TO_SOT_Packages_SMD:SOT-23 | Q2 |
| 1 | — | NPFootprints:Yatagarsu_Logo | G*** |
61 parts, built around the STM32F103CBT6, LM317 and SI2343CDS. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the QUT-EESS/OmniBot repository on GitHub, at the commit this page was made from: the board is Electronics/System Controller/SystemController.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


PhilipMcGaw/robot-NautiPi
NautiPi is the physical hardware and embedded-project repository for the robot projects. It contains electronics, PCB and KiCad work, Arduino projects, component records, mechanical references, photographs, and retained…

pengshulin/mcush
MCUSH application platform (personal toolkit: firmware platform, debugger, hardware, test and application framework)

john0312/hitcon-pcb-badge
execute fw/merge.py to merge STM32CubeIDE generated main.c with user code in main.cc into main.cc.

laneboysrc/rc-headless-transmitter
DIY 2.4 GHz RC transmitter without display, configurable through smartphone or web browser


hkustenterprize/RM2025-Wireless-JLink
Wireless JLink-OB based on Allwinner V3S


electroniceel/stm32....c-breakout
A breakout module for STM32 microcontrollers in LQFP48 and UFQFPN48 footprint.