2 layers

 QUT-EESS/OmniBot
EESS Modular Robotics Platform
BuckConv is an open-source printed circuit board by QUT-EESS, from the QUT-EESS/OmniBot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board with 16 parts on 7 nets, routed with 43 tracks and 0 vias.
Its parts include 7 capacitors, 4 resistors, 2 connectors, 1 IC and 1 diode. It belongs with the robots and motor control boards of this library.
EESS Modular Robotics Platform
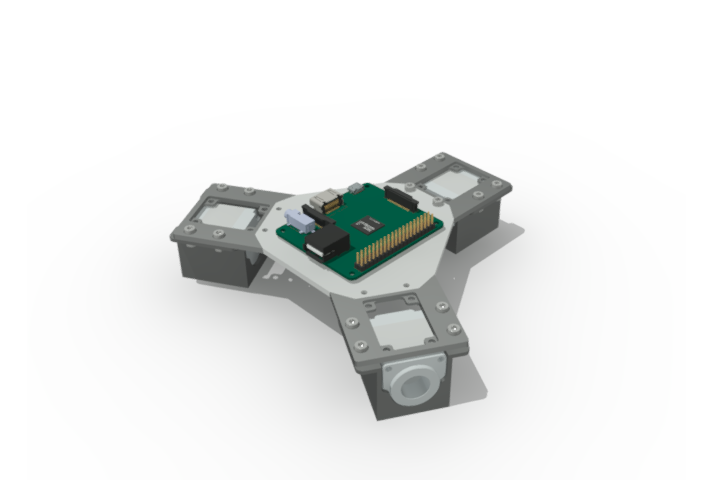
An open source modular robotics platform designed with KiCAD and FreeCAD. Custom designed Chassis designed to be laser cut/3d printed/CnC Milled. Custom fit stepper motor mounts with embedded motor controller PCB.
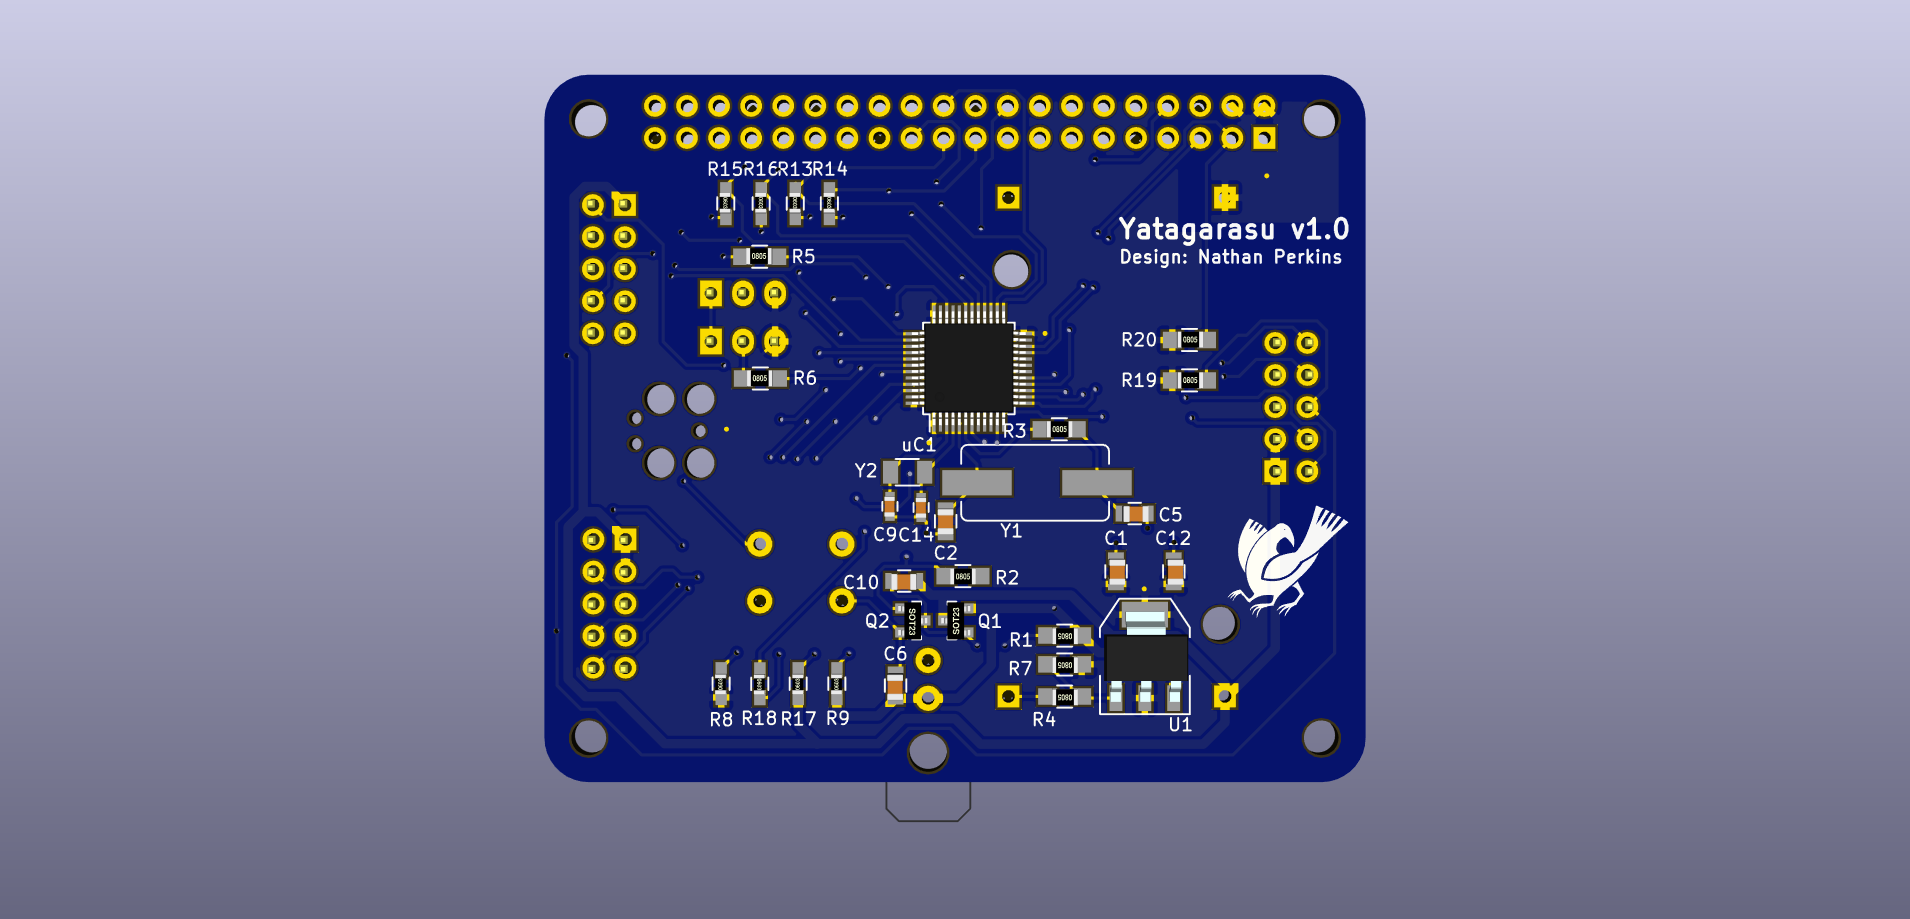
Main Processor unit consists of a Raspberry Pi A+ for path planning and general computation. An STM32 ARM microcontroller system controller will handle the stepper motor control via communication with the RPi A+ board and motor controllers.
1: System Controller
Requirements: The Electronics design require the following footprint libraries for KiCAD
https://github.com/NathanielPerkins/NPFootprints.pretty
2: Mechanical
Chassis design for overall OmniBot frame, and motor mount system
3: Motor Controller
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 0.1u | Capacitors_SMD:C_0805_HandSoldering | C2, C3, C4, C6 |
| 1 | 1.3k | Resistors_SMD:R_0805_HandSoldering | R4 |
| 1 | 100k | Resistors_SMD:R_0805_HandSoldering | R2 |
| 1 | 3.9k | Resistors_SMD:R_0805_HandSoldering | R1 |
| 1 | 470u | Capacitors_SMD:c_elec_8x10 | C1 |
| 1 | 470u | Capacitors_SMD:c_elec_8x10.5 | C7 |
| 1 | 5600p | Capacitors_SMD:C_1206_HandSoldering | C5 |
| 1 | 6.8k | Resistors_SMD:R_0805_HandSoldering | R3 |
| 1 | AP_1539 | footprint:BuckConv | U1 |
| 1 | CONN_01X02 | Socket_Strips:Socket_Strip_Straight_1x02 | P2 |
| 1 | CONN_01X03 | Pin_Headers:Pin_Header_Straight_1x03 | P1 |
| 1 | D_Schottky | Diodes_SMD:SOD-123 | D1 |
| 1 | INDUCTOR | footprint:Inductor1 | L1 |


google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards

conorpp/u2f-zero
U2F USB token optimized for physical security, affordability, and style

rusefi/rusefi
rusefi - GPL internal combustion engine control unit

VoronDesign/Voron-Hardware
Cool Hardware designed by the Voron Design group

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


16 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the QUT-EESS/OmniBot repository on GitHub, at the commit this page was made from: the board is Electronics/Buck Converter/BuckConv.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).