4 layers300 × 250 mm
Supervision
pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.
483 parts

 pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.
Controller carrier is an open-source printed circuit board by pratham-cloud-ctrl, from the pratham-cloud-ctrl/Project-SCCI-RH repository on GitHub. It is a 4-layer board of 155 × 150 mm with 72 parts on 91 nets, routed with 1,958 tracks and 224 vias.
Its parts include 42 resistors, 14 connectors, 7 capacitors and 5 ICs. It belongs with the interfaces and adapters boards and the nRF52 and nRF5x boards of this library.
An entirely digital research and engineering project exploring invasive spinal cord–computer interfaces (SCCI): record relevant activity, interpret it, select an individualized intervention, and observe the response.
Two ambitions: expert-informed practice that could improve retained motor learning, and feedback over a selected physiological function.
Inspect the build in your browser · Explore the project · Read the paper · Download the engineering release
No CAD software needed to inspect: the browser inspector provides selectable 3D assemblies, all eight populated boards, interactive component/net lookup, all four copper layers and 80 searchable schematic sheets. The download panel also supplies standard STEP solids, complete FreeCAD files and complete KiCad projects for local inspection and editing.
| Future implanted-interface concept | Full-scale engineering reference |
|---|---|
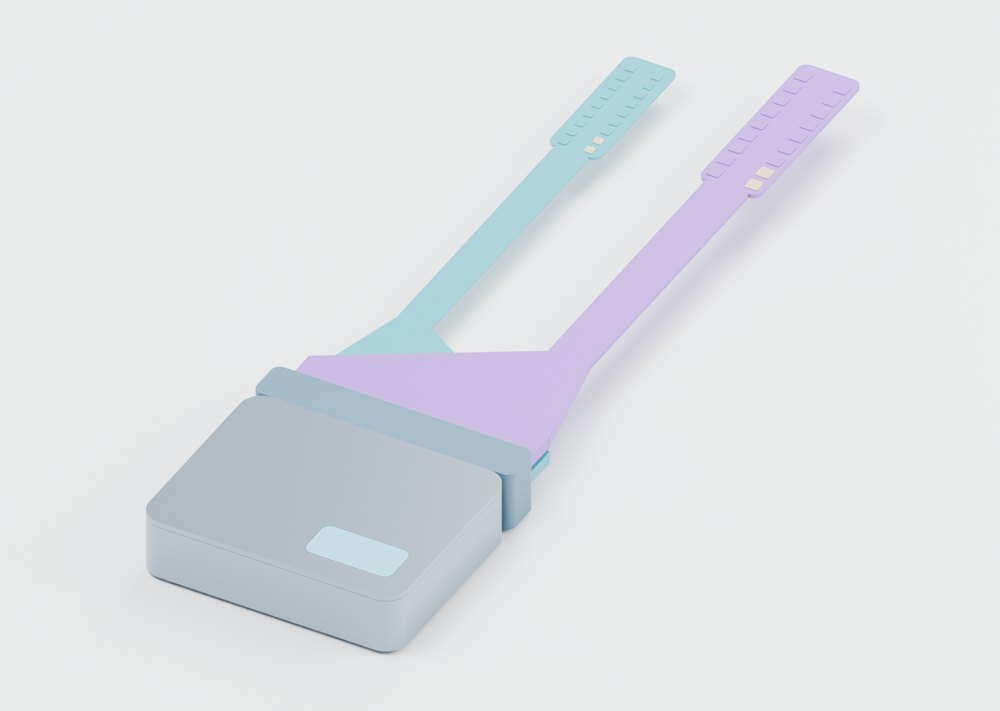 | 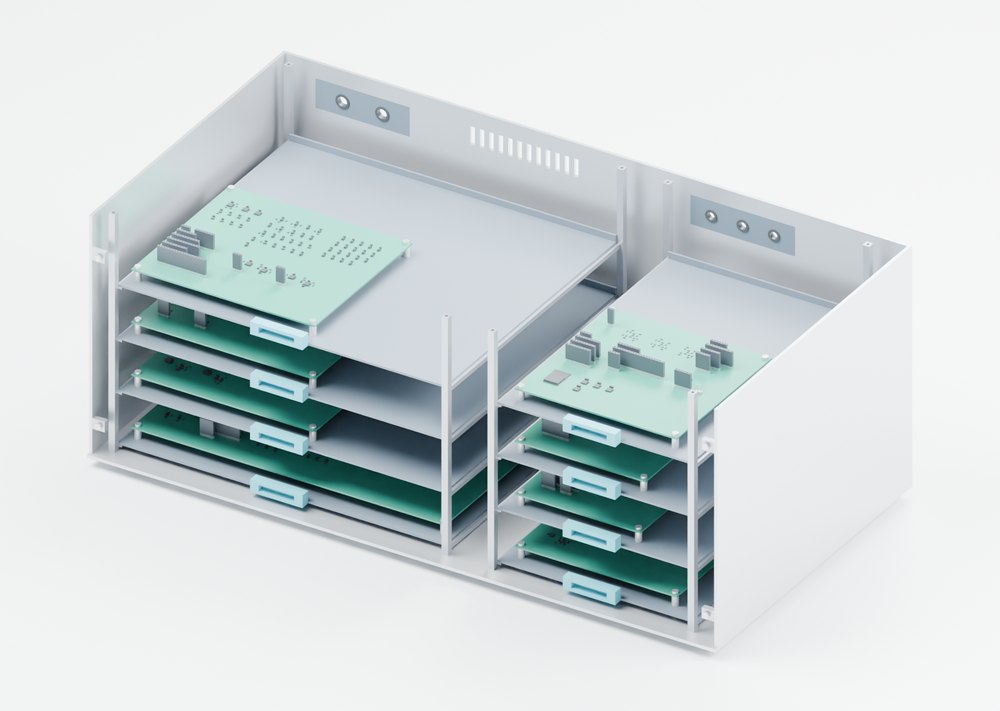 |
| 60 × 58 × 14 mm, before leads. A proposed miniaturized package. | 600 × 310 × 240 mm, including feet. Actual board geometry at 1:1 scale. |
| Open the guide | What you can inspect | |
|---|---|---|
| 01 · Theory & mechanisms | Understand the idea | Both application mechanisms, the assumptions behind them, evidence and mathematical models |
| 02 · CAD & 3D models | Explore the mechanical design | Assembled/exploded views, rotatable meshes, editable FreeCAD files, STEP exports and drawings |
| 03 · Electronics & KiCad | Browse the eight boards | Board gallery, circuit roles, schematic PDF, native projects, layouts and component lists |
| 04 · Firmware & software | Follow the implemented logic | Current nRF5340 image, production control code, packet handling and runnable verification |
| 05 · Evidence & reproduction | Review the work | A short reviewer walkthrough, results, requirements, source records and reproduction commands |
Use the browser inspector for viewing. Links labelled native source lead to engineering files that GitHub may offer only as downloads. Use the complete packages in the inspector to open them locally; the guides explain the required software, dependencies and how to preserve the released originals.
Observe → interpret → calibrate → request stimulation → supervise delivery → observe response.
For motor learning, expert performance informs a task-conditioned reference; learner-specific calibration determines a reachable intervention during practice. Later stimulation-OFF probes assess retention separately from assisted performance. Expert voltage is not replayed as a skill.
For physiological feedback, a function-specific configuration observes a selected state and requests bounded support. The worked pressure example uses an external pressure sensor and positive spinal pressor authority. It is a selected pathway, not a universal body-control mechanism.
The integrated replay passes 114,426 finite software assertions and includes 5,184 modeled motor events and 1,200 pressure events. Favorable, neutral and adverse learning assumptions are retained. These are software/model results; their implications are explained in the theory guide.
This is a completed digital concept and engineering reference. No physical device execution or original human/animal experiment is claimed. Useful chronic spinal decoding, retained human benefit and a miniaturized implanted implementation remain conditional. The current target records in OBSERVE, inhibits neural acquisition while armed, and has no radio image. The reference boards do not fit the future can.
Pratham Varma conceived and steered Project SCCI RH. AstroSam’s Mind-Link inspired the progression from future vision to inspectable engineering; SCCI_RH develops its own spinal architecture and artifacts. Substantial AI assistance is documented in the contribution record.
Engineering release: v2.1.1. Browser inspection and guide refresh: 21 October 2026. The paper and verified engineering geometry and circuit behavior are preserved through the recorded name migration. Historical stage records remain available; use the guides above for the current reading order. The technical inspector supports engineering review; presentation website and video work remain parked.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 41 | 10k | scci_rh_controller:R_0805_2012Metric | R80002, R80100, R80101, R80102, R80103, R80104, R80105, R80106, R80107, R80108, R80109, R80110, R80111, R80112, R80113, R80114 +25 |
| 5 | 100n X7R 10V | scci_rh_controller:C_1206_3216Metric | C80003, C80010, C80011, C80012, C80013 |
| 4 | MountingHole_3.2mm_M3 | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 4 | SN74LVC165APWR | scci_rh_controller:TSSOP-16_4.4x5mm_P0.65mm | U80010, U80011, U80012, U80013 |
| 1 | 0R | scci_rh_controller:R_0805_2012Metric | R80001 |
| 1 | 1u X7R 10V | scci_rh_controller:C_1206_3216Metric | C80002 |
| 1 | 47u X7R 10V | scci_rh_controller:C_1206_3216Metric | C80001 |
| 1 | ACTIVE ROUTE READBACK | scci_rh_controller:PinHeader_1x09_P2.54mm_Vertical | J80017 |
| 1 | DAC SERIAL | scci_rh_controller:PinHeader_1x04_P2.54mm_Vertical | J80014 |
| 1 | DOSE / MONITOR REARM | scci_rh_controller:PinHeader_1x05_P2.54mm_Vertical | J80013 |
| 1 | DRIVER REQUEST / POLARITY | scci_rh_controller:PinHeader_1x09_P2.54mm_Vertical | J80015 |
| 1 | FANSTEL BT40F / nRF5340 | scci_rh_controller:BT40F_Manufacturer_66Pad | U80001 |
| 1 | HOST POWER | scci_rh_controller:PinHeader_1x02_P2.54mm_Vertical | J80001 |
| 1 | ISOLATED COMPANION HOST UART | scci_rh_controller:PinHeader_1x04_P2.54mm_Vertical | J80020 |
| 1 | ISOLATED RECORDING HOST | scci_rh_controller:PinHeader_1x10_P2.54mm_Vertical | J80011 |
| 1 | NATIVE HEALTH OBSERVATIONS | scci_rh_controller:PinHeader_1x19_P2.54mm_Vertical | J80019 |
| 1 | RAW MONITOR | scci_rh_controller:PinHeader_1x06_P2.54mm_Vertical | J80010 |
| 1 | RESET SHORTING HEADER | scci_rh_controller:PinHeader_1x02_P2.54mm_Vertical | J80003 |
| 1 | ROUTE CANDIDATE / COMMIT | scci_rh_controller:PinHeader_1x09_P2.54mm_Vertical | J80016 |
| 1 | SHARED CHARGE ENDPOINT SPI | scci_rh_controller:PinHeader_1x07_P2.54mm_Vertical | J80012 |
| 1 | SUPERVISION CONTROL | scci_rh_controller:PinHeader_1x08_P2.54mm_Vertical | J80018 |
| 1 | SWD / TARGET VREF | scci_rh_controller:PinHeader_1x06_P2.54mm_Vertical | J80002 |
It measures 155 × 150 mm and has 4 copper layers, 1.6 mm thick.
72 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the pratham-cloud-ctrl/Project-SCCI-RH repository on GitHub, at the commit this page was made from: the board is electronics/stage4/integrated-pcb/boards/controller-carrier/controller_carrier.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask pratham-cloud-ctrl before reusing the design.
pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.

pratham-cloud-ctrl/Project-SCCI-RH
A digital spinal cord-computer interface concept: research, eight KiCad boards, nRF5340 firmware and FreeCAD assemblies.


murexrobotics/electrical
Highly integrated electronics design and printed circuit boards (PCBs) for the MATE ROV Competition. Attempt the impossible.

Redherring32/Xbox-Portable
Fully portable original (2001) Xbox handheld using real hardware


Twisted-Fields/induction_encoder
An induction encoder with generator script for the Acorn steering system.
