
2 layers72.6 × 166.6 mm
EncoderHub
pranay-junare/clothbot
Cloth Manipulation using self-supervised Spatial Action Maps
18 parts4MIT

 pranay-junare/clothbot4
Cloth Manipulation using self-supervised Spatial Action Maps
Encoder is an open-source printed circuit board by pranay-junare, from the pranay-junare/clothbot repository on GitHub, published under the MIT licence. It is a 2-layer board of 26 × 25 mm with 7 parts on 15 nets, routed with 47 tracks and 1 via.
It is built around the AS5047D. Its parts include 2 resistors, 2 diodes, 1 capacitor, 1 IC and 1 connector. It belongs with the robots and motor control boards of this library.
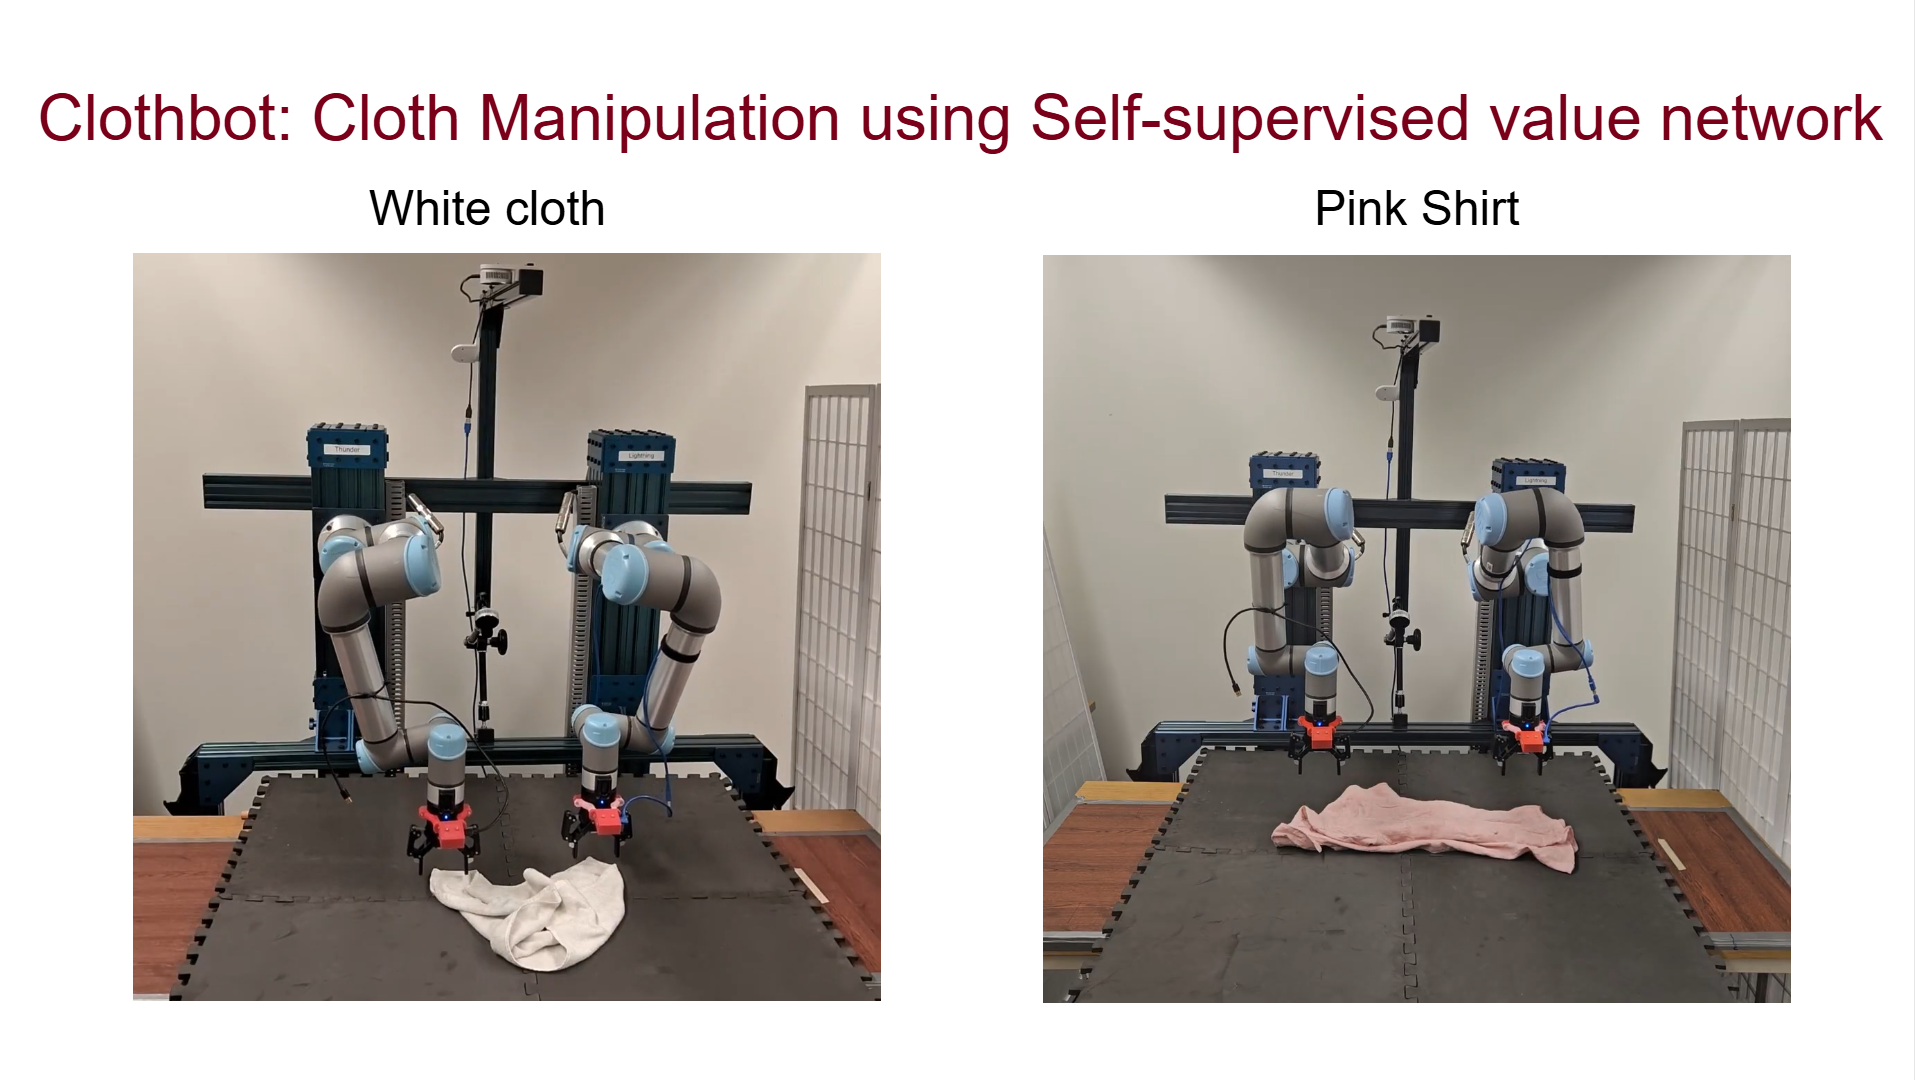 Video Link: Demo
| Rollout on rectangular cloth 1 | Rollout on rectangular cloth 2 |
|---|---|
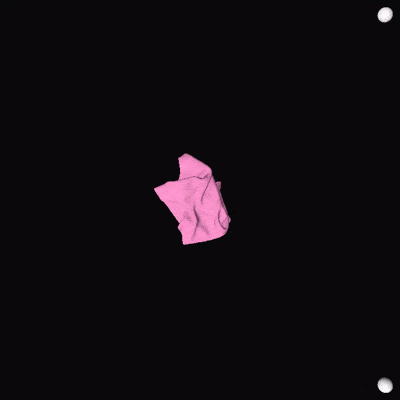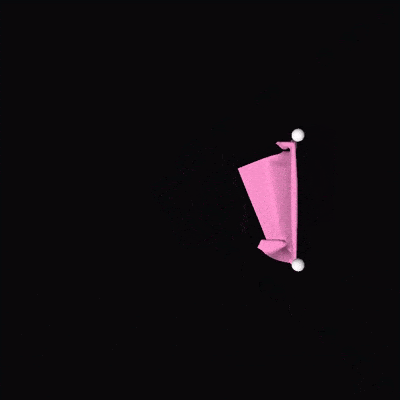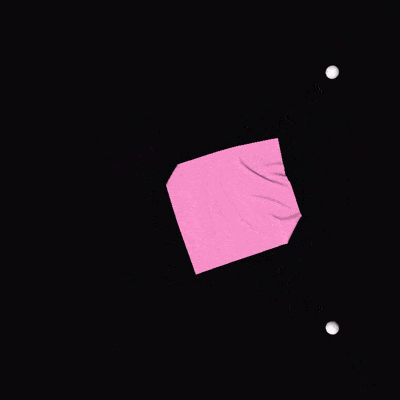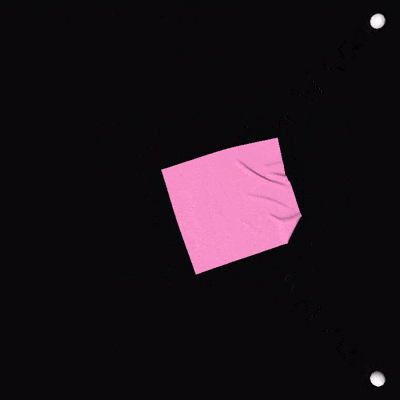 | 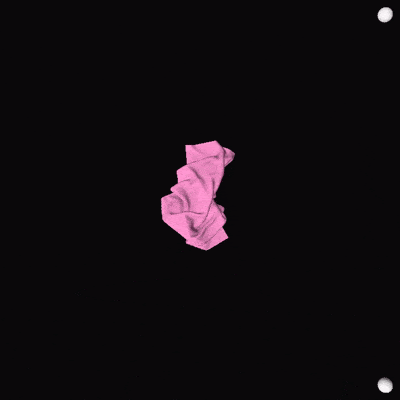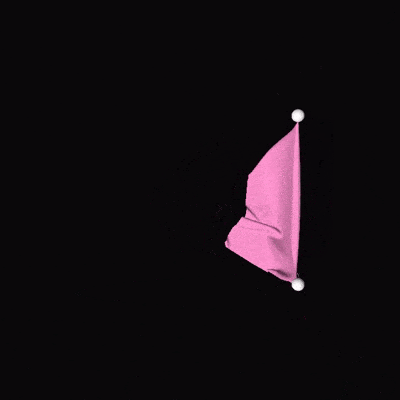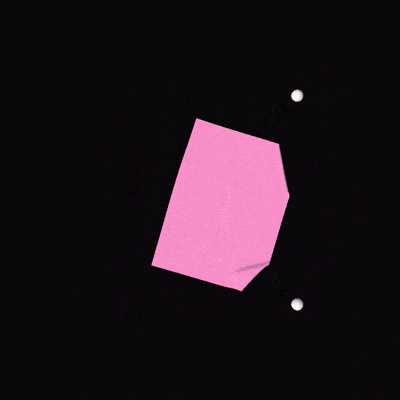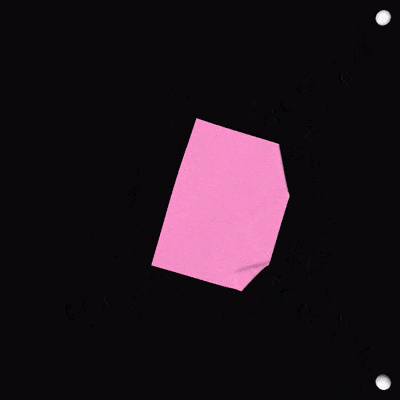 |
| Rollout on unseen tshirt 1 | Rollout on unseen tshirt 2 |
|---|---|
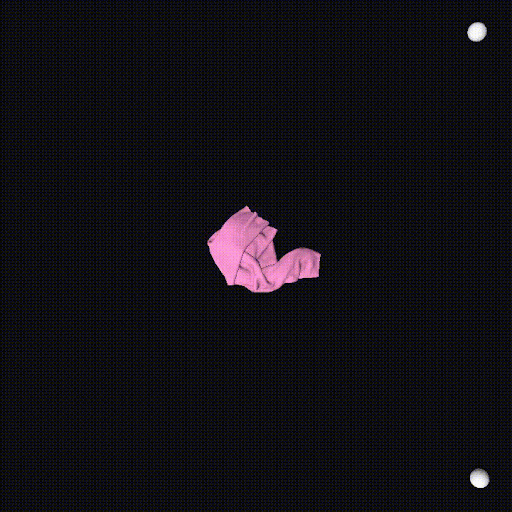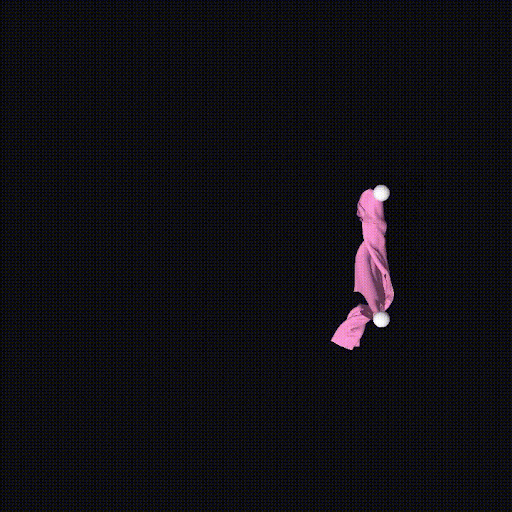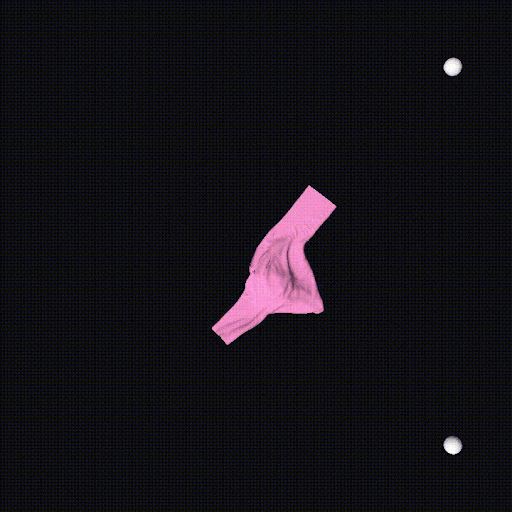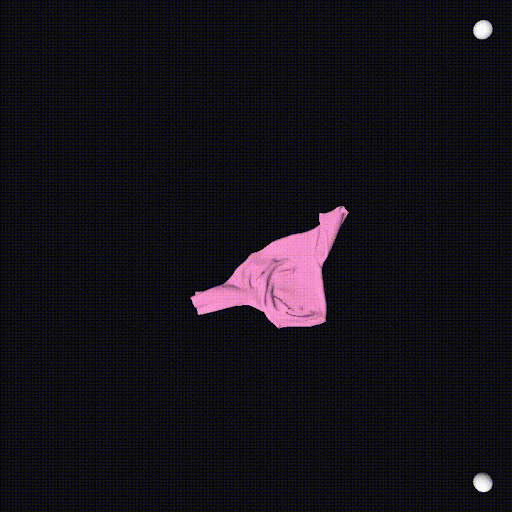 | 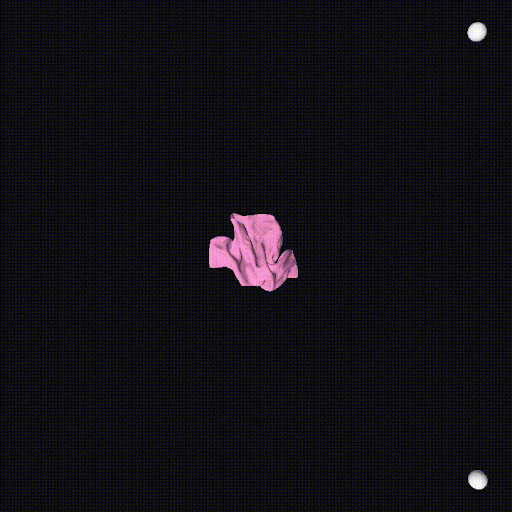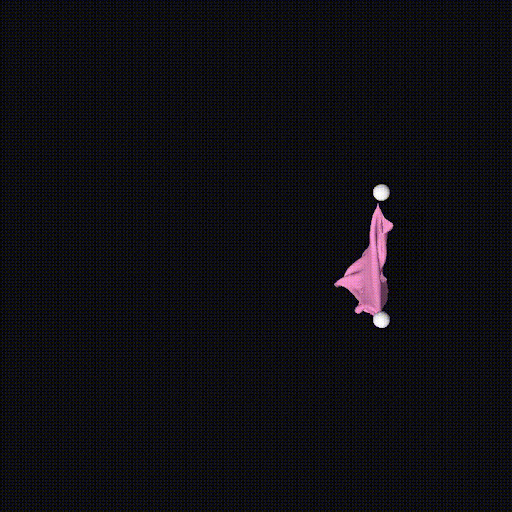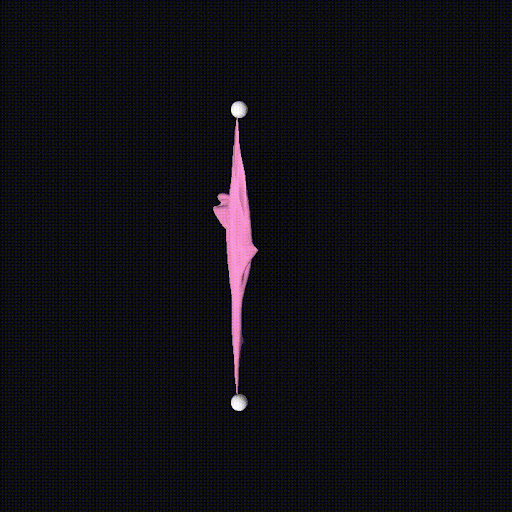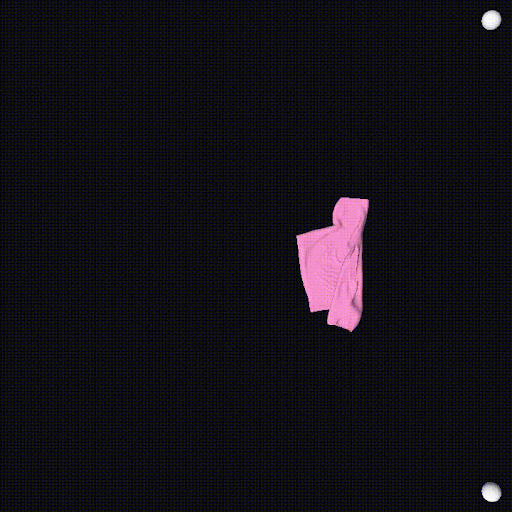 |
Cloth manipulation is a challenging problem due to cloth’s complex dynamics, almost infinite DoF and severe self-occlusion. Moreover, most cloth manipulation tasks require chaining of multiple action primitives such pick, place, drag fling, stretch, etc. In addition, most of the current cloth manipulation research only use quasi-static actions taking large amount of time to manipulate different garments. Thus our project aims to tackle this complex manipulation problem by imparting the capability of dynamic cloth unfolding to a bimanual robot using a high- velocity dynamic fling action. We focus particularly on the task of cloth unfolding, a typical first step in most cloth manipulation tasks. We trained our self-supervised Value network policy based on Spatial Action Maps. The policy is completely trained on only rectangular cloths in simulation. We have leveraged Softgym simulator and have trained the policy for 7 days until convergence. The policy achieves a cloth unfolding mean coverage of 95.09% over 200 rollouts on rectangular cloths. Interestingly our policy also generalizes to unseen cloths such as T-shirts while achieving the mean coverage of 87.68%. It also transfers to the real-world cloths in a zero-shot manner without any need of fine-tuning. Real-world results are evaluated on a UR5e dual-arm robot.
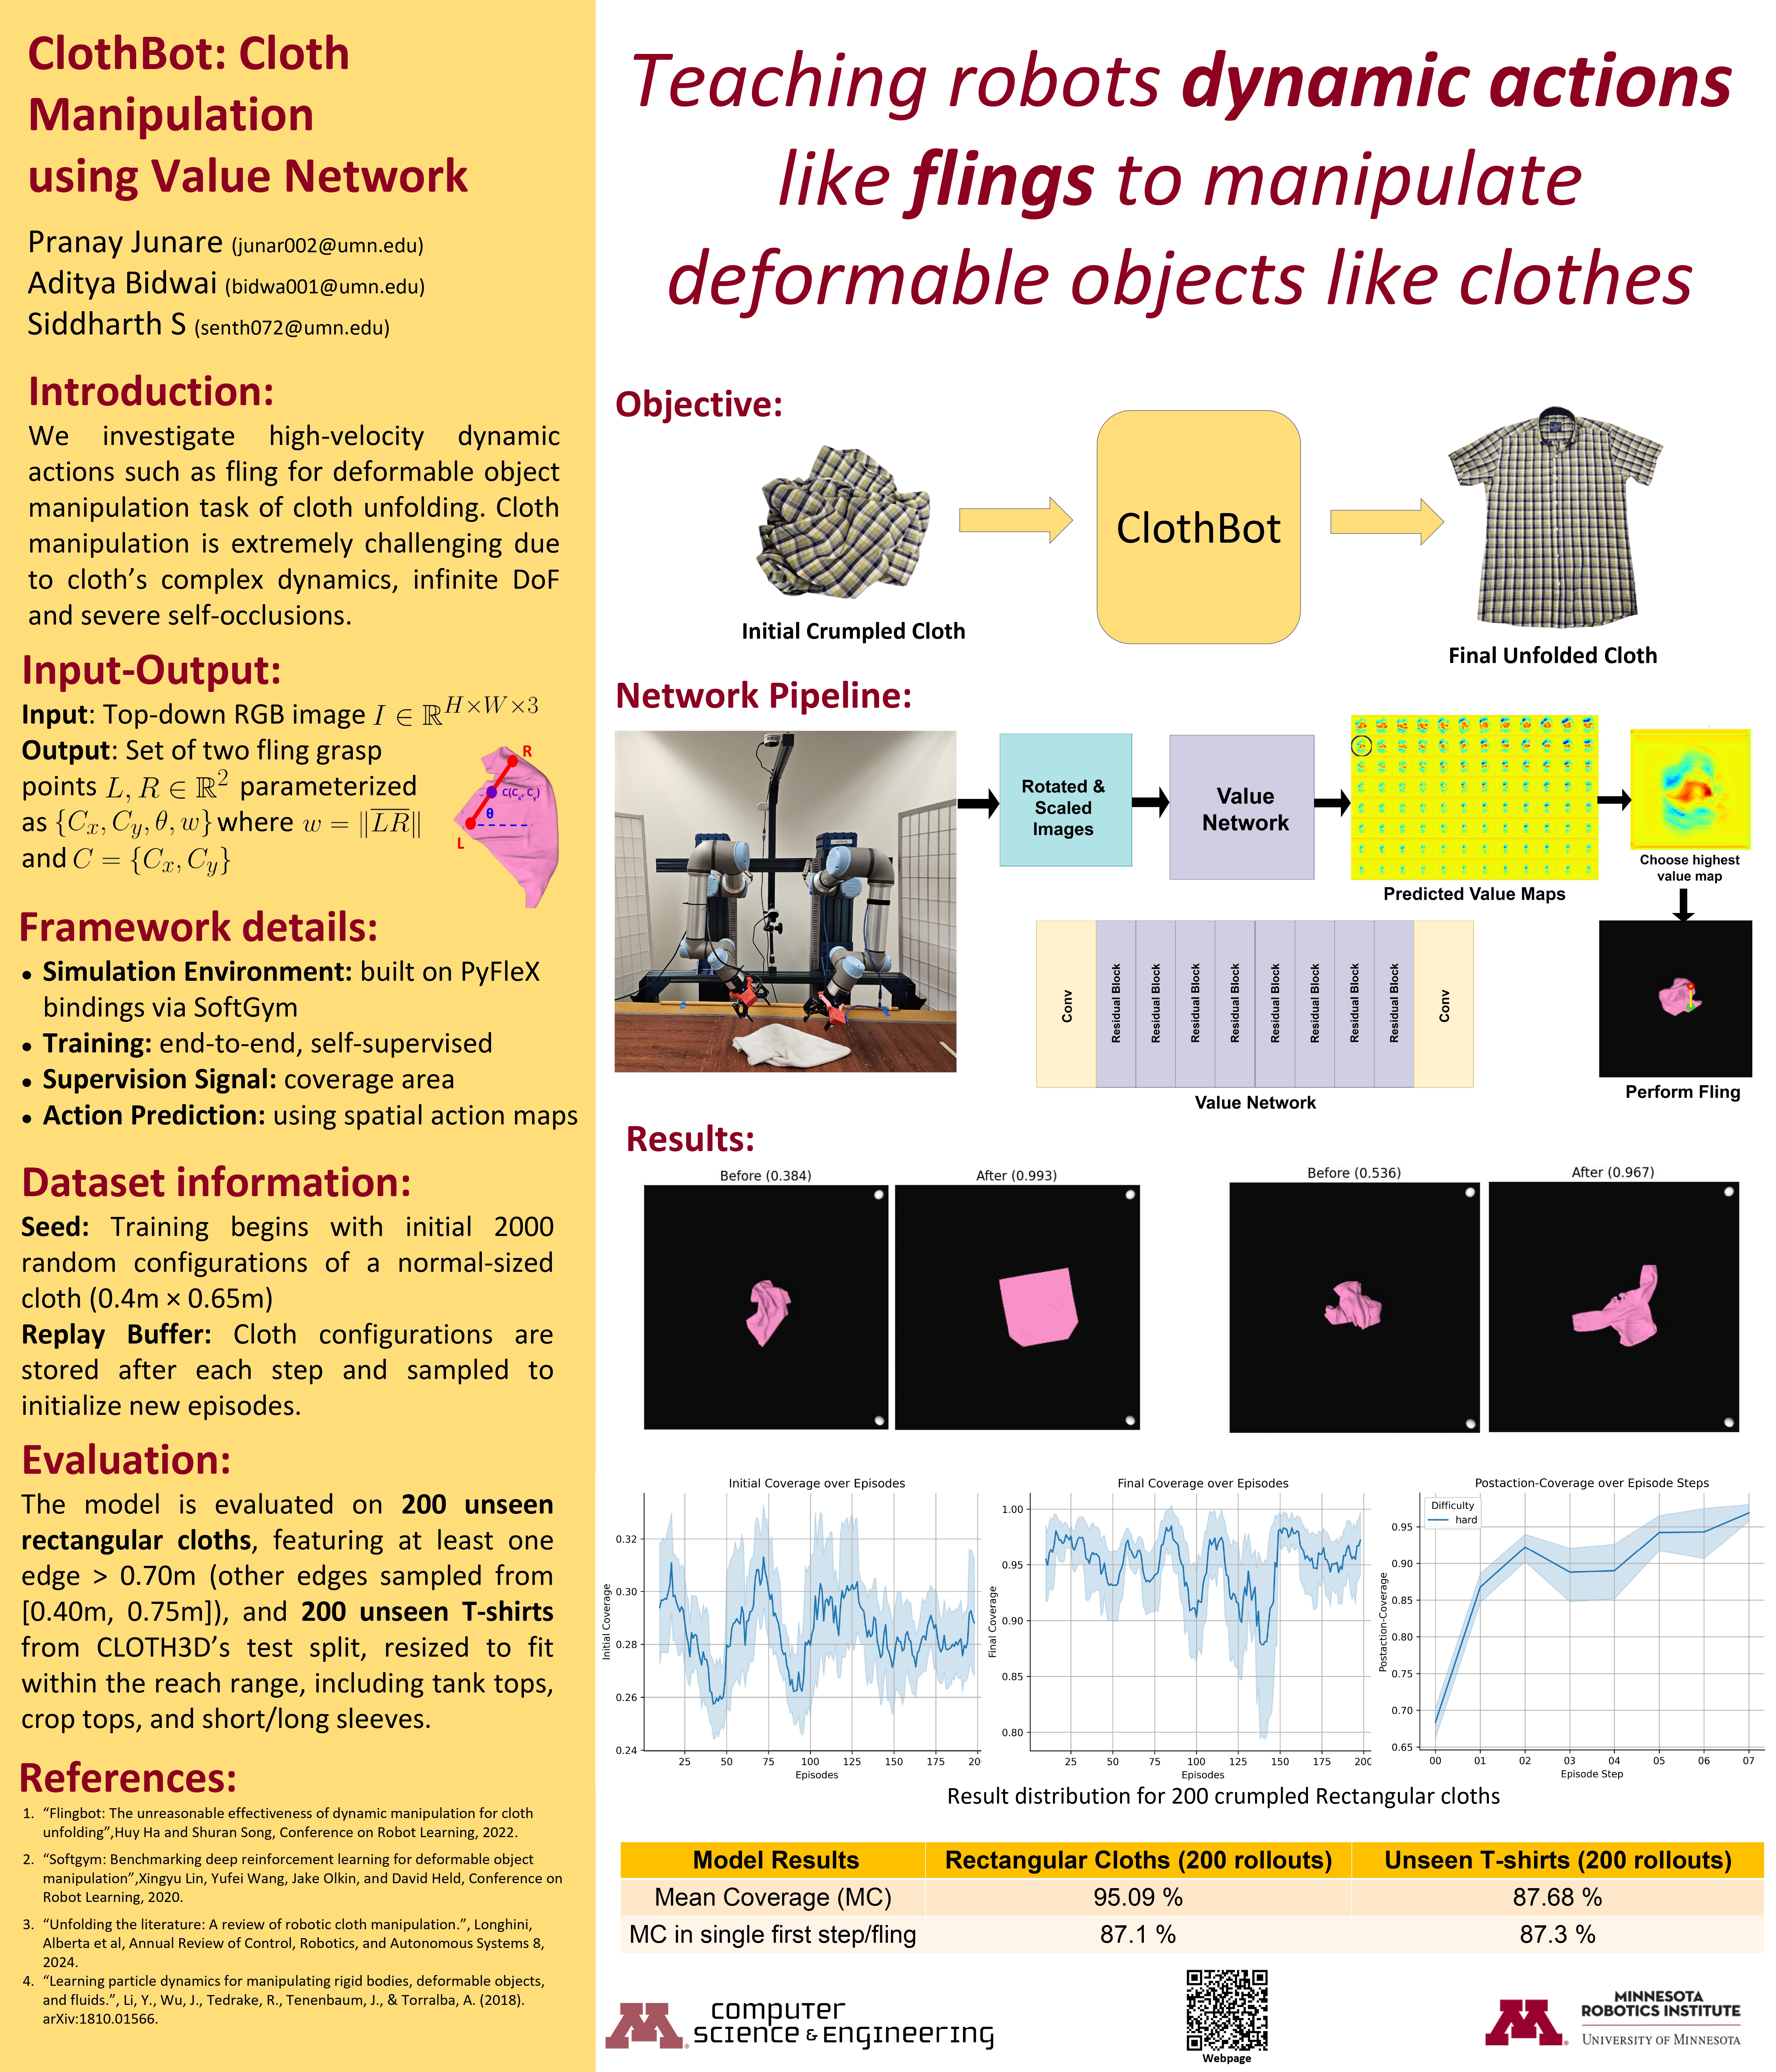
This work is the re-implementation of the below paper, so if you find it useful please cite the Flingbot paper:
Other References:
MIT
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 65 | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1, R2 |
| 1 | 1000nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1 |
| 1 | AS5047D | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U1 |
| 1 | LED | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D2 |
| 1 | RJ45_Shielded | Connector_RJ:RJ45_Ninigi_GE | J1 |
| 1 | Red | LED_SMD:LED_1206_3216Metric_Pad1.42x1.75mm_HandSolder | D1 |
It measures 26 × 25 mm and has 2 copper layers, 1.6 mm thick.
7 parts, built around the AS5047D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the pranay-junare/clothbot repository on GitHub, at the commit this page was made from: the board is real_world/Hardware/PCB/Encoder/Encoder.kicad_pcb and its schematic real_world/Hardware/PCB/ESP32_breakout/ESP32_breakout.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
pranay-junare/clothbot
Cloth Manipulation using self-supervised Spatial Action Maps

pranay-junare/clothbot
Cloth Manipulation using self-supervised Spatial Action Maps


pointhi/HighPower-Mechaduino
Mechaduino derivative which drives up to 10A, drawn using KiCad

NYDEREK/LineFollower_GRUZIK3.0
Loved the project? Please consider giving a Star ⭐️


williamhaarhoff/foc8313
Highly compact field oriented controller based on the DRV8313 IC

sequoia-hope/vesc_encoder
An openly licensed magnetic encoder board, compatible with VESC 4.12 based designs.

dognotdog/smol_servo
circuitry and software for controlling NEMA17 size brushless motors and stepper motors as servos.