4 layers132.5 × 105 mm
HEXCORE PCB Design v0
JoshCrouch/HEXCORE
HEXCORE is a Hexapod-type robot that includes both a custom remote as well as vision system making use of 2.4GHz RF and WiFi respectively.
160 parts3

 paagutie/bluerov_acmodule
DIY Board developed as actuator module using micro-ROS as middelware.
STM32F4 Breakout is an open-source printed circuit board by paagutie, from the paagutie/bluerov_acmodule repository on GitHub, published under the Apache-2.0 licence. It is a 4-layer board of 66 × 47.1 mm with 70 parts on 84 nets, routed with 510 tracks and 79 vias.
It is built around the STM32F405RGT6, R-785.0-1.0 and AMS1117-3.3, with the USBLC6-2SC6, BC848 and IRLML6402 among its other parts. Its parts include 24 connectors, 16 capacitors, 13 resistors, 4 ICs and 2 diodes. It belongs with the interfaces and adapters boards and the STM32 boards of this library.


DIY Board developed as actuator module for a custom BlueROV2 that uses micro-ros as middelware for integration with ROS2. The STM32CubeIDE program was used as programming IDE and the micro_ros_stm32cubemx_utils repository was used for integration with micro-ROS. For more information, follow the steps described in its documentation.
cd ~
mkdir ~/STM32CubeIDE/workspace_1.x.x/minirov_acmodule
git clone --recurse-submodules https://github.com/paagutie/minirov_acmodule.git
cp -a minirov_acmodule/software/. ~/STM32CubeIDE/workspace_1.x.x/minirov_acmodule
cd /minirov_acmodule/sofwareexport EXTRA_PACKAGES_DIR=~/STM32CubeIDE/workspace_1.x.x/minirov_acmodule/micro_ros_stm32cubemx_utils/microros_static_library_ide/library_generation/extra_packages/
cp -a extra_packages/. $EXTRA_PACKAGES_DIRSubscribers:
actuator/module/out/controlPublishers:
actuator/module/battery/dataactuator/module/leakFor the development of the printed circuit board we used the Cross Platform and Open Source Electronics Design Automation Suite KiCad.
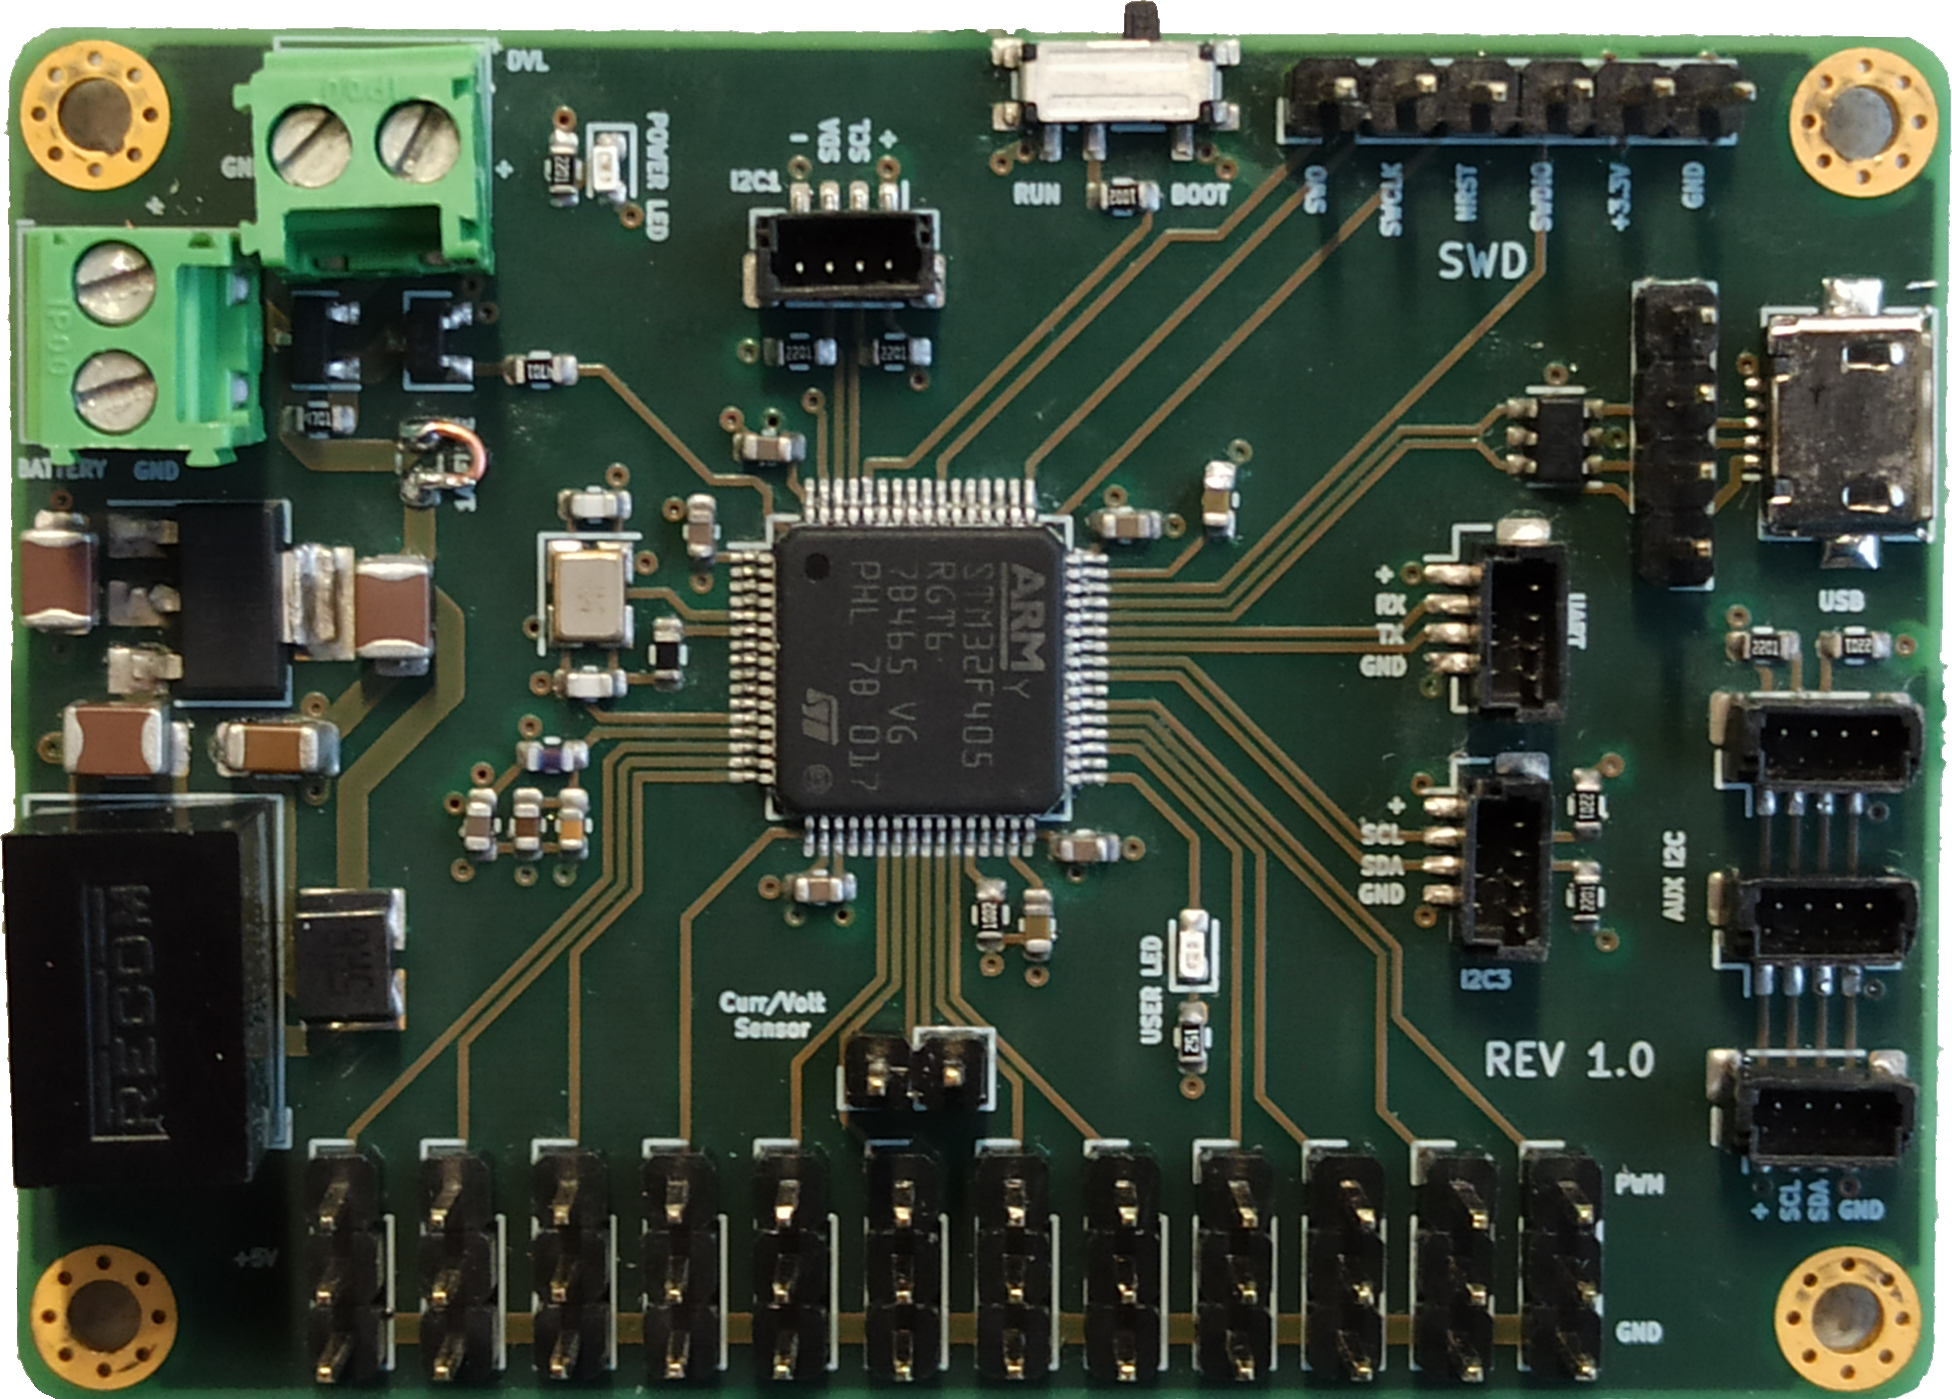
Here is an image of the finished Actuator Module.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J12, J13, J14, J15, J16, J17, J18, J19, J20, J21, J22, J23 |
| 7 | 2k2 | Resistor_SMD:R_0603_1608Metric | R2, R3, R4, R8, R9, R12, R13 |
| 6 | Conn_01x04 | Connector_JST:JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J3, J4, J5, J6, J7, J11 |
| 5 | 100nF | Capacitor_SMD:C_0603_1608Metric | C2, C3, C5, C6, C8 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_2.5mm_Pad_Via | H1, H2, H3, H4 |
| 3 | 10uF | Capacitor_SMD:C_1206_3216Metric | C9, C11, C15 |
| 2 | 10k | Resistor_SMD:R_0603_1608Metric | R1, R7 |
| 2 | 12pF | Capacitor_SMD:C_0603_1608Metric | C13, C14 |
| 2 | 2.2uF | Capacitor_SMD:C_0603_1608Metric | C1, C4 |
| 2 | 4k7 | Resistor_SMD:R_0603_1608Metric | R10, R11 |
| 2 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J1, J2 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric | C12 |
| 1 | 16MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | HSE1 |
| 1 | 1k5 | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 1uF | Capacitor_SMD:C_0603_1608Metric | C10 |
| 1 | 2.2uF | Capacitor_SMD:C_1206_3216Metric | C16 |
| 1 | 39nH | Inductor_SMD:L_0603_1608Metric | L1 |
| 1 | 47 | Resistor_SMD:R_0603_1608Metric | R6 |
| 1 | 4u7 | Capacitor_SMD:C_0603_1608Metric | C7 |
| 1 | 500mA | Fuse:Fuse_0805_2012Metric | F1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U2 |
| 1 | BC848 | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | Blue | LED_SMD:LED_0603_1608Metric | D4 |
| 1 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J24 |
| 1 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J10 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J8 |
| 1 | Green | LED_SMD:LED_0603_1608Metric | D3 |
| 1 | IRLML6402 | Package_TO_SOT_SMD:SOT-23 | Q2 |
| 1 | R-785.0-1.0 | Converter_DCDC:Converter_DCDC_RECOM_R-78E-0.5_THT | U4 |
| 1 | RLS-567-R | RLS-567-R:IND_RLS-567-R | L2 |
| 1 | STM32F405RGT6 | Package_QFP:LQFP-64_10x10mm_P0.5mm | U1 |
| 1 | SW_SPDT | Button_Switch_SMD:SW_SPDT_PCM12 | SW1 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U3 |
| 1 | USB_B_Micro | Connector_USB:USB_Micro-B_Amphenol_10104110_Horizontal | J9 |
JoshCrouch/HEXCORE
HEXCORE is a Hexapod-type robot that includes both a custom remote as well as vision system making use of 2.4GHz RF and WiFi respectively.

MURPHYENGINEERING/STM32F405RGT6-Breakout
Following along with Phil's Lab: https://www.youtube.com/watch?v=t5phi3nT8OU

felixznr/ALBERT
Albert I was a rhesus macaque monkey and the first mammal launched on a rocket (V-2 Rocket "Blossom No. 3") on June 18, 1948.

Phil-CIA/Development-Station-Power-Supply
3 channel bench supply with current and voltage plotting


rogerclarkmelbourne/STM32_Pill_Boards
Various STM32 boards in a form factor similar to the Maple Mini or Blue Pill board


It measures 66 × 47.1 mm and has 4 copper layers, 1.6 mm thick.
70 parts, built around the STM32F405RGT6, R-785.0-1.0, AMS1117-3.3 and USBLC6-2SC6. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the paagutie/bluerov_acmodule repository on GitHub, at the commit this page was made from: the board is hardware/STM32F4_Breakout.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Apache-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).