2 layers42 × 42 mm
NEMA17 FOC Driver
maxmunzner/NEMA17_FOC_Driver
A Stepper Driver project with a PCB that acts as the driver and encoder.
37 parts1MIT
 maxmunzner/RobotArm
A Robot Project
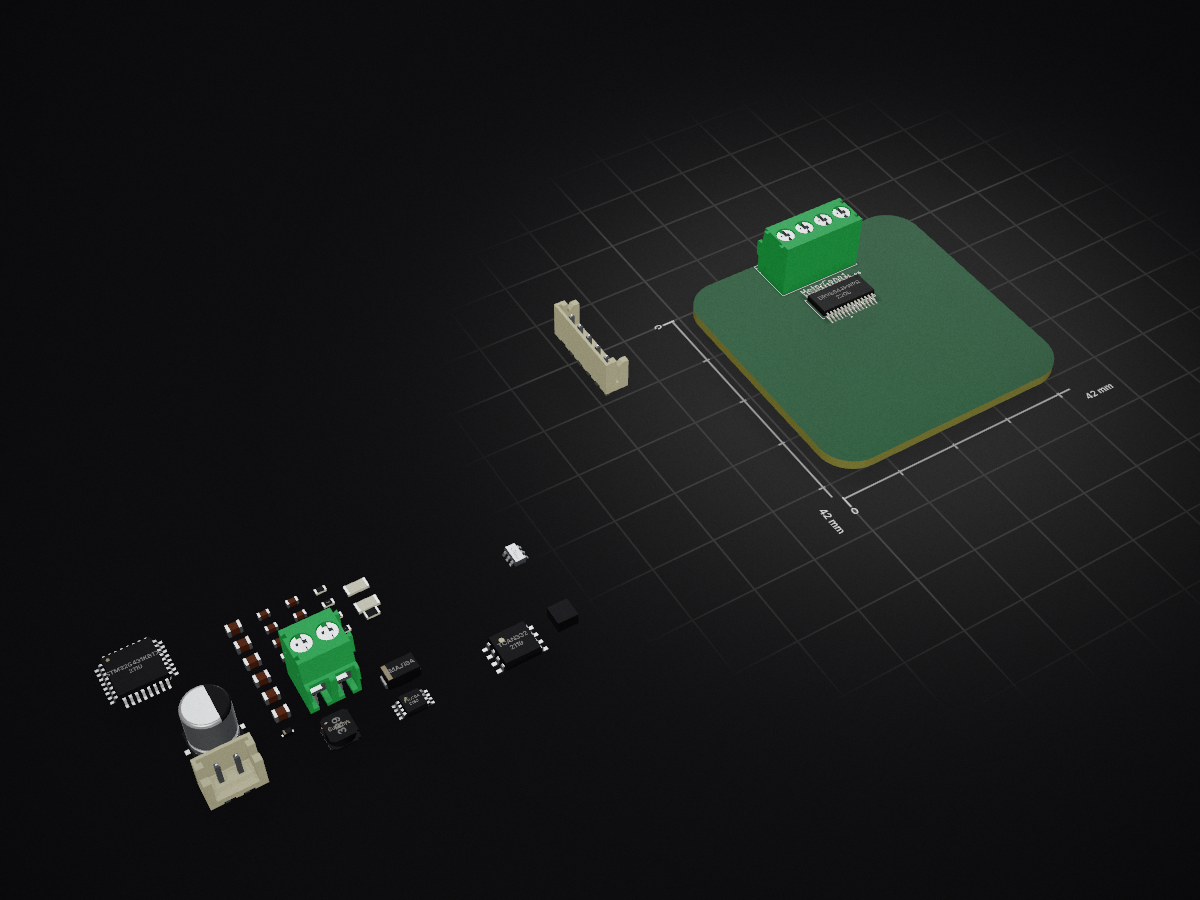
NEMA17 FOC Driver is an open-source printed circuit board by maxmunzner, from the maxmunzner/RobotArm repository on GitHub, published under the MIT licence. It is a 2-layer board of 42 × 42 mm with 36 parts on 52 nets.
It is built around the TCAN332D, DRV8844PWPR and MT6701CT-STD, with the 24LC64(LX) and SMAJ18A among its other parts. Its parts include 13 capacitors, 6 ICs, 3 diodes, 2 connectors and 1 inductor. It belongs with the robots and motor control boards and the STM32 boards of this library.


A Robot Project
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 10u | Capacitor_SMD:C_0805_2012Metric | C3, C5, C10, C11 |
| 3 | 0.1u | Capacitor_SMD:C_0603_1608Metric | C1, C2, C9 |
| 3 | 100n | Capacitor_SMD:C_0603_1608Metric | C6, C12, C13 |
| 3 | 10k | Resistor_SMD:R_0603_1608Metric | R_BOOT1, R_SCL1, R_SDA1 |
| 2 | 0.1 | Resistor_SMD:R_1206_3216Metric | RSENS1, RSENS2 |
| 2 | 220 | Resistor_SMD:R_0603_1608Metric | RLED_G1, RLED_R1 |
| 2 | 22u | Capacitor_SMD:C_0805_2012Metric | C7, C8 |
| 1 | 0.47u | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | 100u | Capacitor_SMD:CP_Elec_6.3x7.7 | CIN1 |
| 1 | 120 | Resistor_SMD:R_0805_2012Metric | RCAN1 |
| 1 | 24LC64 | Package_SO:TSSOP-8_3x3mm_P0.65mm | U6 |
| 1 | 3.9u | Inductor_SMD_Wurth:L_Wurth_WE-LQSH-4020 | L1 |
| 1 | AP63203WU-7 | AP63203WU:AP63203WU-7_DIO-L | U2 |
| 1 | Conn_01x02_Pin | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-3.5-H_1x02_P3.50mm_Horizontal | J1 |
| 1 | Conn_01x02_Pin | Connector_JST:JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J2 |
| 1 | Conn_01x05_Pin | Connector_JST:JST_EH_B5B-EH-A_1x05_P2.50mm_Vertical | PROG_CONN1 |
| 1 | DRV8844PWPR | DRV8844:PWP28_5P18X3P1-M | U1 |
| 1 | ESD5Zxx | Diode_SMD:D_SOD-523 | D1 |
| 1 | MT6701CT | Package_SO:SO-8_3.9x4.9mm_P1.27mm | U3 |
| 1 | SMAJ18A | Diode_SMD:D_SMA | D2 |
| 1 | SML-LX15IGC-RT-TR | SML-LX15:SML-LX15_LUM | LED1 |
| 1 | STM32G431KBTx | Package_QFP:LQFP-32_7x7mm_P0.8mm | U4 |
| 1 | TCAN332 | TCAN332:D0008A_M | U5 |
| 1 | ~ | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-4-3.5-H_1x04_P3.50mm_Horizontal | MotorConn1 |
It measures 42 × 42 mm and has 2 copper layers, 1.6 mm thick.
36 parts, built around the TCAN332D, DRV8844PWPR, MT6701CT-STD and 24LC64(LX). The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the maxmunzner/RobotArm repository on GitHub, at the commit this page was made from: the board is Hardware/NEMA17_FOC_Driver/PCB/NEMA17_FOC_Driver.kicad_pcb and its schematic Hardware/NEMA17_FOC_Driver/PCB/NEMA17_FOC_Driver-backups/NEMA17_FOC_Driver-2026-01-14_214247/NEMA17_FOC_Driver.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
maxmunzner/NEMA17_FOC_Driver
A Stepper Driver project with a PCB that acts as the driver and encoder.


Sarwan1494/Sarwan1494.github.io
Plain HTML / CSS / JS, no build step, no framework, no dependencies except KiCanvas (loaded from kicanvas.org via on the project pages) for the in-browser KiCad viewer.

eez-open/psu-hw
EEZ H24005 programmable bench power supply (powered by Arduino Due)


cfbird/ULNA-Lband-2S
Two-stage ultra-low-noise amplifier for 1.0 – 2.2 GHz, built around a pair of Skyworks SKY67151-396LF GaAs pHEMT LNAs.

fharold/rpi2040-lcd-gauge
Basic and versatile gauges based on the WAVESHARE RP2040-LCD-1.28 module. A small HAT enhances it:
