4 layers64.2 × 51.3 mm
 Mathijsvb/MulticopterFCS1
Multicopter Flight Control System
FlightController is an open-source printed circuit board by Mathijsvb, from the Mathijsvb/MulticopterFCS repository on GitHub, published under the BSD-3-Clause licence. It is a 4-layer board of 57 × 57 mm with 199 parts on 162 nets, routed with 973 tracks and 392 vias.
It is built around the STM32H743VIT6, CH330N and BMP388, with the TF-01A, AMS1117-5V and FM24C64B-G among its other parts. Its parts include 62 resistors, 55 capacitors, 29 diodes, 12 connectors and 8 ICs. It belongs with the robots and motor control boards and the STM32 boards of this library.


MulticopterFCS is a flight controller build from the ground up. It is meant to be a development platform mainly focused on autonomous indoor flying of multi-rotor drones.
Warning The current version still contains design errors.
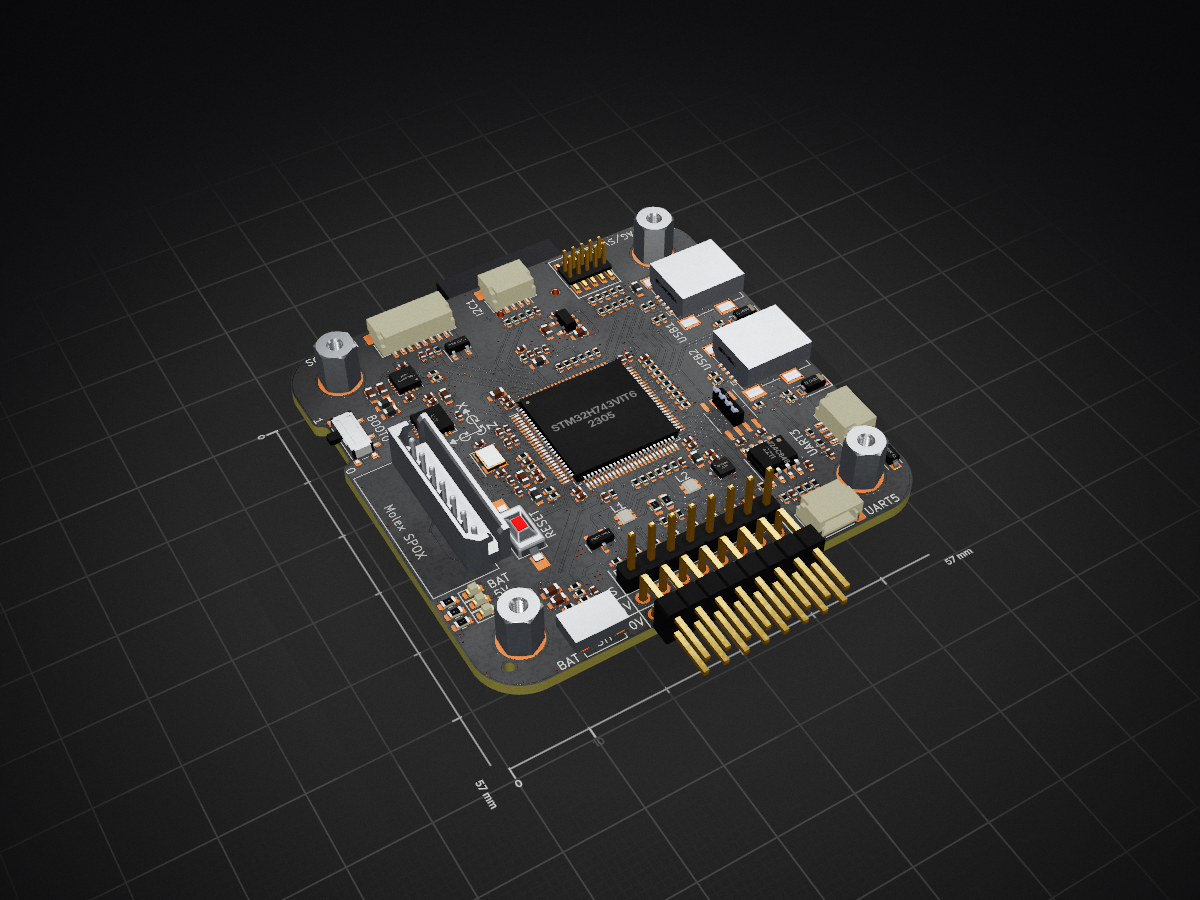
| Diagram | Board |
|---|---|
 |  |
On board:
Connectors:
| quantity | purpose | connector type | Comment |
|---|---|---|---|
| 1 | SWD/JTAG | 1.27 mm pitch 10-pin | For programming and debugging |
| 1 | SDIO | Micro SD Card | For logging data during the flight |
| 1 | I²C | JST SH 4-pin | External I²C connector |
| 2 | UART | JST SH 4-pin | External UART connector |
| 1 | Battery | JST SH 2-pin | Used to measure battery voltage |
| 1 | LED | JST SH 8-pin | To control external LEDs |
| 1 | IBUS | 2.54 mm pitch header | IBUS used by external receivers to communicate remote control signals |
| 6 | PWM | 2.54 mm pitch header | PWM is used to control external ESC's |
| 1 | Buzzer | 2.54 mm pitch header | For connecting a buzzer |
| 1 | RPLiDAR | 2.50 mm MOLEX SPOX 7-pin | This connector will be used for the RPLiDAR |
| 2 | USB | USB Mini B | USB1 goes directly to the MCU, USB2 gets converted to serial first |
Future goals on the roadmap are likely to be Simultaneous Localization and Mapping using a LiDAR implementation. Based on this, autonomous indoor flight could be developed.
This system is still a work in progress, use anything inside this repository at your own risk.
This an open source project released under the BSD 3-Clause License.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 34 | 100n | Capacitor_SMD:C_0402_1005Metric | C2, C10, C11, C12, C13, C18, C19, C20, C21, C22, C23, C24, C25, C26, C27, C28 +18 |
| 24 | 49 | Resistor_SMD:R_0402_1005Metric | R17, R18, R19, R20, R21, R22, R23, R24, R25, R26, R27, R28, R29, R30, R31, R32 +8 |
| 21 | LXES15AAA1-133 | Resistor_SMD:R_0402_1005Metric | D10, D11, D12, D13, D14, D15, D16, D17, D18, D19, D20, D21, D22, D23, D24, D25 +5 |
| 18 | TestPoint | TestPoint:TestPoint_Pad_D1.0mm | TP3, TP4, TP13, TP14, TP15, TP18, TP19, TP20, TP21, TP22, TP24, TP25, TP26, TP28, TP29, TP30 +2 |
| 11 | 10k | Resistor_SMD:R_0402_1005Metric | R16, R48, R50, R53, R54, R55, R56, R57, R58, R59, R60 |
| 8 | 4k7 | Resistor_SMD:R_0402_1005Metric | R42, R43, R44, R45, R46, R47, R49, R52 |
| 7 | 10n | Capacitor_SMD:C_0402_1005Metric | C3, C7, C14, C37, C44, C54, C55 |
| 6 | 100@100MHz | Inductor_SMD:L_0603_1608Metric | FB1, FB2, FB3, FB4, FB5, FB6 |
| 5 | 220 | Resistor_SMD:R_0402_1005Metric | R1, R5, R14, R15, R40 |
| 4 | 10 | Resistor_SMD:R_0402_1005Metric | R3, R4, R7, R8 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_ISO14580_Pad | H1, H2, H3, H4 |
| 3 | 10u | Capacitor_SMD:C_0603_1608Metric | C17, C29, C31 |
| 3 | B5819W SL | Diode_SMD:D_SOD-123 | D6, D7, D8 |
| 3 | JST SH1-4P | Connector_JST:JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J7, J8, J9 |
| 3 | LED_Small | LED_SMD:LED_0603_1608Metric | D3, D4, D5 |
| 2 | 10p | Capacitor_SMD:C_0402_1005Metric | C33, C34 |
| 2 | 1u | Capacitor_SMD:C_0603_1608Metric | C1, C38 |
| 2 | 22u | Capacitor_SMD:C_0603_1608Metric | C30, C32 |
| 2 | 2u2 | Capacitor_SMD:C_0402_1005Metric | C15, C16 |
| 2 | 56k | Resistor_SMD:R_0402_1005Metric | R12, R61 |
| 2 | 68 | Resistor_SMD:R_0603_1608Metric | R2, R6 |
| 2 | MHT194CRGBCT | flightController:0605 | D1, D2 |
| 2 | PMBT3904 | Package_TO_SOT_SMD:SOT-23 | Q1, Q2 |
| 2 | USB_B_Mini | Connector_USB:USB_Mini-B_Wuerth_65100516121_Horizontal | J1, J2 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R62 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R11 |
| 1 | 13k | Resistor_SMD:R_0402_1005Metric | R13 |
| 1 | 16Mhz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | HSE1 |
| 1 | 1k | Resistor_SMD:R_0603_1608Metric | R10 |
| 1 | 1mm header | Connector_PinHeader_1.27mm:PinHeader_2x05_P1.27mm_Vertical_SMD | J6 |
| 1 | 2.54mm header | flightController:PinHeader_2x08_P2.54mm_Horizontal_lessSilk | J4 |
| 1 | 2.54mm header | flightController:PinHeader_1x08_P2.54mm_Vertical_lessSilk | J3 |
| 1 | 220n | Capacitor_SMD:C_0603_1608Metric | C8 |
| 1 | 2n2 | Capacitor_SMD:C_0402_1005Metric | C5 |
| 1 | 4u7 | Capacitor_SMD:C_0603_1608Metric | C9 |
| 1 | 560 | Resistor_SMD:R_0603_1608Metric | R9 |
| 1 | 560 | Resistor_SMD:R_0402_1005Metric | R51 |
| 1 | AMS1117-5V | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U6 |
| 1 | BMP388 | flightController:PQFN50P200X200X80-10N | U4 |
| 1 | CH330N | Package_SO:SOP-8_3.9x4.9mm_P1.27mm | U10 |
| 1 | FM24C64B | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U3 |
| 1 | HMC5883L | flightController:LGA-16_3x3mm_P0.5mm_Large_Pads | U2 |
| 1 | JST SH1-2P | Connector_JST:JST_SHL_SM02B-SHLS-TF_1x02-1MP_P1.00mm_Horizontal | J10 |
| 1 | JST SH1-8P | Connector_JST:JST_SH_SM08B-SRSS-TB_1x08-1MP_P1.00mm_Horizontal | J12 |
| 1 | MOLEX 5268-7P | Connector_Molex:Molex_SPOX_5268-07A_1x07_P2.50mm_Horizontal | J11 |
| 1 | MPU-6000 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U1 |
| 1 | SPX3819M5-L-3-3/TR | Package_TO_SOT_SMD:SOT-23-5 | U7 |
| 1 | STM32H743VIT6 | Package_QFP:LQFP-100_14x14mm_P0.5mm | U5 |
| 1 | SW_Push | Button_Switch_SMD:SW_SPST_FSMSM | SW2 |
| 1 | SW_SPDT | Button_Switch_SMD:SW_SPDT_PCM12 | SW1 |
| 1 | TF-01A | flightController:TF-01A | J5 |
It measures 57 × 57 mm and has 4 copper layers, 1.59 mm thick.
199 parts, built around the STM32H743VIT6, CH330N, BMP388 and TF-01A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Mathijsvb/MulticopterFCS repository on GitHub, at the commit this page was made from: the board is Hardware/KiCad/flightController.kicad_pcb and its schematic Hardware/KiCad/Connectors.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the BSD-3-Clause licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

yagamy4680/drone-study
AUAV-OpenSource/FMUv4-PixRacer is the open hardware design of PixHawk FMUv4. It uses STM32F427 and MPU6000. (github)


jbteja/tj01-ms51-heater-controller
A heater control system featuring deterministic operation, safety auto-cutoff, predefined timer modes, and temperature measurement using a K-type thermocouple.


Hanqaqa/Easyduino
Easily dive into different PCB KiCad designs of the most popular microcontroller devboards