
2 layers65 × 120 mm
Diy robotics gripper
mathias31415/diy_robotics
Gripper, PCBs and ROS2 software for Six-Axis Robot Arm WE-R2.4 from LoboCNC
12 parts39

 mathias31415/diy_robotics39
Gripper, PCBs and ROS2 software for Six-Axis Robot Arm WE-R2.4 from LoboCNC
Diy robotics arm is an open-source printed circuit board by mathias31415, from the mathias31415/diy_robotics repository on GitHub. It is a 2-layer board of 125 × 125 mm with 34 parts on 99 nets, routed with 386 tracks and 0 vias.
It is built around the DRV8825PWP. Its parts include 9 connectors, 7 ICs, 6 capacitors and 6 switches. It belongs with the robots and motor control boards and the ESP32 boards of this library.
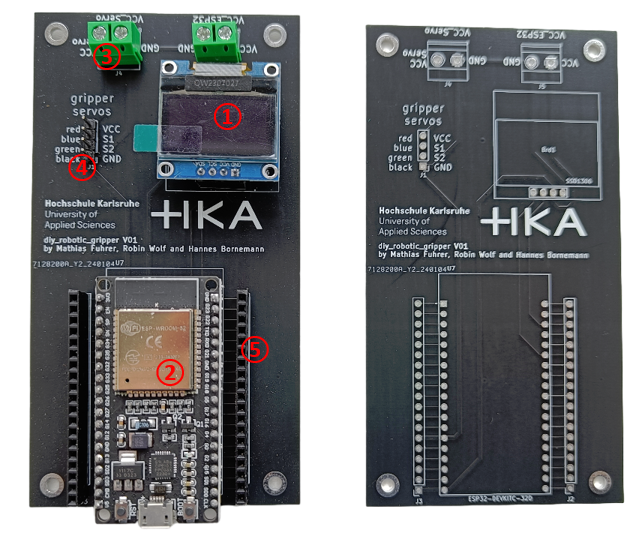
① 0.96 Inch OLED Display SSD1306 (1 pcs.)
② ESP-32 (1 pcs.)
③ 2-Pin Screw Terminal 5mm (2 pcs.)
④ Pin Header 1x4 Male 2,54mm (1 pcs.)
⑤ Pin Header Female 2,54mm
(① and ② are plugged into female pin header 2,54mm)
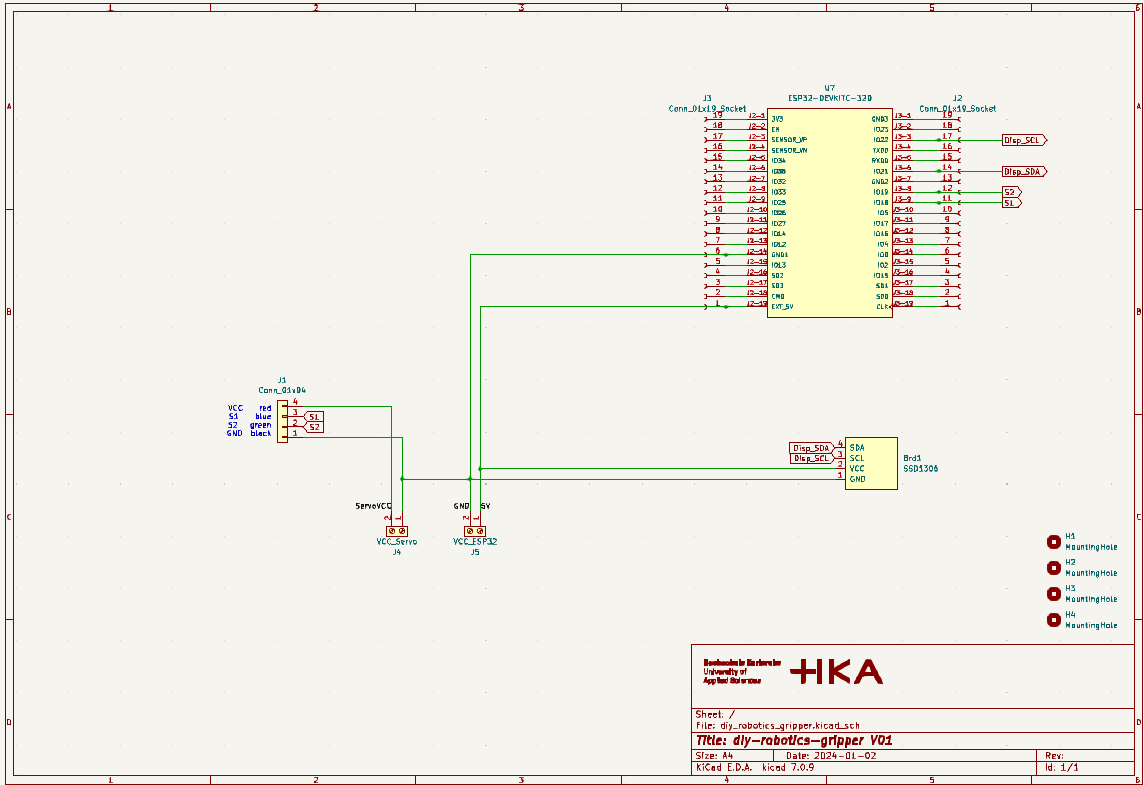
5V for the ESP32 power supply must be connected to the "VCC_ESP32" screw terminal. The power supply for the servo must be connected to the "VCC_Servo" screw terminal (6V). The servos are connected to the pin header "gripper servos".
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 100uF | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C1, C2, C3, C4, C5, C6 |
| 6 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1, J2, J3, J4, J5, J6 |
| 6 | DRV8825 | DRV8825:DRV8825_Breakout_15.2x20.3mm | U1, U2, U3, U4, U5, U6 |
| 6 | SW_DIP_x04 | Button_Switch_THT:SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW1, SW2, SW3, SW4, SW5, SW6 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_DIN965_Pad | H1, H2, H3, H4 |
| 1 | ESP32-DEVKITC-32D | ESP32-DEVKITC-32D:MODULE_ESP32-DEVKITC-32D | U7 |
| 1 | Enable | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J8 |
| 1 | LOGO | LOGO | G*** |
| 1 | SSD1306 | SSD1306-128x64:128x64OLED | Brd1 |
| 1 | VCC_ESP32 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J7 |
| 1 | VCC_Stepper | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J9 |
mathias31415/diy_robotics
Gripper, PCBs and ROS2 software for Six-Axis Robot Arm WE-R2.4 from LoboCNC


o7-machinehum/Hydroponic
Please find the electronics files in the ee folder, all pcb design is done with the open source software KiCad. Is uses an STM32 as the main controller, and an ST L6470 moter driver for the stepper motor.

eli3162/diw_printer
Direct ink Writing(DIW) is a technology that enables 3d printers to print many gels, solvents, and other liquids instead of normal plastic filaments.


It measures 125 × 125 mm and has 2 copper layers, 1.6 mm thick.
34 parts, built around the DRV8825PWP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the mathias31415/diy_robotics repository on GitHub, at the commit this page was made from: the board is diy_robotics_arm_pcb/diy_robotics_arm.kicad_pcb and its schematic diy_robotics_arm_pcb/diy_robotics_arm.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask mathias31415 before reusing the design.