
2 layers45 × 80 mm
Bridge
lachlanhurst/dukki
Bipedal robot based on Microduck, rebuilt around Unitree J288 servos and a Radxa CM4.
72 parts2MIT

Bipedal robot based on Microduck, rebuilt around Unitree J288 servos and a Radxa CM4.
Head is an open-source printed circuit board by lachlanhurst, from the lachlanhurst/dukki repository on GitHub, published under the MIT licence. It is a 2-layer board of 80 × 55 mm with 68 parts on 175 nets, routed with 642 tracks and 252 vias.
It is built around the MAX98357AETE+T, AMS1117-3.3 and BMI088, with the AO3400A, B5819W and SMBJ30A among its other parts. Its parts include 16 capacitors, 14 resistors, 13 connectors, 4 ICs and 3 diodes. It belongs with the robots and motor control boards and the Raspberry Pi (Linux) boards of this library.


[!IMPORTANT] Everything in here is very much a work in progress!
A rework of the Pollen Robotics Microduck with a few hardware changes:
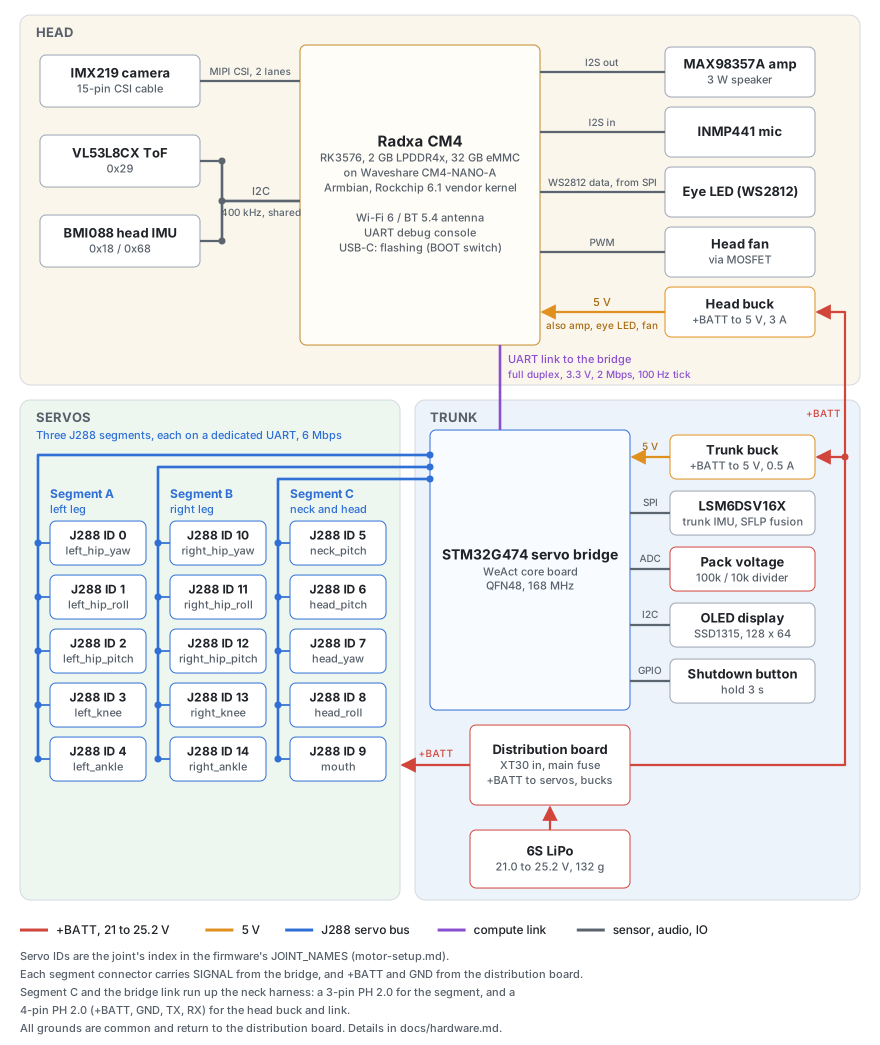
This repository holds the Dukki documentation, the hardware design files (KiCad), and the code that doesn't fit neatly into one of the forked repos, such as the STM32 servo bridge firmware, compute module setup scripts and J288 bench test tools. Changes elsewhere live on branches of forked repos: the robot firmware in microduck (dukki), RL training in microduck_rl (dukki-j288), the J288 actuator model in bam (unitree-j288) and the head IMU driver in bmi088-rs (configurable-addresses).
Hardware is the main design document. It covers each subsystem (servos, compute, the STM32 servo bridge, IMUs, power, audio, camera, ToF) and compares it with the OG robot.
Compute setup takes a Radxa CM4 from the box to a board on WiFi at microduck.local. That includes flashing Armbian to the eMMC.
Servo setup is the bench procedure for each J288 before assembly. You set the bus ID with Unitree's Windows tool, record the firmware version, run a motion check and label the servo for its joint.
J288 bench testing has the results from characterising one servo: bus timing, friction, armature, torque limits and heating. The main finding is that peak output torque is about 0.45 N·m, close to the XL330.
Camera setup and audio setup bring up the IMX219 camera and the MAX98357A speaker and INMP441 microphone on the CM4.
MIT, see LICENSE. The third-party datasheets and schematics in docs/datasheets/ belong to their publishers and are not covered by it.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 100n 50V | Capacitor_SMD:C_0603_1608Metric | C4, C5, C11, C13, C14, C15, C16 |
| 4 | 4.7k | Resistor_SMD:R_0603_1608Metric | R8, R9, R10, R11 |
| 4 | M2 | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4 |
| 3 | 47u 10V | Capacitor_SMD:C_1206_3216Metric | C6, C7, C8 |
| 2 | 100k | Resistor_SMD:R_0603_1608Metric | R4, R6 |
| 2 | 10u 25V | Capacitor_SMD:C_0805_2012Metric | C9, C12 |
| 2 | 10u 50V X7R | Capacitor_SMD:C_1210_3225Metric | C1, C2 |
| 2 | 1k | Resistor_SMD:R_0603_1608Metric | R12, R13 |
| 2 | 330R | Resistor_SMD:R_0603_1608Metric | R7, R14 |
| 2 | GND | TestPoint:TestPoint_Pad_D1.5mm | TP3, TP6 |
| 2 | cut for ext IMU | Jumper:SolderJumper-2_P1.3mm_Bridged_RoundedPad1.0x1.5mm | JP4, JP5 |
| 1 | 100R | Resistor_SMD:R_0603_1608Metric | R5 |
| 1 | 15k | Resistor_SMD:R_0603_1608Metric | R2 |
| 1 | 1M | Resistor_SMD:R_0603_1608Metric | R3 |
| 1 | 22u 25V | Capacitor_SMD:C_0805_2012Metric | C10 |
| 1 | 4.7u | Inductor_SMD:L_Sunlord_SWPA6045S | L1 |
| 1 | 47u 50V | Capacitor_SMD:CP_Elec_6.3x7.7 | C17 |
| 1 | 82k | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U3 |
| 1 | AO3400A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | B5819W | Diode_SMD:D_SOD-123 | D2 |
| 1 | BMI088 | Package_LGA:Bosch_LGA-16_4.5x3mm_P0.5mm_LayoutBorder7x1y_ClockwisePinNumbering | U5 |
| 1 | CM4 socket 1-100 | DukkiHead:DF40C_Socket_CM4_1-100 | J9 |
| 1 | CM4 socket 101-200 | DukkiHead:DF40C_Socket_CM4_101-200 | J10 |
| 1 | CM4_MASKROM | TestPoint:TestPoint_Pad_D1.5mm | TP2 |
| 1 | CM4_RESET | TestPoint:TestPoint_Pad_D1.5mm | TP1 |
| 1 | Camera | DukkiHead:FPC_XUNPU_FPC-1.0HF-15PWAR-H20_1x15-1MP_P1.0mm | J8 |
| 1 | Ext 5V | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J12 |
| 1 | Ext amp | Connector_PinHeader_2.54mm:PinHeader_1x07_P2.54mm_Vertical | J11 |
| 1 | Eye LED | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J4 |
| 1 | Fan | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J6 |
| 1 | Head bundle | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J1 |
| 1 | I2C breakout | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J3 |
| 1 | LMR51635YDDCR | Package_TO_SOT_SMD:TSOT-23-6 | U2 |
| 1 | MAX98357AETE+T | Package_DFN_QFN:TQFN-16-1EP_3x3mm_P0.5mm_EP1.23x1.23mm | U4 |
| 1 | Microphone | Connector_JST:JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J7 |
| 1 | Radxa CM4 | DukkiHead:Radxa_CM4_Module | H5 |
| 1 | SERVO_PWM | TestPoint:TestPoint_Pad_D1.5mm | TP7 |
| 1 | SMBJ30A | Diode_SMD:D_SMB | D1 |
| 1 | SPI pads | DukkiHead:SolderPads_1x09_P2.54mm_SPI | J13 |
| 1 | Speaker | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J5 |
| 1 | ToF | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | J2 |
| 1 | USB_DN | TestPoint:TestPoint_Pad_D1.5mm | TP4 |
| 1 | USB_DP | TestPoint:TestPoint_Pad_D1.5mm | TP5 |
| 1 | cut for ext 5V | DukkiHead:SolderJumper-2_Wide_Bridged_3A | JP1 |
| 1 | cut for ext amp | DukkiHead:SolderJumper-2_Wide_Bridged_3A | JP3 |
| 1 | green | LED_SMD:LED_0603_1608Metric | D3 |
lachlanhurst/dukki
Bipedal robot based on Microduck, rebuilt around Unitree J288 servos and a Radxa CM4.

Simplycissmus/windowmaster-s3-controller
Open hardware and ESP32-S3 firmware for a local 24 V window actuator controller with MQTT and Home Assistant integration.

HeyPCB/quack-core
Brain board for the Open Duck Mini: Pi Zero 2W carrier, 14-servo STS bus, fused 2S power path in stitched copper zones (15-18 A battery side), USB-C charging with balancing, IMU.

HeyPCB/kestrel-fc
Kestrel H7: STM32H743 FPV flight controller with ICM-20602 + BMI088, MS5611, 16 MB blackbox, 5 V and switchable 10 V BECs.

tmb5932/fixed-wing-drone
The basics needed to allow a RC plane to be turned autonomous on signal.

ara-mkr/f405-flight-controller
This is a flight controller I designed as a side project. It was fun and pretty challenging, and I'm planning to build a drone with it at some point!

laurigates/mcu-tinkering-lab
This repository contains projects for various embedded platforms (ESP32, Arduino, STM32).


ajisrawi/DroneMagNav2.0
DroneMagNav 2.0 - survey-fluxgate magnetic-anomaly navigation board for drones (IGRF-14 + EMAG2v3 continued to flight altitude)
It measures 80 × 55 mm and has 2 copper layers, 1.6 mm thick.
68 parts, built around the MAX98357AETE+T, AMS1117-3.3, BMI088 and AO3400A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the lachlanhurst/dukki repository on GitHub, at the commit this page was made from: the board is hardware/head/head.kicad_pcb and its schematic hardware/bridge/bridge.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).