
4 layers165 × 107 mm

 kitspace/jelly5
A jellyfish shaped light-following bristle bot
Jelly is an open-source printed circuit board by kitspace, from the kitspace/jelly repository on GitHub. It is a 2-layer board of 59.9 × 32.9 mm with 39 parts on 13 nets, routed with 123 tracks and 4 vias.
It is built around the JS202011SCQN. Its parts include 15 connectors, 2 resistors, 2 diodes, 2 transistors and 1 switch.
This is a small light following robot that consists of a simple analog circuit and uses pager vibration motors and toothbrush heads as a form of locomotion. This was heavily inspired by Facelesstech's project but adds jellyfishness (with the help of svg2mod).
You can buy most of the parts through the Kitspace page but you will also need:
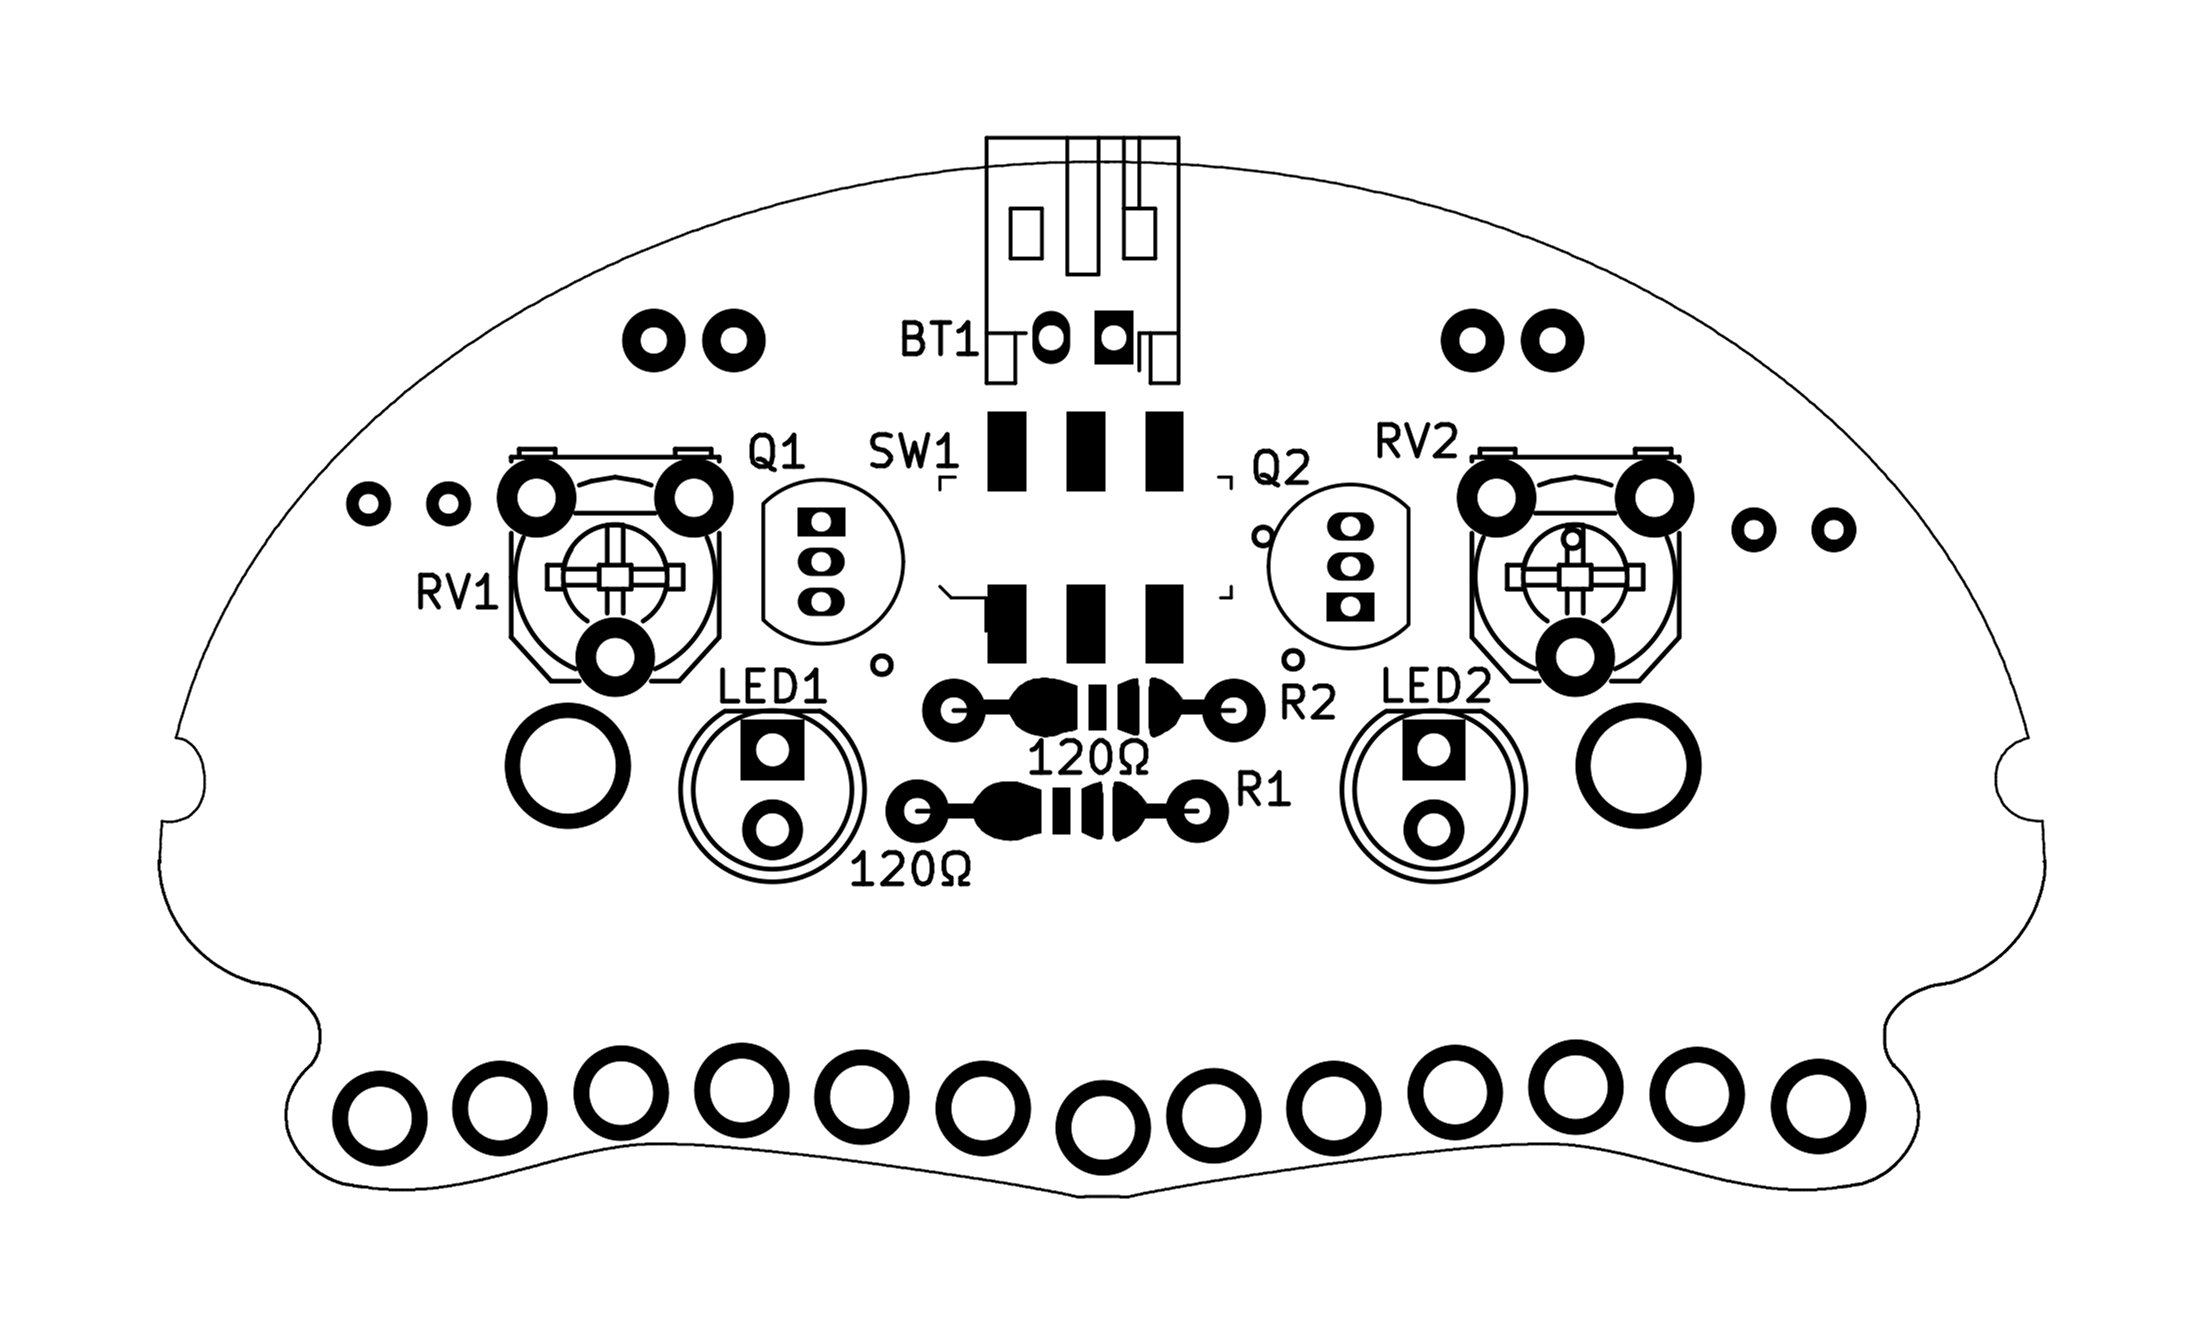
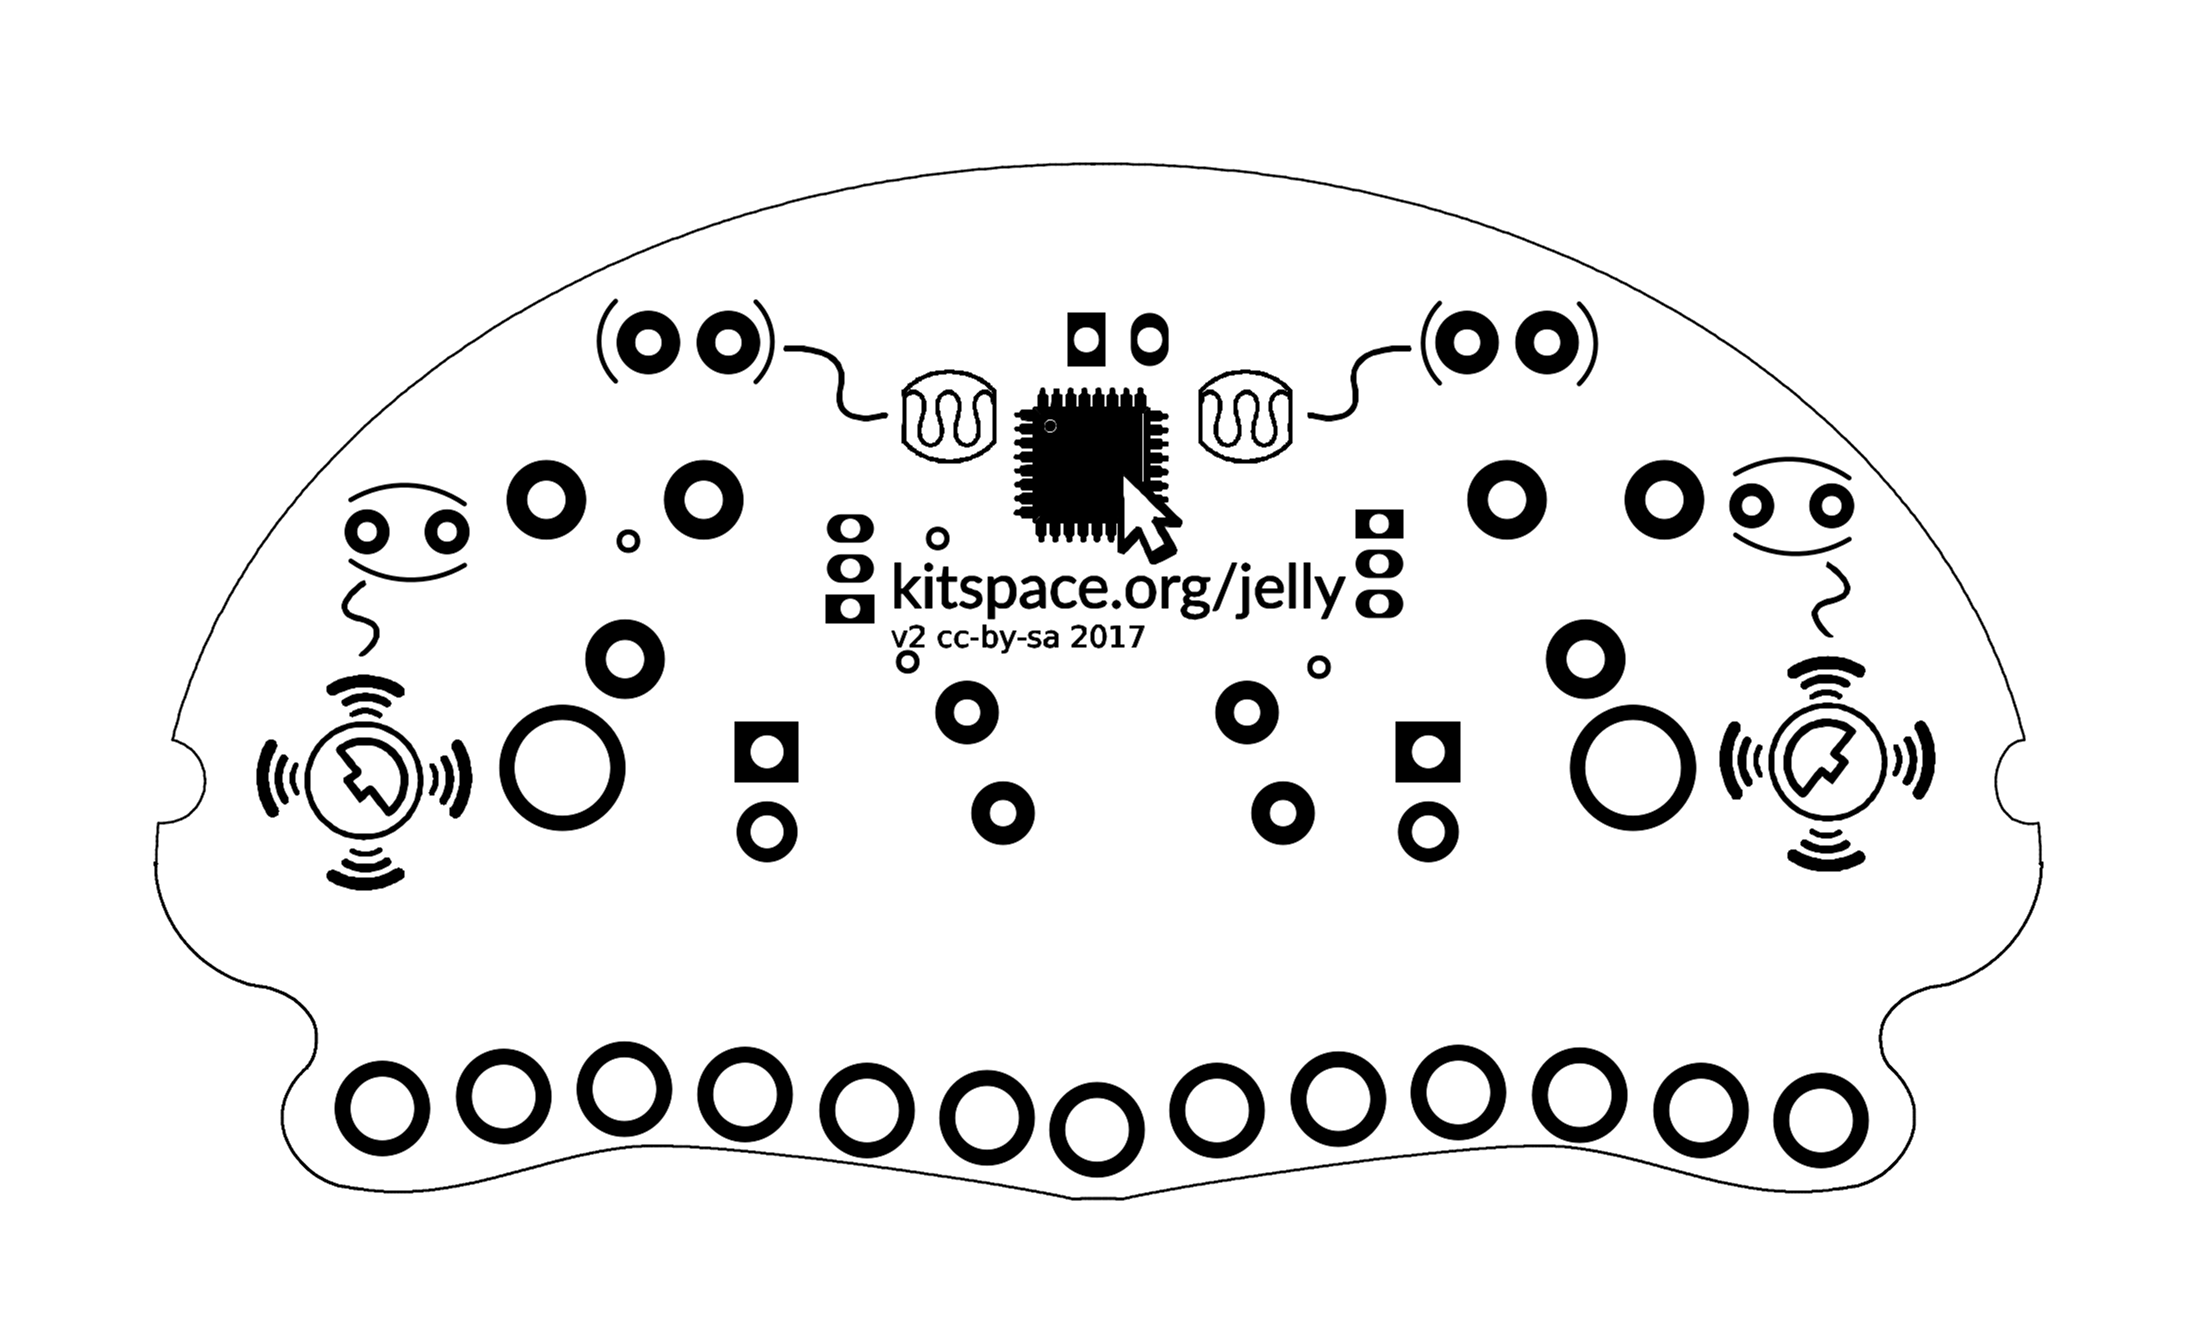
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | CONN_01X01 | custom:hole2 | P3, P4, P5, P6, P7, P8, P9, P10, P11, P12, P13, P14, P15 |
| 2 | 120Ω | custom:R3-5 | R1, R2 |
| 2 | CONN_01X01 | custom:hole | P1, P2 |
| 2 | LED | KiCad/LEDs.pretty:LED-5MM | LED1, LED2 |
| 2 | PAGER_MOTOR | custom:pager_motor_custom | M1, M2 |
| 2 | POT | KiCad/Potentiometers.pretty:Potentiometer_Triwood_RM-065 | RV1, RV2 |
| 2 | Photores | custom:ldr | PHOTO1, PHOTO2 |
| 2 | Q_NMOS_SGD | KiCad/kicad-footprints/Package_TO_SOT_THT.pretty:TO-92_Inline_Narrow_Oval | Q1, Q2 |
| 1 | BATTERY | KiCad/Connectors_JST.pretty:JST_PH_S2B-PH-K_02x2.00mm_Angled | BT1 |
| 1 | JS202011SCQN | custom:JS202011SCQN | SW1 |
| 1 | jelly | custom:jelly | DNP1 |
| 1 | jelly_mirrored | custom:jelly_mirrored | DNP8 |
| 1 | ldr_image | custom:ldr_image_flipped | DNP3 |
| 1 | ldr_image | custom:ldr_image | DNP2 |
| 1 | logo | custom:logo | DNP4 |
| 1 | name | custom:name | DNP5 |
| 1 | pager_motor_image1 | custom:page_motor_image | DNP10 |
| 1 | pager_motor_image2 | custom:page_motor_image_flipped | DNP11 |
| 1 | resistor_R1 | custom:resistor | DNP6 |
| 1 | resistor_R2 | custom:resistor | DNP7 |
It measures 59.9 × 32.9 mm and has 2 copper layers, 1.6 mm thick.
39 parts, built around the JS202011SCQN. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the kitspace/jelly repository on GitHub, at the commit this page was made from: the board is kicad/jelly.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask kitspace before reusing the design.

aws/iot-expresslink
This device was designed and created for the AWS IoT ExpressLink Demo Badge Workshop, which was run at re:Invent 2022.

GMUCERG/fobos
Flexible Open-source workBench fOr Side-channel analysis (FOBOS)

konrad1s/LineFollower-Kwark
Fast LineFollower Robot project. Build on STM32 F7 microcontroller with custom PCB. Software, Hardware and QT Application.

onolab-tmu/blinky
Hardware design files and software for a flexible and portable sound-to-light conversion device.


neubauek/CircuitPythonBadge
Open Source Hardware Circuit Python Badge

RemkoPr/icra2025-SMI-tactile-sensing
[Main Paper, Follow-up] The source files in this repo are provided as-is, additional support for recreating the design can be requested, see contact information below.