2 layers97 × 77.5 mm
ESPlant
CCHS-Melbourne/ESPlant
Environmental Sensor Plant - solar WiFi gardening/meteorological sensor using ESP8266
77 parts37

 KBieszczad/Bike-Computer
Custom bike computer with speed tracking, GPS, environmental sensors, and OLED display, built on nRF52840 using PlatformIO.
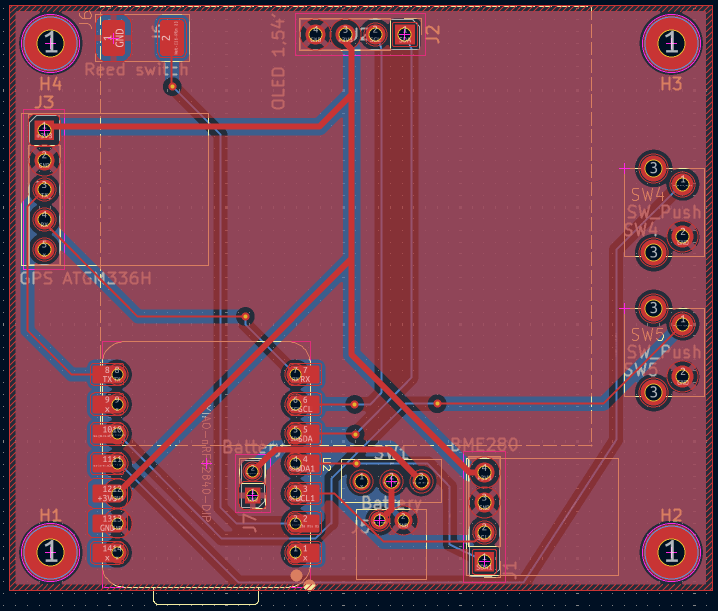
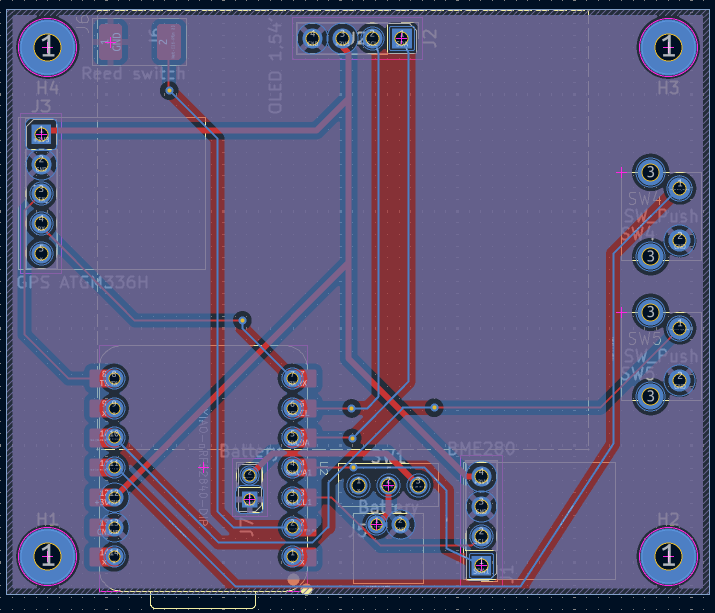
Bike Computer is an open-source printed circuit board by KBieszczad, from the KBieszczad/Bike-Computer repository on GitHub, published under the MIT licence. It is a 2-layer board of 60 × 50 mm with 14 parts on 21 nets, routed with 61 tracks and 6 vias.
It is built around the BME280 and SS-12D00-G3. Its parts include 6 connectors, 3 switches and 1 IC. It belongs with the lEDs and displays and radio and wireless boards and the nRF52 and nRF5x boards of this library.


A low-power custom bicycle computer featuring speed measurement, GPS tracking, environmental sensing, and an OLED display. The hardware is designed from scratch with a custom PCB created in KiCad.
This project aims to build a standalone, power-efficient bike computer. At its core is the Seeed Studio XIAO nRF52840, a very energy efficient microcontroller with native Bluetooth Low Energy support.
The device combines data from a classic magnetic reed switch (for precise speed and distance tracking) with an external GPS module for recording traces. Additionally, it integrates a BME280 sensor to monitor environmental conditions (temperature, humidity, and barometric pressure).
delay() functions..gpx file compatible with for example Strava..
├── hardware/
│ ├── project.kicad_sch # KiCad Schematic file
│ ├── project.kicad_pcb # KiCad PCB layout file
│ └── img/ # Schematic and PCB layout images
├── software/ # PlatformIO Firmware files
└── README.md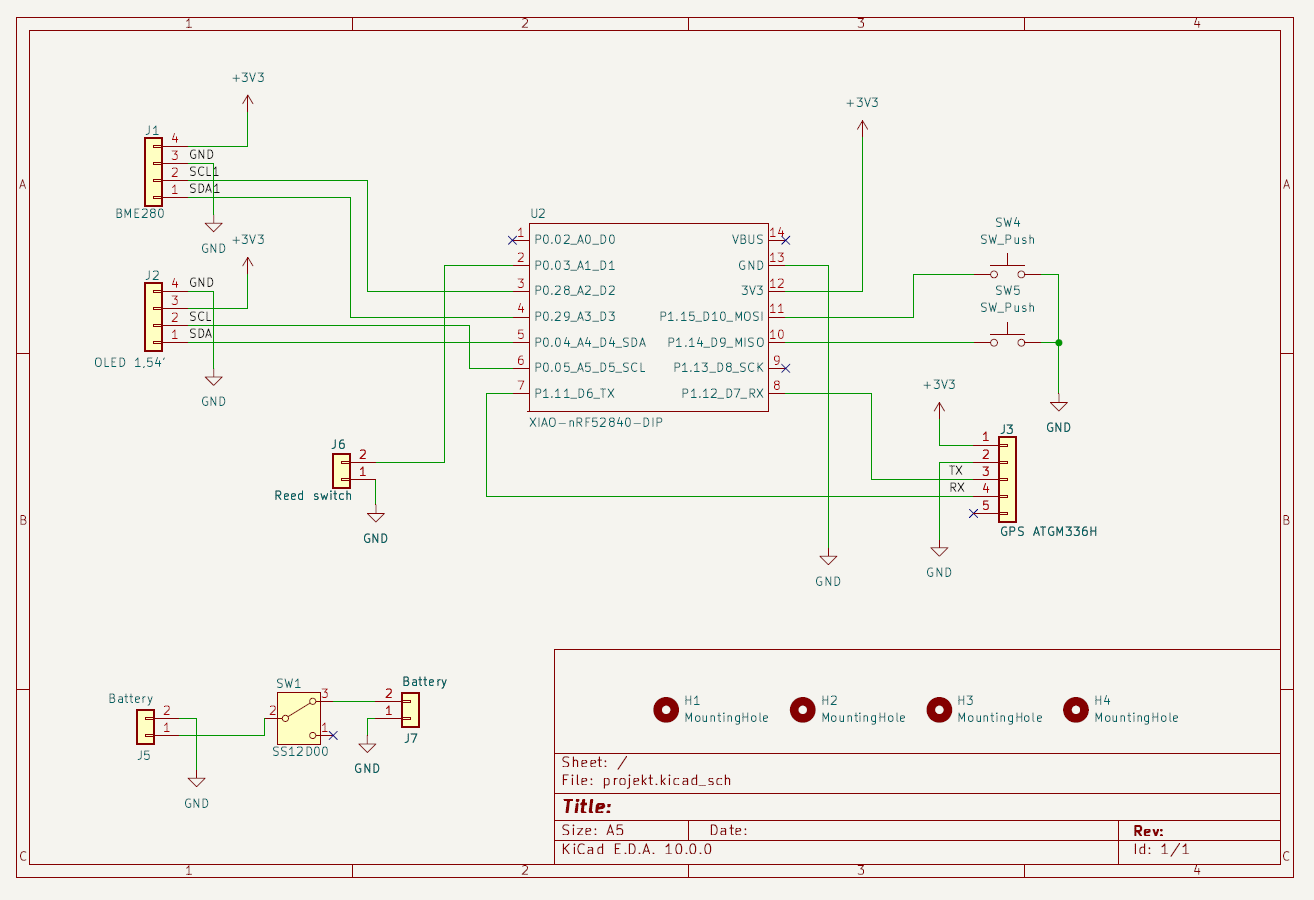
platformio.inigit clone https://github.com/KBieszczad/Bike-Computer.gitsoftware folder in VS Code (PlatformIO).ON in the GPS Settings screen. The device will automatically start tracking your route once satellites are locked and movement is detected.115200 baud..gpx file, and upload it directly to Strava or GPX Studio.Krzysztof Bieszczad @KBieszczad
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2_Pad | H1, H2, H3, H4 |
| 2 | SW_Push | licznik_lbr:tact_switch | SW4, SW5 |
| 1 | BME280 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | Battery | Connector_PinHeader_2.00mm:PinHeader_1x02_P2.00mm_Vertical | J7 |
| 1 | Battery | licznik_lbr:jst_2mm | J5 |
| 1 | GPS ATGM336H | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J3 |
| 1 | OLED 1,54' | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | Reed switch | licznik_lbr:reed_switch | J6 |
| 1 | SS12D00 | licznik_lbr:SS12D00 | SW1 |
| 1 | XIAO-nRF52840-DIP | Seeed_Studio_XIAO_Series:XIAO-nRF52840-DIP | U2 |
It measures 60 × 50 mm and has 2 copper layers, 1.6 mm thick.
14 parts, built around the BME280 and SS-12D00-G3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the KBieszczad/Bike-Computer repository on GitHub, at the commit this page was made from: the board is hardware/project.kicad_pcb and its schematic hardware/project.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
CCHS-Melbourne/ESPlant
Environmental Sensor Plant - solar WiFi gardening/meteorological sensor using ESP8266

ozkan/Cockpit-Keyboard
A hot swap system column staggered mechanical keyboard, running QMK Firmware on Pro Micro controllers.

Ardakilic/woodpecker-keyboard
5 row ortholinear keyboard, based on Lumberelite and Lumberjack

IamPhytan/christmas-tree-pcb
Christmas Tree PCB, made with FOSS

Pacane/pacino
Hand-wired wireless split keyboard: printable OpenSCAD case/plate with STEP output for Fusion 360. Cheapino-descended layout, nRF52840 + ZMK, Amoeba-King hot-swap.

ChristopherAwomolo/Nova-Micromouse
Newer version based off the Futura Micromouse

darshg321/Minicopter
Compact and precise ESP-32 based drone capable of autonomous pathing, built from scratch
